


bridge
#PWM
#full bridge
#half bridge
#motor controller
#H-bridge
#power electronics
#switching circuits
#driver circuit
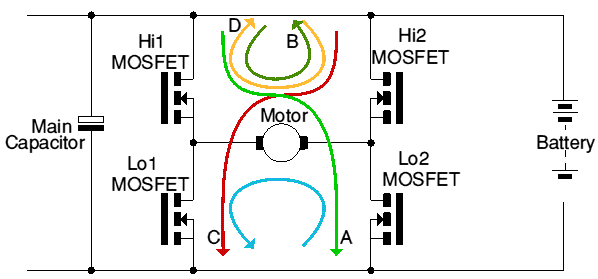
Description: Before attempting to understand a full bridge circuit, it is advisable to familiarize oneself with PWM controllers, which also explain the operation of a half-bridge circuit. Most full bridge motor controllers utilize PWM. Designing a reliable and user-friendly full-bridge PWM circuit is quite challenging. 4QD released its first such controller in 1992; while it may not have been the first, it was certainly among the early entrants in this field. The circuit comprises a full bridge of four MOSFETs. In forward drive, current flows in the direction indicated by the pale green arrow A, from the positive battery terminal, through Hi1, through the motor, and then through Lo2 to the negative battery terminal. In reverse drive, current flows in the direction of the red arrow C. Given the current state of integrated circuits and N-channel MOSFETs, it is generally unwise to use the high-side as the main active switching element; therefore, PWM is typically applied to the low-side MOSFETs, allowing the high-side ones to assume a more passive role. For forward drive, Hi1 would be continuously on, Hi2 off, Lo1 off, and Lo2 on, potentially modulated by PWM. If PWM is employed, when Lo2 is off, motor current must continue flowing in the same direction, sustained by the motor's inductance, utilizing Hi2 as a flywheel diode, as represented by the dark green arrow B. The operation of the high-side MOSFET during the flywheel period is not critical; if it is activated, resistive losses will occur instead of the diode drop, which could result in greater losses. It is essential to use a static, pumped supply for the high-side gate drives, as a bootstrap type charge pump will not function unless the output is switching. At full motor speed, nothing in the bridge is switching, leading to bootstrap failure. The overall design largely depends on the desired level of safety for the circuit. A commercial-grade controller must endure nearly any user action and requires adequate protection in all four quadrants. This necessitates current limiting on both halves of the bridge, applicable in both drive and regenerative modes, which significantly increases complexity.
Regarding regenerative braking, it is likely that PWM switching will be employed for the low-side transistors, and current monitoring is most straightforward when performed on the low-side MOSFETs. Considering forward regenerative braking, the current direction is reversed compared to forward drive, represented by the green arrow A. During forward drive, the left end of the motor is positive (connected to the battery positive via a turned-on Hi1). In forward braking, the motor's back EMF is of the same polarity as in forward drive (since the motor is rotating in the same direction), yet the current direction must be reversed (indicated by the blue arrow). Therefore, Lo2 must remain permanently on, shorting the right side of the motor to the battery negative, while Lo1 is modulated on and off with the PWM signal. This configuration allows Lo1 to operate with positive voltages and currents, simplifying current sensing and limiting. If Lo1 is pulsed, when it is off, the motor's inductive energy will continue to drive current, seeking to flywheel through Hi1 (with Lo2 fully on) back into the battery, facilitating regeneration (opposite to current arrow A). Alternative schemes exist, but they often involve high-side chopping or negative current sensing. Another option is to incorporate a resistor in the motor circuit and utilize a floating differential op-amp for current sensing, although this method is not practical due to the cost and size of resistors capable of handling several hundred amps, which must be integrated seamlessly into the controller's design. It is also crucial to ensure proper timing to avoid conflicts between Hi1 and Lo1 (or Hi2 and Lo2).Before trying to understand a full bridge circuit, you may care to read up on PWM controllers, which page also describes how a half-bridge circuit works. Most full bridge motor controllers also use pwm! Designing a full-bridge PWM circuit that is reliable and `user-proof` is actually quite difficult! 4QD released our first such controller in 1992: it was probably not the first but was certainly early in the race. The circuit shows a full bridge of four MOSFETs. In forward drive, current must flow in the direction of the pale green arrow A from battery positive, through Hi1, through the motor and so through Lo2 to battery negative. In reverse drive, current must flow in the direction of the red arrow C. With the current state of ICs and N channel MOSFETs, only a fool or a masochist would use the hi-side as the main active switching element, so it is normal to apply PWM to the loside MOSFETs, and to let the Hi-side ones take a more passive role.
So, for forward drive, Hi 1 would be permanently on, Hi2 off, Lo1 off and Lo2 on, maybe chopped in PWM mode. If PWM is used, then, when Lo2 is off, motor current will still need to keep flowing in the same direction, forced to do so by the motor`s inductance, and it will use Hi2 as a `flywheel` diode as shown by the dark green arrow B.
It matters not a lot whether the hiside MOSFET is turned on during the flywheel period: if it is on, then resistive losses apply rather than the diode drop that would cause more rather more loss. Note that you will need to use a static, pumped supply for the hi-side gate drives. A Bootstrap type charge pump won`t work unless the output is switching and, at full motor speed, nothing in the bridge is switching, so the bootstrap will fail.
The rest of the design rather depends on how `safe` you want to make the circuit. A proper commercial controller needs to survive almost anything a user can do to it, and requires proper protection in all four quadrants. So it needs current limiting on both halves of the bridge, not only in drive mode but also in regen mode.
This of course adds significantly to the complexity! So - what about regenerative braking Given the facts that you will probably want to PWM switch the lo-side transistors and that current monitoring is easiest done in the loside MOSFETs, consider forward regen braking. Forward drive current is the green arrow, A. So during forward braking the current is reversed with respect to this. In forward drive, the left hand end of the motor is positive (it was connected to battery + by a turned-on Hi1).
In forward braking, the motor`s back emf is of the same polarity as for forward drive (as the motor is rotating in the same direction), but the current must be reversed (blue arrow). So the left end of the motor will still be positive. So we must permanently turn on Lo2, shorting the RH side of the motor to battery negative and we must chop Lo1 on and off with the PWM signal.
That way Lo1 is still working with positive voltages and currents, making it easier to think about and easier to use for current sensing and current limiting. If Lo 1 is chopping then, when it is off, motor inductive energy will still cause current to flow and it will want to flywheel through Hi1 (remember, Lo2 is on full-time) back into the battery, giving the regeneration (reverse of current arrow A).
There are of course other schemes possible, but they either involve chopping the hi-sides, or sensing negative currents. Or you could put a resistor in the motor and use a floating differential op-amp to sense motor current.
Rather you that I! A resistor to sense currents of maybe several hundred amps is neither a common nor a small item and is therefore of significant cost! And it has to be incorporated neatly into the controller`s design. You may also realise from the above that, provided you don`t get the timing totally wrong, so that Hi 1 and Lo 1 (or Hi2 and Lo2 for that ma
Regarding regenerative braking, it is likely that PWM switching will be employed for the low-side transistors, and current monitoring is most straightforward when performed on the low-side MOSFETs. Considering forward regenerative braking, the current direction is reversed compared to forward drive, represented by the green arrow A. During forward drive, the left end of the motor is positive (connected to the battery positive via a turned-on Hi1). In forward braking, the motor's back EMF is of the same polarity as in forward drive (since the motor is rotating in the same direction), yet the current direction must be reversed (indicated by the blue arrow). Therefore, Lo2 must remain permanently on, shorting the right side of the motor to the battery negative, while Lo1 is modulated on and off with the PWM signal. This configuration allows Lo1 to operate with positive voltages and currents, simplifying current sensing and limiting. If Lo1 is pulsed, when it is off, the motor's inductive energy will continue to drive current, seeking to flywheel through Hi1 (with Lo2 fully on) back into the battery, facilitating regeneration (opposite to current arrow A). Alternative schemes exist, but they often involve high-side chopping or negative current sensing. Another option is to incorporate a resistor in the motor circuit and utilize a floating differential op-amp for current sensing, although this method is not practical due to the cost and size of resistors capable of handling several hundred amps, which must be integrated seamlessly into the controller's design. It is also crucial to ensure proper timing to avoid conflicts between Hi1 and Lo1 (or Hi2 and Lo2).Before trying to understand a full bridge circuit, you may care to read up on PWM controllers, which page also describes how a half-bridge circuit works. Most full bridge motor controllers also use pwm! Designing a full-bridge PWM circuit that is reliable and `user-proof` is actually quite difficult! 4QD released our first such controller in 1992: it was probably not the first but was certainly early in the race. The circuit shows a full bridge of four MOSFETs. In forward drive, current must flow in the direction of the pale green arrow A from battery positive, through Hi1, through the motor and so through Lo2 to battery negative. In reverse drive, current must flow in the direction of the red arrow C. With the current state of ICs and N channel MOSFETs, only a fool or a masochist would use the hi-side as the main active switching element, so it is normal to apply PWM to the loside MOSFETs, and to let the Hi-side ones take a more passive role.
So, for forward drive, Hi 1 would be permanently on, Hi2 off, Lo1 off and Lo2 on, maybe chopped in PWM mode. If PWM is used, then, when Lo2 is off, motor current will still need to keep flowing in the same direction, forced to do so by the motor`s inductance, and it will use Hi2 as a `flywheel` diode as shown by the dark green arrow B.
It matters not a lot whether the hiside MOSFET is turned on during the flywheel period: if it is on, then resistive losses apply rather than the diode drop that would cause more rather more loss. Note that you will need to use a static, pumped supply for the hi-side gate drives. A Bootstrap type charge pump won`t work unless the output is switching and, at full motor speed, nothing in the bridge is switching, so the bootstrap will fail.
The rest of the design rather depends on how `safe` you want to make the circuit. A proper commercial controller needs to survive almost anything a user can do to it, and requires proper protection in all four quadrants. So it needs current limiting on both halves of the bridge, not only in drive mode but also in regen mode.
This of course adds significantly to the complexity! So - what about regenerative braking Given the facts that you will probably want to PWM switch the lo-side transistors and that current monitoring is easiest done in the loside MOSFETs, consider forward regen braking. Forward drive current is the green arrow, A. So during forward braking the current is reversed with respect to this. In forward drive, the left hand end of the motor is positive (it was connected to battery + by a turned-on Hi1).
In forward braking, the motor`s back emf is of the same polarity as for forward drive (as the motor is rotating in the same direction), but the current must be reversed (blue arrow). So the left end of the motor will still be positive. So we must permanently turn on Lo2, shorting the RH side of the motor to battery negative and we must chop Lo1 on and off with the PWM signal.
That way Lo1 is still working with positive voltages and currents, making it easier to think about and easier to use for current sensing and current limiting. If Lo 1 is chopping then, when it is off, motor inductive energy will still cause current to flow and it will want to flywheel through Hi1 (remember, Lo2 is on full-time) back into the battery, giving the regeneration (reverse of current arrow A).
There are of course other schemes possible, but they either involve chopping the hi-sides, or sensing negative currents. Or you could put a resistor in the motor and use a floating differential op-amp to sense motor current.
Rather you that I! A resistor to sense currents of maybe several hundred amps is neither a common nor a small item and is therefore of significant cost! And it has to be incorporated neatly into the controller`s design. You may also realise from the above that, provided you don`t get the timing totally wrong, so that Hi 1 and Lo 1 (or Hi2 and Lo2 for that ma
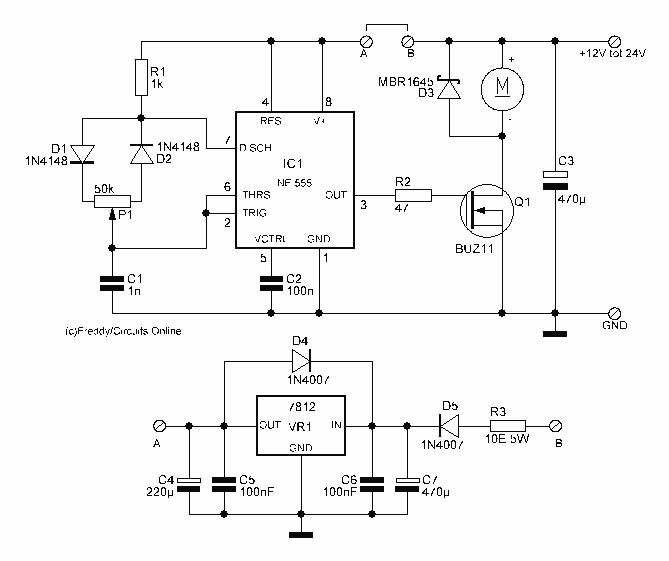
Motor Control circuit II
This circuit is 12 volt motors and lights well regulated. The scheme operates with PWM (Pulse Width Modulation). By IC1, a 555 is a square wave generated by a controllable duty cycle. This means that the width of the pulse...
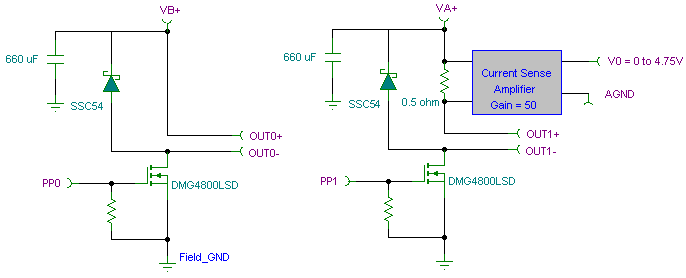
Pulse Width Modulation PWM Controller Board for DC Loads/devices
The PWM pulse width modulation controller board enables 9S12/HCS12 microcontrollers or PIC microcontrollers to output 8 channels, each capable of delivering 5 DC amps, while incorporating current sensing for the PWM waveform. This PWM driver circuit is suitable for applications...
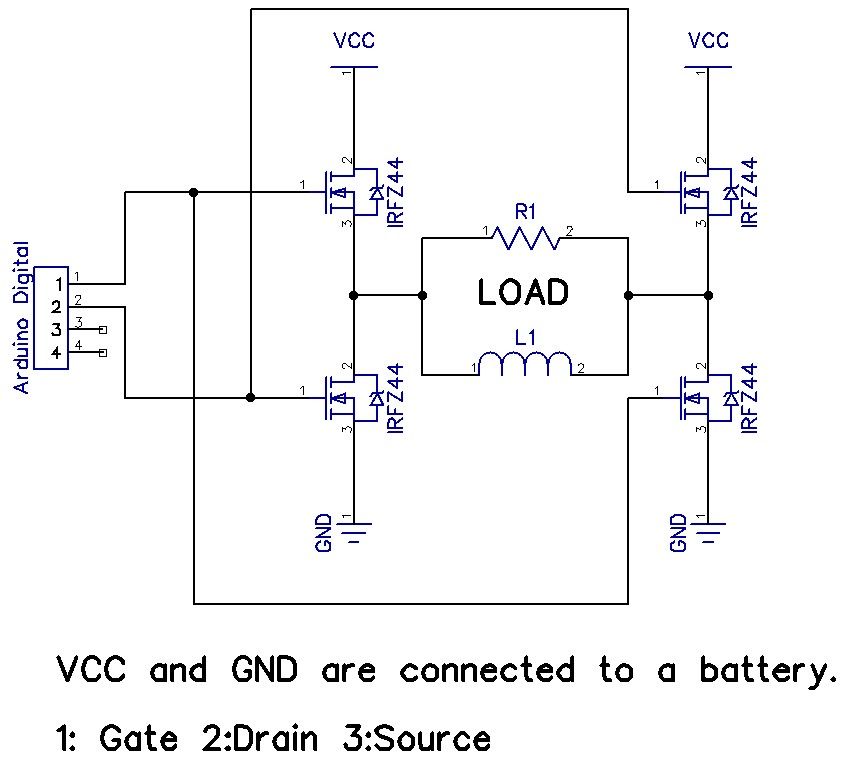
H-Bridge on a Breadboard
The H-Bridge is a circuit that can drive a motor in both forward and reverse directions. It can be a straightforward circuit that requires only a few components.
The H-Bridge circuit is a fundamental configuration used in motor control applications, allowing...
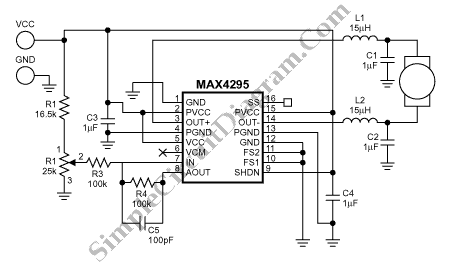
PWM Motor Speed Control Using Class D Audio Amplifier
This is a Class D audio amplifier circuit used to control the PWM motor speed. This circuit has two advantages for battery-powered portable devices. First, it provides high efficiency, which extends battery life.
The Class D audio amplifier operates by modulating...
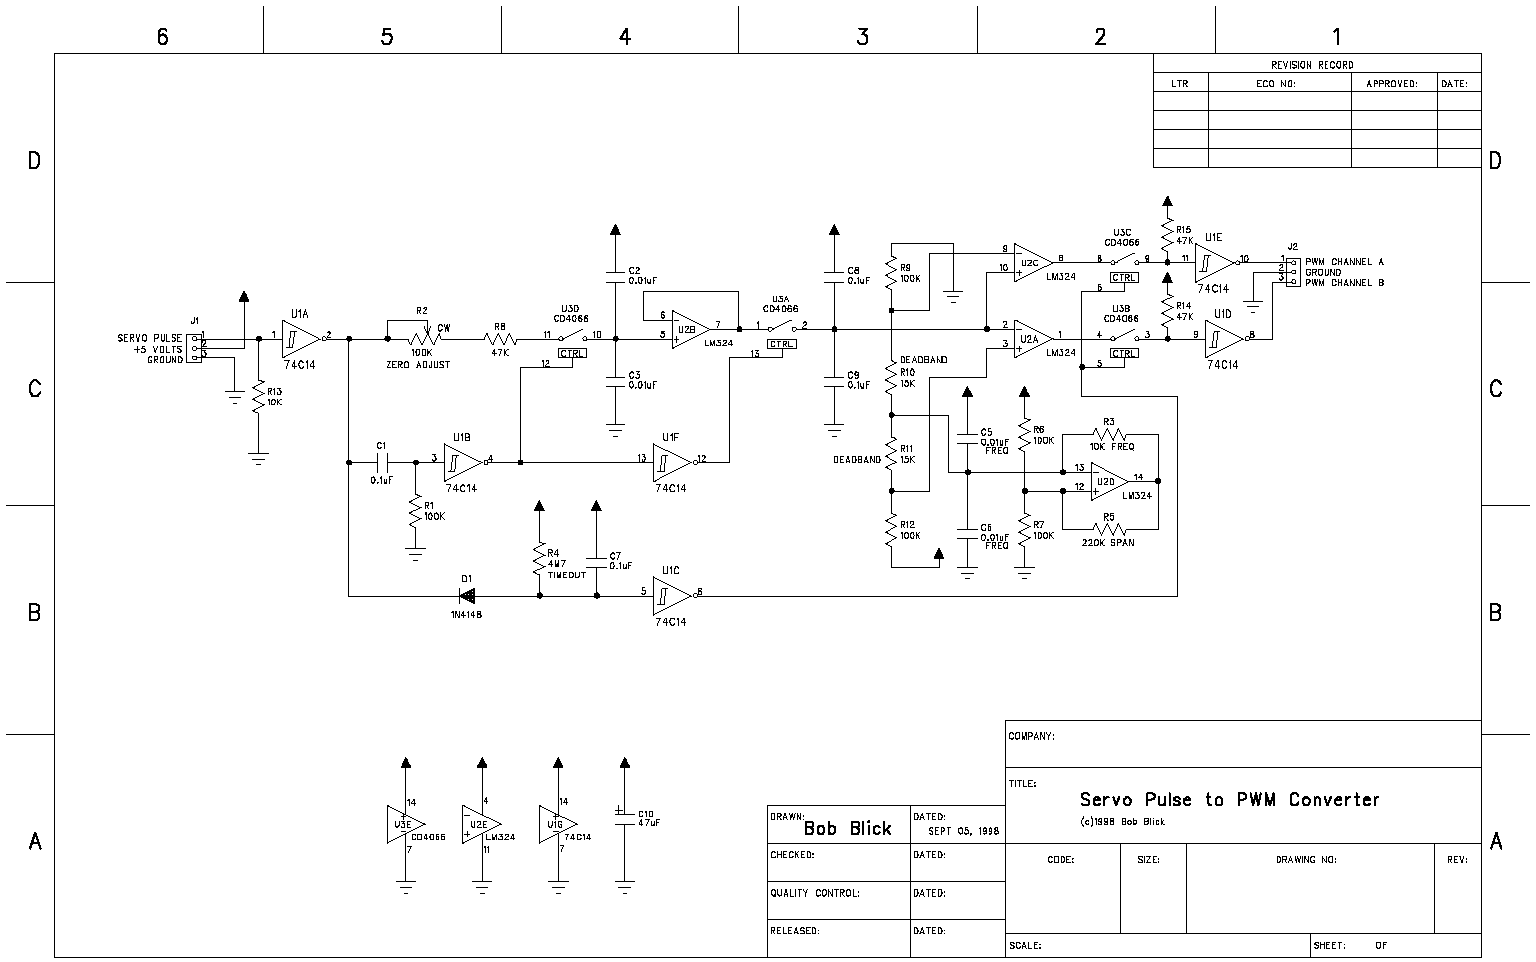
Servo pulse to PWM converter
The circuit presented on this page attempts to be an interface to convert pulses such as provided by a Basic Stamp or R/C receiver to a dual PWM (Pulse Width Modulation) signal required by an H-bridge. The simplest circuit would...
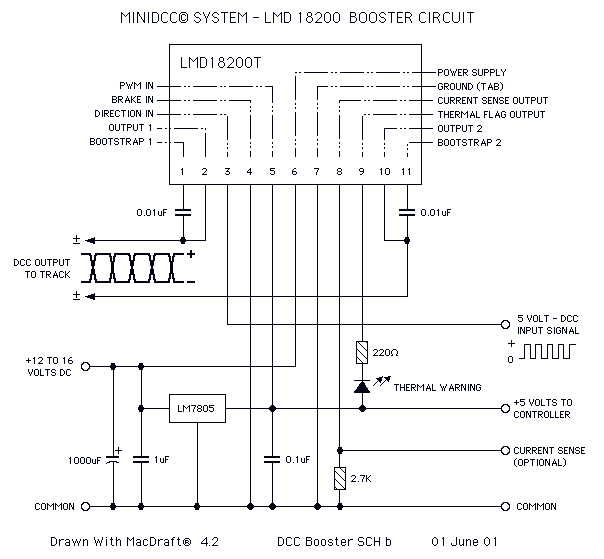
H Bridge Direct Current Motor Control Circuits
This page features H-Bridge circuits used for controlling direct current motors. Several designs are shown using both CMOS and Bi-Polar power devices. These circuits could be used as the basis for Model Railroad DCC Boosters or PWM motor controllers. The...
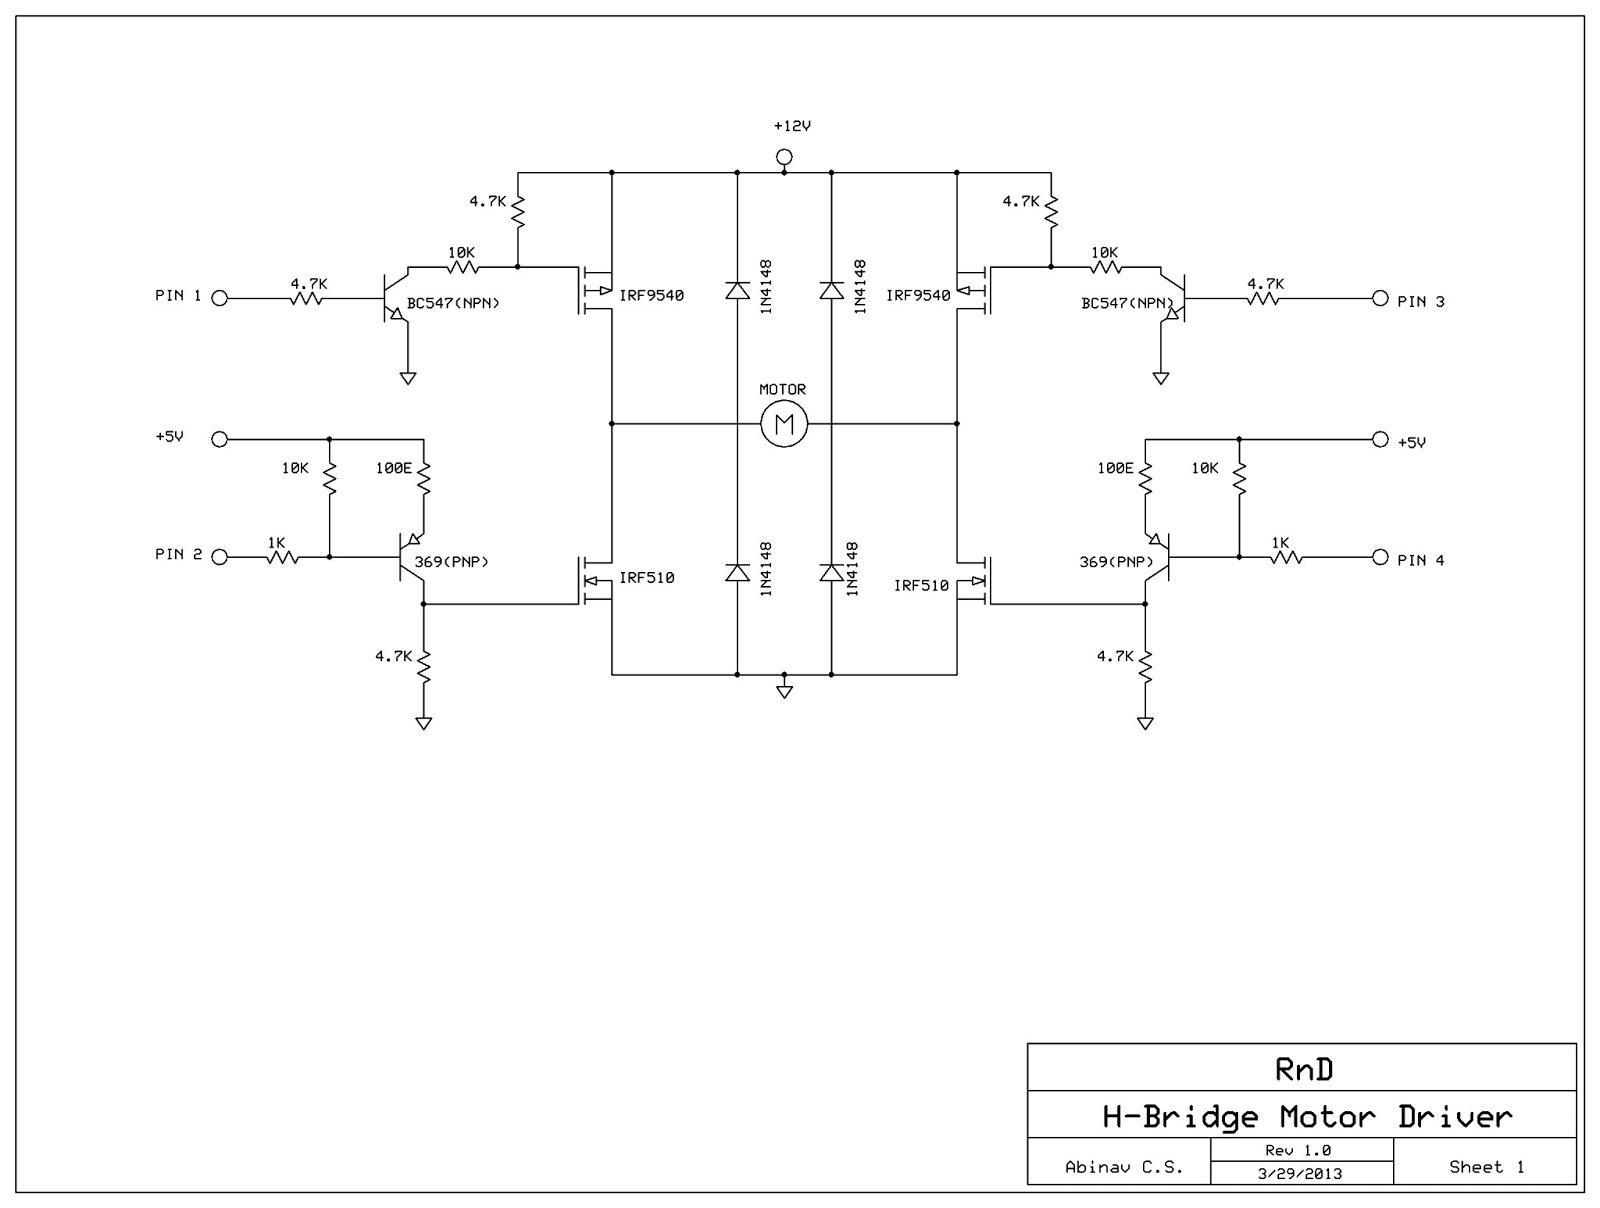
H-Bridge Motor Driver using MOSFETs and Transistors
This post discusses the construction of an H-Bridge Motor Driver circuit using simple MOSFETs and transistors. The primary feature of this H-Bridge is its ability to drive a motor in both directions. An H-Bridge is a circuit that allows voltage...
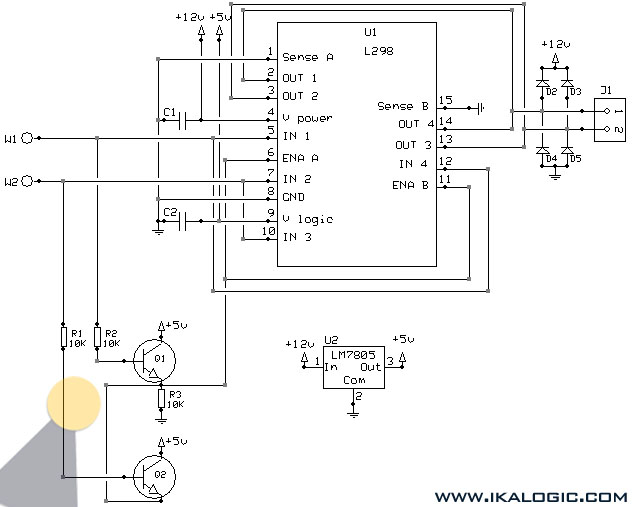
4A H-bridge motor driver using the L298 IC Schematic
This implementation utilizes the L298 integrated circuit to drive motors and inductive loads with a continuous current capacity of up to 4A. The L298 consists of two independent channels, each capable of driving loads of up to 2A. By connecting...
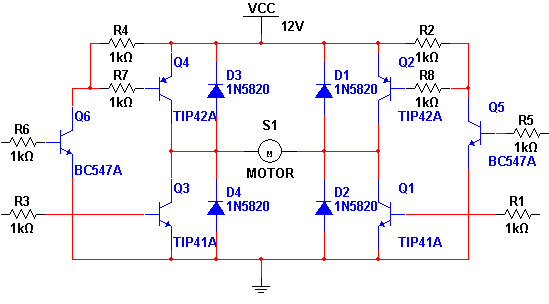
H-Bridge Transistor Smoking (Bipolar BJT Transistor)
This circuit operates with a 12V supply connected to a motor, utilizing transistors TIP 142 and TIP 147. Each transistor is controlled by a high (5V) or low (0V) signal through a 1kΩ resistor. The diodes used in the circuit...