


Bipolar stepper motor
#PIC microcontroller
#H-bridge
#L298
#bipolar stepper motor
#motor driver
#microcontroller
#stepper motor control
#robotics
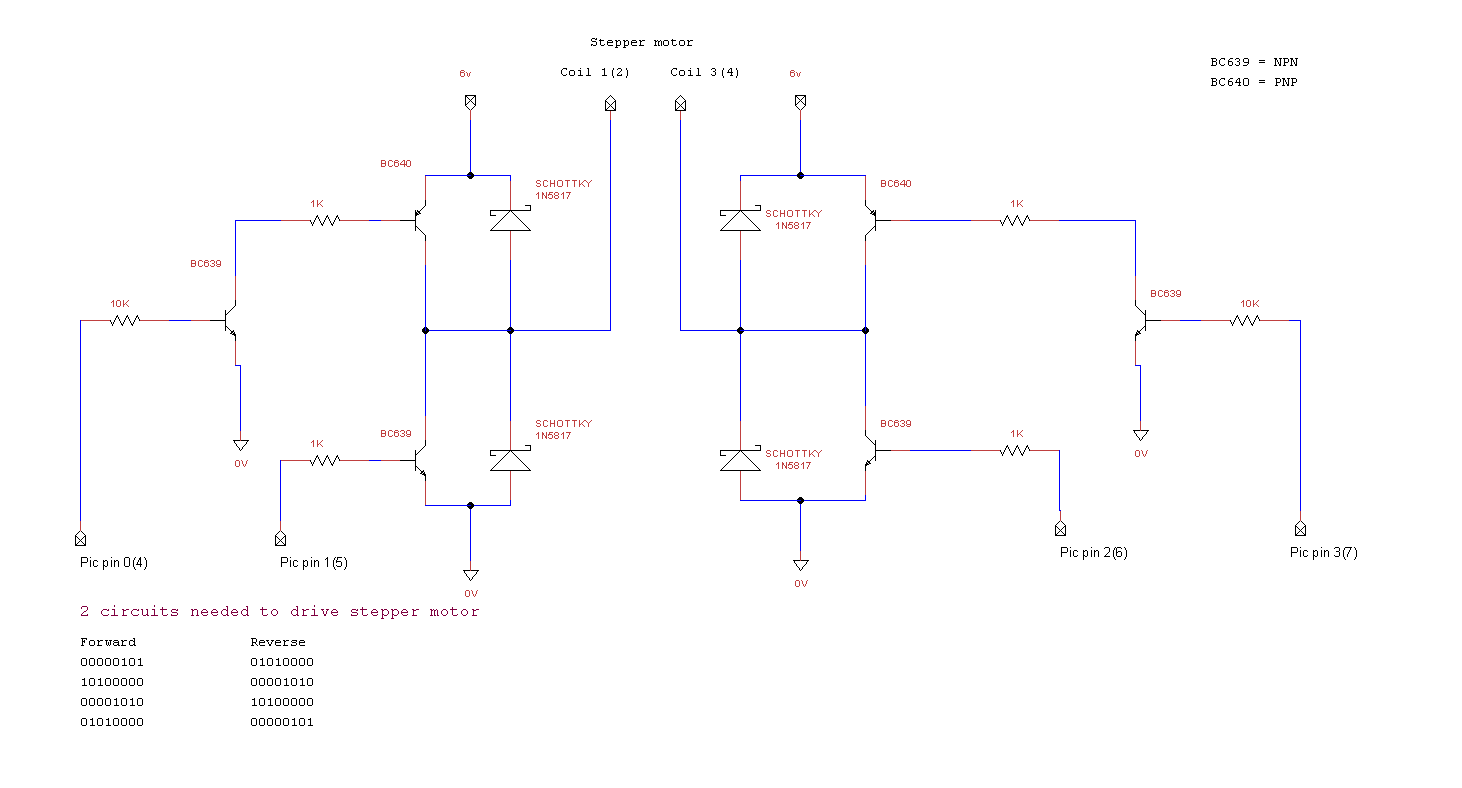
Description: miRover. This page details how to use a PIC microcontroller and an H-bridge or an L298 to drive a bipolar stepper motor.
The project involves utilizing a PIC microcontroller to control a bipolar stepper motor, which is commonly used in robotics and automation applications due to its precise positioning capabilities. The control of the stepper motor is achieved through an H-bridge circuit or specifically using the L298 dual H-bridge driver IC.
In this setup, the PIC microcontroller generates pulse-width modulation (PWM) signals that dictate the stepping sequence of the motor. The bipolar stepper motor requires alternating current in two coils to achieve rotation in either direction. The H-bridge or L298 allows the microcontroller to control the direction of the current flow through the motor coils, enabling precise control over the motor's movement.
The circuit typically includes the following components:
1. **PIC Microcontroller**: Acts as the central control unit, programmed to output the necessary signals for motor control.
2. **L298 H-Bridge Driver**: This IC contains two H-bridges, allowing it to control two motors or a single bipolar stepper motor. It can handle significant current and voltage, making it suitable for driving motors.
3. **Bipolar Stepper Motor**: The motor is characterized by its two coils, which are energized in a specific sequence to produce rotational motion.
4. **Power Supply**: Provides the required voltage and current to the L298 and the stepper motor.
5. **Control Circuitry**: This includes resistors, capacitors, and possibly diodes to protect the circuit and ensure stable operation.
The operation begins with the PIC generating a series of digital signals that correspond to the required stepping sequence. The L298 receives these signals and controls the power delivered to the motor coils. By adjusting the timing and sequence of the signals, the speed and direction of the motor can be controlled effectively.
It is essential to consider the specifications of the stepper motor and ensure that the L298 is capable of handling the motor's current requirements. Additionally, proper heat dissipation measures should be incorporated, as the L298 can generate heat during operation.
This configuration enables a robust and efficient system for driving a bipolar stepper motor, suitable for various applications in robotics and automation where precise control of movement is essential.miRover. This pages details how to use a PIC microcontroller and an H-bridge or a L298 to drive a Bipolar stepper motor
The project involves utilizing a PIC microcontroller to control a bipolar stepper motor, which is commonly used in robotics and automation applications due to its precise positioning capabilities. The control of the stepper motor is achieved through an H-bridge circuit or specifically using the L298 dual H-bridge driver IC.
In this setup, the PIC microcontroller generates pulse-width modulation (PWM) signals that dictate the stepping sequence of the motor. The bipolar stepper motor requires alternating current in two coils to achieve rotation in either direction. The H-bridge or L298 allows the microcontroller to control the direction of the current flow through the motor coils, enabling precise control over the motor's movement.
The circuit typically includes the following components:
1. **PIC Microcontroller**: Acts as the central control unit, programmed to output the necessary signals for motor control.
2. **L298 H-Bridge Driver**: This IC contains two H-bridges, allowing it to control two motors or a single bipolar stepper motor. It can handle significant current and voltage, making it suitable for driving motors.
3. **Bipolar Stepper Motor**: The motor is characterized by its two coils, which are energized in a specific sequence to produce rotational motion.
4. **Power Supply**: Provides the required voltage and current to the L298 and the stepper motor.
5. **Control Circuitry**: This includes resistors, capacitors, and possibly diodes to protect the circuit and ensure stable operation.
The operation begins with the PIC generating a series of digital signals that correspond to the required stepping sequence. The L298 receives these signals and controls the power delivered to the motor coils. By adjusting the timing and sequence of the signals, the speed and direction of the motor can be controlled effectively.
It is essential to consider the specifications of the stepper motor and ensure that the L298 is capable of handling the motor's current requirements. Additionally, proper heat dissipation measures should be incorporated, as the L298 can generate heat during operation.
This configuration enables a robust and efficient system for driving a bipolar stepper motor, suitable for various applications in robotics and automation where precise control of movement is essential.miRover. This pages details how to use a PIC microcontroller and an H-bridge or a L298 to drive a Bipolar stepper motor
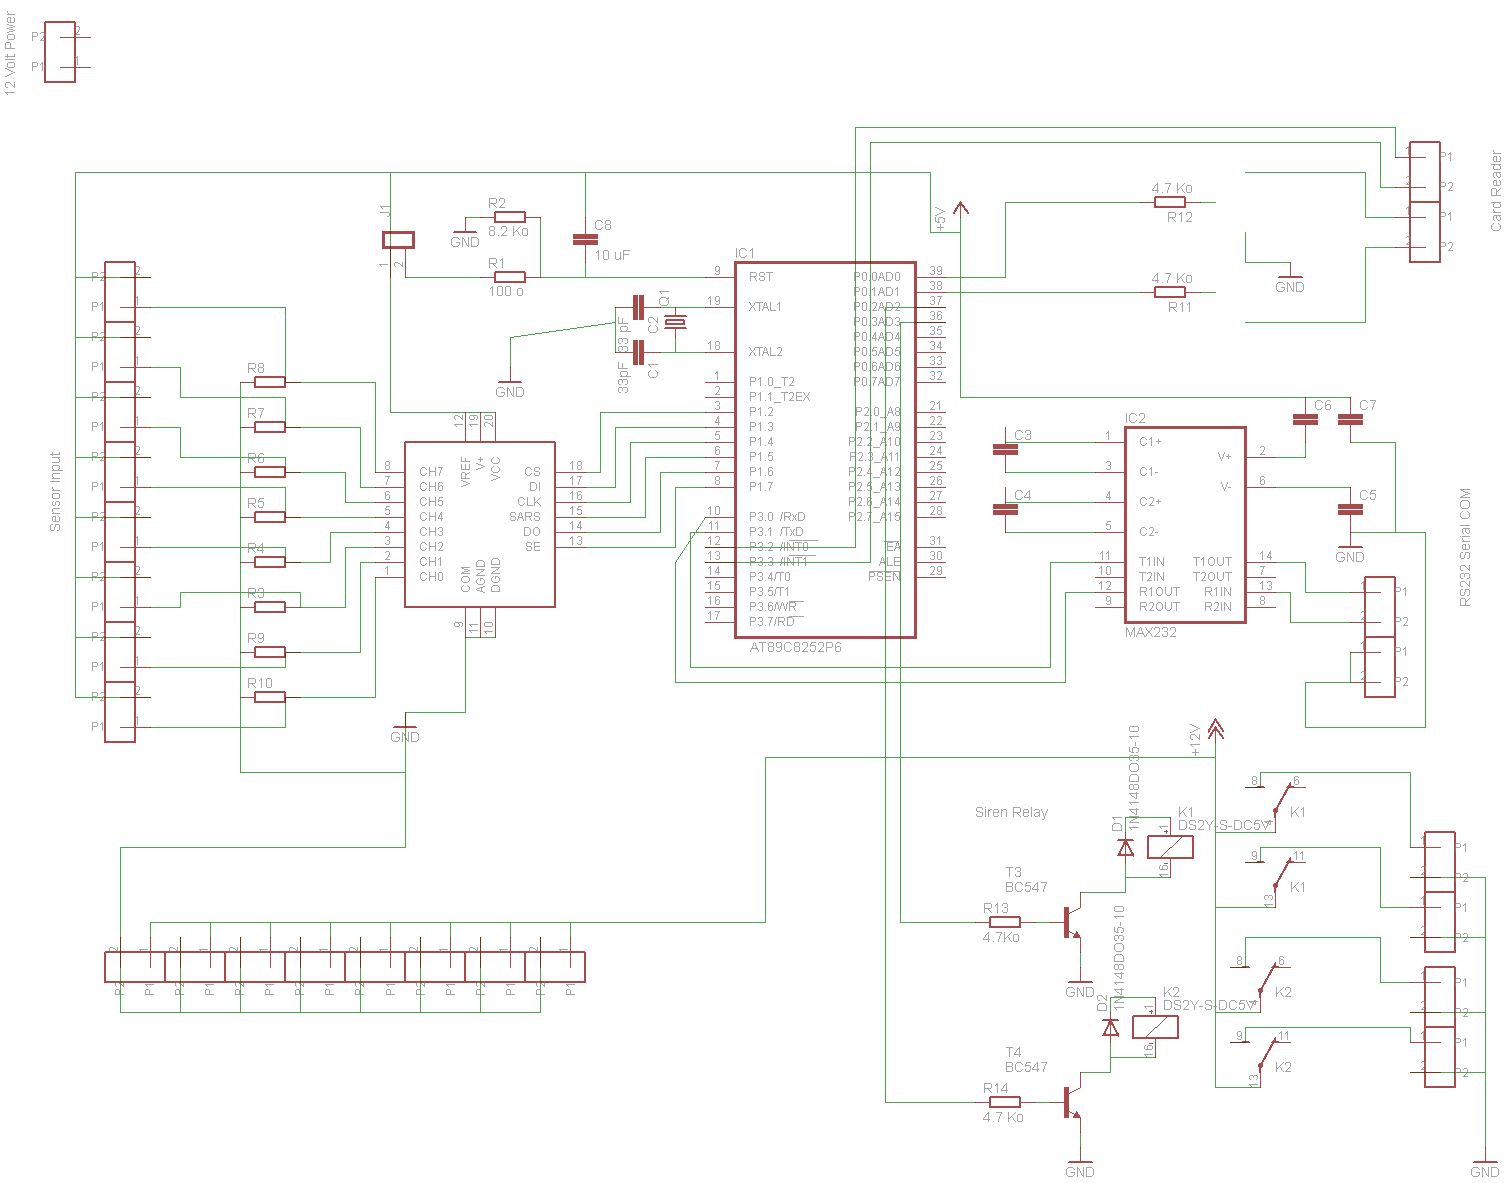
home security system
The fundamental design of this project employs an Atmel AT89S8252-24PC Microcontroller, which features 2KB of EEPROM for runtime data storage. An ADC0838CCN analog-to-digital converter will be utilized to process up to eight inputs from sensor devices, including passive infrared sensors...
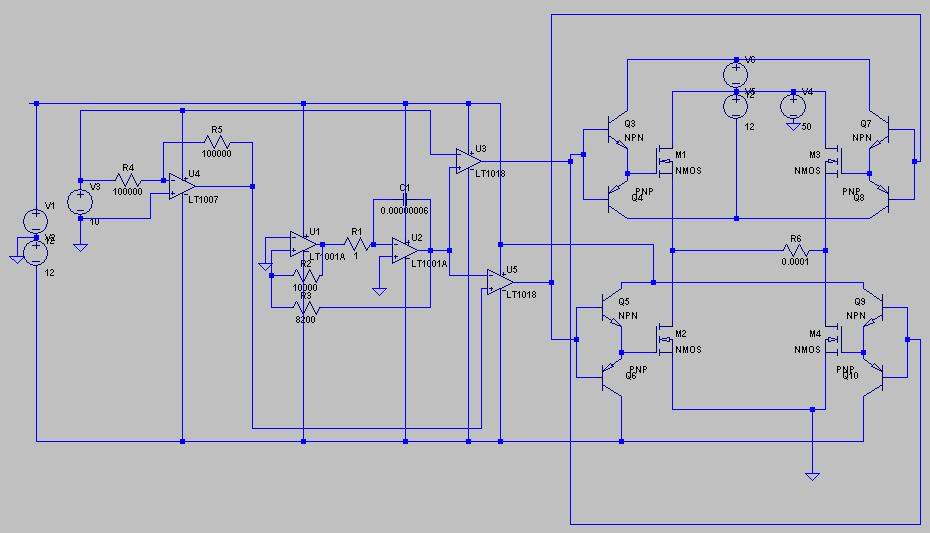
whats wrong my h bridge drivers
I have attempted to create drivers for my H-bridge circuit using complementary emitters; however, the square wave outputs consistently run at a constant 25V instead of a ±10V square wave. The image is somewhat difficult to interpret, but it appears...
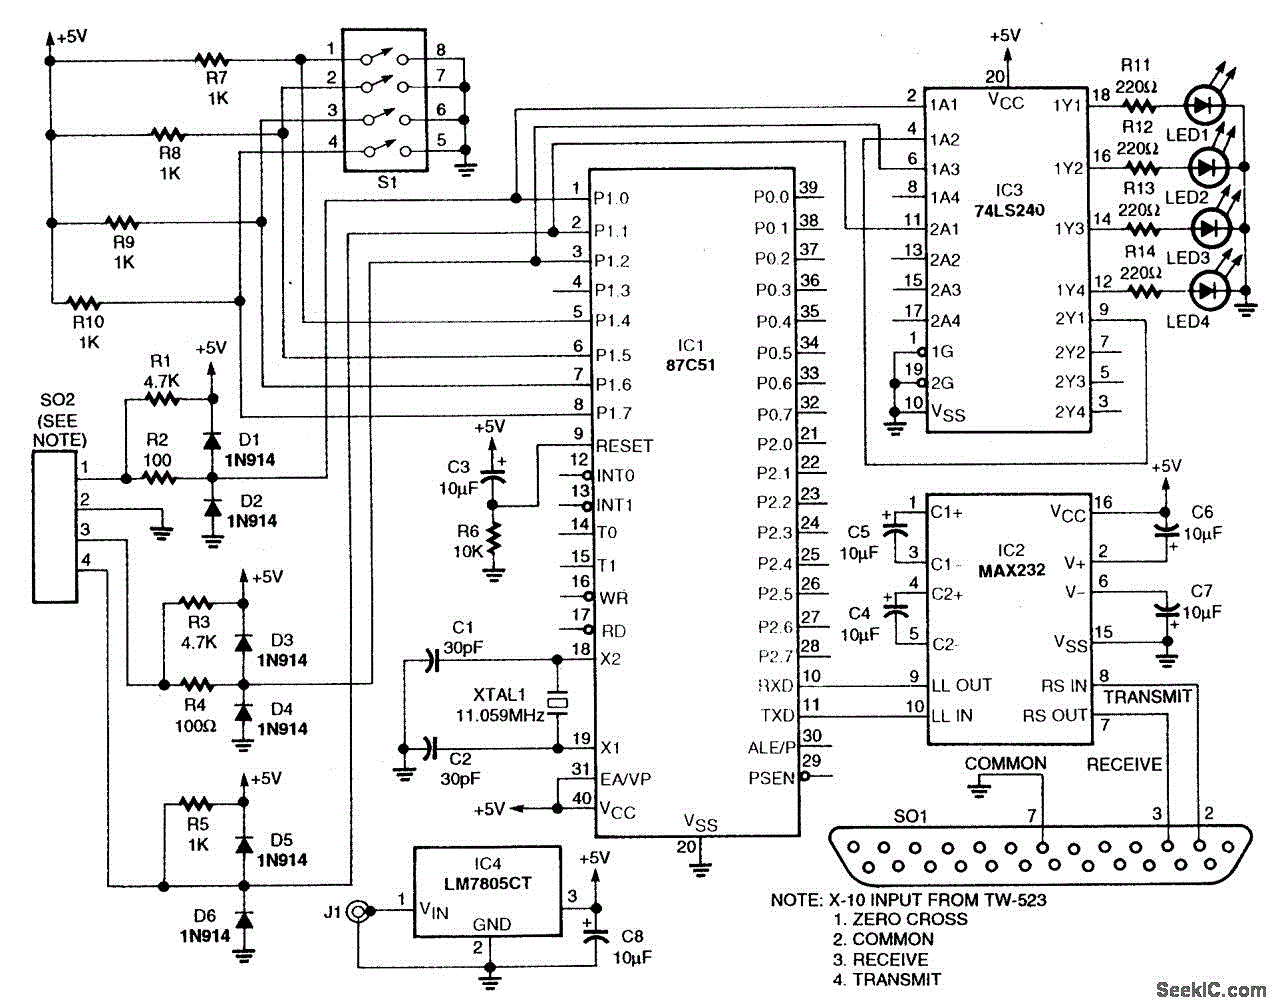
POWER LINE MODEM FOR COMPUTER CONTROL
This circuit employs an 87C57 microcontroller along with several peripherals to convert X-10 power-line carrier-code formats from a personal computer for use with an X-10 power-line interface in a home-control system. Software details can be found in the reference.
The circuit...
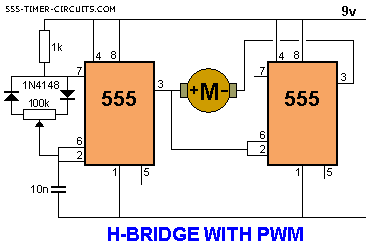
h bridge with pwm
This circuit controls a motor's rotation direction (clockwise or counterclockwise) using a potentiometer and can reduce the speed to zero when the potentiometer is positioned in the middle. The current is limited to 200 mA, and the voltage across the...
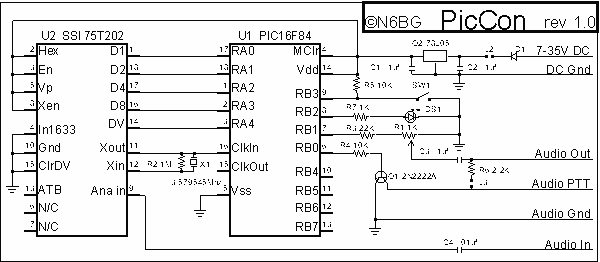
Hidden Radio Transmitter Controller
PicCon is a PIC microcontroller based radio controller designed for hidden transmitter hunting. When combined with a radio transmitter, it will produce tone sequences and Morse code messages at user-programmed times. It is completely field programmable via DTMF tones, utilizes...

Microcontroller and Motor Driver Circuit Board
Efforts were made to minimize the number of wire jumpers on this board, but space constraints arose due to the integration of the microcontroller and motor driver on a single board. The design would have been cleaner without the inclusion...
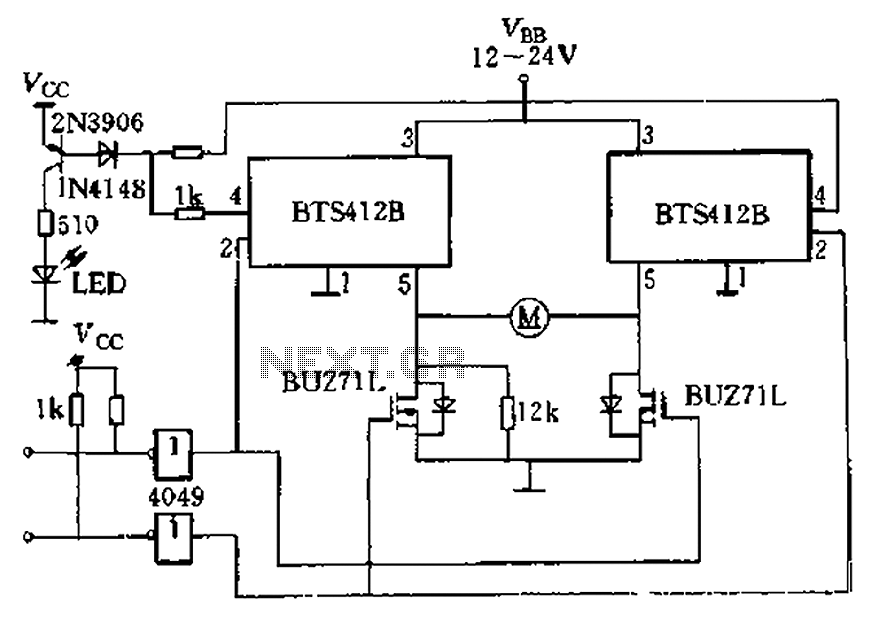
H-bridge driver circuit composed by the Smart SIPMOS
The BTS412B functions as two high-side power MOSFET switches, while two BU271L (50V, Zhang 1n) serve as low-side switches, forming a bi-directional H-bridge DC motor drive circuit. This configuration is designed for electrical automatic door systems, capable of handling continuous...
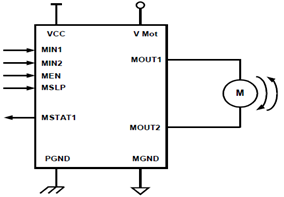
5A H-Bridge Module Pinout Circuit Schematic for Bipolar DC Motor
The schematic presented illustrates a 5A H-Bridge Module designed for the operation of a single Bipolar DC motor. The H-Bridge Module includes a header set (J2) and a connector terminal set (J1). Below is the pinout description for the J2...
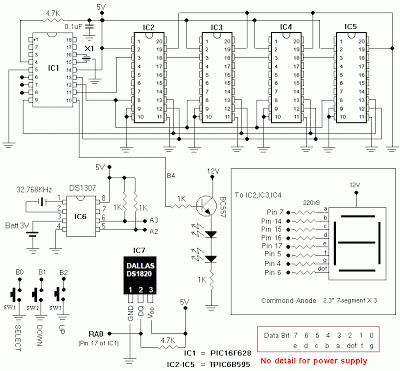
digital clock and temperature block
The diagram illustrates a block diagram for an agenda alarm and agenda thermometer system. It includes one temperature sensor, a real-time clock (RTC), a microcontroller (PIC), an EEPROM, a 7-segment display, and a keyboard. The EEPROM is utilized to expand...