


VCR Pong game
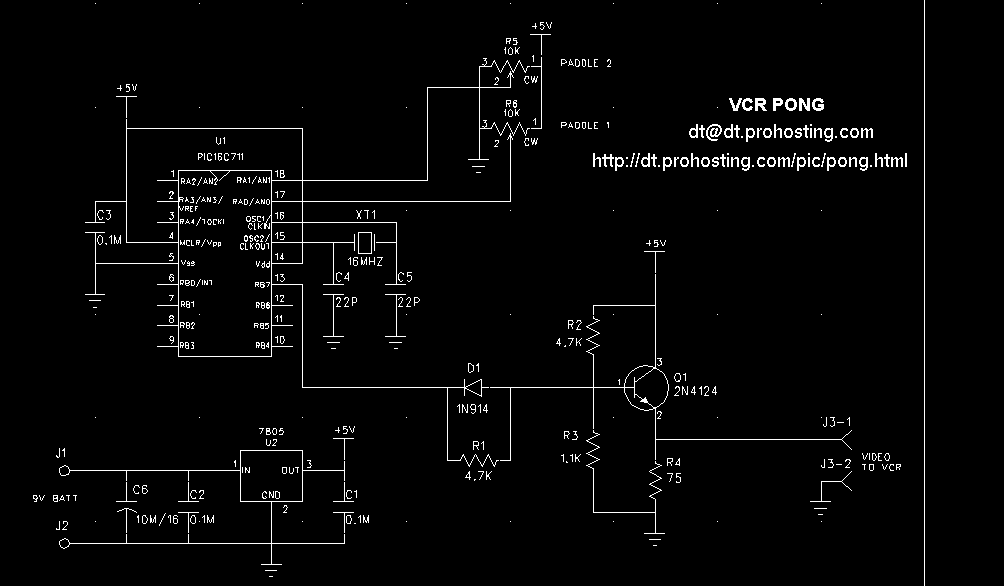
Description: The most amazing thing about this project is the small number of parts. My boss joked that it involves 17 cents worth of parts and 1000 dollars worth of programming. But don't worry -- the code is free to you! That means you can build this TV pong game in a very short time, or adapt the generic "video engine" portion of the program to make your own video-from-a-PIC project. More: At the heart of the circuit is a cute one-transistor driver circuit that generates the NTSC voltages for white (1v), black (.3v) and sync (0v), depending on whether the PIC pin is driven high, low, or allowed to float.
The described project is a simple yet effective implementation of a TV pong game utilizing a minimalistic approach in terms of components. The primary component is a one-transistor driver circuit, which is essential for generating the necessary NTSC video signals. This circuit operates by manipulating the output from a PIC microcontroller, which is programmed to control the state of the transistor.
The transistor acts as a switch that toggles between three voltage levels corresponding to the NTSC standard: 1 volt for the white pixels, 0.3 volts for the black pixels, and 0 volts for the synchronization signals. When the PIC pin is set to high, the transistor allows the voltage to reach 1 volt, creating a white pixel on the screen. Conversely, when the pin is set to low, the output drops to 0.3 volts, displaying a black pixel. If the pin is floating, the output is 0 volts, which sends a sync signal necessary for the proper timing and synchronization of the video display.
The simplicity of this design allows for rapid prototyping and adaptation. The accompanying code, which is available for free, serves as a foundation that can be modified to create various video projects based on the PIC microcontroller platform. This flexibility enables hobbyists and engineers alike to experiment with and expand upon the original concept, making it a valuable educational tool for understanding both video signal generation and microcontroller programming. The overall design emphasizes efficiency and cost-effectiveness, making it accessible for those looking to delve into video electronics without extensive investment in components.The most amazing thing about this project is the small number of parts. My boss joked that it involves 17 cents worth of parts and 1000 dollars worth of programming. But don`t worry -- the code is free to you! That means you can build this TV pong game in a very short time, or adapt the generic "video engine" portion of the program to make your own video-from-a-PIC project. At the heart of the circuit is a cute one-transistor driver circuit that generates the NTSC voltages for white (1v), black (.3v) and sync (0v), depending on whether the PIC pin is driven high, low, or allowed to float. With careful programming, I was able
The described project is a simple yet effective implementation of a TV pong game utilizing a minimalistic approach in terms of components. The primary component is a one-transistor driver circuit, which is essential for generating the necessary NTSC video signals. This circuit operates by manipulating the output from a PIC microcontroller, which is programmed to control the state of the transistor.
The transistor acts as a switch that toggles between three voltage levels corresponding to the NTSC standard: 1 volt for the white pixels, 0.3 volts for the black pixels, and 0 volts for the synchronization signals. When the PIC pin is set to high, the transistor allows the voltage to reach 1 volt, creating a white pixel on the screen. Conversely, when the pin is set to low, the output drops to 0.3 volts, displaying a black pixel. If the pin is floating, the output is 0 volts, which sends a sync signal necessary for the proper timing and synchronization of the video display.
The simplicity of this design allows for rapid prototyping and adaptation. The accompanying code, which is available for free, serves as a foundation that can be modified to create various video projects based on the PIC microcontroller platform. This flexibility enables hobbyists and engineers alike to experiment with and expand upon the original concept, making it a valuable educational tool for understanding both video signal generation and microcontroller programming. The overall design emphasizes efficiency and cost-effectiveness, making it accessible for those looking to delve into video electronics without extensive investment in components.The most amazing thing about this project is the small number of parts. My boss joked that it involves 17 cents worth of parts and 1000 dollars worth of programming. But don`t worry -- the code is free to you! That means you can build this TV pong game in a very short time, or adapt the generic "video engine" portion of the program to make your own video-from-a-PIC project. At the heart of the circuit is a cute one-transistor driver circuit that generates the NTSC voltages for white (1v), black (.3v) and sync (0v), depending on whether the PIC pin is driven high, low, or allowed to float. With careful programming, I was able
10 or more switches using a microcontroller
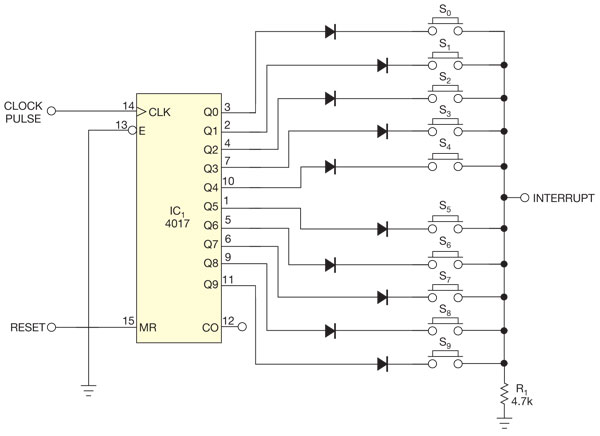
There are several methods to read multiple switch inputs using a reduced number of microcontroller unit (MCU) pins. One approach involves using an analog MCU pin to read multiple switches by assigning a unique voltage to each switch through a...
Low Resource Microcontroller 3 Phase BLDC Motor Speed Controller
This article discusses a minimal resource microcontroller implementation for a three-phase Brushless DC (BLDC) motor, focusing on a closed-loop speed motor controller application based on a Microchip PIC12 device. It demonstrates how minimization techniques can reduce the number of I/O...
connecting lego sensor pic
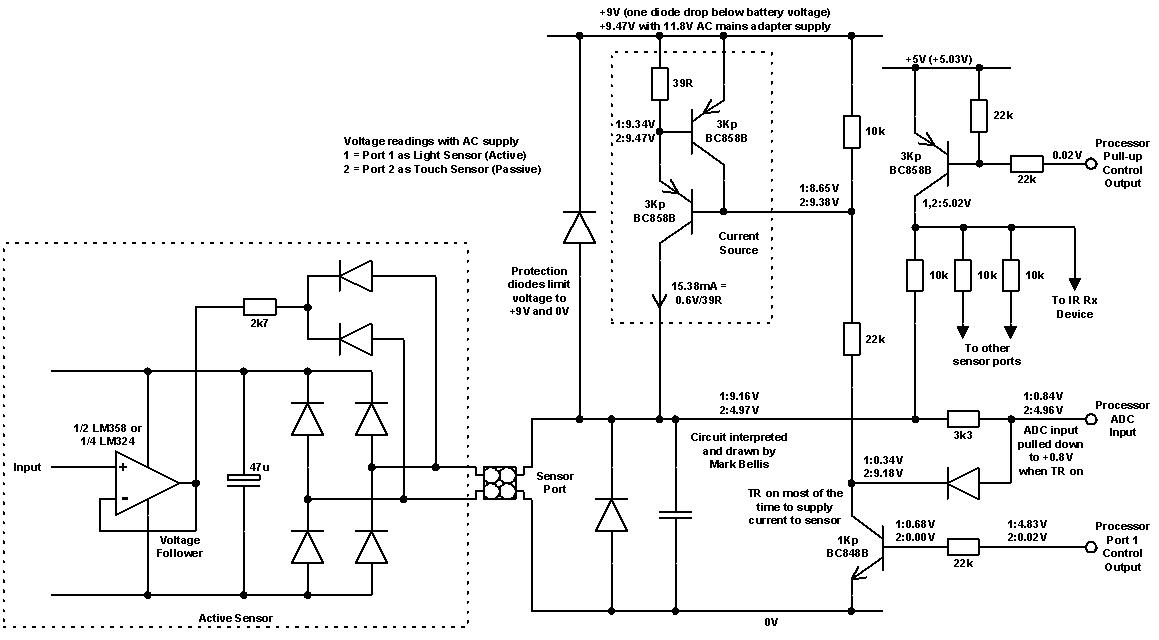
A control system is required using a standard PIC microcontroller for managing a LEGO light sensor. Guidance on the implementation process is needed.
To control a LEGO light sensor with a standard PIC microcontroller, several key components and steps must be...
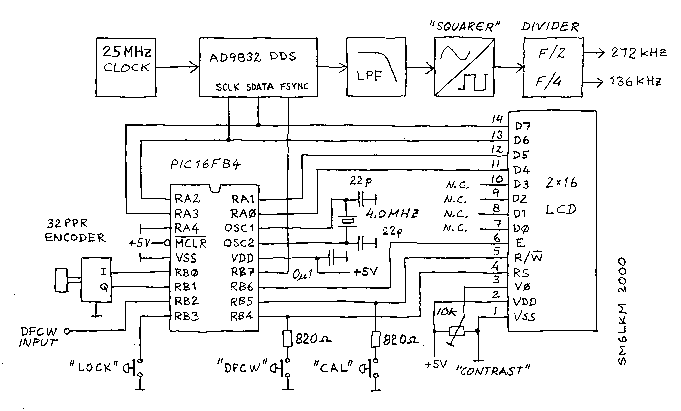
Build a PIC controlled DDS VFO, 0 to 6 MHz
Almost any 2x16 character LCD module with Hitachi HD44780 controller chip will work. The LCD pin numbers on the schematic are not valid for all LCD modules. Please check the actual signal names on your particular LCD module. The selected...
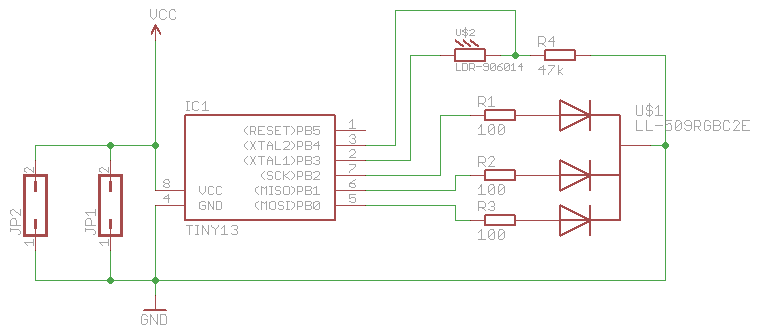
synchronizing fireflies ng
This is a remake of the fireflies project that was created a year ago. The concept revolves around the emergence of patterns, particularly the synchronization of hundreds or thousands of fireflies. Initially, they flash randomly, but over time, influenced by...
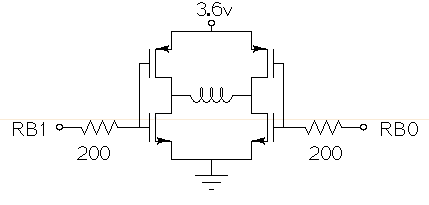
microcontroller Driving low-voltage H-bridge directly from MCU
Drive a small (3.6V, <1A) brushed motor bidirectionally with a PIC microcontroller (MCU). The available space is extremely limited, so a single 3.6V power supply will be used for both the motor and the PIC, with minimal drive circuitry required. There is no dedicated motor driver IC that operates at this low voltage, making a discrete H-bridge the most suitable drive arrangement. The NXP PMV30UN and PMV32UP have been identified as suitable N-type and P-type drive MOSFETs. Since both the PIC and the motor share the same power supply, it is questioned whether it is possible to eliminate the usual driving circuitry for an H-bridge and connect the transistors directly to the MCU pins. Potential pitfalls of this approach should also be considered.
To design a bidirectional motor drive circuit using a PIC microcontroller and a discrete H-bridge configuration, the following considerations must be taken into account. The H-bridge consists of four MOSFETs arranged in a configuration that allows current to flow through the motor in either direction, enabling bidirectional control. The NXP PMV30UN and PMV32UP MOSFETs are suitable candidates due to their low on-resistance and capability to operate at the required 3.6V supply voltage.
The connections between the PIC MCU and the MOSFETs should be made with consideration of the gate drive requirements. Directly connecting the MOSFET gates to the MCU pins can be feasible, but it is essential to ensure that the MCU can provide sufficient gate drive voltage to fully turn on the MOSFETs. A typical threshold voltage for these MOSFETs is around 1V, so the output high level from the PIC should exceed this threshold to ensure efficient operation.
It is also critical to incorporate pull-down resistors on the gate pins to prevent the MOSFETs from floating when the MCU is in a high-impedance state. This will help avoid unintended motor activation. Additionally, using gate resistors can help dampen any oscillations and limit inrush current during switching, which could potentially damage the MOSFETs or the MCU.
Another consideration is the back EMF generated by the motor when it is switched off or when changing direction. This can induce voltage spikes that may damage the MCU or the MOSFETs. To mitigate this risk, flyback diodes should be placed in parallel with each MOSFET to provide a path for the back EMF, ensuring safe operation of the circuit.
Thermal management is also a critical aspect of the design. Although the MOSFETs are rated for low on-resistance, continuous operation near their current limits can lead to significant heat generation. Adequate heat dissipation measures, such as heat sinks or thermal pads, should be considered.
In summary, while it is possible to connect the MOSFETs directly to the MCU pins, careful attention must be given to gate drive requirements, protection against back EMF, and thermal management to ensure reliable and efficient operation of the bidirectional motor drive circuit.
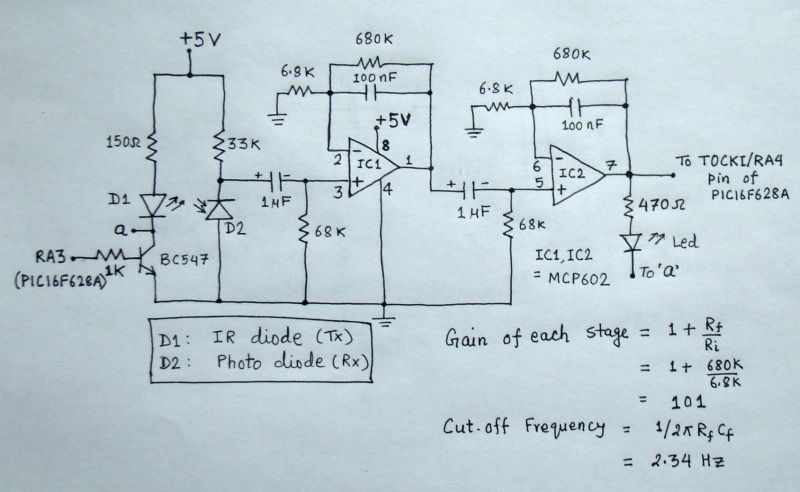
Microcontroller measures heart rate through fingertip
The reflected infrared (IR) signal detected by the photodiode is sent to a signal conditioning circuit, which filters out unwanted signals and amplifies the desired output.
The circuit begins with a photodiode that captures the reflected IR signals. The photodiode operates...
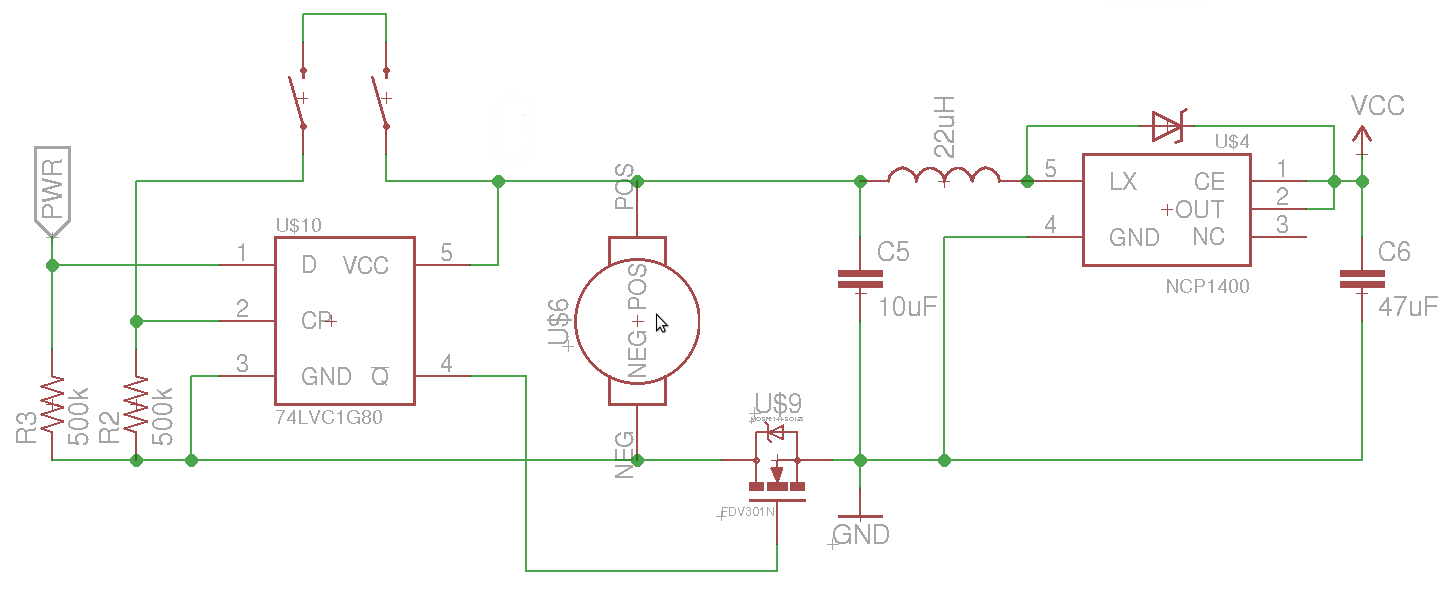
mosfet Turning a microcontroller on with a flip flop
The objective is to control the power to a load, specifically an 8051-based microcontroller (uC), using two switches. When the uC is powered on, it sets the PWR pin high. Upon pressing the switches again, pin 4 of the flip-flop...
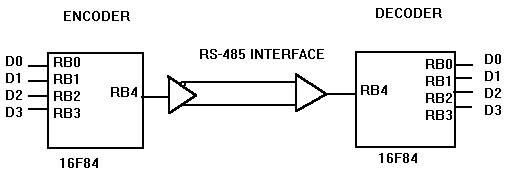
PIC Based RS485 Multiplexer
I decided to implement this using a PIC 16F84 for both an encoder and decoder, and use RS-485 drivers (DS26C31 and DS26C32) to drive the 350m cable. I only needed five I/O pins per PIC, so this could have been...