


parallel PIC
#PIC
#parallel processing
#microcontroller
#computational power
#educational
#algorithms
#MCUs
#cooperative computing
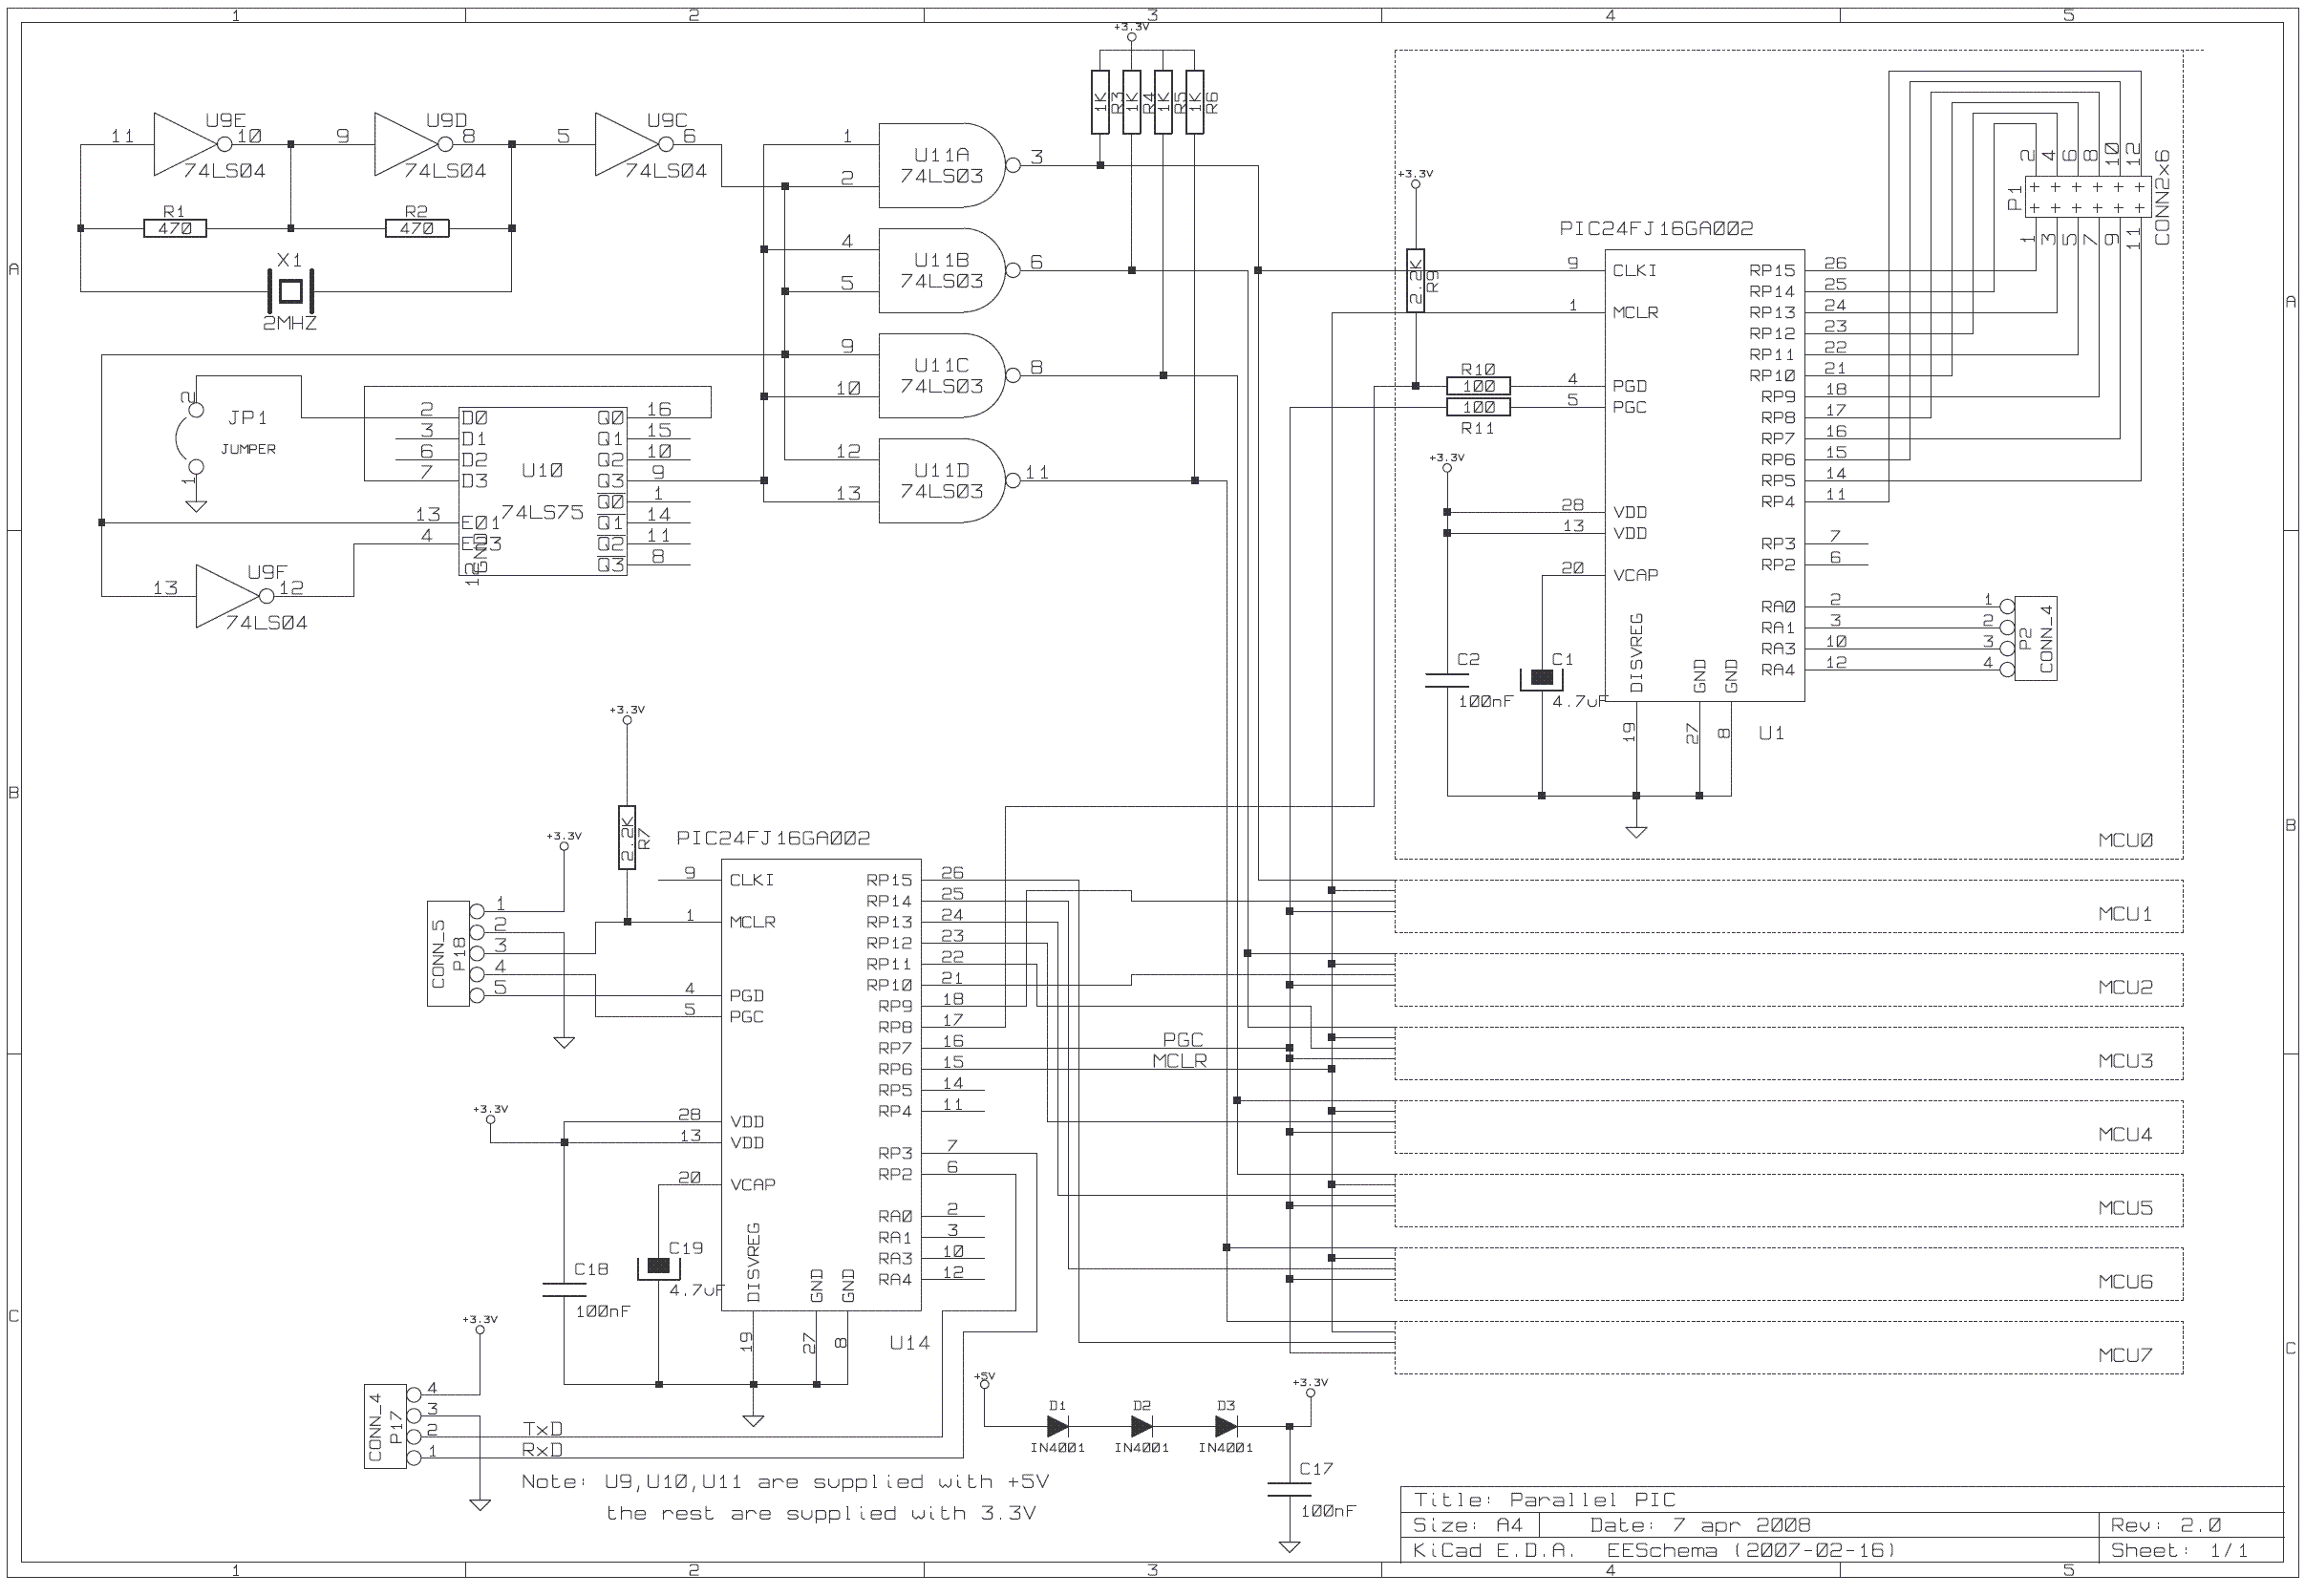
Description: The purpose of this project is to construct a computer that utilizes the combined computational power of multiple microcontrollers (MCUs). All MCUs collaborate to solve a single problem. This computer is classified as a parallel processing machine, and the algorithms executed on it are referred to as parallel algorithms. The system serves as an educational tool that aids in the development, understanding, and fine-tuning of various parallel algorithms. Additionally, it can achieve high performance in applications such as Digital Signal Processing. The construction of the computer is feasible for amateurs, although efficient utilization requires significant effort, as developing and implementing parallel algorithms can be challenging. The document includes a brief introduction to parallel processing computers, followed by hardware descriptions, supporting software details (including PC software and firmware for the parallel computer board), and explanations of parallel algorithms that operate on this computer. The conclusions are presented at the end. Source code samples are available in the compressed file "ParallelPIC_examples.zip", while the supporting software for the PC is found in "ParallelPIC_PCcode_V2.zip", and the firmware source code (including hex files) is in "ParallelPIC_firmwareV2.zip". This parallel computer employs a Single Instruction Multiple Data (SIMD) architecture, meaning that all MCUs execute the same program but operate on different data sets. In certain instances, only a subset of MCUs may execute code while others remain inactive, a characteristic inherent to some parallel algorithms. MCUs communicate with one another to exchange data, forming a network that influences the design of the executed algorithms. The parallel machine can be graphically represented with circles for the MCUs and arcs for their interconnections, which may allow for one-way or two-way communication. Two common topologies are illustrated, with an example of a tree structure used to find the maximum value among eight numbers. The leaves (MCUs 1, 2, 3, 4) receive input data, compare the two incoming values, and relay the maximum to the upper MCU (MCU 7), which ultimately holds the maximum value after three execution cycles. Numerous algorithms have been developed for problem-solving on such parallel machines, ranging from simple enumeration to complex operations like Fourier Transforms and optimization. The interconnection network significantly impacts algorithm efficiency. While the most powerful network allows each MCU to communicate with all others, practical implementations often utilize simpler networks. A key parameter is the number of connections per MCU; for instance, a mesh topology connects each MCU to a maximum of four others, while a binary tree requires three connections per MCU.
The described project focuses on a parallel processing computer that leverages multiple microcontrollers, enabling concurrent problem-solving capabilities. The architecture is based on the SIMD model, allowing all MCUs to execute the same instruction set while processing distinct data inputs. This design supports various applications, particularly in educational and performance-critical environments such as Digital Signal Processing.
The interconnection network among the MCUs is a pivotal component of this architecture. The choice of topology—whether it be a mesh, binary tree, or other configurations—directly affects the efficiency and speed of data exchange and algorithm execution. For example, in a binary tree topology, the hierarchical structure facilitates a systematic comparison of data values, enabling the determination of maximum values efficiently through a series of comparisons and data transfers.
The implementation of parallel algorithms is crucial for maximizing the performance of this system. Algorithms must be carefully designed to minimize communication overhead and optimize the workload distribution among the MCUs. The project documentation provides detailed insights into various algorithms suitable for this architecture, illustrating their practical applications and performance metrics.
Furthermore, the supporting software and firmware play essential roles in managing the interactions between the MCUs and coordinating the execution of parallel algorithms. The provided source code and firmware files serve as valuable resources for developers and researchers interested in exploring and expanding upon the capabilities of this parallel processing computer. Overall, this project exemplifies the potential of distributed computing through microcontroller networks, offering significant educational and practical opportunities in the field of parallel processing.The purpose of this project is to construct a computer that uses the combined computational power of many microcontrollers (MCUs). All the MCUs cooperate to solve one problem. The computer is defined as parallel processing machine and the algorithms that are executed on it are called parallel algorithms .
The machine can be used as an educat ional system that will help the development, understanding and fine-tuning of many parallel algorithms. It can also be used to achieve high performance in many cases such as in Digital Signal Processing. The computer can be easily constructed by an amateur. However the efficient use of it requires more effort as the development and implementation of parallel algorithms is a rather difficult task.
The next section makes a brief introduction to parallel processing computers. Section 3 describes the hardware, while section 4 describes the supporting software (i. e. the software that runs on the PC plus the firmware that lies on the "parallel computer" board). Section 5 explains and demonstrates some parallel algorithms that run on this parallel computer. Finally, section 6 holds the conclusions. The source code of the samples is held at compressed file " ParallelPIC_examples. zip ". The code for the supporting software that runs on the PC is stored into file " ParallelPIC_PCcode_V2. zip " and the source code (and the hex files) of the firmware is stored into the file " ParallelPIC_firmwareV2.
zip ". This parallel computer is of type Single Instruction Multiple Data (SIMD) which means that all MCUs execute the same program, but each MCU works with different data. (As a matter of fact, there are time instances where only one subset of the MCUs executes actual code while the other MCUs do nothing.
This is inherent in some parallel algorithms and will be shown in details in a subsequent section). The MCUs communicate with other MCUs to exchange data. Thus a network is developed between the MCUs. The topology of this network affects the design of the algorithms that are executed in the parallel machine. The parallel machine can be represented graphically by using circles for the MCUs and arcs for the interconnections between them.
(There may be one-way or two-way communication between two MCUs). The following figure shows two common topologies: An example of the use of the tree may be useful: Suppose that the problem is to find the maximum between 8 numbers. We use the tree structure shown in the above figure. The MCUs 1, 2, 3, 4 are called leaves . The MCU 7 is called root . The leaves get the input data. Each MCU compares the two (2) incoming data values, find the maximum and passes it to the upper MCU.
This means that -for example- MCU number 5 gets two values from MCUs 1 and 2 and passes the maximum to MCU 7. This read-compare-send algorithm is repeatedly executed. This way the root MCU (7) will hold the maximum of the eight (8) input numbers after three (3) executions of the read-compare-send algorithm: in the first execution the MCUs 1, 2, 3, 4 will send correct results to their upper MCUs, in the second execution MCUs 5, 6 will send correct results, and finally in the third execution MCU 7 will have the maximum Many algorithms have been developed for solving problems in this type of parallel machines covering many areas from elementary operations such as enumeration to complex operations such as Fourier Transforms, optimization and so on.
The interconnection network plays an important role in the efficiency of the algorithm. The most powerful network is the one where each MCU communicates with all the others. However, this is not a practical network and all the algorithms concentrate on simpler networks. A critical parameter is the number of connection for each MCU. The mesh topology requires that each MCU is connected with at most four (4) other MCUs. The binary tree requires three (3) connections per MCU. A very pow
The described project focuses on a parallel processing computer that leverages multiple microcontrollers, enabling concurrent problem-solving capabilities. The architecture is based on the SIMD model, allowing all MCUs to execute the same instruction set while processing distinct data inputs. This design supports various applications, particularly in educational and performance-critical environments such as Digital Signal Processing.
The interconnection network among the MCUs is a pivotal component of this architecture. The choice of topology—whether it be a mesh, binary tree, or other configurations—directly affects the efficiency and speed of data exchange and algorithm execution. For example, in a binary tree topology, the hierarchical structure facilitates a systematic comparison of data values, enabling the determination of maximum values efficiently through a series of comparisons and data transfers.
The implementation of parallel algorithms is crucial for maximizing the performance of this system. Algorithms must be carefully designed to minimize communication overhead and optimize the workload distribution among the MCUs. The project documentation provides detailed insights into various algorithms suitable for this architecture, illustrating their practical applications and performance metrics.
Furthermore, the supporting software and firmware play essential roles in managing the interactions between the MCUs and coordinating the execution of parallel algorithms. The provided source code and firmware files serve as valuable resources for developers and researchers interested in exploring and expanding upon the capabilities of this parallel processing computer. Overall, this project exemplifies the potential of distributed computing through microcontroller networks, offering significant educational and practical opportunities in the field of parallel processing.The purpose of this project is to construct a computer that uses the combined computational power of many microcontrollers (MCUs). All the MCUs cooperate to solve one problem. The computer is defined as parallel processing machine and the algorithms that are executed on it are called parallel algorithms .
The machine can be used as an educat ional system that will help the development, understanding and fine-tuning of many parallel algorithms. It can also be used to achieve high performance in many cases such as in Digital Signal Processing. The computer can be easily constructed by an amateur. However the efficient use of it requires more effort as the development and implementation of parallel algorithms is a rather difficult task.
The next section makes a brief introduction to parallel processing computers. Section 3 describes the hardware, while section 4 describes the supporting software (i. e. the software that runs on the PC plus the firmware that lies on the "parallel computer" board). Section 5 explains and demonstrates some parallel algorithms that run on this parallel computer. Finally, section 6 holds the conclusions. The source code of the samples is held at compressed file " ParallelPIC_examples. zip ". The code for the supporting software that runs on the PC is stored into file " ParallelPIC_PCcode_V2. zip " and the source code (and the hex files) of the firmware is stored into the file " ParallelPIC_firmwareV2.
zip ". This parallel computer is of type Single Instruction Multiple Data (SIMD) which means that all MCUs execute the same program, but each MCU works with different data. (As a matter of fact, there are time instances where only one subset of the MCUs executes actual code while the other MCUs do nothing.
This is inherent in some parallel algorithms and will be shown in details in a subsequent section). The MCUs communicate with other MCUs to exchange data. Thus a network is developed between the MCUs. The topology of this network affects the design of the algorithms that are executed in the parallel machine. The parallel machine can be represented graphically by using circles for the MCUs and arcs for the interconnections between them.
(There may be one-way or two-way communication between two MCUs). The following figure shows two common topologies: An example of the use of the tree may be useful: Suppose that the problem is to find the maximum between 8 numbers. We use the tree structure shown in the above figure. The MCUs 1, 2, 3, 4 are called leaves . The MCU 7 is called root . The leaves get the input data. Each MCU compares the two (2) incoming data values, find the maximum and passes it to the upper MCU.
This means that -for example- MCU number 5 gets two values from MCUs 1 and 2 and passes the maximum to MCU 7. This read-compare-send algorithm is repeatedly executed. This way the root MCU (7) will hold the maximum of the eight (8) input numbers after three (3) executions of the read-compare-send algorithm: in the first execution the MCUs 1, 2, 3, 4 will send correct results to their upper MCUs, in the second execution MCUs 5, 6 will send correct results, and finally in the third execution MCU 7 will have the maximum Many algorithms have been developed for solving problems in this type of parallel machines covering many areas from elementary operations such as enumeration to complex operations such as Fourier Transforms, optimization and so on.
The interconnection network plays an important role in the efficiency of the algorithm. The most powerful network is the one where each MCU communicates with all the others. However, this is not a practical network and all the algorithms concentrate on simpler networks. A critical parameter is the number of connection for each MCU. The mesh topology requires that each MCU is connected with at most four (4) other MCUs. The binary tree requires three (3) connections per MCU. A very pow
Experimental I/O board for microcontrollers
For beginners experiencing similar challenges, a general-purpose I/O board is recommended to minimize prototyping time and maximize space on the breadboard for projects. The construction of this board is straightforward. Basic I/O devices can be soldered onto a general-purpose perforated...

Microcontroller Voltmeter / Ammeter with LCD
The rectifier bridge voltage is determined by the U2 element; refer to its datasheet for the maximum voltage specifications. The minimum voltage at this pin should not fall below approximately 9V, or 6.5V if low-dropout type U2 and U3 voltage...
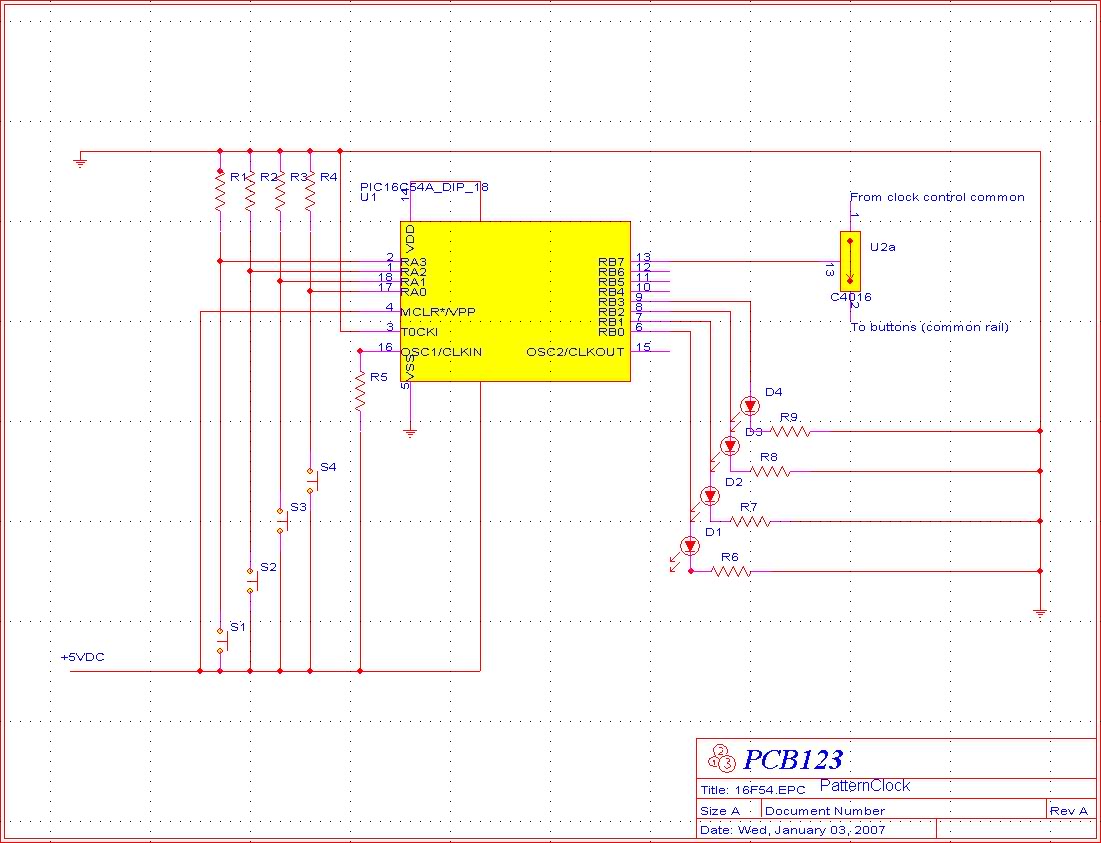
16F54 fickle!
The primary issue observed is that the circuit runs code, but several input/output (I/O) components are non-functional. For instance, only half of the LEDs driven by the circuit operate, and this appears to be random. Attempts to implement the slow...
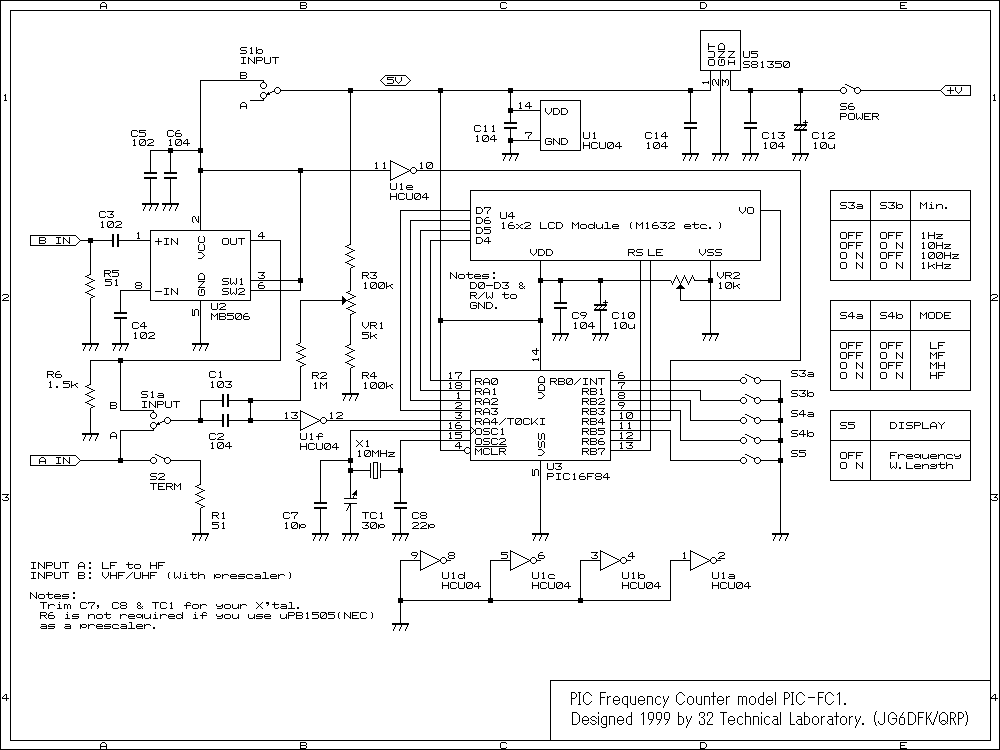
PIC frequency counter with prescaller
This is an image Schematic. No Description available.
The provided input indicates that there is an image schematic without any accompanying descriptive details. In the absence of specific schematics or circuit details, it is essential to consider the typical components...
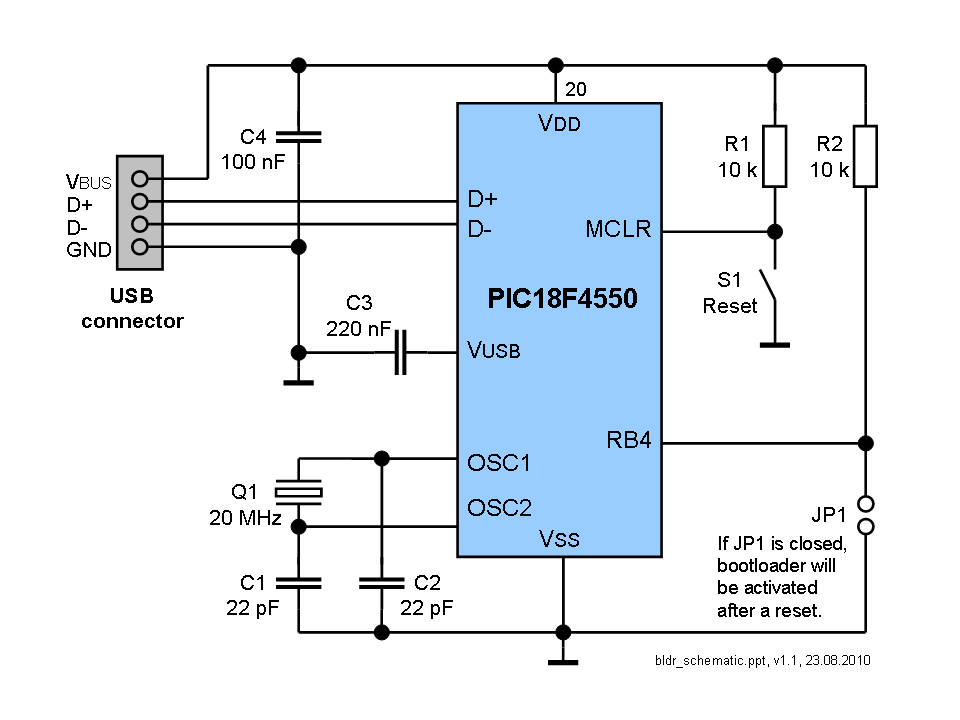
USB Bootloader
The bootloader is compatible with all USB PIC devices, including PIC18F4550, PIC18F4455, PIC18F2550, PIC18F2455, PIC18F4553, PIC18F4458, PIC18F2553, and PIC18F2458. However, since the bootloader is designed for the Microchip demo board, its configuration may not be suitable for specific projects. For...
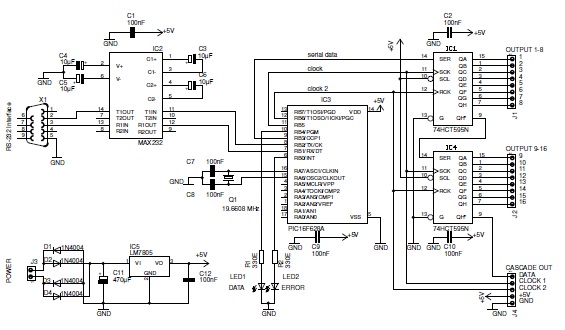
computer Interface Circuit
This basic PIC-based RS-232 serial interface can control up to 120 digital TTL outputs.
The described circuit utilizes a PIC microcontroller to facilitate communication via the RS-232 protocol, which is a standard for serial communication. The interface primarily serves to control...
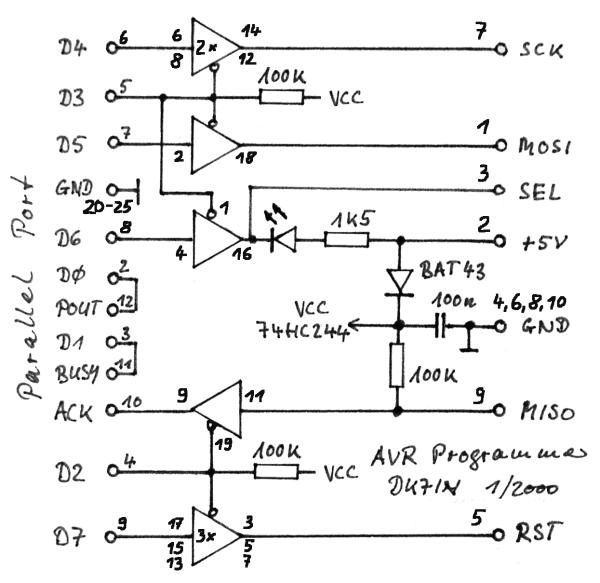
Microcontroller
The gap between TTL (Transistor-Transistor Logic) devices and personal computers can be effectively bridged with modern microcontrollers. These microcontrollers not only incorporate a central processing unit (CPU) but also include program and data memory, EEPROM, input/output (I/O) ports, timers, and...
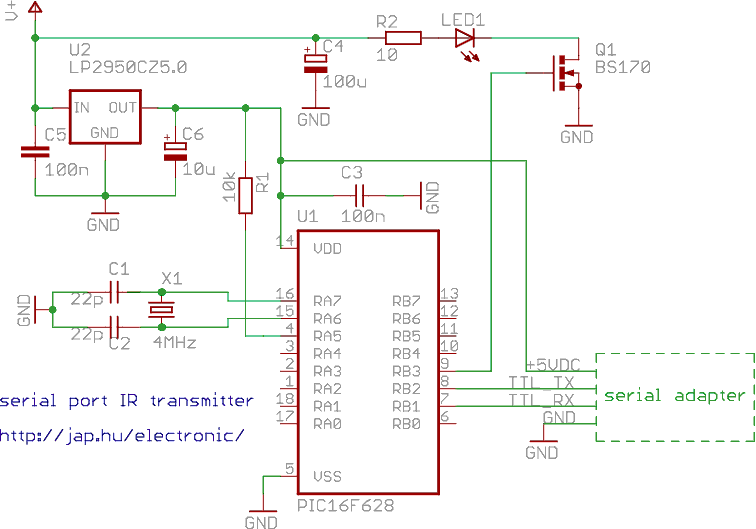
Serial port controlled infrared transmitter with PIC
This is a programmable infrared (remote control) transmitter, which can be controlled from a PC serial port. It is capable of sending many remote control formats, including the Philips RC-5 standard. Exact formats with the timing parameter names are shown...
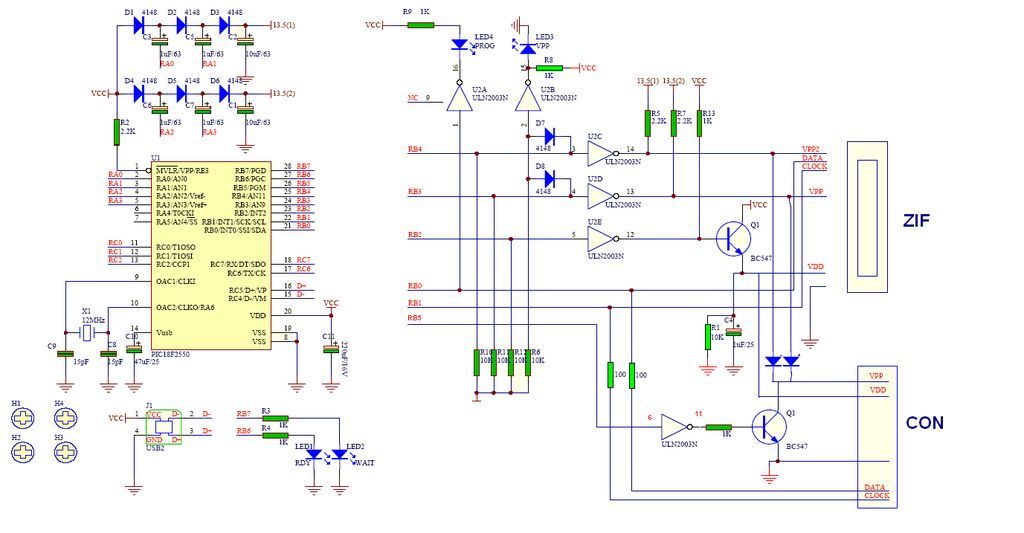
gtp usb pic programmer open source using pic18f252
GTP USB PIC Programmer (Open Source). This project includes the GTP USB (not plus or lite). The schematic, photos, and PCB have been developed by PICMASTERS.
The GTP USB PIC Programmer is an open-source device designed for programming PIC microcontrollers via...