


MidiMotor2 Module
#CAN bus
#MCP2551
#microcontroller
#optoisolator
#current limiting
#logic power
#transmit
#receive
#quad optoisolator
#RC0
Description: The logic power and CAN signals enter through pins 3 to 8 of connector N4. These CAN signals are routed to the MCP2551 CAN physical layer integrated circuit (IC), designated as U5. The transmit and receive pins of the microcontroller (U4, pins 5 and 6) connect to the corresponding pins on U5. Additionally, pins RC0 through RC3 are utilized to drive the quad optoisolator, U3, via current-limiting resistors R5 through R7. It is important to note that the U3 optoisolator appears in both schematics for clarity, although only one optoisolator is present. There is no shared ground between the two sides of the optoisolator. Each L298 (U1 and U2) is a dual H-bridge housed in a Multiwatt-15 package. Following standard practices, the two H-bridges are combined to create a single H-bridge with a capacity of 3.5 Amps. Power is supplied through connector N3, while the dedicated voltage regulator VR1 provides 5 volts for the logic circuitry. The H-bridge circuitry remains enabled at all times. Schottky diodes (D1-D8) are employed to suppress unwanted voltage spikes generated during switching operations. Each H-bridge is linked to two optoisolators in U3, facilitating independent control of the H-bridge.
The circuit described involves a robust setup for handling CAN communication and motor control through H-bridge configurations. The MCP2551 serves as the interface between the CAN bus and the microcontroller, ensuring reliable signal transmission. The microcontroller's transmit and receive pins are directly connected to the MCP2551, allowing for seamless data exchange.
The quad optoisolator, U3, plays a critical role in isolating the control signals from the power side of the circuit, thus protecting sensitive components from high voltage or noise. The use of current-limiting resistors R5 to R7 is essential to prevent excessive current from damaging the optoisolator inputs.
The dual L298 H-bridges (U1 and U2) are configured to operate in tandem, effectively doubling the current handling capacity for driving motors or other inductive loads. This configuration is particularly useful in applications requiring significant power, as it allows for efficient control of motor direction and speed.
The implementation of Schottky diodes (D1-D8) is a prudent design choice, as these diodes provide fast recovery times and low forward voltage drops, thereby enhancing the reliability of the circuit during switching events. This protection mechanism is vital in preventing damage from voltage transients that can occur in inductive loads.
Overall, the described circuit architecture provides a comprehensive solution for integrating CAN communication with motor control, emphasizing isolation, protection, and efficient power management.The logic power and CAN signals come in from N4 pins 3 through 8. The CAN signals are connected to the MCP2551 CAN physical layer IC, U5. The transmit and receive pins of the microctroller, (U4 pins 5 and 6) are connected to the other side of U5. Lastly, the RC0 through RC3 are used to drive the quad optoislator, U3, through current limiting resis
tors R5 through R7. Please note that U3 optoisolator shows up in both schematics. There is only one optoisolator, it is just easier to understand what is going on if the optoisolator is present in both schematics. There is no shared ground between the two sides of the optoisolator. Each L298 (U1 and U2) is a dual H-bridge in a Multiwatt-15 package. As per recommended practice, the two H-bridges are ganged together to form a single H-bridge with 3. 5 Amp capacity. Power comes in on N3. The dedicated regulator VR1 provides 5 volts for the logic ciruitry. The H-bridge circuitry is always enabled. The Schottky diodes (D1-D8) are used to clamp out unwanted voltage spikes that occur as a result of switching.
Each H-bridge is connected to two optoisolators in U3 to allow independent switching of the H-bridge.
The circuit described involves a robust setup for handling CAN communication and motor control through H-bridge configurations. The MCP2551 serves as the interface between the CAN bus and the microcontroller, ensuring reliable signal transmission. The microcontroller's transmit and receive pins are directly connected to the MCP2551, allowing for seamless data exchange.
The quad optoisolator, U3, plays a critical role in isolating the control signals from the power side of the circuit, thus protecting sensitive components from high voltage or noise. The use of current-limiting resistors R5 to R7 is essential to prevent excessive current from damaging the optoisolator inputs.
The dual L298 H-bridges (U1 and U2) are configured to operate in tandem, effectively doubling the current handling capacity for driving motors or other inductive loads. This configuration is particularly useful in applications requiring significant power, as it allows for efficient control of motor direction and speed.
The implementation of Schottky diodes (D1-D8) is a prudent design choice, as these diodes provide fast recovery times and low forward voltage drops, thereby enhancing the reliability of the circuit during switching events. This protection mechanism is vital in preventing damage from voltage transients that can occur in inductive loads.
Overall, the described circuit architecture provides a comprehensive solution for integrating CAN communication with motor control, emphasizing isolation, protection, and efficient power management.The logic power and CAN signals come in from N4 pins 3 through 8. The CAN signals are connected to the MCP2551 CAN physical layer IC, U5. The transmit and receive pins of the microctroller, (U4 pins 5 and 6) are connected to the other side of U5. Lastly, the RC0 through RC3 are used to drive the quad optoislator, U3, through current limiting resis
tors R5 through R7. Please note that U3 optoisolator shows up in both schematics. There is only one optoisolator, it is just easier to understand what is going on if the optoisolator is present in both schematics. There is no shared ground between the two sides of the optoisolator. Each L298 (U1 and U2) is a dual H-bridge in a Multiwatt-15 package. As per recommended practice, the two H-bridges are ganged together to form a single H-bridge with 3. 5 Amp capacity. Power comes in on N3. The dedicated regulator VR1 provides 5 volts for the logic ciruitry. The H-bridge circuitry is always enabled. The Schottky diodes (D1-D8) are used to clamp out unwanted voltage spikes that occur as a result of switching.
Each H-bridge is connected to two optoisolators in U3 to allow independent switching of the H-bridge.
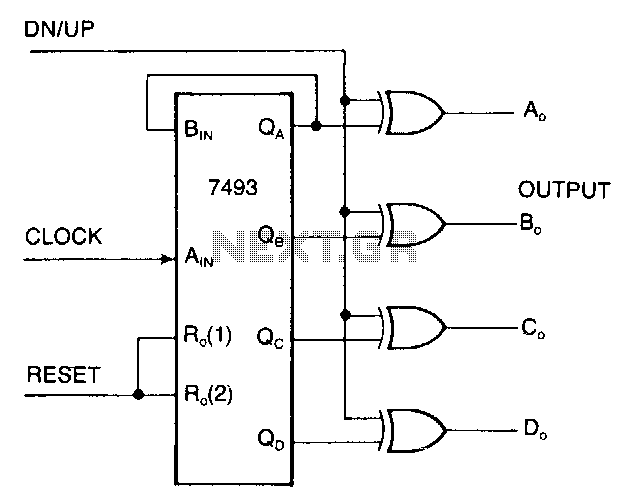
Eight-digit-microprocessor-display
The display interface utilizes the ICM7218A/B in conjunction with an 8048 family microcontroller. An 8-bit data bus (DBO/DB7-IDO/ID7) facilitates the transfer of control and data information to the 7218 display interface during successive WRITE pulses. The mode input pins on...
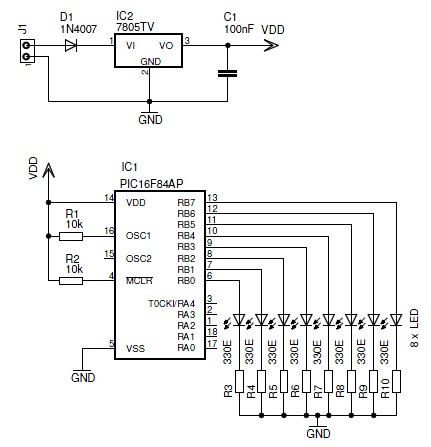
knight Rider
A light computer has been developed that simulates the scanning effect seen in the KITT car from the TV series Knight Rider. The design utilizes a microcontroller, specifically the PIC16F84A, instead of the commonly used CD4017 counter IC. This choice...
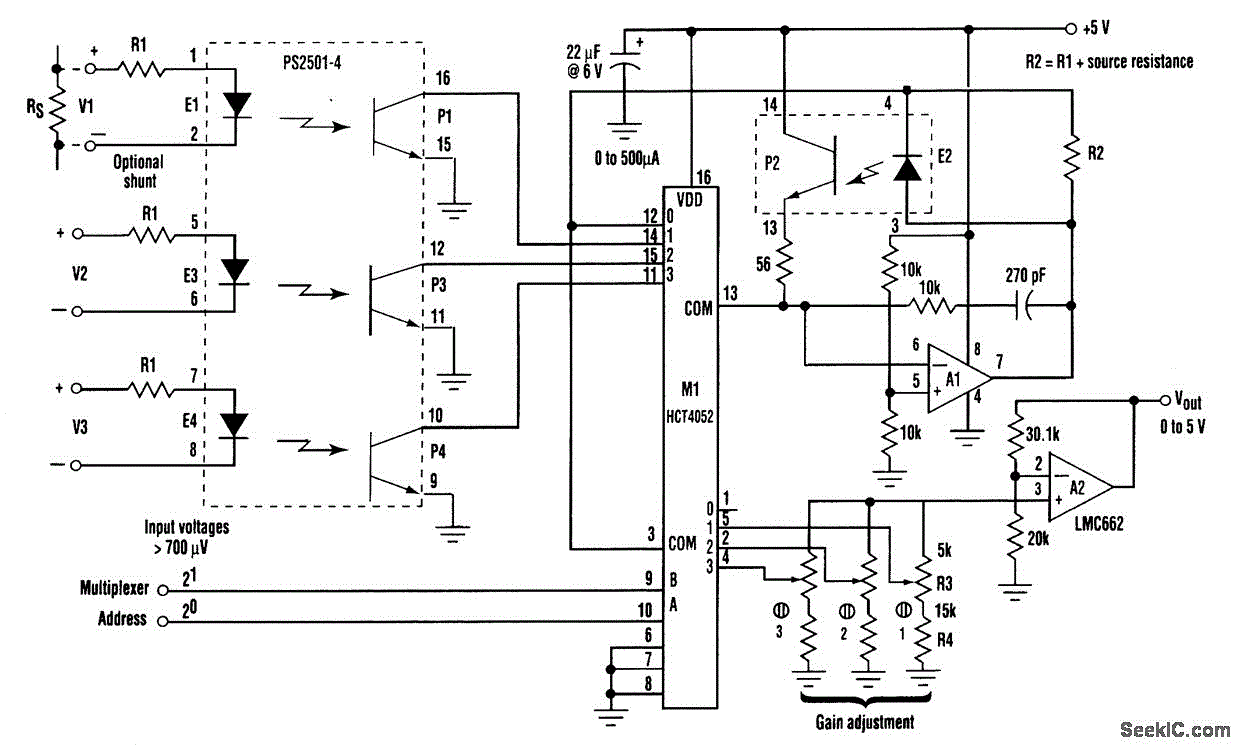
OPTICALLY ISOLATED ANALOG MULTIPLEXER
The circuit provides three channels of optically isolated input suitable for various precision signal-acquisition applications. It operates using a single 15-V power rail with a ground common to the analog-to-digital converter. The multiplexer functions through a standard quad-channel optoisolator (PS2501-4)....
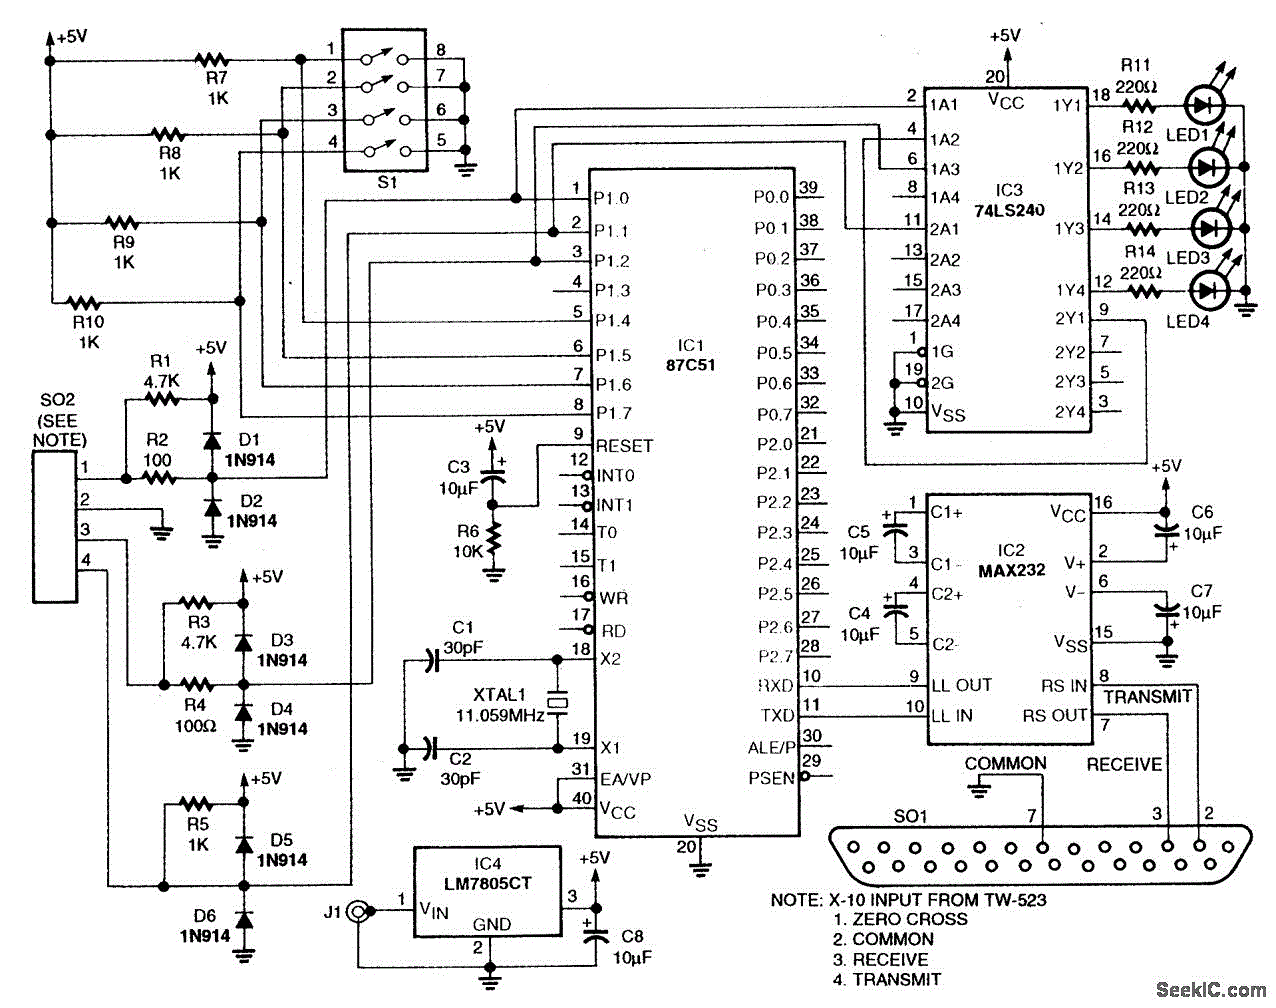
POWER LINE MODEM FOR COMPUTER CONTROL
This circuit employs an 87C57 microcontroller along with several peripherals to convert X-10 power-line carrier-code formats from a personal computer for use with an X-10 power-line interface in a home-control system. Software details can be found in the reference.
The circuit...
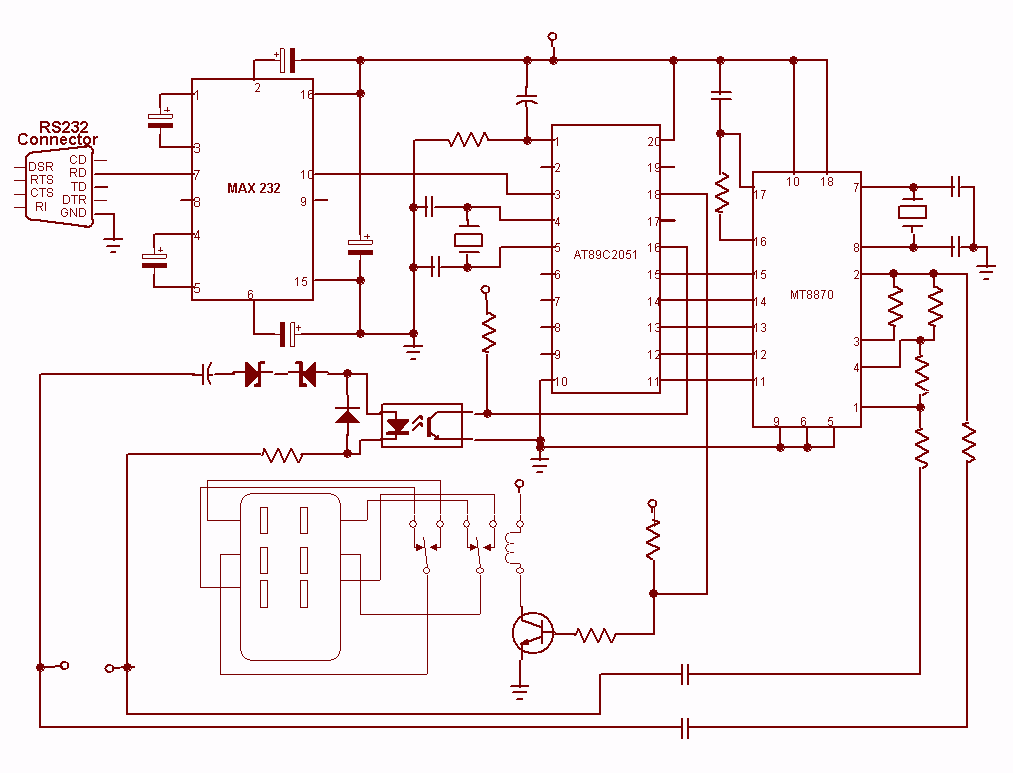
Interactive Voice Response System
Nowadays every institution needs automation. As a part of college automation, a project has been developed for a Voice Interactive System for College Automation. This project allows users to quickly access student attendance and marks through the telephone line without...
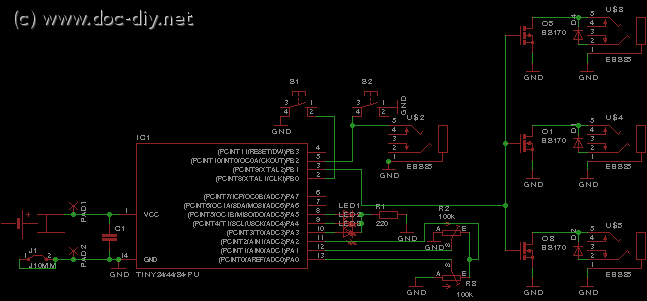
delay circuit for photography
This article outlines the construction of a simple microcontroller-based delay circuit designed for photographic applications such as drop or high-speed photography. It can control the trigger lag of cameras and flash units, generate periodic trigger pulses, or manage magnetic valves....
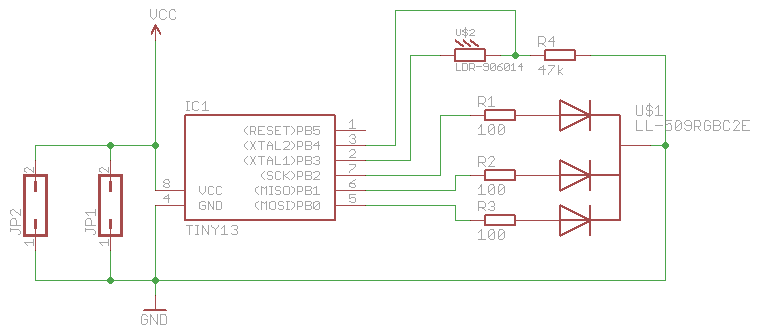
synchronizing fireflies ng
This is a remake of the fireflies project that was created a year ago. The concept revolves around the emergence of patterns, particularly the synchronization of hundreds or thousands of fireflies. Initially, they flash randomly, but over time, influenced by...
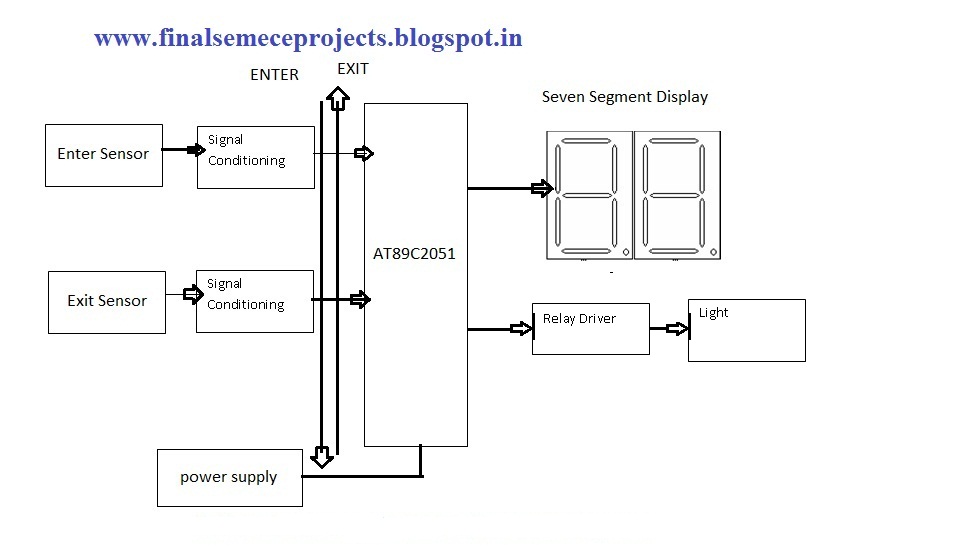
MICROCONTROLLER BASED AUTOMATIC ROOM LIGHT CONTROLLER
This project involves an automatic room light controller with a bidirectional visitor counter using a microcontroller. It is designed to manage room lighting and accurately count the number of individuals present. When a person enters the room, the counter increments...
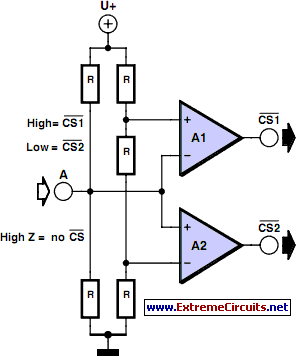
Multitasking Pins
It is entirely logical that low-cost miniature microcontrollers have fewer pins than their larger counterparts, sometimes too few. Consideration has been given to how to economize on pins by making them perform multiple functions. One approach is to exploit the...