


Line Following Auto Robot
#AT89C2051
#infrared sensors
#autonomous robot
#line following
#8 bit microcontroller
#sensor circuit
#embedded system
#robotics
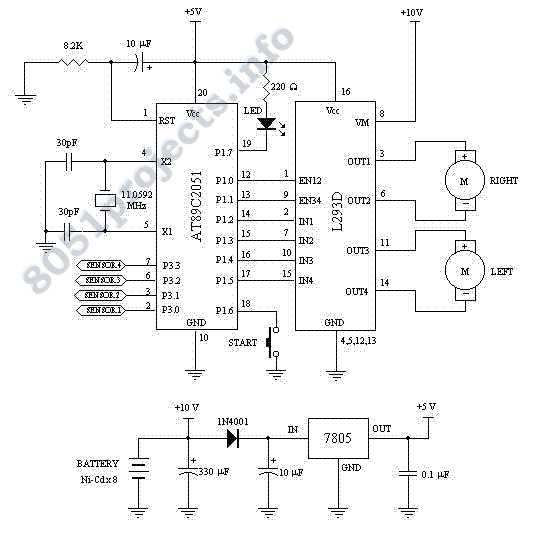
Description: This Project Line Following Autonomous Robot is based on 8 bit Microcontroller AT89C2051. This Robot follows the black line which is drawn over the white surface or it follows the white line which is drawn over the black surface. The infrared sensors are used to sense the line. When the infrared signal falls on the white surface, it gets reflected and if it falls on the black surface, it is not reflected this principle is used to scan the Lines for the Robot. More: All the above systems are controlled by the Microcontroller. In our project we are using the popular 8 bit microcontroller AT89C2051. It is a 20 pin microcontroller. The Microcontroller AT89C2051 is used to control the motors. It gets the signals from the
The line-following autonomous robot utilizes the AT89C2051 microcontroller, a widely recognized 8-bit microcontroller known for its compact design and efficiency in handling real-time control tasks. The core functionality of the robot is based on the principle of line detection using infrared (IR) sensors. These sensors are strategically placed to detect the contrast between the black line and the surrounding white surface. When the IR sensor detects the white surface, the reflected infrared light indicates the absence of a line, while the detection of a black line results in minimal or no reflection.
The AT89C2051 microcontroller is equipped with 20 pins, which are utilized for various functionalities including input and output operations, motor control, and sensor interfacing. The microcontroller processes the signals received from the IR sensors and executes the control logic necessary to drive the motors. The motors are typically DC motors, which are connected to the microcontroller through driver circuits that allow for directional control and speed modulation.
The robot's movement is dictated by the logic programmed into the AT89C2051. When the IR sensors detect the black line, the microcontroller sends signals to adjust the motor speeds accordingly, enabling the robot to follow the line seamlessly. For instance, if the left sensor detects the line while the right sensor does not, the microcontroller will slow down the left motor and speed up the right motor, causing the robot to turn right and realign with the line.
In addition to the core components, power supply considerations are crucial for the operation of the robot. A battery pack is generally used to provide the necessary voltage and current to the microcontroller and motors. Proper voltage regulation and filtering are essential to ensure stable operation and prevent noise interference that could affect sensor readings.
Overall, the design of the line-following autonomous robot demonstrates the integration of sensor technology, microcontroller programming, and motor control, showcasing a practical application of electronics engineering principles in robotics.This Project Line Following Autonomous Robot is based on 8 bit Microcontroller AT89C2051. This Robot follows the black line which is drawn over the white surface or it follows the white line which is drawn over the black surface. The infrared sensors are used to sense the line. When the infrared signal falls on the white surface, it gets reflected and if it falls on the black surface, it is not reflected this principle is used to scan the Lines for the Robot.
All the above systems are controlled by the Microcontroller. In our project we are using the popular 8 bit microcontroller AT89C2051. It is a 20 pin microcontroller. The Microcontroller AT89C2051 is used to control the motors. It gets the signals from th
The line-following autonomous robot utilizes the AT89C2051 microcontroller, a widely recognized 8-bit microcontroller known for its compact design and efficiency in handling real-time control tasks. The core functionality of the robot is based on the principle of line detection using infrared (IR) sensors. These sensors are strategically placed to detect the contrast between the black line and the surrounding white surface. When the IR sensor detects the white surface, the reflected infrared light indicates the absence of a line, while the detection of a black line results in minimal or no reflection.
The AT89C2051 microcontroller is equipped with 20 pins, which are utilized for various functionalities including input and output operations, motor control, and sensor interfacing. The microcontroller processes the signals received from the IR sensors and executes the control logic necessary to drive the motors. The motors are typically DC motors, which are connected to the microcontroller through driver circuits that allow for directional control and speed modulation.
The robot's movement is dictated by the logic programmed into the AT89C2051. When the IR sensors detect the black line, the microcontroller sends signals to adjust the motor speeds accordingly, enabling the robot to follow the line seamlessly. For instance, if the left sensor detects the line while the right sensor does not, the microcontroller will slow down the left motor and speed up the right motor, causing the robot to turn right and realign with the line.
In addition to the core components, power supply considerations are crucial for the operation of the robot. A battery pack is generally used to provide the necessary voltage and current to the microcontroller and motors. Proper voltage regulation and filtering are essential to ensure stable operation and prevent noise interference that could affect sensor readings.
Overall, the design of the line-following autonomous robot demonstrates the integration of sensor technology, microcontroller programming, and motor control, showcasing a practical application of electronics engineering principles in robotics.This Project Line Following Autonomous Robot is based on 8 bit Microcontroller AT89C2051. This Robot follows the black line which is drawn over the white surface or it follows the white line which is drawn over the black surface. The infrared sensors are used to sense the line. When the infrared signal falls on the white surface, it gets reflected and if it falls on the black surface, it is not reflected this principle is used to scan the Lines for the Robot.
All the above systems are controlled by the Microcontroller. In our project we are using the popular 8 bit microcontroller AT89C2051. It is a 20 pin microcontroller. The Microcontroller AT89C2051 is used to control the motors. It gets the signals from th
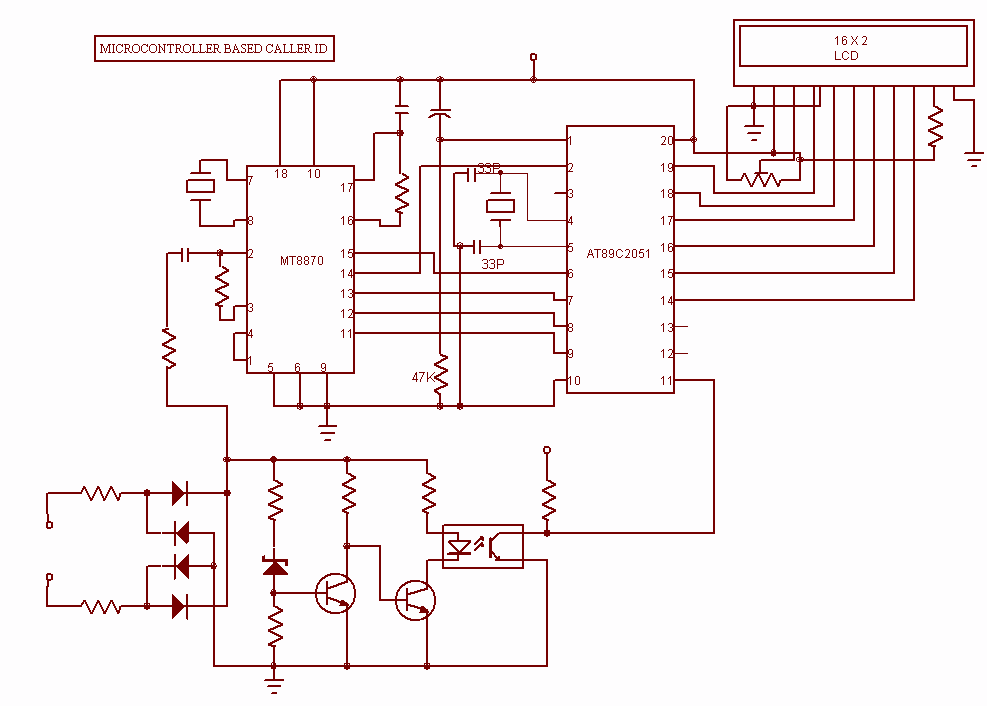
LCD Caller ID with AT89C2051
This Project can be used in home, shops, offices etc. It keeps tracking of both Incoming and Outgoing Calls. It has a built in Caller ID. The incoming and the dialed numbers are displayed on the LCD display. The system...
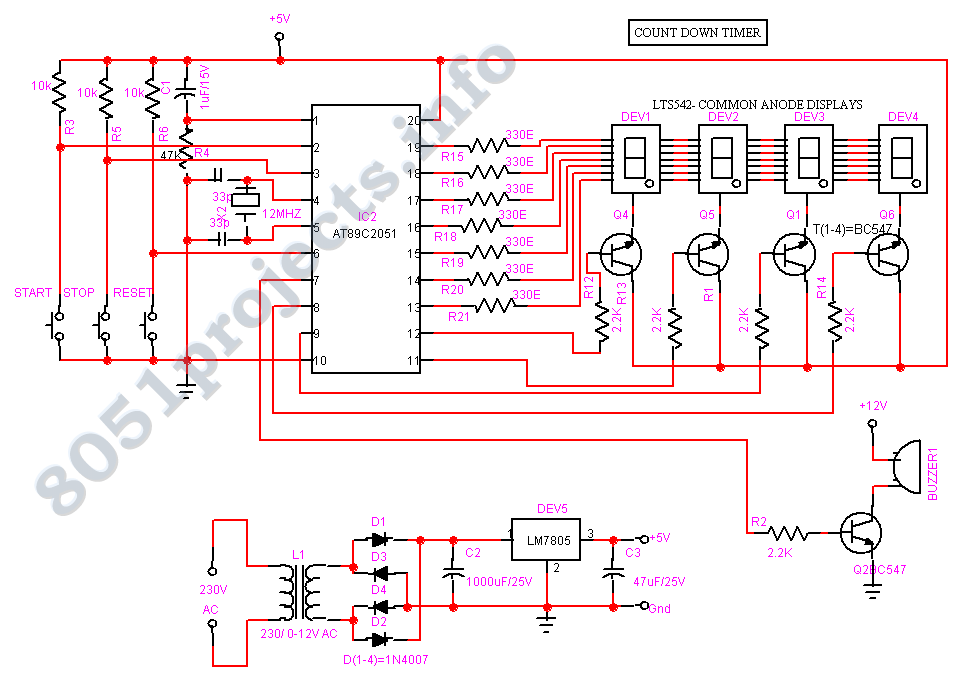
LED Countdown Timer with AT89C2051
A simple count-down LED timer that counts in minutes and seconds. Three buttons below the LED provide control of the unit, allowing you set the desired countdown time in minutes and seconds and a start/stop button. Completion of the countdown...
System AT89C2051 and AT89C4051
The circuit is better referred to as the Evaluation Board for the AT89C2051 and AT89C4051 microcontrollers. This Minimum System Evaluation Board for the AT89C2051 and AT89C4051 offers several advantages in terms of hardware support.
The Evaluation Board for the AT89C2051 and...
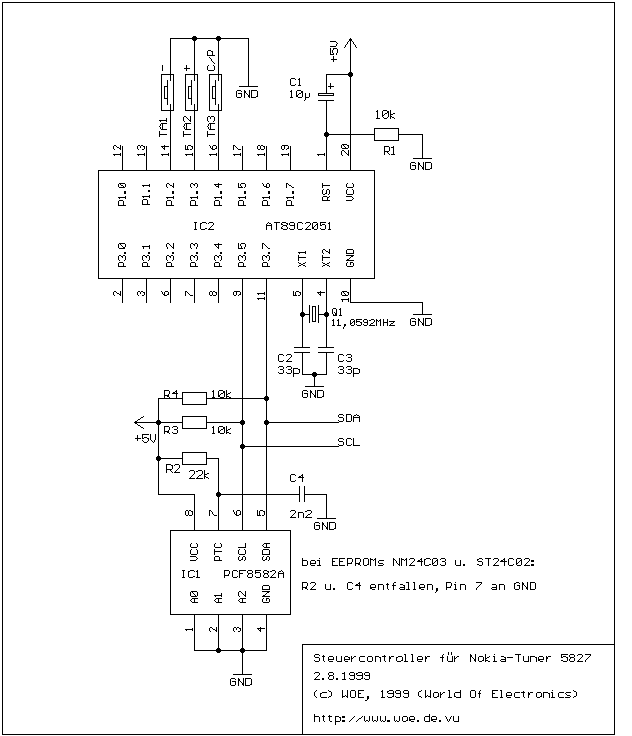
control circuit for nokia tv tuner 5827
The tuner is programmable via I²C-Bus and provides a FBAS signal at its output. There is also the homepage of Georg Acher containing information about this tuner. A control circuit has been developed for this tuner using the AT89C2051 from...
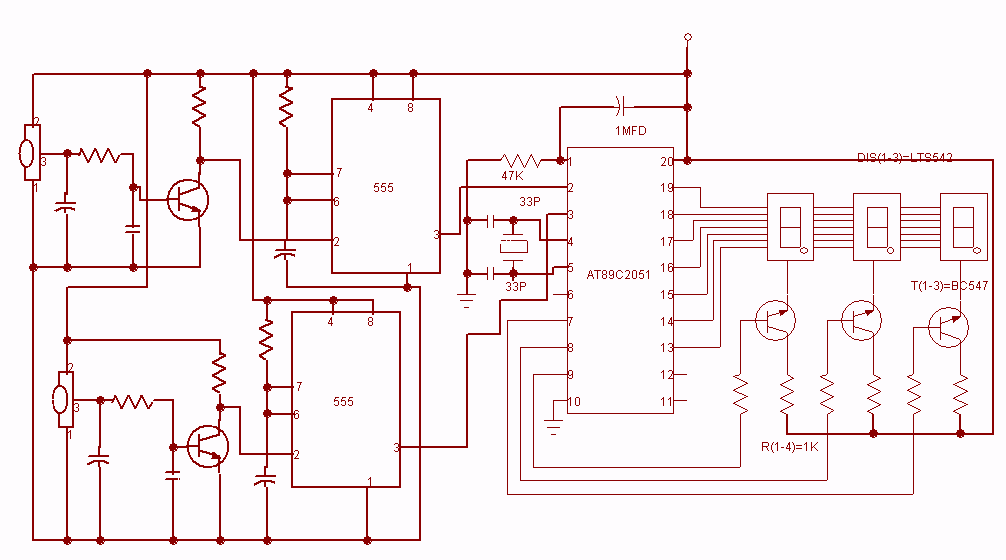
Digital event Counter AT89C2051
Digital visitor counter is a reliable circuit that takes over the task of counting Number of Persons/ Visitors in the Room very Accurately. When somebody enters into the Room then the Counter is Incremented by one and when any one...
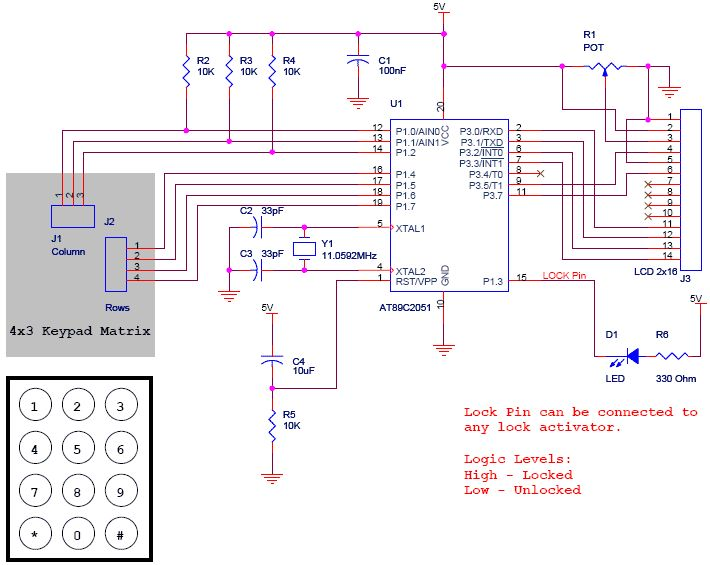
digital code lock
The project is a Digital Code Lock utilizing the AT89C2051 microcontroller. An LCD is employed for display purposes, and a keypad is used for inputting keys. The source code for this project is written in C. It is designed as...
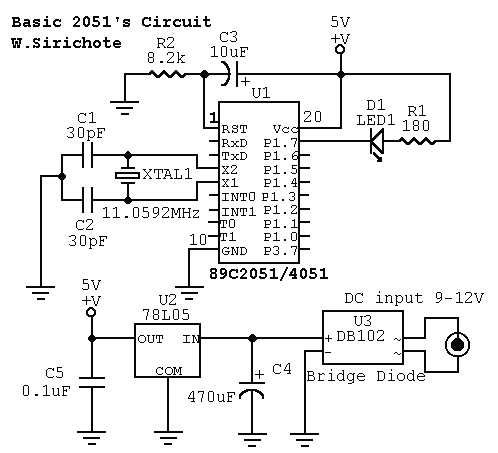
AT89C2051/4051 Driving Dot LED
A basic circuit of the 89C2051 can be constructed using point-to-point soldering on a universal printed circuit board (PCB). An ordinary 20-pin socket should be utilized, avoiding the use of a circular-pin socket. D1 represents a small dot LED. U2...
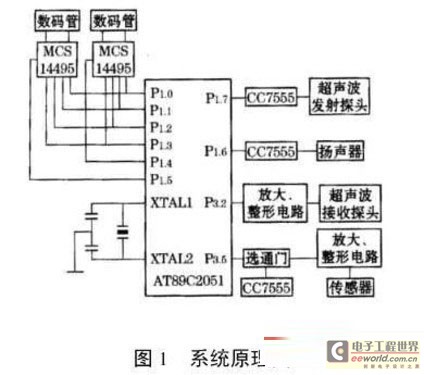
Design on the basis of AT89C2051 intelligent automobile anticollision alarm equipment
With the fast-paced nature of modern life, the frequency of traffic accidents is also increasing. To enhance vehicle safety, this text presents a mechanically controlled car anti-collision alarm system designed as a single unit. This device integrates real-time control and...

Robotics Art
This page contains links to various projects and items of interest for the RoboticsArt Studio class projects.
The RoboticsArt Studio class projects encompass a range of innovative endeavors that integrate art and robotics. These projects typically involve the design, assembly, and...