


How to use SPI (Serial Peripheral Interface) in AVR Microcontrollers
#SPI
#AVR
#communication
#serial interface
#data exchange
#shift registers
#embedded systems
#protocol
#microcontroller programming
#hardware interface
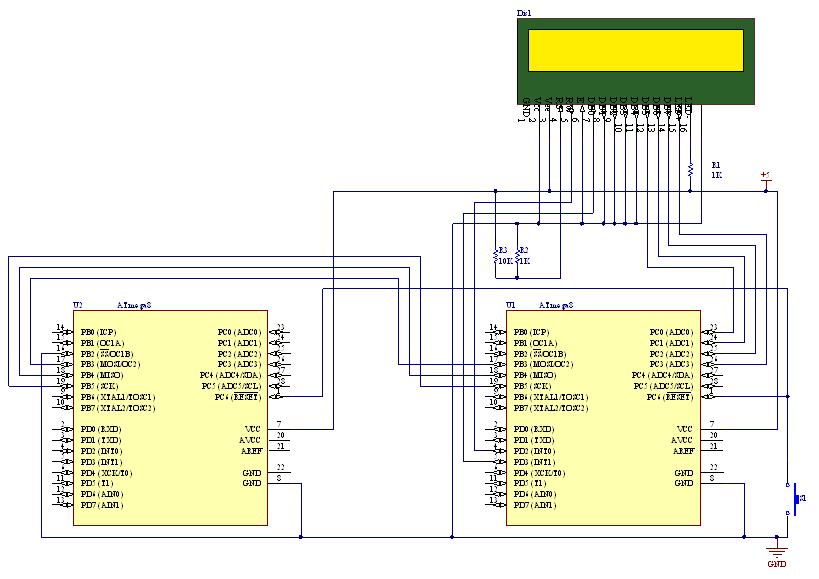
Description: SPI stands for Serial Peripheral Interface, which is the simplest among all communication protocols. Eight-bit data registers in the devices are connected by wires. These data registers function as shift registers, with one device controlling the data exchange within the SPI network. The device or devices that control the operation within the network are known as the Master. Multiple Masters can exist in a system, as well as multiple slaves. The slave does not necessarily have to be another microcontroller; it can be an SD card, a display device, or other electronic circuits. Regardless of the device attached as a slave, it must be selected by the Master device(s) for data transfer. In a multi-master network, each individual secondary master must be selected to control the SPI bus. An SPI bus consists of two data lines, one clock line, and device select (or slave select) lines. The clock signal is generated by the master in the network. In a particular experiment, a system is built to receive any character transmitted via SPI and display it on an LCD. Thus, the receiver circuit acts as a slave. Since the receiver system will never transmit any data, it can remain enabled at all times. A master device will transmit a string of characters either once or repetitively. Upon completion of a serial transfer, the SPIF flag is set. An interrupt is generated if SPIE in SPCR is set and global interrupts are enabled. If SS is an input and is driven low while the SPI is in Master mode, this will also set the SPIF flag. The SPIF flag is cleared by hardware when executing the corresponding interrupt handling vector. Alternatively, it can be cleared by first reading the SPI Status Register with SPIF set, then accessing the SPI Data Register (SPDR). The WCOL bit is set if the SPI Data Register (SPDR) is written during a data transfer. Both the WCOL and SPIF bits are cleared by first reading the SPI Status Register with WCOL set, followed by accessing the SPI Data Register. When written as logic one, this bit doubles the SPI speed (SCK frequency) when the SPI is in Master mode, meaning that the minimum SCK period will be two CPU clock periods. When configured as a Slave, the SPI is guaranteed to function at or below this rate. This bit selects Master SPI mode when written as one and Slave SPI mode when written as zero. If SS is configured as an input and is driven low while MSTR is set, MSTR will be cleared, and SPIF in SPSR will be set. The user must then reset MSTR to re-enable SPI Master mode. These two bits control the SCK rate of the device configured as a Master. SPR1 and SPR0 have no effect on the Slave. The relationship between SCK and the oscillator clock frequency is shown in the following table:
The Serial Peripheral Interface (SPI) is a synchronous serial communication protocol that facilitates data exchange between a master device and one or multiple slave devices. The architecture of SPI is characterized by its simplicity and efficiency, making it suitable for a wide range of applications, including microcontroller communication with peripheral devices like sensors, memory cards, and display modules.
In an SPI configuration, the master device generates the clock signal, which synchronizes the data transmission on the two data lines, MOSI (Master Out Slave In) and MISO (Master In Slave Out). The master also controls the selection of slave devices through the Slave Select (SS) line, ensuring that only one slave is active during communication. The SPI protocol allows for full-duplex communication, meaning that data can be sent and received simultaneously, increasing the overall throughput of the system.
The SPI bus operates with a minimum of four lines: SCK (clock), MOSI, MISO, and SS. Additional slave devices can be connected to the same bus, each with a dedicated SS line controlled by the master. This configuration allows for multiple slaves to be addressed without the need for complex handshaking protocols, as the master simply toggles the SS line to select the desired slave.
In terms of electrical characteristics, the SPI bus can operate at various clock speeds, determined by the master. The SPI clock frequency (SCK) is critical in ensuring reliable data transfer, and its relationship with the oscillator frequency must be carefully managed, especially in systems with multiple devices operating at different speeds.
The SPI protocol also includes status flags, such as SPIF and WCOL, which provide feedback on the status of data transfers. The SPIF flag indicates the completion of a data transfer, while the WCOL flag indicates a write collision, which occurs if data is written to the SPI Data Register during an active transfer. Proper handling of these flags is essential for robust SPI communication.
Overall, the SPI protocol's straightforward design and high-speed capabilities make it a preferred choice in embedded systems, where efficient communication between microcontrollers and peripherals is essential.SPI stands for Serial Peripheral Interface and it is the simplest among all the communication protocols. 8bit data registers in the devices are connected by wires. These data registers works as shift registers and one of the device controls the data exchange inside the SPI Network.
The device or devices that controls the operation inside the netwo rk is known as the Master. For more elaboration, you may read the Wikipedia article: Serial Peripheral Interface Bus. There can be multiple Masters in a system. There may be multiple slaves too. The slave need not to be another micro controller. It can be an SD card, or some display device or may be some other electronic circuit. Irrespective of the device attached as a slave, it needs to get selected by master device(s) for data transfer. If the system is a multi-master network, then each individual secondary master needs to be selected for mastering the SPI BUS.
An SPI bus consist of two DATA lines, one clock line, and device select (or slave select) lines. The clocking signal is generated by the master in the network. Here, in this experiment, one system is build up to receive any character transmitted in the SPI. And it displays the character on the LCD display. So the receiver circuit is essentially a slave. As the receiver system will never transmit any data, we can keep it enabled all the time. There would be a master device that will transmit a string of character, either once, or repetitively. So let`s see, what are the available resources for this communication. When a serial transfer is complete, the SPIF Flag is set. An interrupt is generated if SPIE in SPCR is set and global interrupts are enabled. If SS is an input and is driven low when the SPI is in Master mode, this will also set the SPIF Flag.
SPIF is cleared by hardware when executing the corresponding interrupt Handling Vector. Alternatively, the SPIF bit is cleared by first reading the SPI Status Register with SPIF set, then accessing the SPI Data Register (SPDR). The WCOL bit is set if the SPI Data Register (SPDR) is written during a data transfer. The WCOL bit (and the SPIF bit) are cleared by first reading the SPI Status Register with WCOL set, and then accessing the SPI Data Register.
When this bit is written logic one the SPI speed (SCK Frequency) will be doubled when the SPI is in Master mode. This means that the minimum SCK period will be 2 CPU clock periods. When the SPI is configured as Slave, the SPI is only guaranteed to work at or lower. This bit selects Master SPI mode when written to one, and Slave SPI mode when written logic zero. If SS is configured as an input and is driven low while MSTR is set, MSTR will be cleared, and SPIF in SPSR will become set.
The user will then have to set MSTR to re-enable SPI Master mode. These two bits control the SCK rate of the device configured as a Master. SPR1 and SPR0 have no effect on the Slave. The relationship between SCK and the Oscillator Clock frequency is shown in the following table:
The Serial Peripheral Interface (SPI) is a synchronous serial communication protocol that facilitates data exchange between a master device and one or multiple slave devices. The architecture of SPI is characterized by its simplicity and efficiency, making it suitable for a wide range of applications, including microcontroller communication with peripheral devices like sensors, memory cards, and display modules.
In an SPI configuration, the master device generates the clock signal, which synchronizes the data transmission on the two data lines, MOSI (Master Out Slave In) and MISO (Master In Slave Out). The master also controls the selection of slave devices through the Slave Select (SS) line, ensuring that only one slave is active during communication. The SPI protocol allows for full-duplex communication, meaning that data can be sent and received simultaneously, increasing the overall throughput of the system.
The SPI bus operates with a minimum of four lines: SCK (clock), MOSI, MISO, and SS. Additional slave devices can be connected to the same bus, each with a dedicated SS line controlled by the master. This configuration allows for multiple slaves to be addressed without the need for complex handshaking protocols, as the master simply toggles the SS line to select the desired slave.
In terms of electrical characteristics, the SPI bus can operate at various clock speeds, determined by the master. The SPI clock frequency (SCK) is critical in ensuring reliable data transfer, and its relationship with the oscillator frequency must be carefully managed, especially in systems with multiple devices operating at different speeds.
The SPI protocol also includes status flags, such as SPIF and WCOL, which provide feedback on the status of data transfers. The SPIF flag indicates the completion of a data transfer, while the WCOL flag indicates a write collision, which occurs if data is written to the SPI Data Register during an active transfer. Proper handling of these flags is essential for robust SPI communication.
Overall, the SPI protocol's straightforward design and high-speed capabilities make it a preferred choice in embedded systems, where efficient communication between microcontrollers and peripherals is essential.SPI stands for Serial Peripheral Interface and it is the simplest among all the communication protocols. 8bit data registers in the devices are connected by wires. These data registers works as shift registers and one of the device controls the data exchange inside the SPI Network.
The device or devices that controls the operation inside the netwo rk is known as the Master. For more elaboration, you may read the Wikipedia article: Serial Peripheral Interface Bus. There can be multiple Masters in a system. There may be multiple slaves too. The slave need not to be another micro controller. It can be an SD card, or some display device or may be some other electronic circuit. Irrespective of the device attached as a slave, it needs to get selected by master device(s) for data transfer. If the system is a multi-master network, then each individual secondary master needs to be selected for mastering the SPI BUS.
An SPI bus consist of two DATA lines, one clock line, and device select (or slave select) lines. The clocking signal is generated by the master in the network. Here, in this experiment, one system is build up to receive any character transmitted in the SPI. And it displays the character on the LCD display. So the receiver circuit is essentially a slave. As the receiver system will never transmit any data, we can keep it enabled all the time. There would be a master device that will transmit a string of character, either once, or repetitively. So let`s see, what are the available resources for this communication. When a serial transfer is complete, the SPIF Flag is set. An interrupt is generated if SPIE in SPCR is set and global interrupts are enabled. If SS is an input and is driven low when the SPI is in Master mode, this will also set the SPIF Flag.
SPIF is cleared by hardware when executing the corresponding interrupt Handling Vector. Alternatively, the SPIF bit is cleared by first reading the SPI Status Register with SPIF set, then accessing the SPI Data Register (SPDR). The WCOL bit is set if the SPI Data Register (SPDR) is written during a data transfer. The WCOL bit (and the SPIF bit) are cleared by first reading the SPI Status Register with WCOL set, and then accessing the SPI Data Register.
When this bit is written logic one the SPI speed (SCK Frequency) will be doubled when the SPI is in Master mode. This means that the minimum SCK period will be 2 CPU clock periods. When the SPI is configured as Slave, the SPI is only guaranteed to work at or lower. This bit selects Master SPI mode when written to one, and Slave SPI mode when written logic zero. If SS is configured as an input and is driven low while MSTR is set, MSTR will be cleared, and SPIF in SPSR will become set.
The user will then have to set MSTR to re-enable SPI Master mode. These two bits control the SCK rate of the device configured as a Master. SPR1 and SPR0 have no effect on the Slave. The relationship between SCK and the Oscillator Clock frequency is shown in the following table:
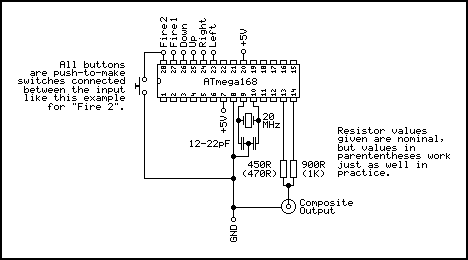
AVR TV Game
Martin Ustek has modified the project to include a Sokoban game. Information about his version can be found throughout this page; for full details, please visit his website (Czech). Either game can be selected with a menu that appears when...
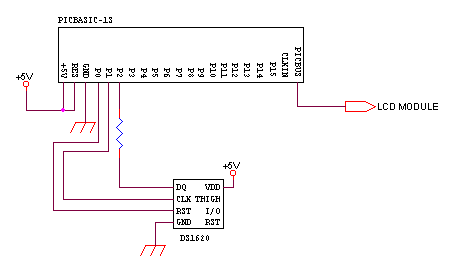
spi circuit
SPI Integrated Circuit Bus, IC Buses, an IC, Chip-to-Chip Bus Serial Peripheral Interface, Integrated Circuit Bus types, and IC Bus Electrical Interface Descriptions. Peripheral Interface (SPI) circuit is a.
The Serial Peripheral Interface (SPI) is a synchronous serial communication protocol...
SPI Interface Circuit for Big 7 Segment LED
This circuit is designed for general-purpose use with a large LED display utilizing SPI serial interfacing. It employs a serial-in-parallel-out shift register, specifically the 74HC595, to receive serial data from a microcontroller board. The schematic wiring indicates that SER is...
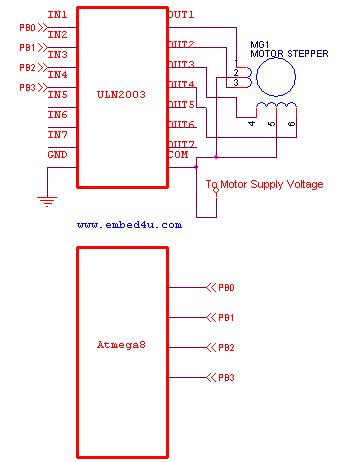
AVR Microcontroller Interface with Stepper Motor
This tutorial utilizes the ATmega8 microcontroller with a 4 MHz crystal oscillator and unipolar stepper motors. The ULN2003, a Darlington pair driver integrated circuit, is employed for motor control.
The ATmega8 microcontroller is a versatile 8-bit device from the AVR family,...
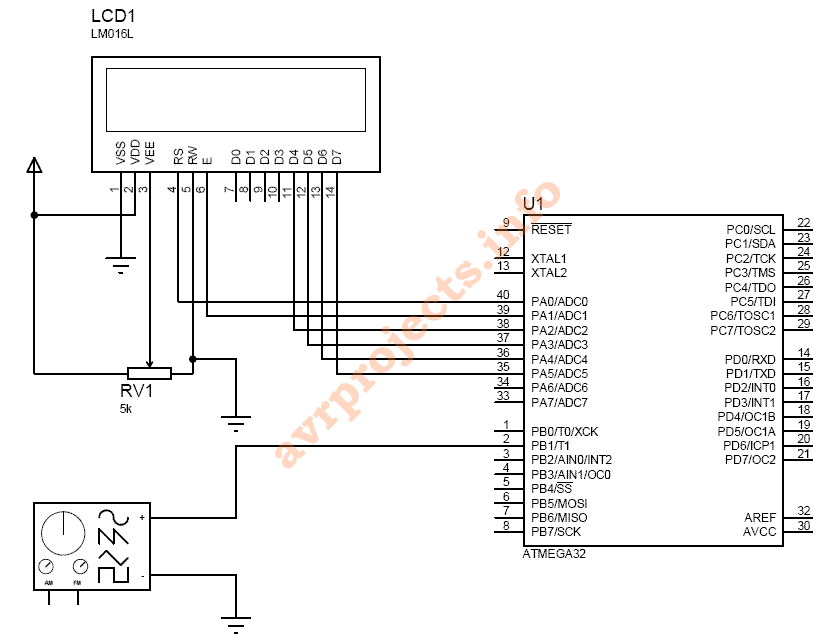
8 MHz frequency meter using AVR microcontroller
This project measures the clock pulses supplied to the Timer input of the AVR microcontroller. The Bascom code counts the clock pulses over a duration of 1 second and displays the result.
The circuit for this project primarily consists of an...
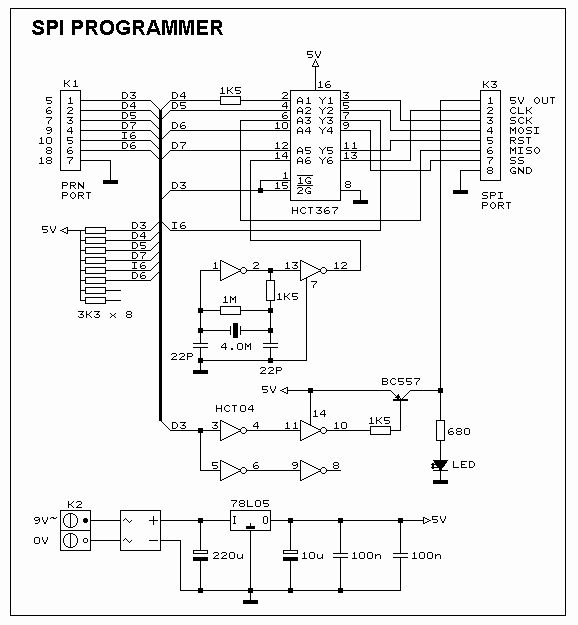
SPI-Flash Programmer 3.7
This SPI Flash Programmer can be utilized for both in-system programming and as a standalone serial flash programmer for Atmel SPI programmable devices. The hardware interface of the programmer is managed through the PC's parallel port, with control signals from...
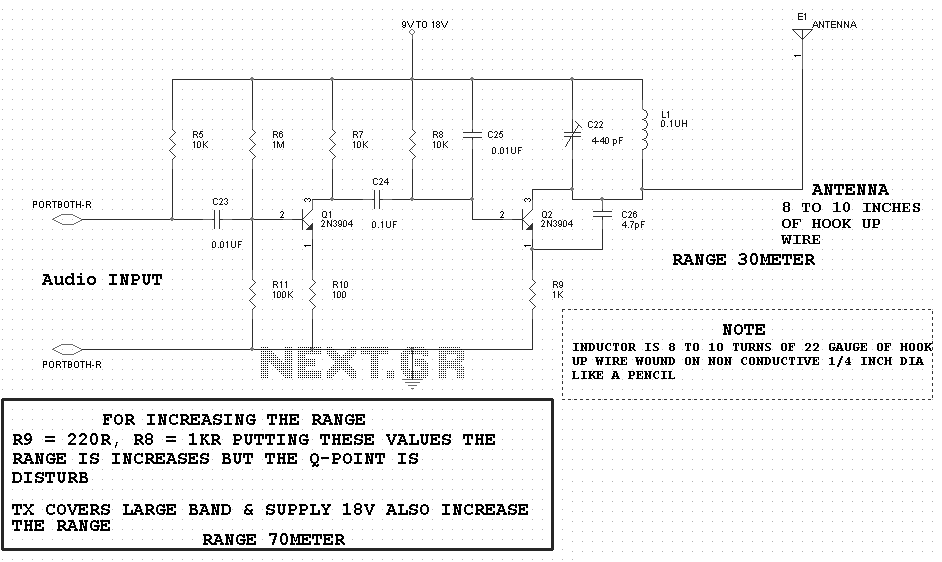
thermometer dengan avr
The module provides a pre-wired multiplex of a 4-digit common anode LED, which is quite useful. The soldering pad for these signals is shown in the first picture below. A friend provided an AT90S2313 chip, along with a simple homemade...
Wireless Lan for AVR microcontrollers
The page is about equipping an Atmel AVR microcontroller based system with a Prism WLAN interface. This document is intended for people that already have experiences with the AVR microcontrollers and teaches them how to add a cheap but flexible...
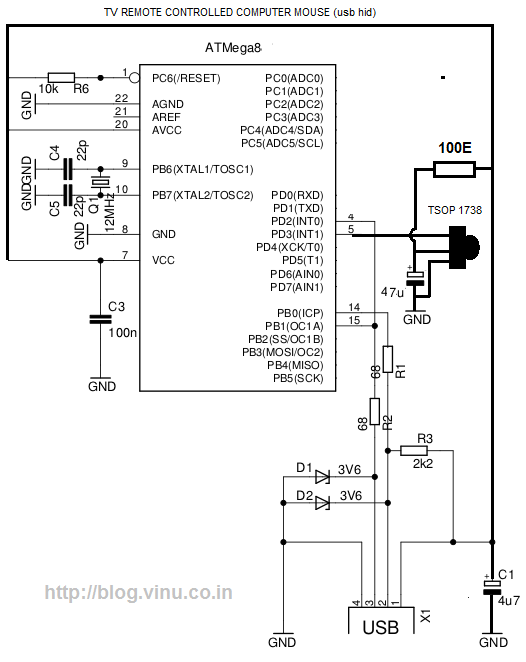
TV remote controlled computer mouse (an avr VUSB project)
While lying in bed and watching movies on a laptop, the idea arose that having a remote control would simplify the tasks of pausing, playing, fast forwarding, rewinding, adjusting volume, and playing the next track without needing to approach the...