


gps altimeter
#GPS
#Picaxe 18X
#NMEA
#altimeter
#rocketry
#data stream
#baud rate
#sensor
#programming
#desert launch
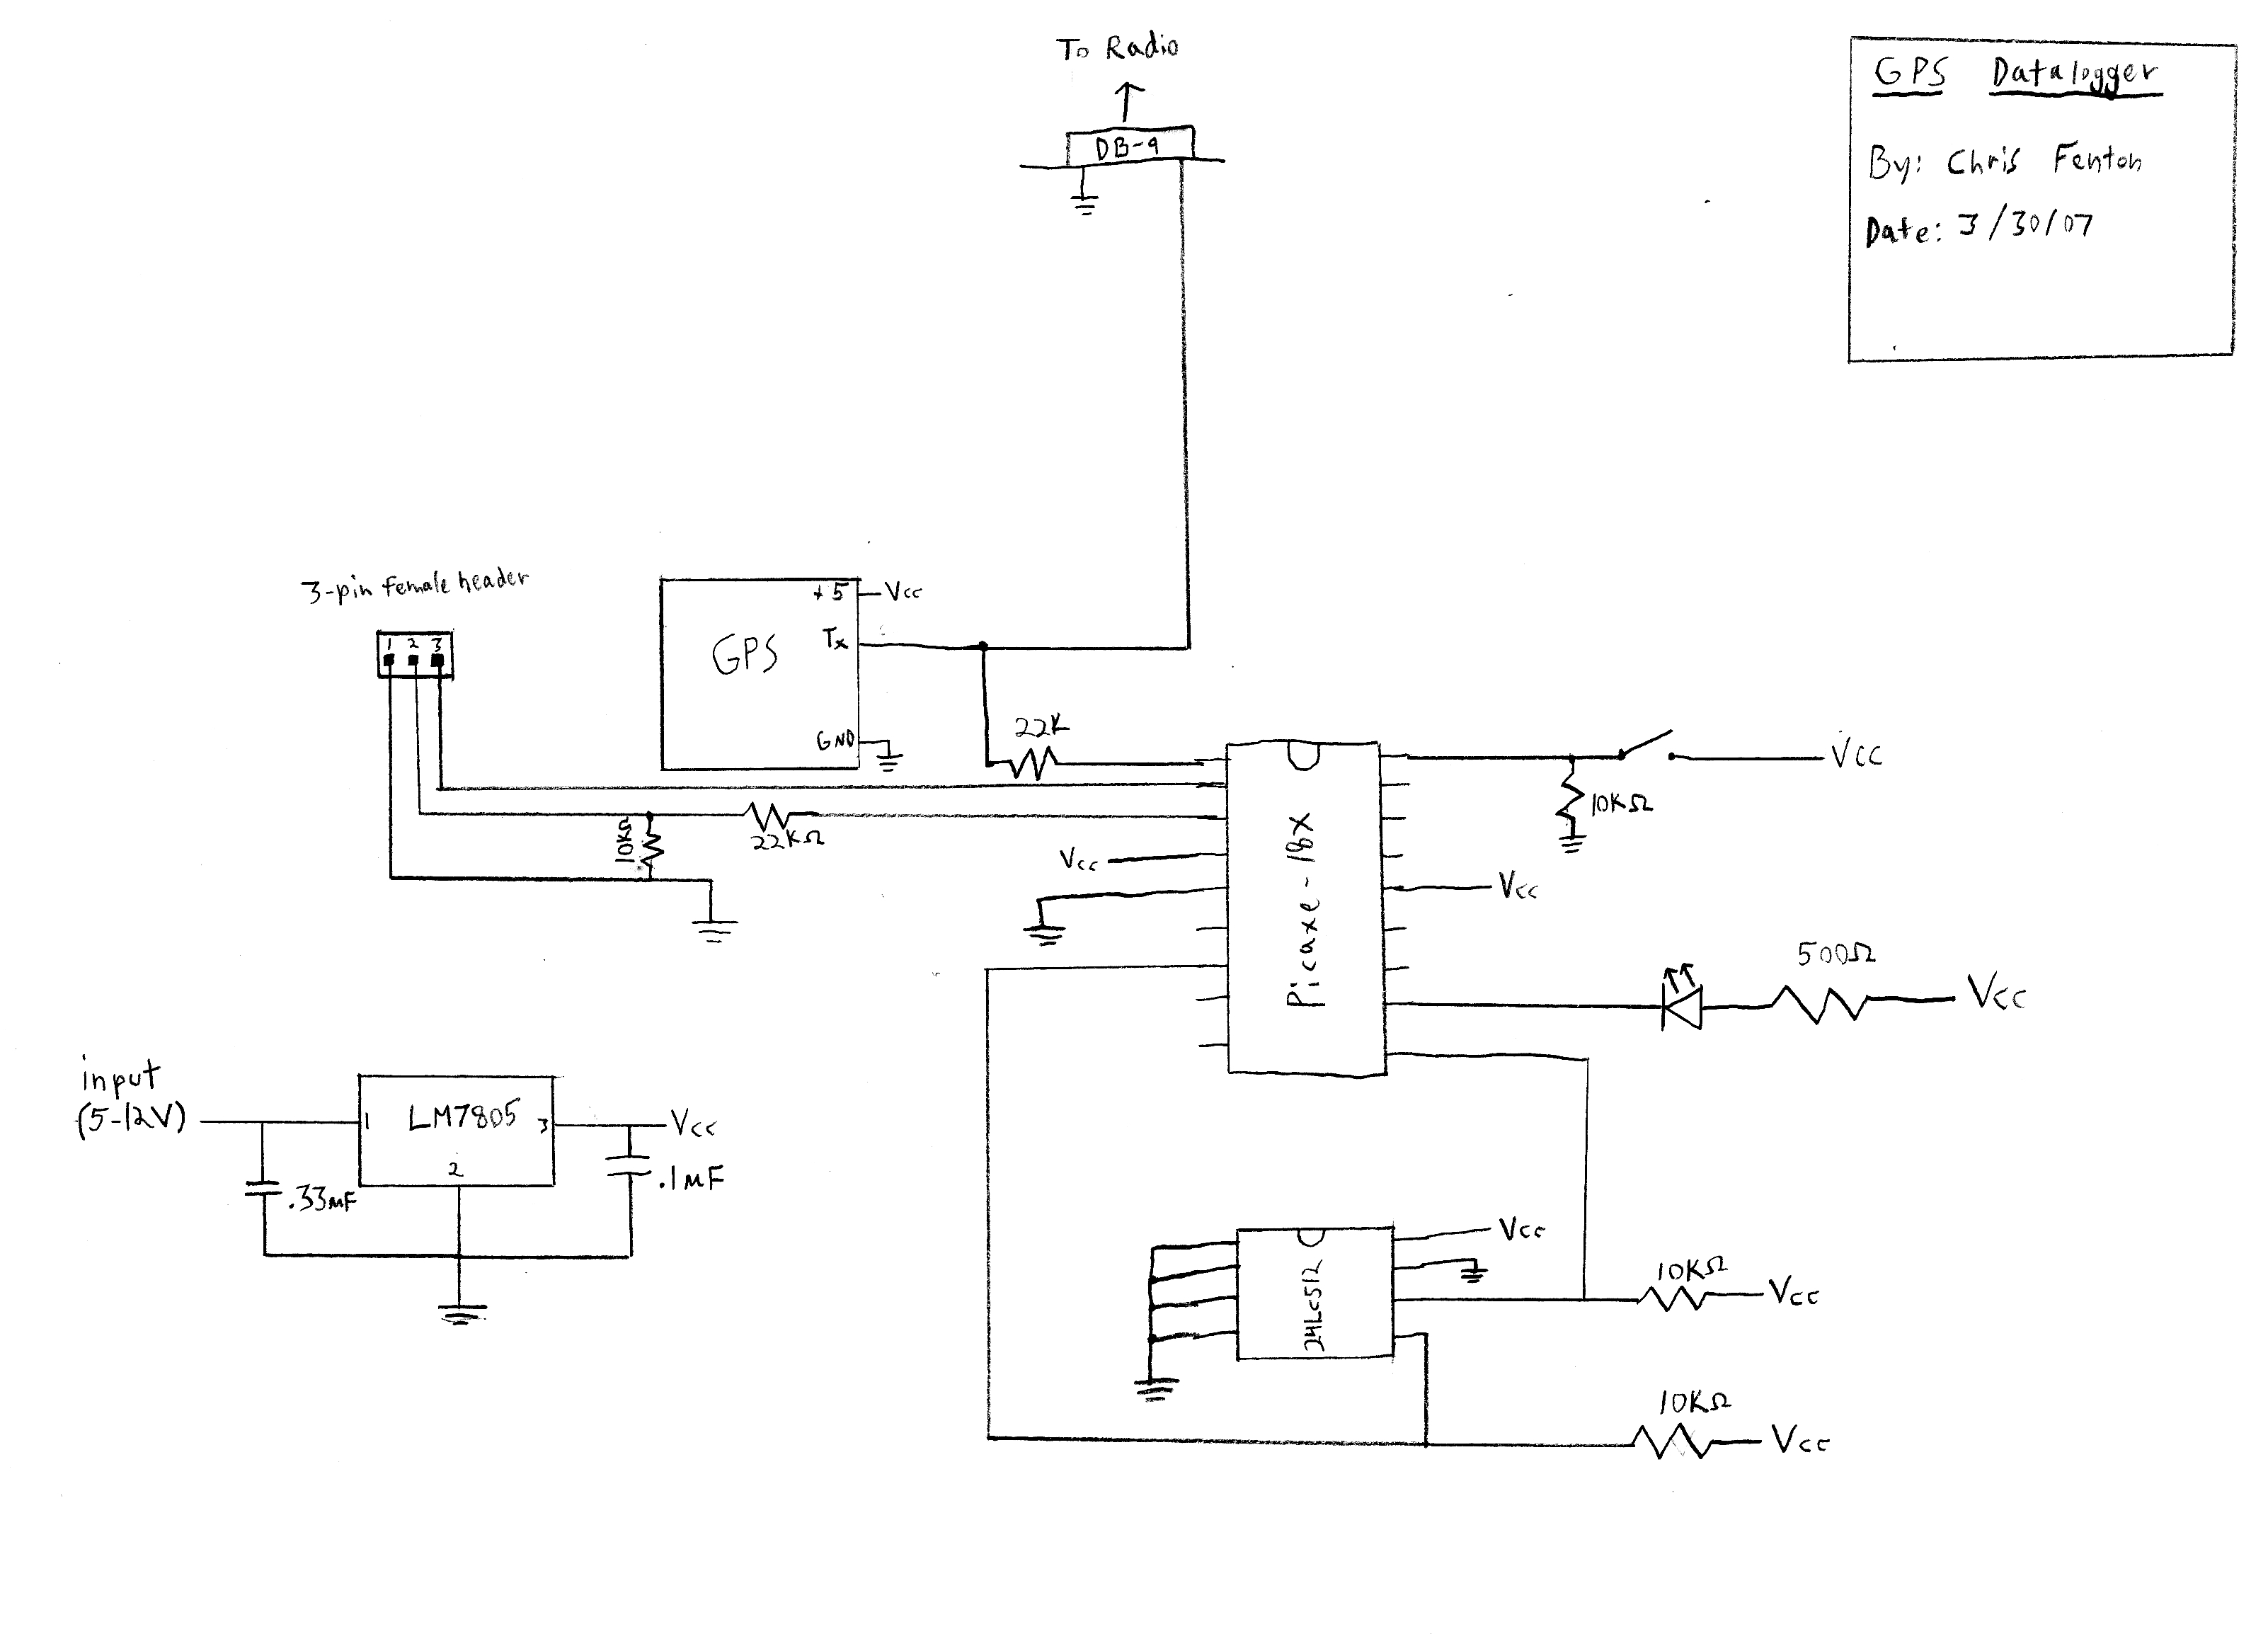
Description: This device was developed rapidly for the USC Rocket Propulsion Lab, which is a student-run high-altitude rocketry initiative at USC. It was assembled shortly before the launch and programmed during travel to the launch site. The device utilizes a Picaxe 18X microcontroller and accepts a GPS NMEA data stream at 4800 baud. It extracts altitude data and logs it to a 24LC512 external EEPROM, which can be read back after the flight. The data clearly indicates instances where the GPS lost satellite lock during descent. The rocket achieved a maximum altitude of approximately 18,400 feet.
The electronic schematic of this device integrates several key components to facilitate its operation. The Picaxe 18X microcontroller serves as the central processing unit, controlling the overall functionality and data processing of the system. It is programmed to handle incoming GPS data, interpret the NMEA sentences, and extract relevant altitude information from the data stream.
The GPS module interfaces with the Picaxe microcontroller through a serial communication link, operating at a baud rate of 4800. This allows the microcontroller to receive real-time position and altitude data. The GPS module is powered by the same supply as the microcontroller, ensuring synchronized operation during the rocket's ascent and descent.
Data logging is accomplished using a 24LC512 EEPROM, which is interfaced with the microcontroller via the I2C protocol. The EEPROM provides sufficient storage capacity to log multiple altitude readings throughout the flight. The microcontroller writes altitude data to the EEPROM at predetermined intervals, ensuring that data is captured even if the GPS temporarily loses satellite lock.
The design includes power regulation circuitry to ensure that both the microcontroller and GPS module operate within specified voltage ranges. This may involve the use of linear voltage regulators or DC-DC converters, depending on the power source used during the launch.
To enhance reliability, the circuit may include decoupling capacitors near the power pins of the microcontroller and GPS module, filtering out noise that could disrupt operation. Additionally, a reset circuit may be implemented to ensure that the microcontroller can recover from any unexpected faults during operation.
Overall, this device represents a compact and efficient solution for high-altitude rocketry data logging, with a focus on capturing and storing critical flight data for post-launch analysis.This device was created in a hurry for the USC Rocket Propulsion Lab, the student-run high-altitude rocketry effort at USC. I think I soldered it together a day or two before the launch, and then programmed it on a laptop on the car trip out to the desert.
It uses a Picaxe 18X microcontroller and accepts a GPS NMEA data stream at 4800 baud (I thin k ). It pulls out the altitude and logs it to a 24LC512 external EEPROM, and then reads it back when you are done. You can clearly see where the GPS device briefly lost satellite lock on the way down. The rocket hit a final altitude of about 18, 400 feet! Its take-off was also the single loudest thing I have ever heard in my life. If you ever get a chance to watch a large rocket launch, I highly recommend it!
The electronic schematic of this device integrates several key components to facilitate its operation. The Picaxe 18X microcontroller serves as the central processing unit, controlling the overall functionality and data processing of the system. It is programmed to handle incoming GPS data, interpret the NMEA sentences, and extract relevant altitude information from the data stream.
The GPS module interfaces with the Picaxe microcontroller through a serial communication link, operating at a baud rate of 4800. This allows the microcontroller to receive real-time position and altitude data. The GPS module is powered by the same supply as the microcontroller, ensuring synchronized operation during the rocket's ascent and descent.
Data logging is accomplished using a 24LC512 EEPROM, which is interfaced with the microcontroller via the I2C protocol. The EEPROM provides sufficient storage capacity to log multiple altitude readings throughout the flight. The microcontroller writes altitude data to the EEPROM at predetermined intervals, ensuring that data is captured even if the GPS temporarily loses satellite lock.
The design includes power regulation circuitry to ensure that both the microcontroller and GPS module operate within specified voltage ranges. This may involve the use of linear voltage regulators or DC-DC converters, depending on the power source used during the launch.
To enhance reliability, the circuit may include decoupling capacitors near the power pins of the microcontroller and GPS module, filtering out noise that could disrupt operation. Additionally, a reset circuit may be implemented to ensure that the microcontroller can recover from any unexpected faults during operation.
Overall, this device represents a compact and efficient solution for high-altitude rocketry data logging, with a focus on capturing and storing critical flight data for post-launch analysis.This device was created in a hurry for the USC Rocket Propulsion Lab, the student-run high-altitude rocketry effort at USC. I think I soldered it together a day or two before the launch, and then programmed it on a laptop on the car trip out to the desert.
It uses a Picaxe 18X microcontroller and accepts a GPS NMEA data stream at 4800 baud (I thin k ). It pulls out the altitude and logs it to a 24LC512 external EEPROM, and then reads it back when you are done. You can clearly see where the GPS device briefly lost satellite lock on the way down. The rocket hit a final altitude of about 18, 400 feet! Its take-off was also the single loudest thing I have ever heard in my life. If you ever get a chance to watch a large rocket launch, I highly recommend it!
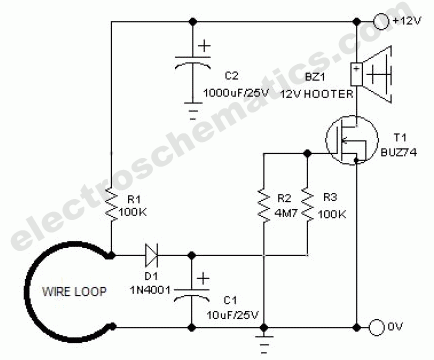
Wire Break Sensor Alarm Circuit Schematic
The circuit of a loop sensor-based simple security alarm is described here. The sensor loop consists of a short length of thin enamelled copper wire.
The loop sensor security alarm operates on the principle of detecting interruptions in the circuit formed...
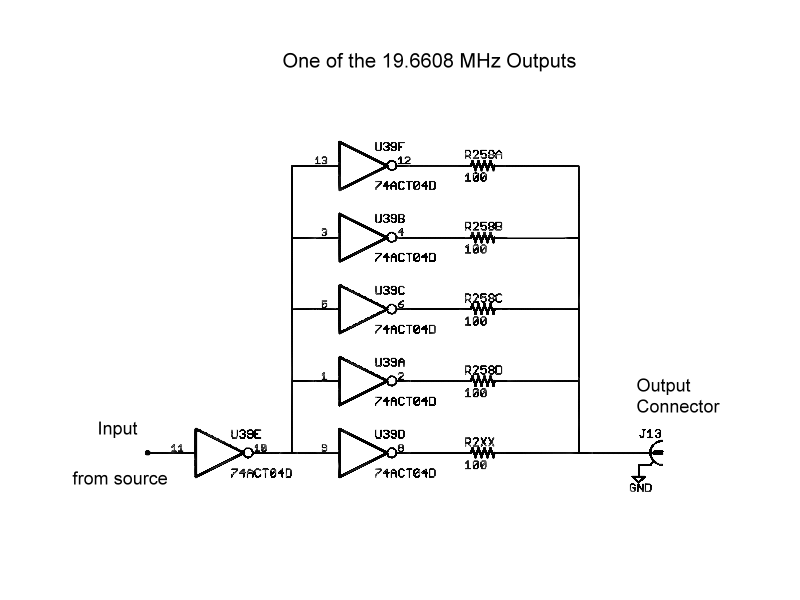
Z3816A Modification
The Z3816A is a GPS disciplined timing source manufactured by HP in the mid-1990s, intended for use in cellular telephone equipment. It provides ten output signals through SMA connectors on the back panel. The first four connectors on the left...
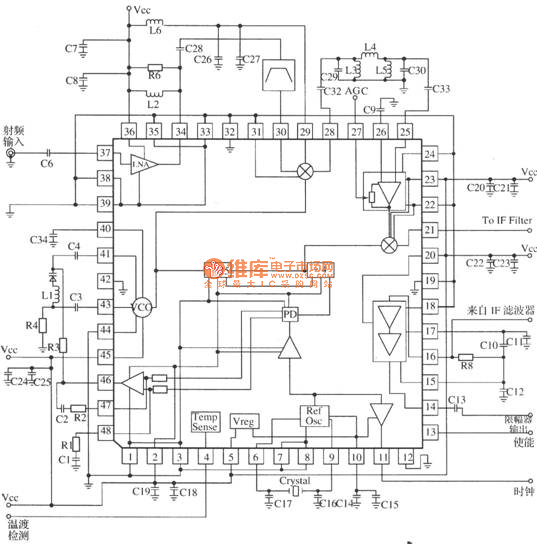
MRFICl505R2 based GPS receiver RF front-end circuit
MRFICl505R2 is a 1.575GHz GPS downconverter chip. It integrates a mixer, VCO, PLL, crystal oscillator, A/D converter, loop filter, and other circuits. The MRFICl505R2 IF output frequency is 4.1MHz, with a typical conversion gain of 105dB, an operating voltage of...
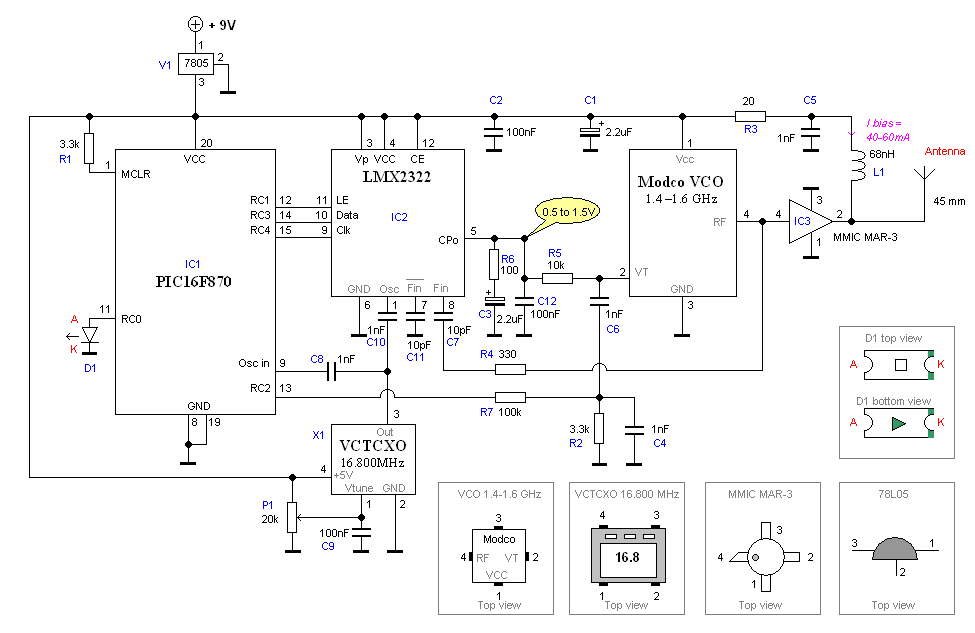
GPS Jammer
A GPS receiver costing less than a few hundred dollars can provide immediate location information, including latitude, longitude, and altitude, accurate to within a few hundred feet. The output from the Voltage-Controlled Oscillator (VCO) is directly connected to a Monolithic...
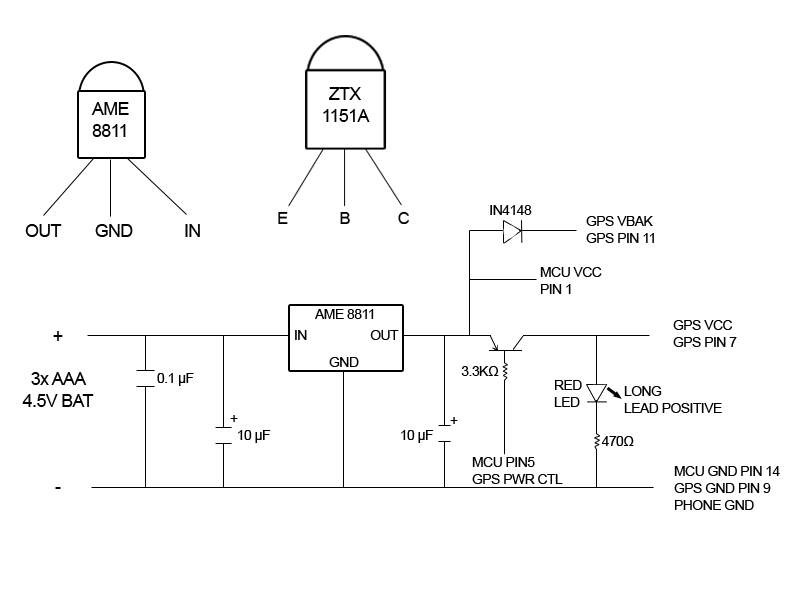
the Open GPS Tracker
The tracker is straightforward to construct on a perfboard. A basic one-pad-per-hole perfboard and 26-gauge wire are recommended, although 30-gauge wire may be more suitable. All electronic components can be sourced from Mouser Electronics, while Radio Shack offers the perfboard...
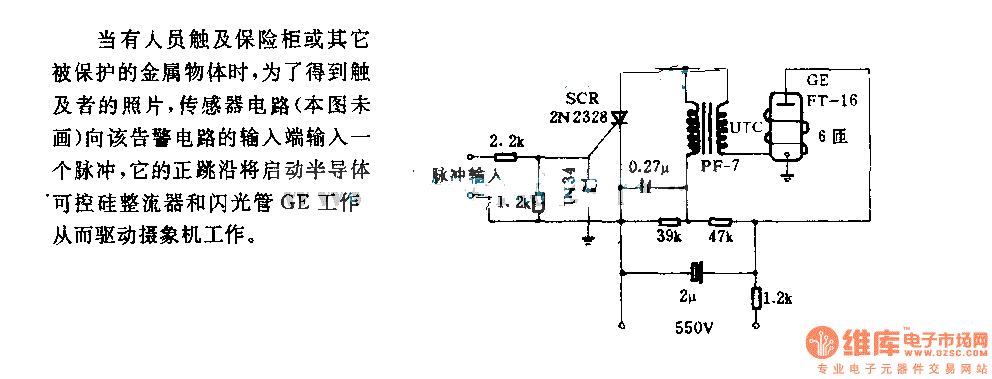
The alarm circuit diagram for safety box and other metal objects
When an individual touches the safety box or other protected metal objects, the sensor circuit generates a pulse to the alarm circuit. The positive edge of this pulse activates the semiconductor and thyristor flash GE, subsequently triggering the camera to...
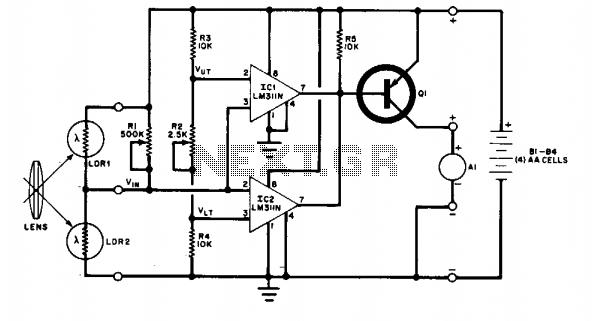
Field disturbance sensor-alarm
The change in ambient light triggers the alarm by changing the resistance of LDR1 and LDR2.
The circuit utilizes two light-dependent resistors (LDR1 and LDR2) to detect variations in ambient light levels. LDRs are passive components that exhibit a change in...
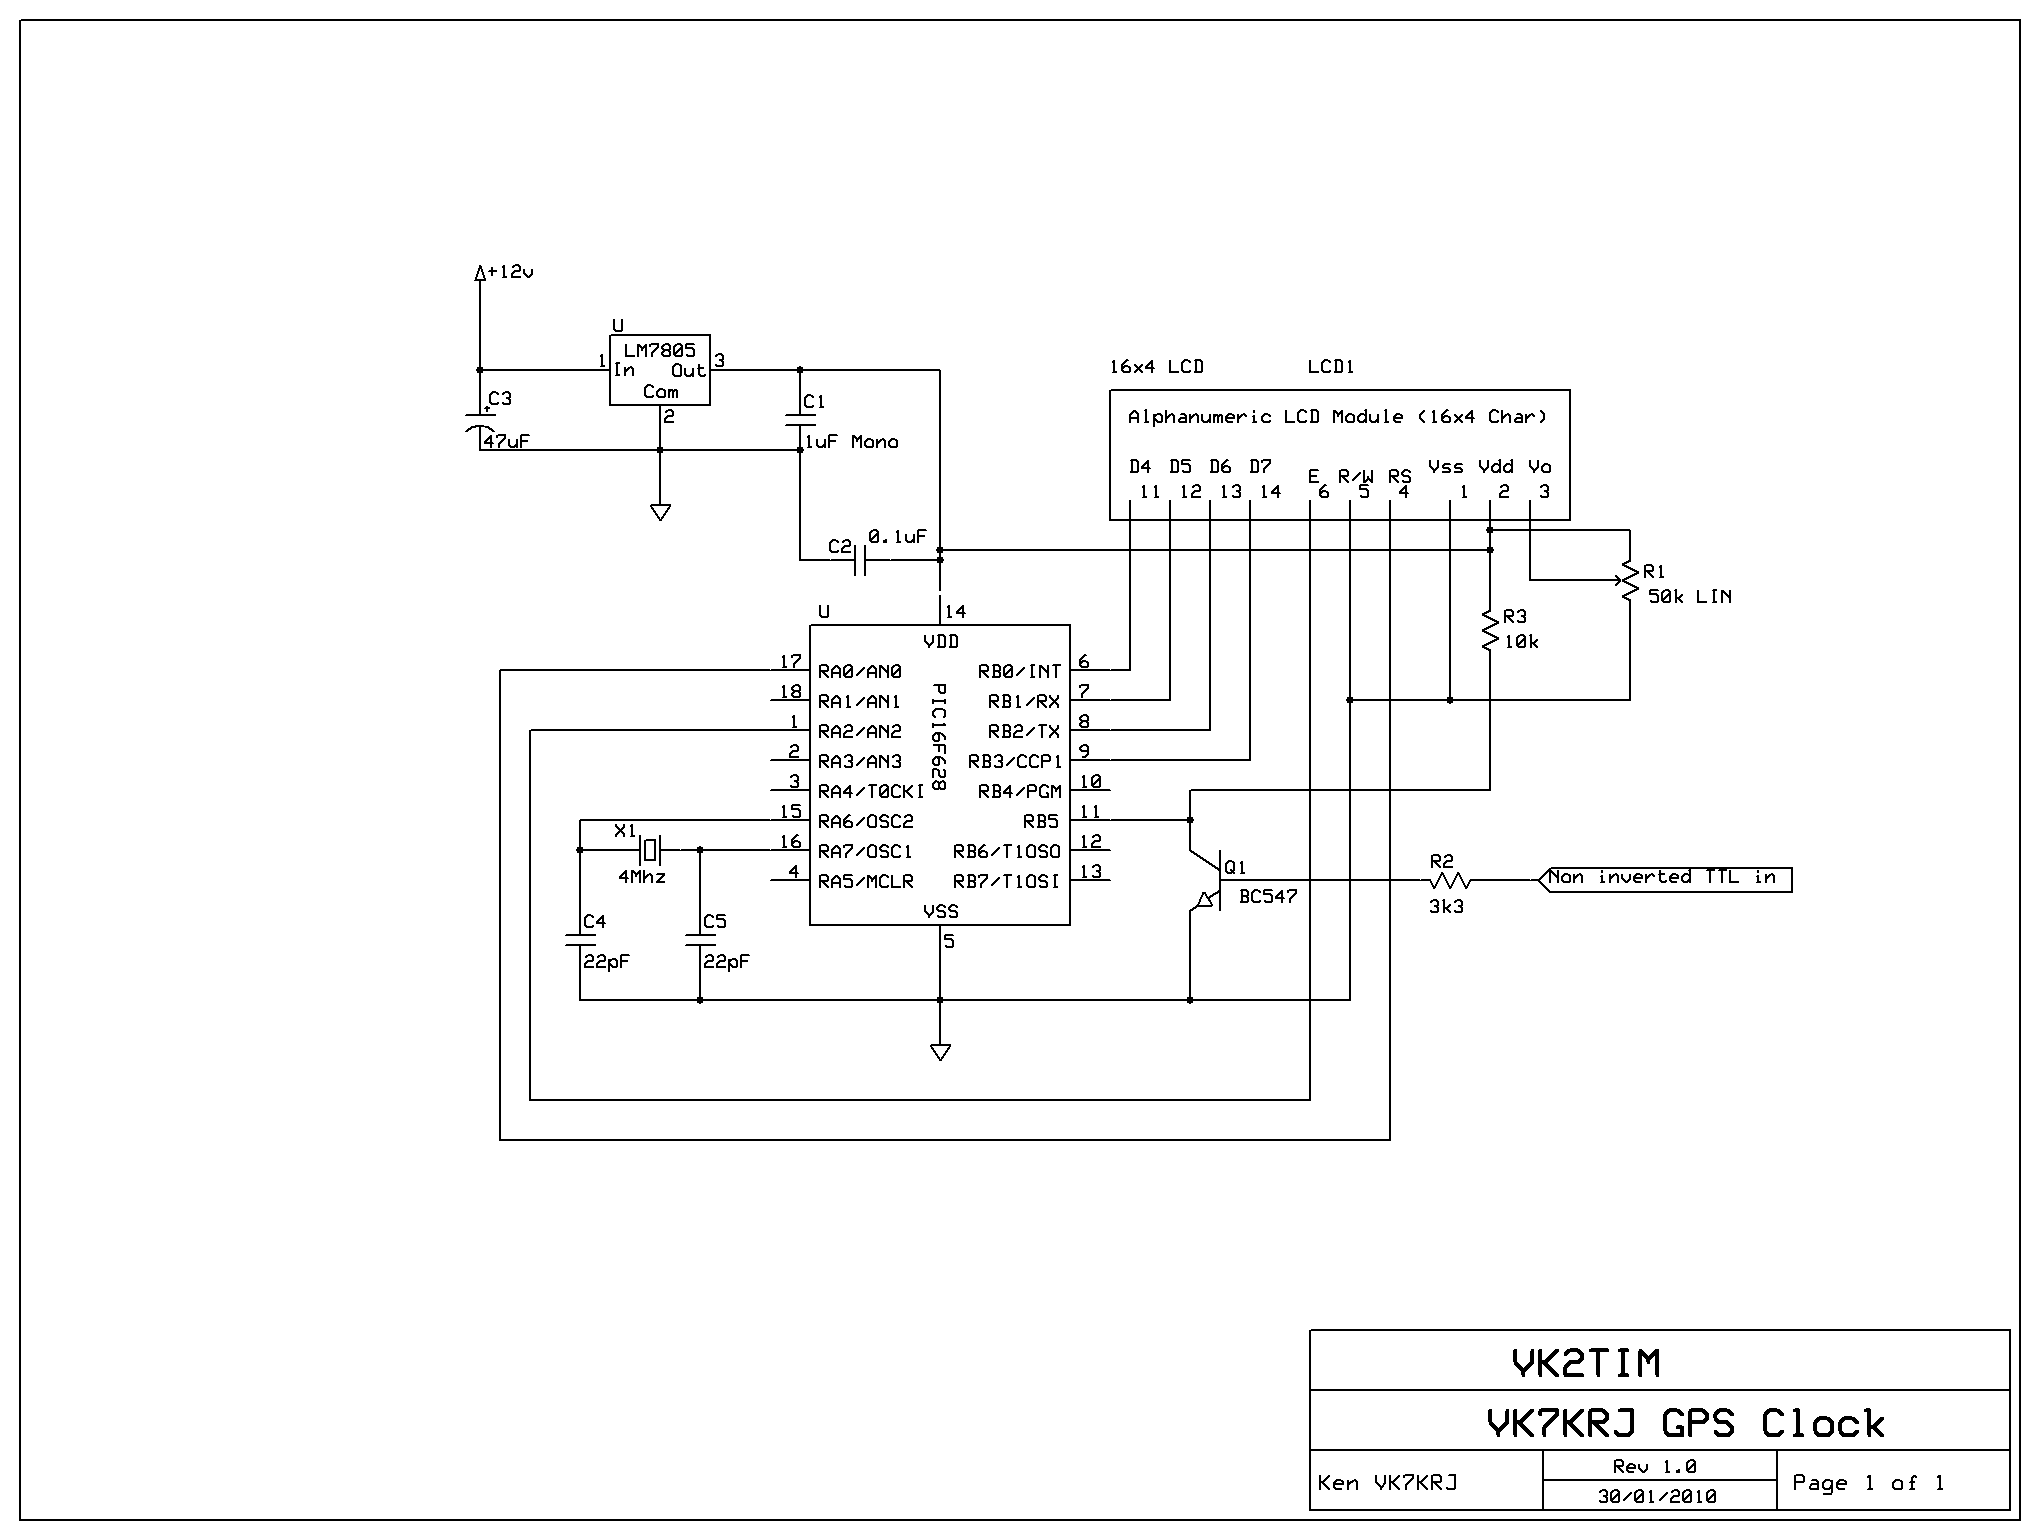
gps driven clock compasss peedo
This project is a GPS-based clock that displays the current date, automatically adjusts for daylight saving time, shows current speed, maximum speed, and present heading in degrees relative to true north. The original firmware and concept were developed by Ken,...
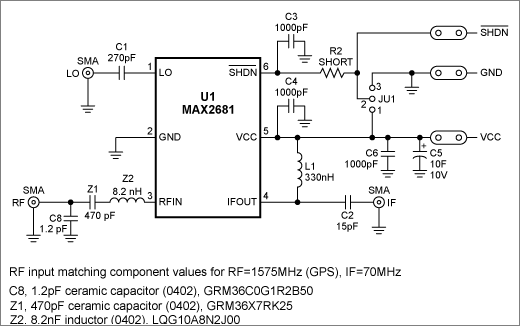
The MAX2681 SiGe Downconverter Mixer Tuned for GPS Front Ends
This application note presents the component values and measured performance for the MAX2681 mixer IC when tuned for GPS operation at 1575 MHz.
The MAX2681 is a high-performance mixer integrated circuit designed for use in GPS applications, particularly at the frequency...