


Decoding 4 buttons with two I/O's on AVR
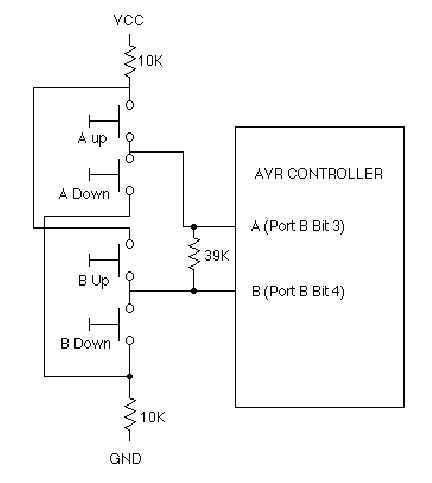
Description: Just the solution for AVR applications in which I/O is tight, such as the ATtiny12. This should work well on other kinds of controllers that have independently controlled I/O direction registers, such as PIC and 6805 controllers. This solution was devised for those I/O limited 8 pin controllers like the AT90S2323 (though it was tested on an AT90S1200A). In principle, the circuit senses three states of the pushbuttons: Open (no button down), Pulled Up, and Pulled Down. The process is this: Pin A (PORTB bit 4) driven high through a resistor and the other end of the resistor is looked at Pin B (PORTB bit 4) to see if it is being pulled high, low, or not being driven up by a button at all. Then Pin B is driven and the other end of the resistor (Pin A) is looked at. In the circuit, a 39k resistor is placed across the two I/O pins to allow each pin to drive the other through the resistor. The two pairs of buttons connected identically, except that one pair of buttons is connected to pin A (PORTB bit 3) and the other pair of buttons is connected to Pin B (PORTB bit 4). In each pair, one button is connected to VCC through a 10k resistor and the other button connects to ground through a 10k resistor. The remaining contacts on the two buttons in each pair are connected together and connected to their respective I/O pin. It's a digital circuit so the actual resistor values aren't important as long as the logic thresholds for the input ports are exceeded. The four-button implementation only requires three resistors total. This concept can be extended by using more pairs of I/O pins and still has an advantage over simpler matrices, but the disadvantage disappears when the number of I/O lines reaches 8. One other note: A circuit was published on the web around the end of 2002 (about a year after this circuit was first published) that uses one less resistor but relies on the value of the weak internal pull-up on the processor's I/O pin. This concept was rejected early on as it was not robust enough in light of the poorly defined characteristics of the weak pull-up. The design presented here will work by design.
The described circuit is a pushbutton input mechanism designed for AVR microcontrollers, particularly useful in scenarios where the number of available I/O pins is limited. The circuit utilizes two I/O pins to detect the state of multiple pushbuttons, allowing for efficient use of available resources.
The primary components of the circuit include two I/O pins (designated as Pin A and Pin B) and a set of pushbuttons. Each button is configured such that one is connected to the positive supply voltage (VCC) through a 10kΩ resistor, while the other is connected to ground through another 10kΩ resistor. This configuration allows the circuit to determine three distinct states: when no button is pressed (Open), when a button is pressed connecting the pin to VCC (Pulled Up), and when a button is pressed connecting the pin to ground (Pulled Down).
A critical aspect of the circuit is the 39kΩ resistor placed between the two I/O pins. This resistor allows the two pins to interact, enabling Pin A to read the state of Pin B and vice versa. When Pin A is driven high, the state of Pin B is monitored to determine if it is also being pulled high, pulled low, or remains unconnected. This provides a simple yet effective method for managing multiple inputs while minimizing the number of required resistors, as only three resistors are needed to implement a four-button configuration.
This design can be extended by adding more pairs of I/O pins, thereby increasing the number of buttons that can be detected while maintaining the same resistor configuration. However, it is noted that the advantage of this setup diminishes when the number of I/O lines reaches eight, at which point a more conventional matrix configuration may be more suitable.
Overall, this circuit design is robust and effective for applications requiring multiple button inputs with limited I/O resources, providing a reliable method for state detection in embedded systems.Just the solution for AVR applications in which I/O is tight, such as the ATtiny12. This should work well on other kids of controllers that have independently controlled I/O direction registers, such as PIC and 6805 controllers. This is a solution was devised for those I/O limited 8 pin controllers like the AT90S2323 (though I tested it on an AT90S1200A).
In principle, the circuit senses three states of the pushbuttons: Open (no button down), Pulled Up, and Pulled Down. The process is this: Pin A (PORTB bit 4)driven high through a resistor and the other end of the resistor is looked, at Pin B (PORTB bit 4) to see if it is being pulled high, low, or not being driven up a button at all.
Then Pin B is driven and the other end of the resistor (Pin A) is looked at. In the circuit, a 39k resistor is placed across the two I/O pins to allow each pin to drive the other through the resistor. The two pair of buttons connected identically, except that one pair of buttons is connected to pin A (PORTB bit 3) and the other pair of buttons is connected Pin B (PORTB bit 4).
In each pair, one button is connected to VCC through a 10k resistor and the other button connects to ground through a 10k resistor. The remaining contacts on the two buttons in each pair are connected together and connected to their respective I/O pin.
Its a digital circuit so the actual resistor values aren't important as long as the logic thresholds for the input ports are exceeded. The four button implementation only requires three resistors total. This concept can be extended by using more pairs of I/O pins and still has an advantage over simpler matrices, but the disadvantage disappears when the number of I/O lines reaches 8.
(Added June, 2003): One other note: A circuit was published on the web around the end of 2002 (about a year after this circuit was first published) that uses one less resistor but relies on the value of the weak internal pullup on the processor's I/O pin. I rejected this concept early on as it was not robust enough in light of the poorly defined characteristics of the weak pullup.
The design presented here will work by design.
The described circuit is a pushbutton input mechanism designed for AVR microcontrollers, particularly useful in scenarios where the number of available I/O pins is limited. The circuit utilizes two I/O pins to detect the state of multiple pushbuttons, allowing for efficient use of available resources.
The primary components of the circuit include two I/O pins (designated as Pin A and Pin B) and a set of pushbuttons. Each button is configured such that one is connected to the positive supply voltage (VCC) through a 10kΩ resistor, while the other is connected to ground through another 10kΩ resistor. This configuration allows the circuit to determine three distinct states: when no button is pressed (Open), when a button is pressed connecting the pin to VCC (Pulled Up), and when a button is pressed connecting the pin to ground (Pulled Down).
A critical aspect of the circuit is the 39kΩ resistor placed between the two I/O pins. This resistor allows the two pins to interact, enabling Pin A to read the state of Pin B and vice versa. When Pin A is driven high, the state of Pin B is monitored to determine if it is also being pulled high, pulled low, or remains unconnected. This provides a simple yet effective method for managing multiple inputs while minimizing the number of required resistors, as only three resistors are needed to implement a four-button configuration.
This design can be extended by adding more pairs of I/O pins, thereby increasing the number of buttons that can be detected while maintaining the same resistor configuration. However, it is noted that the advantage of this setup diminishes when the number of I/O lines reaches eight, at which point a more conventional matrix configuration may be more suitable.
Overall, this circuit design is robust and effective for applications requiring multiple button inputs with limited I/O resources, providing a reliable method for state detection in embedded systems.Just the solution for AVR applications in which I/O is tight, such as the ATtiny12. This should work well on other kids of controllers that have independently controlled I/O direction registers, such as PIC and 6805 controllers. This is a solution was devised for those I/O limited 8 pin controllers like the AT90S2323 (though I tested it on an AT90S1200A).
In principle, the circuit senses three states of the pushbuttons: Open (no button down), Pulled Up, and Pulled Down. The process is this: Pin A (PORTB bit 4)driven high through a resistor and the other end of the resistor is looked, at Pin B (PORTB bit 4) to see if it is being pulled high, low, or not being driven up a button at all.
Then Pin B is driven and the other end of the resistor (Pin A) is looked at. In the circuit, a 39k resistor is placed across the two I/O pins to allow each pin to drive the other through the resistor. The two pair of buttons connected identically, except that one pair of buttons is connected to pin A (PORTB bit 3) and the other pair of buttons is connected Pin B (PORTB bit 4).
In each pair, one button is connected to VCC through a 10k resistor and the other button connects to ground through a 10k resistor. The remaining contacts on the two buttons in each pair are connected together and connected to their respective I/O pin.
Its a digital circuit so the actual resistor values aren't important as long as the logic thresholds for the input ports are exceeded. The four button implementation only requires three resistors total. This concept can be extended by using more pairs of I/O pins and still has an advantage over simpler matrices, but the disadvantage disappears when the number of I/O lines reaches 8.
(Added June, 2003): One other note: A circuit was published on the web around the end of 2002 (about a year after this circuit was first published) that uses one less resistor but relies on the value of the weak internal pullup on the processor's I/O pin. I rejected this concept early on as it was not robust enough in light of the poorly defined characteristics of the weak pullup.
The design presented here will work by design.
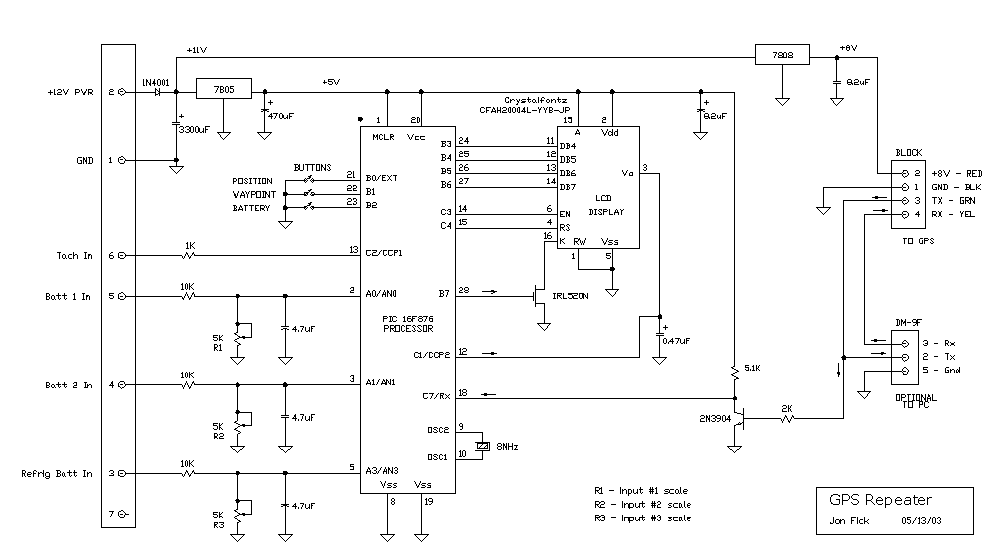
PIC-based applications from Westford MicroSystems descriptions C source code and schematics
PIC C Compilers are utilized to compile source code, leveraging the extensive built-in functions offered by these compilers. A single C statement can produce multiple pages of PIC RISC instructions, eliminating the need for manual coding. CCS charges $125 for...
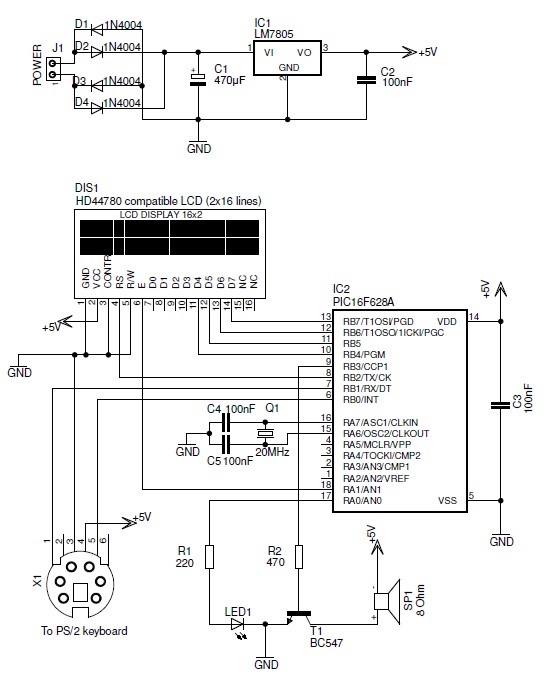
morse Circuit
This PIC-based hardware circuit accepts texts from a PS/2 keyboard and converts it into a Morse code audio signal.
The described circuit utilizes a PIC microcontroller to interface with a PS/2 keyboard, allowing for the input of alphanumeric characters. The microcontroller...
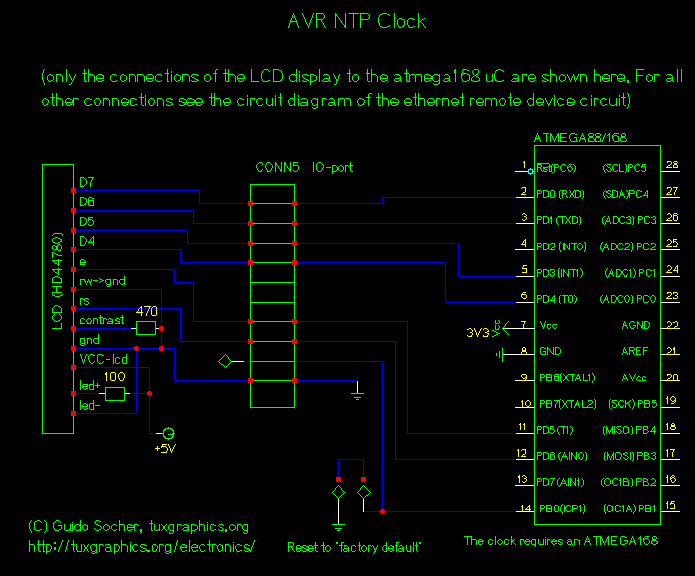
avr ntp clock.
The Network Time Protocol (NTP) has transformed global timekeeping, allowing accurate time and date information from anywhere in the world. NTP is a straightforward UDP-based protocol that can be implemented in a microcontroller. While UDP and TCP servers have been...
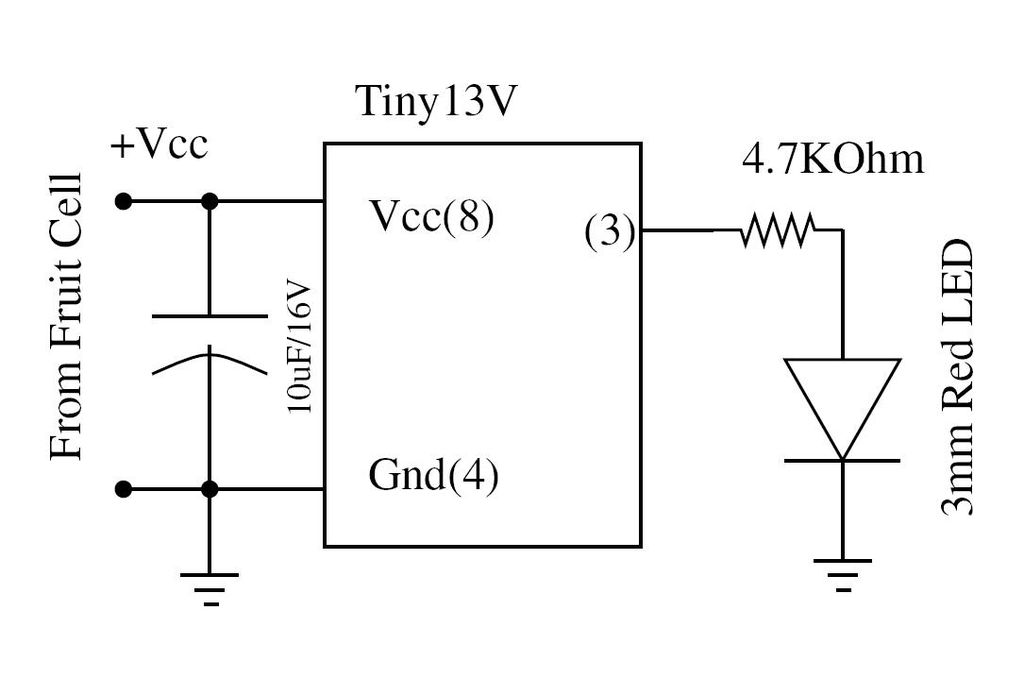
Assemble the AVR Tiny MIcrocontroller Circuit
Wire the circuit diagram shown here on a breadboard. The choice of V type of AVR is important. For example, Tiny13V is very appropriate for such an application.
To successfully implement the circuit diagram on a breadboard, several considerations must be...
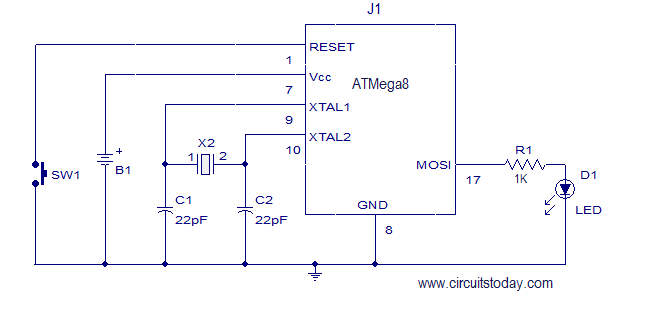
How to add 32K crystal/clock source to AVR Microcontroller (ATmega8)
This article explains how to add a 32K external crystal/clock source to the Atmel AVR microcontroller Atmega8, including a circuit diagram and a C program.
The Atmel AVR microcontroller Atmega8 is a popular choice for various embedded applications, often requiring an...
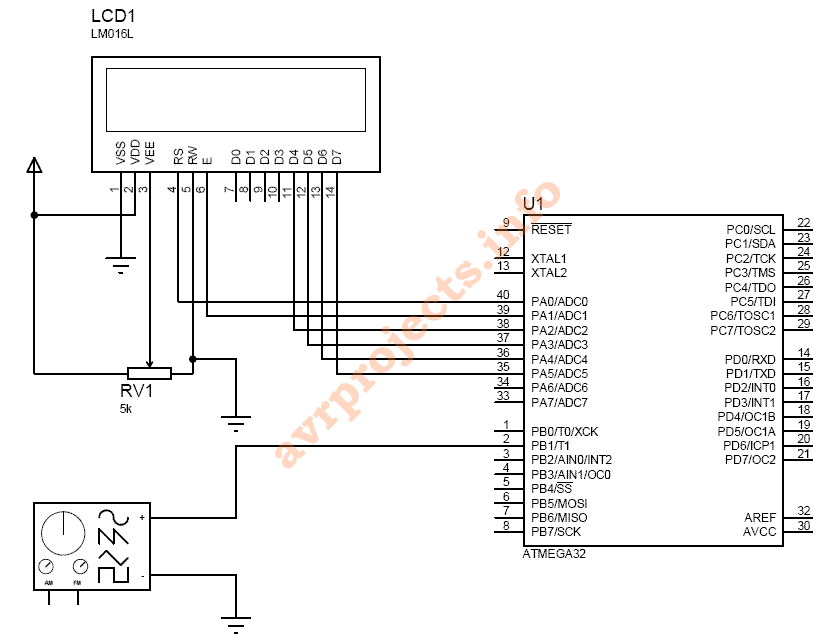
8 MHz frequency meter using AVR microcontroller
This project measures the clock pulses supplied to the Timer input of the AVR microcontroller. The Bascom code counts the clock pulses over a duration of 1 second and displays the result.
The circuit for this project primarily consists of an...
AVR
The article "Creating a Line Follower Robot with AVR" serves as a continuation of a previous piece on line follower robots, focusing on the AVR ATMega8535 and the associated block diagram. In the first part of this series, titled "Creating...
Wireless Lan for AVR microcontrollers
The page is about equipping an Atmel AVR microcontroller based system with a Prism WLAN interface. This document is intended for people that already have experiences with the AVR microcontrollers and teaches them how to add a cheap but flexible...
PIC Frequency Counter with Frequency Lock
This PIC software integrates frequency counter and frequency locking functions. By incorporating a couple of transistors and an operational amplifier (TL082), it is feasible to stabilize the LC oscillator frequency. The frequency reference is established from the measured frequency itself...