


Chosen Circuit
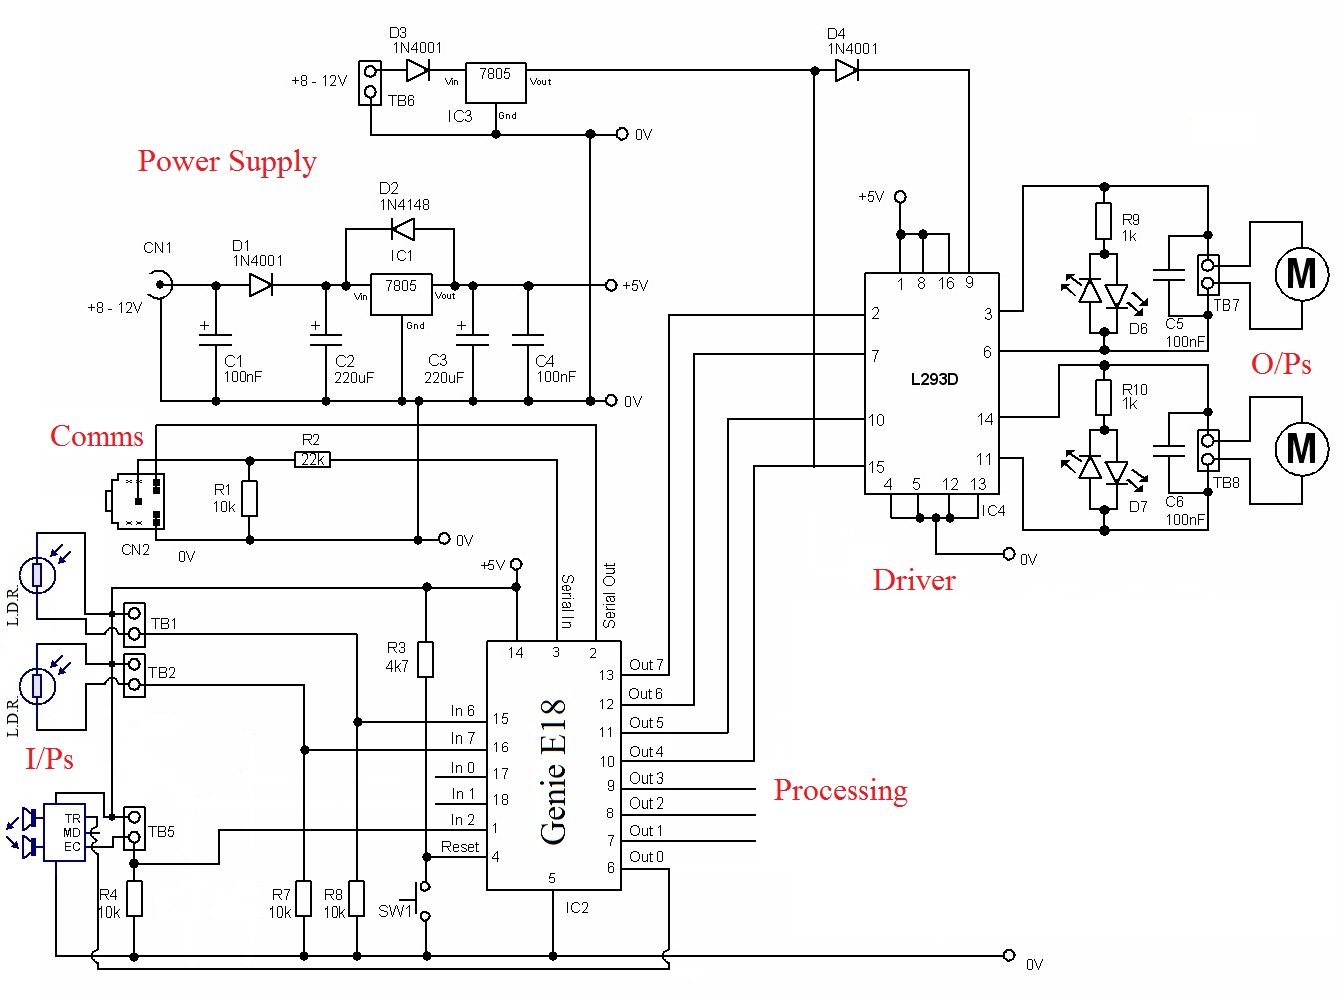
Description: The circuit requires a power source to function. The PIC needs a 5-volt supply, while the driver demands a higher voltage to operate the motors. Inputs: The inputs come from three sensors. Two of these sensors are Light Dependent Resistors (LDRs) designed to detect the edge of the arena. The third sensor is an ultrasonic sensor.
The circuit design incorporates a microcontroller, specifically a PIC (Peripheral Interface Controller), which operates at a nominal voltage of 5 volts. This microcontroller serves as the central processing unit, interfacing with various sensors and controlling motor operations. The higher voltage required for the motor driver is typically in the range of 12 to 24 volts, depending on the specifications of the motors used in the application.
The input stage of the circuit consists of three sensors. The two LDRs are strategically positioned to monitor ambient light levels and detect the boundaries of the arena. When the LDRs sense a significant change in light intensity, indicating the presence of an edge, they provide a signal to the PIC, allowing it to take appropriate action, such as stopping or redirecting the motors.
The third sensor, the ultrasonic sensor, operates by emitting high-frequency sound waves and measuring the time it takes for the echoes to return. This sensor is crucial for distance measurement and obstacle detection. It provides real-time feedback to the PIC, enabling the system to navigate effectively within the arena.
Power management is essential in this circuit. A voltage regulator may be used to ensure that the PIC receives a stable 5-volt supply, while a separate power supply circuit is necessary for the motor driver to handle the higher voltage requirements. Additionally, proper decoupling capacitors should be placed near the power pins of the microcontroller and driver to filter out any noise and ensure stable operation.
In summary, this circuit integrates a PIC microcontroller with LDR and ultrasonic sensors for effective edge detection and obstacle avoidance, powered by a dual-voltage system to meet the operational requirements of both the microcontroller and the motor driver.The circuit requires a power source to work. The PIC requires a 5volt supply and the driver requires a larger voltage to operate the motors. Inputs: The inputs are from three sensors. Two sensors are L.D.R`s. These two sensors are to detect the edge of the arena. The third sensor is an Ultrasonic.
The circuit design incorporates a microcontroller, specifically a PIC (Peripheral Interface Controller), which operates at a nominal voltage of 5 volts. This microcontroller serves as the central processing unit, interfacing with various sensors and controlling motor operations. The higher voltage required for the motor driver is typically in the range of 12 to 24 volts, depending on the specifications of the motors used in the application.
The input stage of the circuit consists of three sensors. The two LDRs are strategically positioned to monitor ambient light levels and detect the boundaries of the arena. When the LDRs sense a significant change in light intensity, indicating the presence of an edge, they provide a signal to the PIC, allowing it to take appropriate action, such as stopping or redirecting the motors.
The third sensor, the ultrasonic sensor, operates by emitting high-frequency sound waves and measuring the time it takes for the echoes to return. This sensor is crucial for distance measurement and obstacle detection. It provides real-time feedback to the PIC, enabling the system to navigate effectively within the arena.
Power management is essential in this circuit. A voltage regulator may be used to ensure that the PIC receives a stable 5-volt supply, while a separate power supply circuit is necessary for the motor driver to handle the higher voltage requirements. Additionally, proper decoupling capacitors should be placed near the power pins of the microcontroller and driver to filter out any noise and ensure stable operation.
In summary, this circuit integrates a PIC microcontroller with LDR and ultrasonic sensors for effective edge detection and obstacle avoidance, powered by a dual-voltage system to meet the operational requirements of both the microcontroller and the motor driver.The circuit requires a power source to work. The PIC requires a 5volt supply and the driver requires a larger voltage to operate the motors. Inputs: The inputs are from three sensors. Two sensors are L.D.R`s. These two sensors are to detect the edge of the arena. The third sensor is an Ultrasonic.
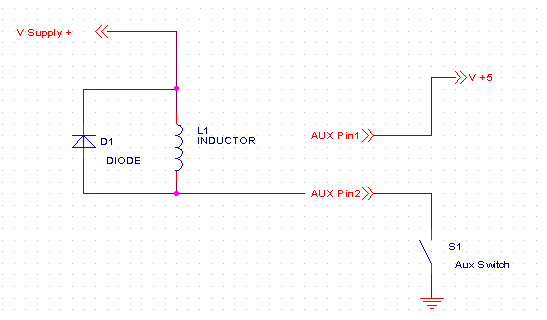
KMotion Connectors
The typical current consumption is 0.7 Amps when no user input/output is connected. Additional current may be necessary depending on the amount of digital input/output and analog +/- 15V consumed by the user. The board generates up to 2 watts...
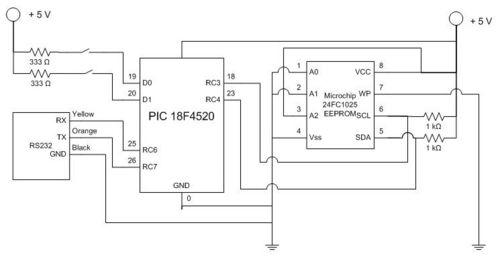
Data logging with an EEPROM
The task involves using a PIC microcontroller to log data from an analog input to an external EEPROM and subsequently sending the collected data back to a PC running MATLAB. An interrupt service routine (ISR) is utilized to read the...
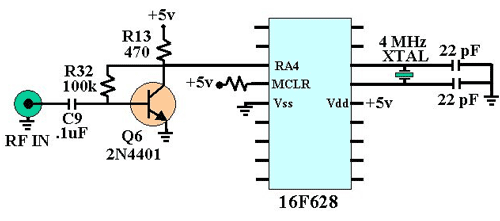
PIC Freq Counter
A prescaler is connected to a PIC microcontroller to create a basic frequency counter. It is anticipated that this component will serve as a module to be integrated into future design projects. The initial requirement is to obtain a functional...
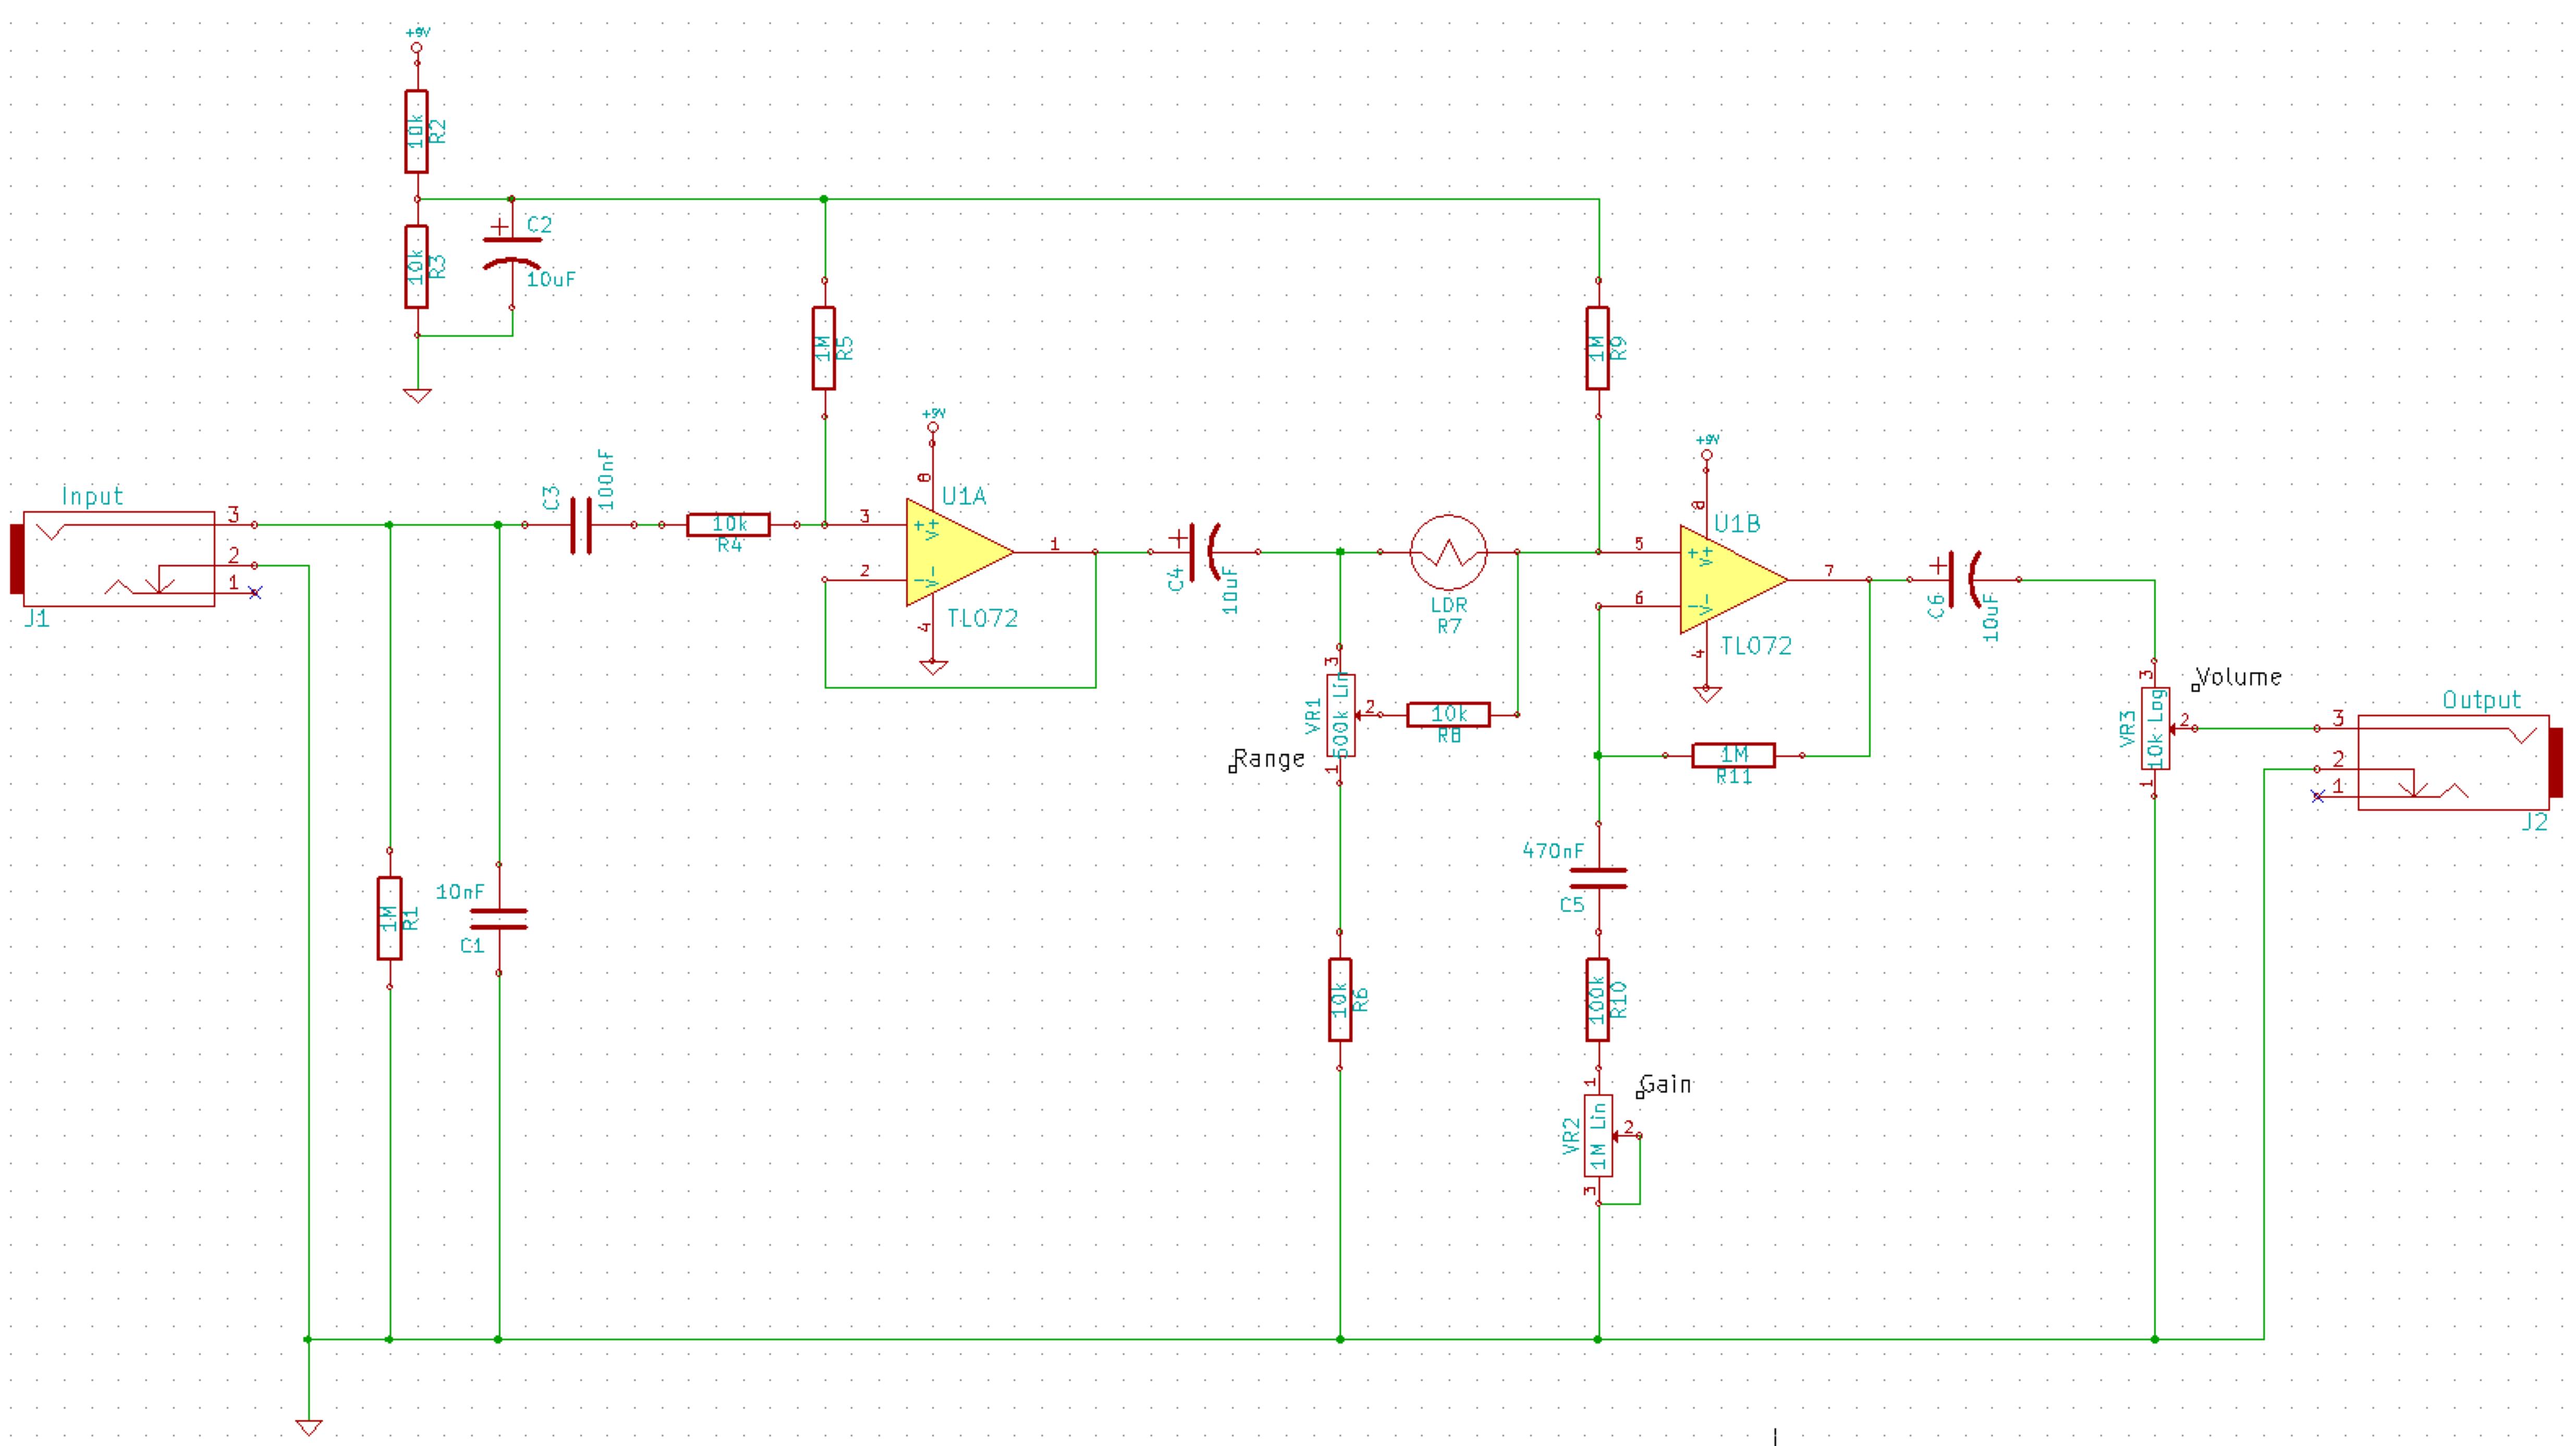
Solar Lifeforce LDR volume pedal circuit
This is a simplified schematic for the Solar Lifeforce. The design eliminates the expression/CV output features and the toggle for the buffer, making it a straightforward circuit. It may benefit from adding small capacitors between R5 and ground, as well...
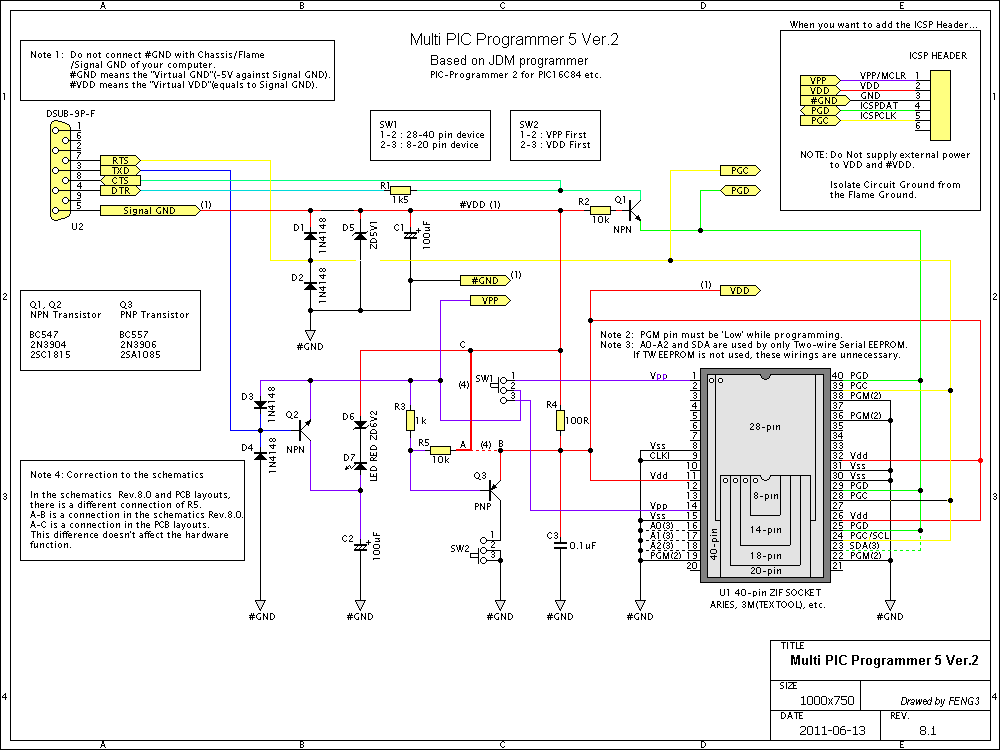
JDM pic programmer help required
For the following circuit of the JDM PIC microcontroller programmer, information is needed regarding the PIC microcontroller pins that receive the RS232 signals.
The JDM PIC microcontroller programmer is a widely used circuit for programming PIC microcontrollers via the RS232 interface....
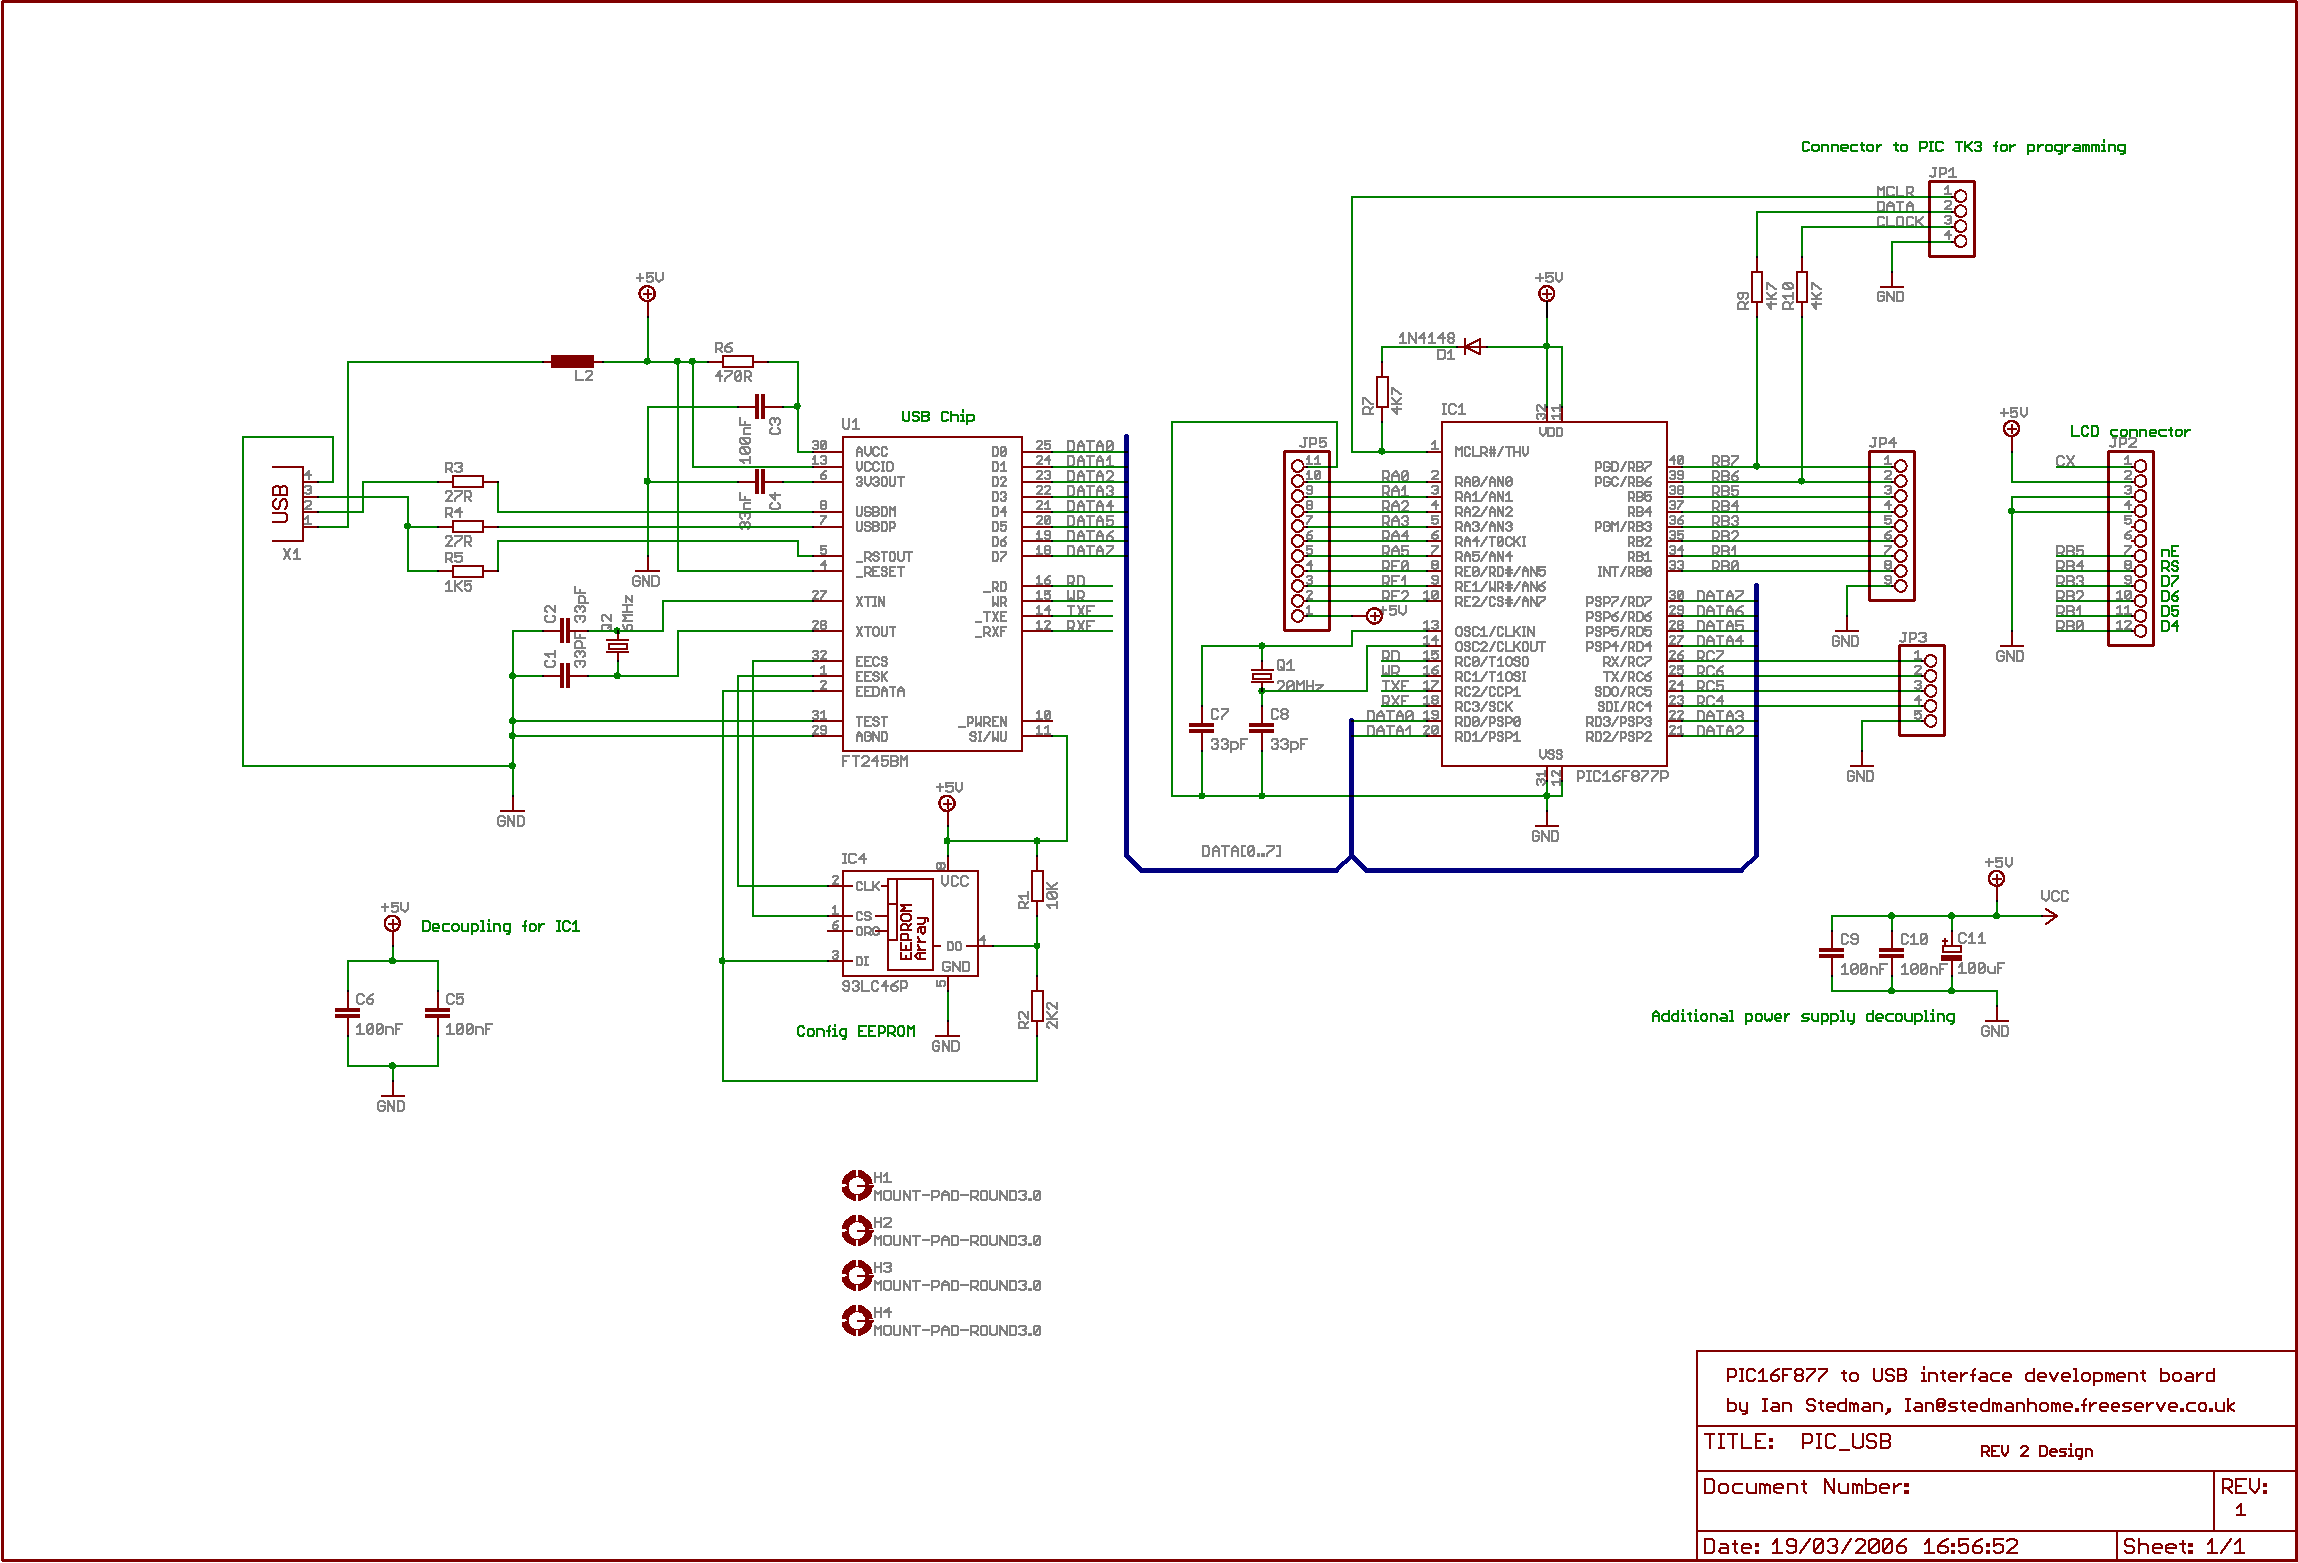
PIC USB Interface
The second program sends "Hello world" to the PC. By default, the board utilizes the Virtual COM Port (VCP) driver, allowing output to be viewed using Hyperterminal or similar software; PuTTY is recommended. The setup is straightforward: upon connecting the...
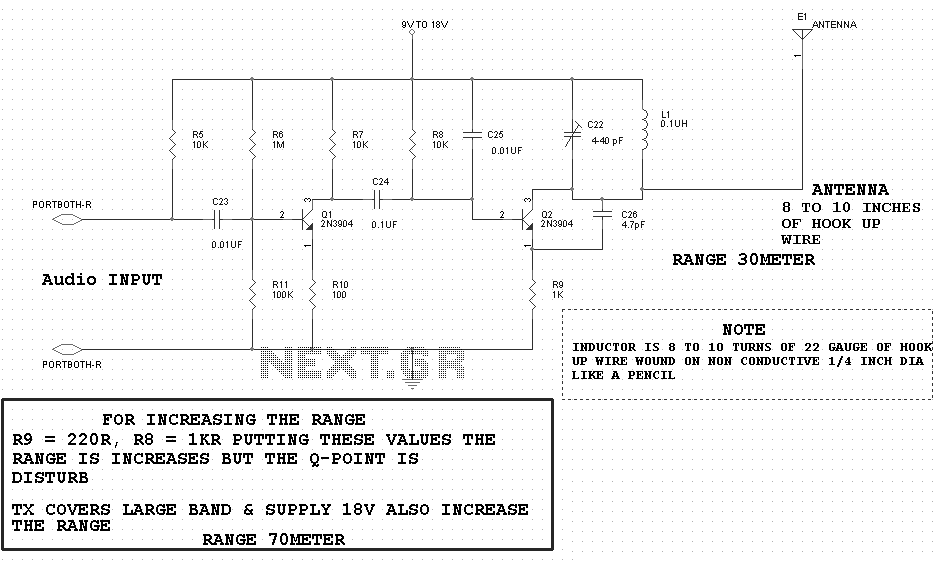
prop clock
Propclocks are complex devices that utilize a PIC microcomputer operating at 10 MHz. The PIC serves as the core component, managing the timing of LED illumination to create the illusion of numbers and, in analog mode, hands suspended in mid-air....
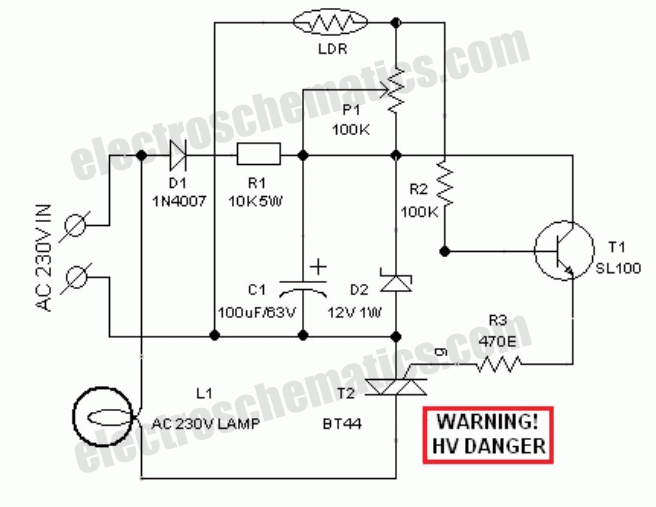
Automatic street light circuit
The circuit depicted will automatically switch ON and OFF at night and morning, respectively. In this circuit, R1 can be adjusted to change the sensitivity. The operation of the circuit is straightforward. The Light Dependent Resistor (LDR) exhibits very low...
PIC Frequency Counter with Frequency Lock
This PIC software integrates frequency counter and frequency locking functions. By incorporating a couple of transistors and an operational amplifier (TL082), it is feasible to stabilize the LC oscillator frequency. The frequency reference is established from the measured frequency itself...