


build solar engine
#PIC16F84
#solar engine
#BEAM robots
#robotics
#microcontroller programmer
#solar power
#living robots
#Mark W. Tilden
#control circuits
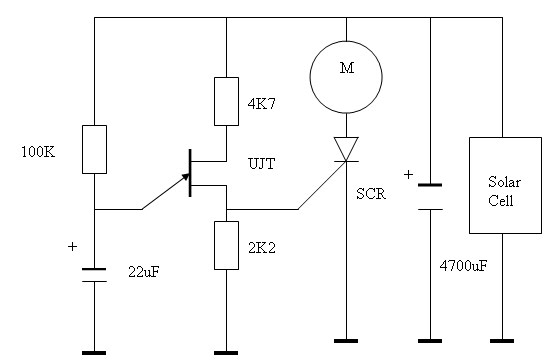
Description: A discussion on the application of the PIC16F84 microcontroller for control and robotics, as well as instructions for programming the PIC16F84/A microcontroller. The solar engine is frequently utilized as an onboard power source for BEAM-type robots, sometimes referred to as living robots. The concept of the solar engine was initially developed by Mr. Mark W. Tilden, who created a solar engine design. Another contributor, Dave Hrynkiw from Canada, adapted this design to power a solar ball robot. The following figure illustrates the schematic for the solar engine, which is derived from the book titled "Robot, Android, and Animatron" by John Iovine. The operational principle involves the solar cell charging a main 4700µF capacitor, which acts as a power bank. As the capacitor charges, the circuit voltage increases. The Uni Junction Transistor (UJT) begins to oscillate, generating a trigger pulse for the Silicon Controlled Rectifier (SCR). Once the voltage from the main capacitor reaches approximately 3 volts, the trigger pulse is adequate to activate the SCR. When the SCR is turned on, the stored energy in the main capacitor is released through a high-efficiency motor (HE-motor).
The PIC16F84 microcontroller is a versatile device that can be employed in various applications, including robotics and control systems. Its architecture supports a range of features, including digital I/O, timers, and analog-to-digital conversion, making it suitable for complex control tasks. For programming the PIC16F84/A, a programmer circuit is necessary, which typically includes a serial interface for communication with a computer, as well as necessary voltage regulation and signal conditioning components.
The solar engine schematic operates effectively by utilizing a solar cell to harness energy from sunlight. This energy is stored in a 4700µF capacitor, which serves as a reservoir of electrical energy. The UJT plays a critical role in regulating the discharge of this energy. Upon reaching a certain voltage threshold, the UJT oscillates, generating a pulse that triggers the SCR. The SCR, once activated, allows the stored energy to flow to the HE-motor, enabling it to perform work, such as propelling a robot.
The integration of the solar engine with the PIC16F84 microcontroller can enhance the functionality of BEAM-type robots. The microcontroller can be programmed to manage the charging and discharging cycles of the capacitor, optimizing performance and energy efficiency. Additionally, sensors can be incorporated to allow the robot to respond to environmental stimuli, further increasing its autonomy and adaptability.
In summary, the combination of the PIC16F84 microcontroller and the solar engine design presents a powerful solution for creating energy-efficient robotic systems. The schematic provides a clear framework for understanding the operation of the solar engine, while the microcontroller offers extensive programming capabilities to enhance robotic functionality.Discussion about application of microcontroler PIC16F84 both for Control or Robotics and How to make Programmer of Microcontroller PIC16F84/A. The solar engine is commonly used as an onboard power plant for BEAM-type robots. Sometime called living robots. The inspiration for this solar engine originated from Mr. Mark W. Tilden who originally designed a solar engine. Another innovator was Dave Hrynkiw from Canada. He modified the solar engine design to power a solar ball robot. Below figure is schematic for the solar engine. This design are take from book with title Robot, Android, and Animatron by Jhon Iovine. Here is how it works. The solar cell charges the main 4700uF Capacitor as a power banks. As the capacitor charges the voltage level of the circuit increase. The UJT ( Uni Junction Transistor ) begin oscillating and sending a trigger pulse to the SCR ( Silicon Controlled Rectifier ). When the circuit voltage has risen to about 3 Volt from the main capacitor, the trigger pulse is sufficient to turn on the SCR.
When SCR turn on, all the stored power in the main capacitor is dumped trough the high efficiency motor ( HE-motor ).
The PIC16F84 microcontroller is a versatile device that can be employed in various applications, including robotics and control systems. Its architecture supports a range of features, including digital I/O, timers, and analog-to-digital conversion, making it suitable for complex control tasks. For programming the PIC16F84/A, a programmer circuit is necessary, which typically includes a serial interface for communication with a computer, as well as necessary voltage regulation and signal conditioning components.
The solar engine schematic operates effectively by utilizing a solar cell to harness energy from sunlight. This energy is stored in a 4700µF capacitor, which serves as a reservoir of electrical energy. The UJT plays a critical role in regulating the discharge of this energy. Upon reaching a certain voltage threshold, the UJT oscillates, generating a pulse that triggers the SCR. The SCR, once activated, allows the stored energy to flow to the HE-motor, enabling it to perform work, such as propelling a robot.
The integration of the solar engine with the PIC16F84 microcontroller can enhance the functionality of BEAM-type robots. The microcontroller can be programmed to manage the charging and discharging cycles of the capacitor, optimizing performance and energy efficiency. Additionally, sensors can be incorporated to allow the robot to respond to environmental stimuli, further increasing its autonomy and adaptability.
In summary, the combination of the PIC16F84 microcontroller and the solar engine design presents a powerful solution for creating energy-efficient robotic systems. The schematic provides a clear framework for understanding the operation of the solar engine, while the microcontroller offers extensive programming capabilities to enhance robotic functionality.Discussion about application of microcontroler PIC16F84 both for Control or Robotics and How to make Programmer of Microcontroller PIC16F84/A. The solar engine is commonly used as an onboard power plant for BEAM-type robots. Sometime called living robots. The inspiration for this solar engine originated from Mr. Mark W. Tilden who originally designed a solar engine. Another innovator was Dave Hrynkiw from Canada. He modified the solar engine design to power a solar ball robot. Below figure is schematic for the solar engine. This design are take from book with title Robot, Android, and Animatron by Jhon Iovine. Here is how it works. The solar cell charges the main 4700uF Capacitor as a power banks. As the capacitor charges the voltage level of the circuit increase. The UJT ( Uni Junction Transistor ) begin oscillating and sending a trigger pulse to the SCR ( Silicon Controlled Rectifier ). When the circuit voltage has risen to about 3 Volt from the main capacitor, the trigger pulse is sufficient to turn on the SCR.
When SCR turn on, all the stored power in the main capacitor is dumped trough the high efficiency motor ( HE-motor ).
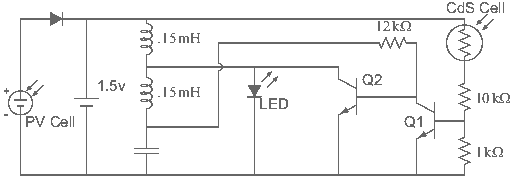
Solar Power walkway marker Led display
These are small lights with a stake on the bottom that can be inserted into the ground along driveways or sidewalks, featuring a solar panel on top. The solar cell charges a AA NiCd battery during the day, and at...
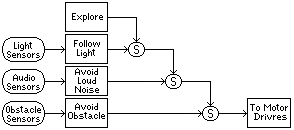
Subsumption Architecture
This term refers to a robotic control concept developed by Rodney Brooks, closely associated with behavior-based robotics, which incorporates modular behavior-based artificial intelligence. Unlike traditional artificial intelligence that relies on a centralized, top-down planning, execution, and monitoring structure, subsumption architecture...
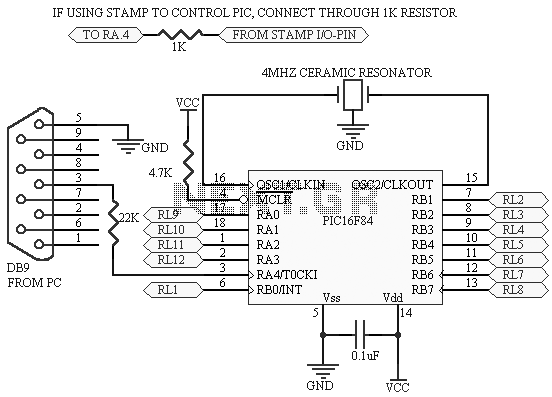
Using PicBasic with the PIC16F84 PIC Microcontroller
This project uses only a few of the instructions that come with PicBasic, but serves to show how easy PicBasic really is. It also shows how PicBasic strongly resembles programming the BASIC Stamp. Here we are using the serin command,...
Robotics Page
This is an attempt to create a simple and compact photovore. Although it may not be visually appealing, it serves as a good starting point for beginners. It is a personal version of the Dozer photovore. The latest robot built...
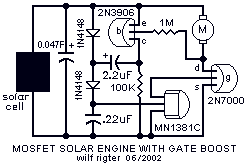
The GBSE (gate boost solar engine)
The Gate Boost SE uses a 1381, a 2N7000 MOSFET and a 2N3906 with a unique voltage doubler to increase the voltage applied to the gate of the MOSFET. Normally the 2.6V output of a 1381C is barely able to...
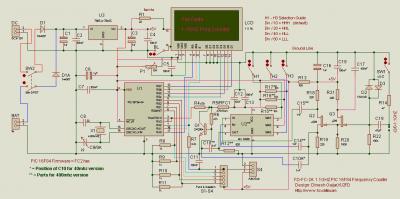
PIC16F84 IC For 40 MHZ/400 MHZ Frequency Counter
The following circuit illustrates a 40 MHz/400 MHz Frequency Counter Circuit Diagram. This circuit is based on the PIC16F84 IC. Features:
The frequency counter circuit operates within the range of 40 MHz to 400 MHz, utilizing the PIC16F84 microcontroller as...
Rotating Sprocket Wheel Generator
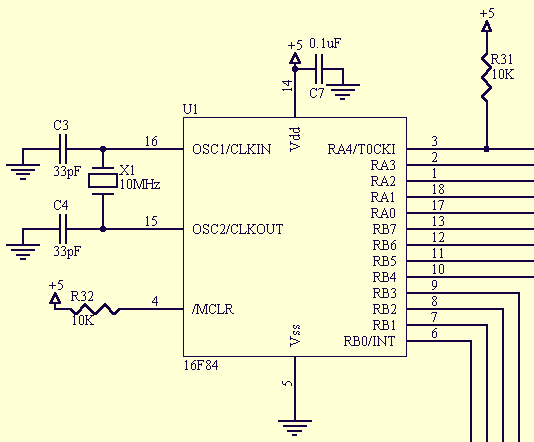
The 16F84 has 13 outputs. All 13 can serve as inputs, but only 12 are normal outputs, one is an open-drain. An open-drain output has no active pull up - you have to provide an external (passive) pull up. Since...
USB PICKit2 programmer
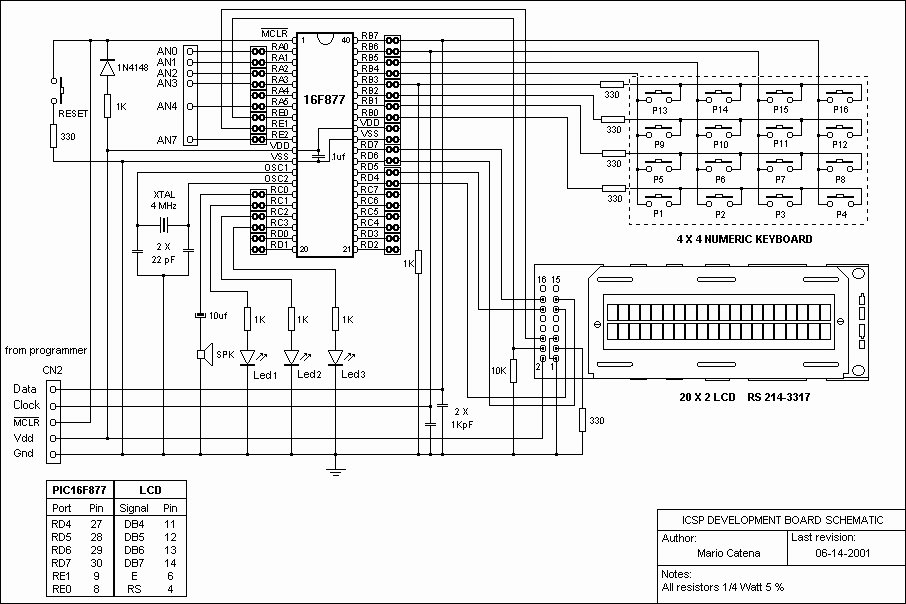
A schematic of a board featuring the PIC16F84 microcontroller, along with other compatible PIC microcontrollers that can be connected to the USB PICKit2 programmer. Additionally, there are concerns regarding the potential damage to the programmer when experimenting with oscillator frequencies...
solar robot
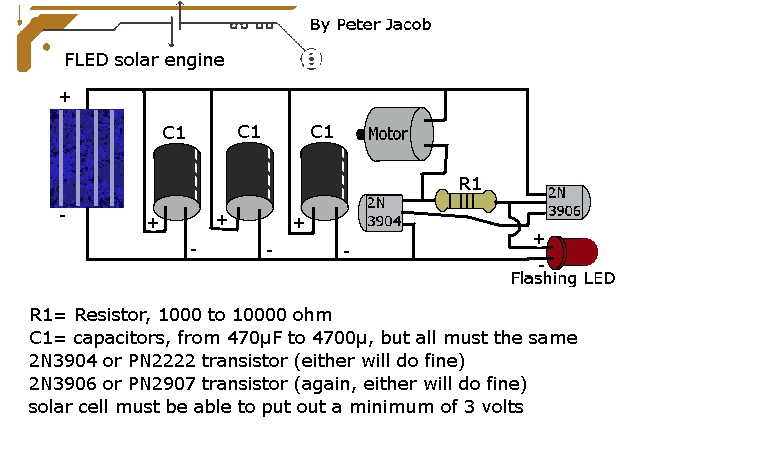
This document outlines the construction of a trimet. The required components include three capacitors, a 2N3904 transistor, a 2N3906 transistor, a resistor with a value between 1k to 10k ohms, and a solar cell with a minimum voltage of 3...