


avr How to redesign a circuit to use a current sinking IC rather than a current sourcing IC
#AVR
#servo controller
#PWM
#demultiplexer
#ATTiny2313
#assembly language
#I/O expansion
#hexapod robot
#CD74HCT238E
#current sinking
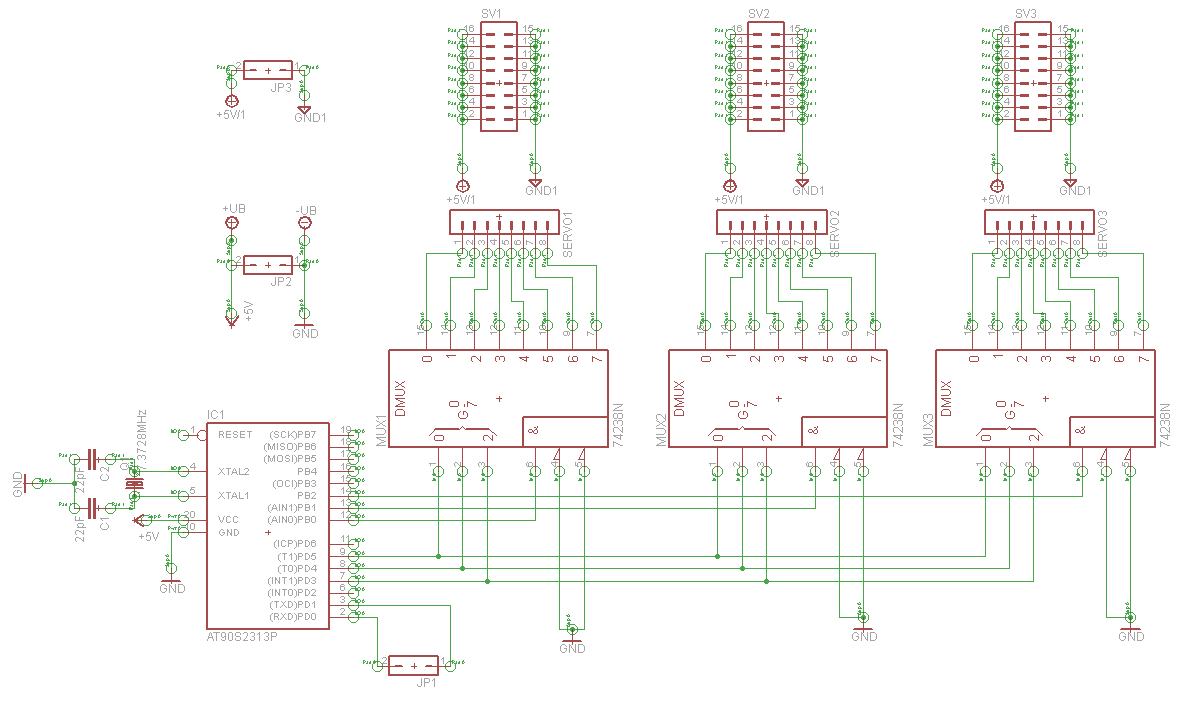
Description: A serial servo controller is being developed to enhance knowledge of electronics and assembly language as part of a hexapod robot project. Initially, the ATTiny2313 microcontroller was utilized; however, it became evident that additional I/O channels were necessary. Consequently, 3-8 line demultiplexer chips (CD74HCT238E) were explored, enabling the creation of a 64-channel PWM servo controller with only 8 I/O pins dedicated to PWM channels and 3 address lines. Additionally, CD74HCT138E chips, which are active low, were acquired. Although the fundamental differences between current sourcing chips and current sinking chips are understood, there is uncertainty regarding the necessary adjustments to the circuit to incorporate current sinking chips. This inquiry arises from the accidental purchase of active low integrated circuits, and there is curiosity about the potential complexity involved in modifying the schematic and circuit design to utilize them.
The design of a serial servo controller utilizing 3-8 line demultiplexers, such as the CD74HCT238E, allows for efficient control of multiple PWM signals with minimal I/O pin usage. The CD74HCT238E operates as a high-active demultiplexer, routing incoming signals from the microcontroller to the designated output channels based on the binary address provided. This enables the control of up to 64 servo motors using only 8 pins for the PWM signals and 3 pins for address selection.
In contrast, the CD74HCT138E serves as an active low demultiplexer, which presents a different operational characteristic. When integrating the CD74HCT138E into the circuit, the logic levels must be inverted; this requires adjustments to the circuit design to accommodate the active low configuration. The main difference lies in the way the outputs are activated. With the CD74HCT238E, a high signal on the address lines activates the corresponding output, while the CD74HCT138E requires a low signal for activation.
To successfully transition from the CD74HCT238E to the CD74HCT138E, the schematic must be modified to account for the active low nature of the latter. This involves altering the logic levels in the control signals and potentially introducing additional components, such as pull-up resistors, to ensure that the outputs remain in a defined state when not actively driven low. The complexity of the new design will depend on the existing circuit configuration and how the signals are currently routed.
In summary, while the transition from a current sourcing chip to a current sinking chip introduces additional considerations, it is feasible with careful planning and schematic adjustments. The resulting circuit will maintain the ability to control multiple servo motors while utilizing the active low characteristics of the CD74HCT138E.Building a serial servo controller to learn about electronics and assembly language as part of my hexapod robot project. Quite early on I decided that I needed more I/O channels than my ATTiny2313 that I was using at the time supported so I investigated some 3-8 line demultiplexer chips ( CD74HCT238E `s) which have allowed me to create a 64 channel PWM servo controller with just 8 I/O pins for the PWM channels and 3 address
lines. Anyway. I also bought some CD74HCT138E `s which are active low rather than the active high CD74HCT238E`s. I understand, in principal, the differences between the current sourcing chip that I`m using and the current sinking chips but I don`t really know how to adjust my circuit to use the current sinking chips instead of the current sourcing chips. Note that the reason for asking this question is that I bought a tube of the active low ICs by mistake and I`m curious at how much more complex the schematic and circuit design would need to be for me to make use of them.
The design of a serial servo controller utilizing 3-8 line demultiplexers, such as the CD74HCT238E, allows for efficient control of multiple PWM signals with minimal I/O pin usage. The CD74HCT238E operates as a high-active demultiplexer, routing incoming signals from the microcontroller to the designated output channels based on the binary address provided. This enables the control of up to 64 servo motors using only 8 pins for the PWM signals and 3 pins for address selection.
In contrast, the CD74HCT138E serves as an active low demultiplexer, which presents a different operational characteristic. When integrating the CD74HCT138E into the circuit, the logic levels must be inverted; this requires adjustments to the circuit design to accommodate the active low configuration. The main difference lies in the way the outputs are activated. With the CD74HCT238E, a high signal on the address lines activates the corresponding output, while the CD74HCT138E requires a low signal for activation.
To successfully transition from the CD74HCT238E to the CD74HCT138E, the schematic must be modified to account for the active low nature of the latter. This involves altering the logic levels in the control signals and potentially introducing additional components, such as pull-up resistors, to ensure that the outputs remain in a defined state when not actively driven low. The complexity of the new design will depend on the existing circuit configuration and how the signals are currently routed.
In summary, while the transition from a current sourcing chip to a current sinking chip introduces additional considerations, it is feasible with careful planning and schematic adjustments. The resulting circuit will maintain the ability to control multiple servo motors while utilizing the active low characteristics of the CD74HCT138E.Building a serial servo controller to learn about electronics and assembly language as part of my hexapod robot project. Quite early on I decided that I needed more I/O channels than my ATTiny2313 that I was using at the time supported so I investigated some 3-8 line demultiplexer chips ( CD74HCT238E `s) which have allowed me to create a 64 channel PWM servo controller with just 8 I/O pins for the PWM channels and 3 address
lines. Anyway. I also bought some CD74HCT138E `s which are active low rather than the active high CD74HCT238E`s. I understand, in principal, the differences between the current sourcing chip that I`m using and the current sinking chips but I don`t really know how to adjust my circuit to use the current sinking chips instead of the current sourcing chips. Note that the reason for asking this question is that I bought a tube of the active low ICs by mistake and I`m curious at how much more complex the schematic and circuit design would need to be for me to make use of them.
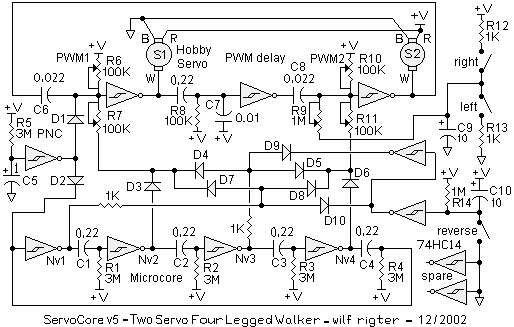
Servocore 2-motor walker circuit
There is an advantage in using continuously active PWM signals. The main reason is that the asynchronous frequencies of the PWM core and microcore can sometimes result in a shortened PWM pulse. The servo recognizes this as a command for...
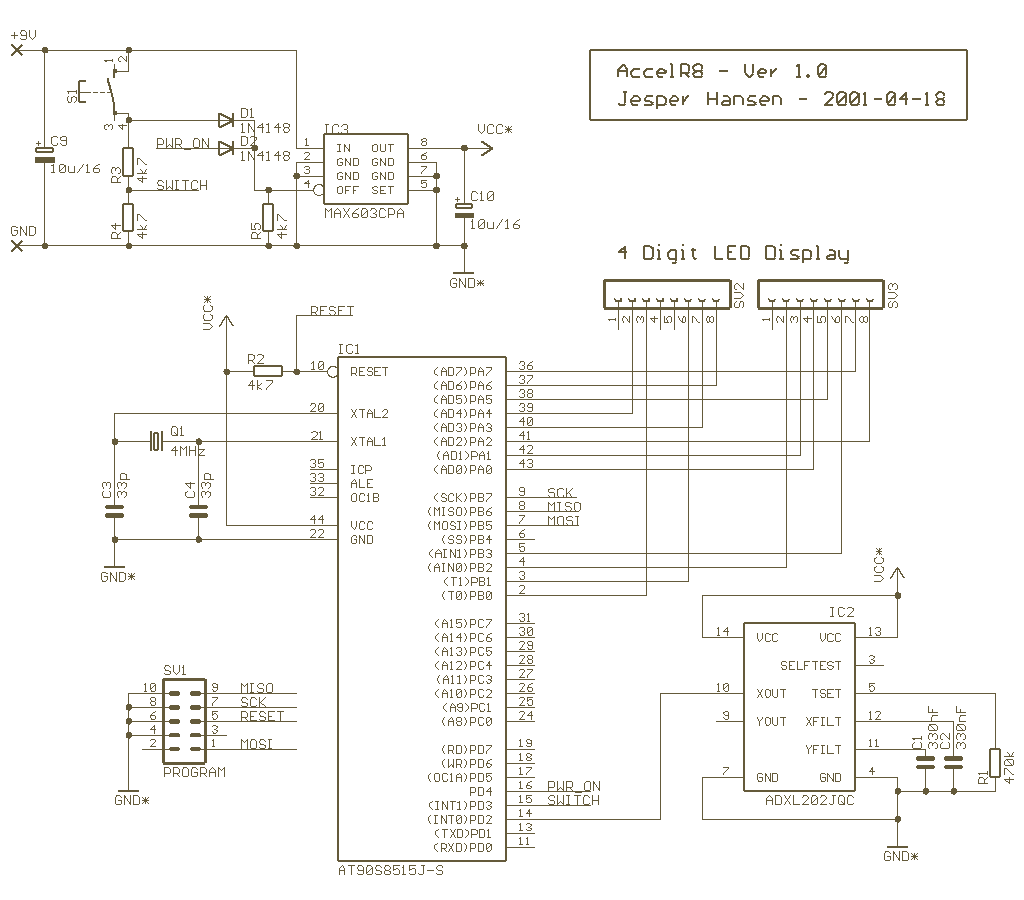
AccelR8
The schematic shows that the AccelR8 only uses 3 ICs. An AVR 8515 microcontroller does the calculation work and controls the other circuits. A MAX603 controls voltage and power-on/power-off. And the chip that makes it all possible, the ADXL202 from...
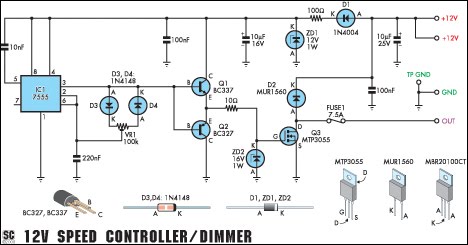
12V Speed Controller/Dimmer
This circuit serves as a speed controller for a 12V motor with a continuous rating of up to 5A or as a dimmer for a 12V halogen or standard incandescent lamp rated up to 50W. It regulates power to the...
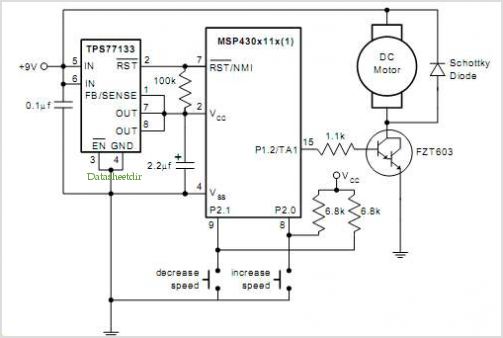
Pwm Dc Motor Control Using Timer A Of The Msp430
The QAMI5516 is an integrated demodulator and decoder solution designed for digital cable receivers, capable of handling compressed video, audio, and data services. This QAM demodulator executes intermediate frequency (IF) to MPEG-2 block processing of QAM carriers. The resulting demodulated...
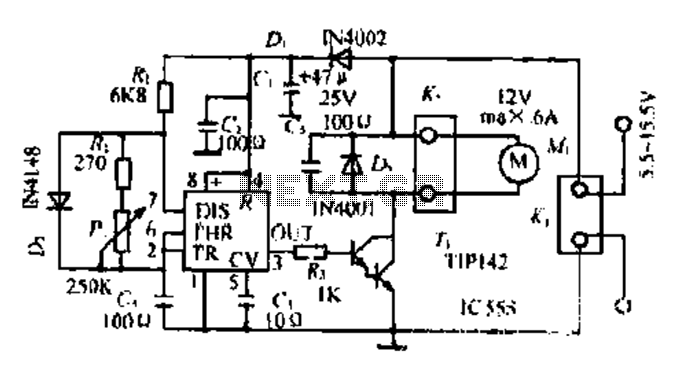
A DC motor PWM speed control circuit
Most governors utilize pulse width modulation (PWM) and pulse position modulation (PPM) in their circuits. The 555 timer is commonly used in these applications. The pulse width is typically fixed at 0.5 milliseconds, which is essential for the functioning of...
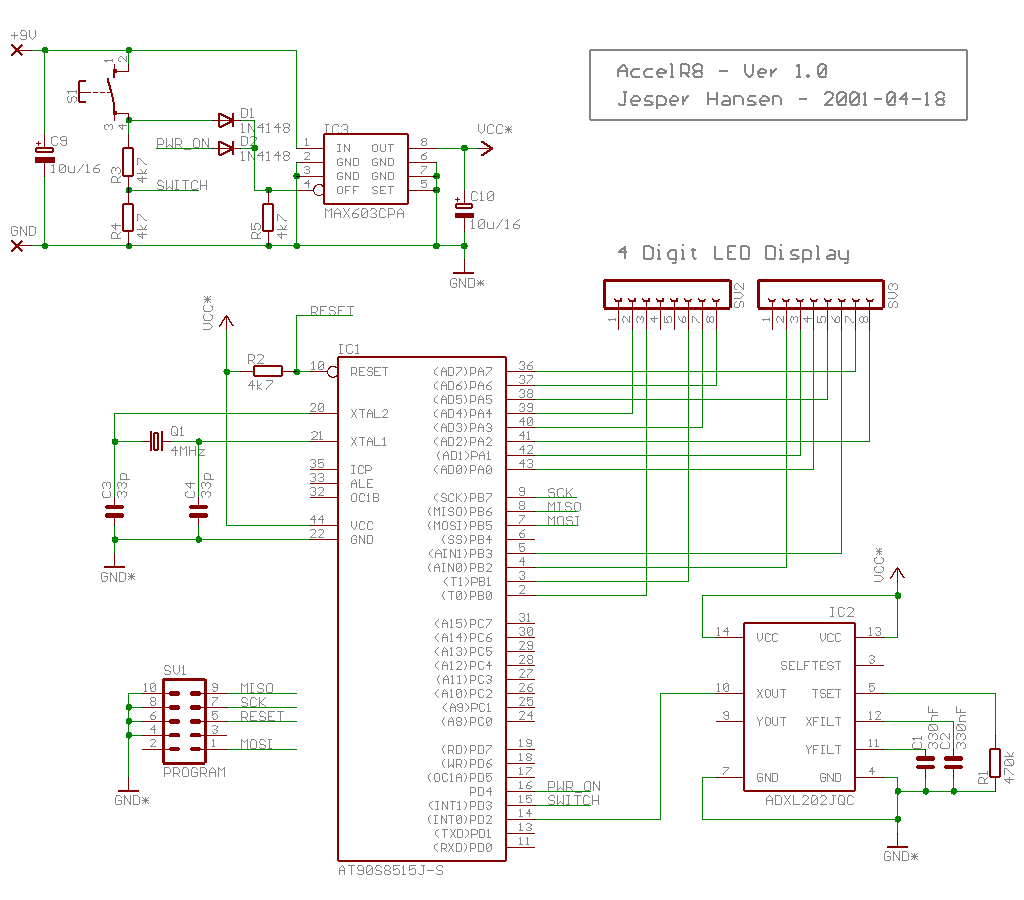
Acceleration Monitor using ADXL202 and AVR
The schematic indicates that the AccelR8 utilizes only three integrated circuits (ICs). An AVR 8515 microcontroller performs the computational tasks and manages the other circuits. A MAX603 regulates voltage and controls the power-on and power-off functions. The key component enabling...
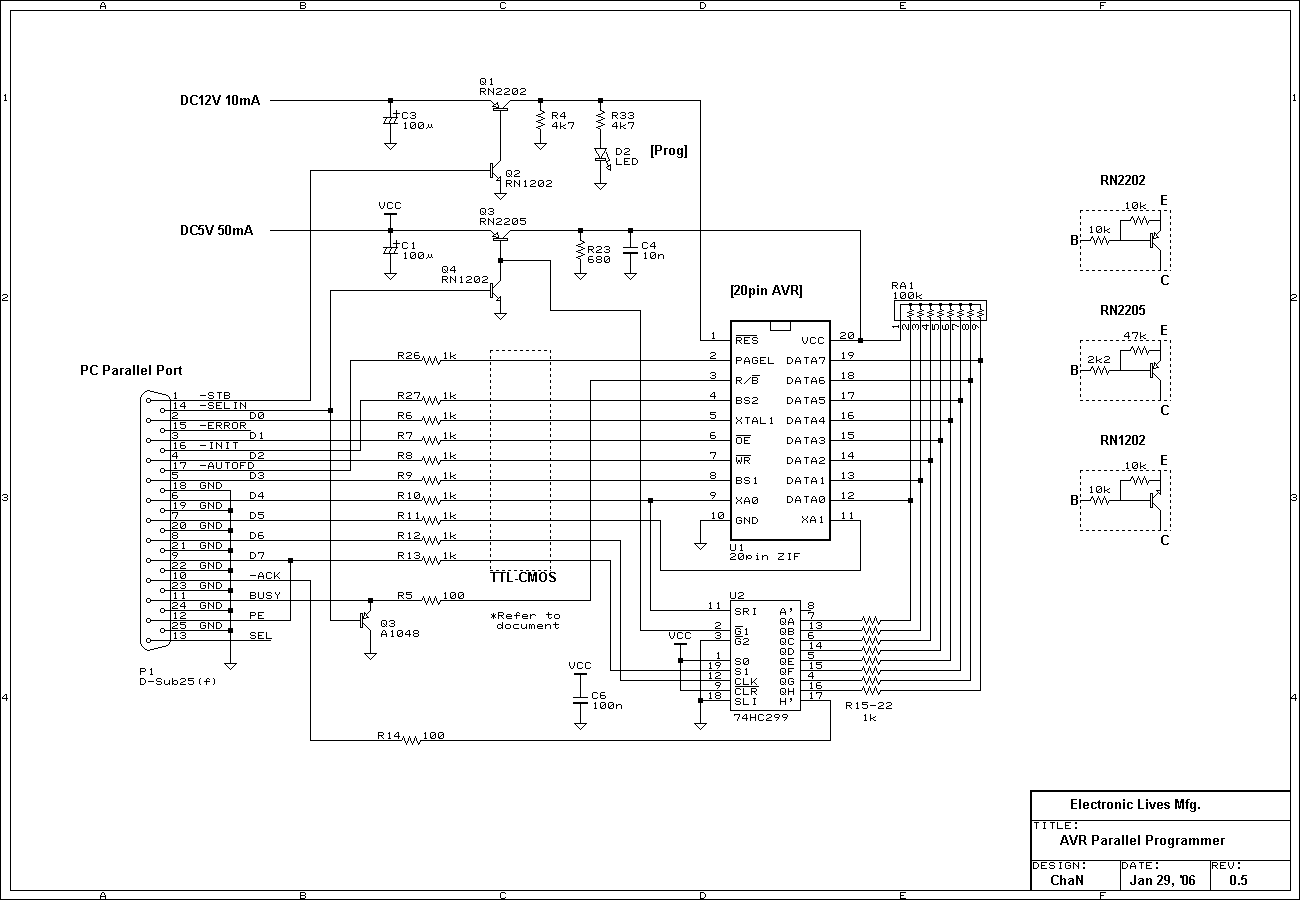
high voltage parallel programmer avr
AVR has two different programming modes called Parallel Programming Mode (Parallel Mode) and Serial Downloading Mode (ISP mode). In Parallel Mode, the programming is done using multiple data lines simultaneously, allowing for faster programming speeds. This mode is typically used...
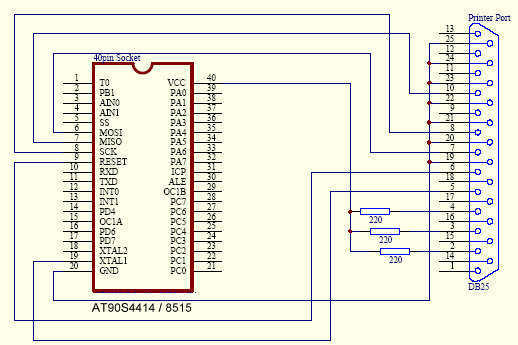
AVR programmer
To program some AVR microcontroller unit (MCU) you will need an AVR programmer. The better way to do that is to buy some development kit like STK-500. This kit has the advantage to give you serial port, LCD connector, SRAM...
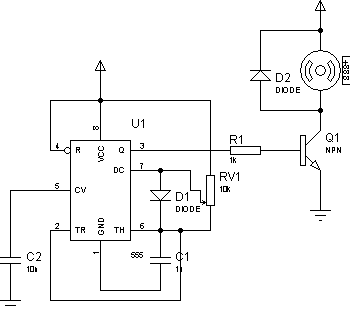
Control motor PWM schematic
There are two primary methods to control the speed of a DC motor: by varying the supply voltage and through pulse width modulation (PWM). The first method is less convenient, particularly in digital systems, as it necessitates the use of...