


magnetics application schematics
#current measurement
#op-amp
#sensor calibration
#AC/DC
#feedback resistor
#bandwidth limitation
#voltage output
#conductor current
#displacement measurement
#sensor circuit
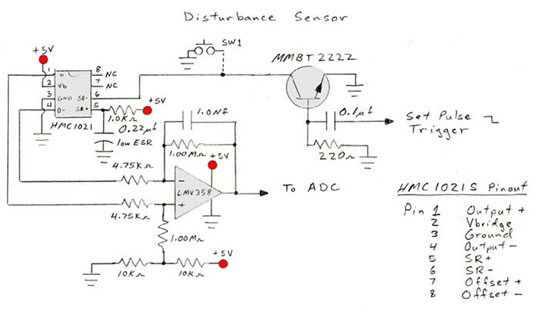
Description: Calibrate the measurement circuit by applying a known current to the conductor and measuring the resulting voltage output. If the displacement between the sensor and conductor changes, recalibration is necessary. This sensor circuit is capable of measuring both DC and AC currents within the bandwidth of the operational amplifier. Additional bandwidth limitations can be achieved by placing a capacitor in parallel with the 475k-ohm feedback resistor. Other power supplies may be utilized with this circuit, provided the selected operational amplifier is compatible. The 1N4148 diode can be omitted if reverse polarity protection is not required. This circuit is suitable for laptops, portable devices, and similar applications for detecting changes in position, such as rotational movement. The HMC1021S sensor should be mounted on a horizontal circuit board in a magnetically clean environment. It is recommended to use 10-bit or higher ADCs for optimal resolution. The software should accommodate slow value drifts but should trigger alerts for sudden changes in multiple ADC counts. Gradiometers serve as fundamental magnetic anomaly detectors, often employed in metal detection applications. The near sensor acts as a reference while the far sensor probes for metal presence, with differences indicated on the meter. This circuit is optimized for voltage operation, utilizing the HMC1052 AMR sensor with a battery supply range of 1.8 to 3.6 volts. To extend battery life, the sensor and amplifier supplies (VDDSW) can be powered down when not actively measuring magnetic axes. The set/reset MOSFETs can remain powered without drawing current unless the gate logic is toggled. The specific types of operational amplifiers and MOSFETs are not defined, allowing for sourcing from various vendors. MOSFETs should have Rds(on) ratings of 0.4 ohms or lower per FET. All components should be selected for low voltage compatibility. The placement of the HMC1052 must allow for adequate spacing from other surface-mount technology (SMT) components and ferrous metals to ensure optimal performance. The accuracy of the compass is primarily determined by the processor's ADC resolution and the firmware used to compute the heading, typically achieving an accuracy of +/- 3 degrees or better. Substitution of 3-axis accelerometers, ADCs, and magnetic sensors is permissible based on brand preferences, cost considerations, and layout requirements. The host controller may feature onboard ADC channels to reduce chip count and costs. A compact layout is advised to minimize the need for additional supply decoupling capacitors. A 10µF reservoir capacitor is recommended if the power supply (battery or regulator) is located more than 2 inches away.
This measurement circuit is designed to accurately detect and measure magnetic fields and changes in position using advanced sensor technology. The calibration process is crucial for ensuring the accuracy of the measurements, particularly when environmental factors may alter the sensor's position relative to the conductor. The dual capability of measuring both DC and AC currents broadens the application potential of this circuit, making it suitable for various electronic devices.
The choice of operational amplifiers and MOSFETs plays a significant role in the performance and efficiency of the circuit. It is essential to select components that are compatible with low voltage operations, as this is critical for battery-powered applications. The recommendation for MOSFETs with low on-resistance (Rds(on)) ensures minimal power loss and heat generation during operation, which is vital for maintaining the longevity of portable devices.
Furthermore, the integration of a high-resolution ADC enhances the circuit's ability to detect minute changes in magnetic fields, which is essential for applications such as metal detection. The firmware's capability to handle slow drifts while responding to sudden changes ensures reliable operation in dynamic environments.
The design considerations regarding the placement of the HMC1052 sensor highlight the importance of minimizing interference from nearby components, particularly those that may generate magnetic fields. This attention to detail is crucial for achieving the desired accuracy and performance of the circuit.
Overall, this circuit represents a sophisticated approach to magnetic field measurement and position detection, incorporating best practices in electronic design to ensure reliability and effectiveness in practical applications.Calibrate the measurement circuit by forcing a known conductor current and measuring the resulting voltage output. If sensor to conductor displacement changes, recalibrate This sensor circuit can measure DC and AC currents to the bandwidth of the op-amp.
Additional bandwidth limitation can be had by placing capacitance across the 475k-ohm feedback resistor. Other power supplies can be used with this circuit if the selected op-amp can operate. Note that the 1N4148 diode can be removed if reverse polarity protection is un-needed. Simple circuit for laptop computers, portable devices, etc. for detecting change in location (i. e. rotational movement). The HMC1021S is placed on a horizontal circuit board in a magnetically clean area. 10-bit to higher ADC`s recommended for best resolution. Software should allow for slow drifts in value, but trigger for disturbances if sudden value changes in many ADC counts. Gradiometers are basic magnetic anomaly detectors, commonly used for metal detection. The near sensor is the reference in which the far sensor is used to probe for metals. Differences show up in the meter. This circuit is optimized for voltage operation and using the HMC1052 AMR sensor in the 1. 8 to 3. 6 volt battery supply. To conserve battery life, you can power off the sensor and amplifier supplies (VDDSW) when not measuring the magnetic axes.
The set/reset MOSFETs can remain powered and will not draw current unless the gate logic toggles. The op-amp and MOSFET types are not specified to allow sourcing from multiple vendors. MOSFETs should have Rds(on) ratings of 0. 4 ohms or lower per FET. All parts should be chosen for low voltage compatibility. Placement of the HMC1052 must permit a standoff from other SMT parts and ferrous metals for best performance. Compass accuracy is set primarily by processor ADC resolution and firmware to compute heading. Typically, +/- 3 degree accuracy or better can be obtained. Substitution of 3-Axis Accel, ADC, and magnetic sensors can be permitted for brand preferences, cost concerns, and layout.
Host controller may have onboard ADC channels to further minimize chip count and costs. Keep the layout tight to minimize extra supply decoupling capacitors. A 10uf reservoir capacitor is recommended if supply (battery, regulator) is more than 2 inches away
This measurement circuit is designed to accurately detect and measure magnetic fields and changes in position using advanced sensor technology. The calibration process is crucial for ensuring the accuracy of the measurements, particularly when environmental factors may alter the sensor's position relative to the conductor. The dual capability of measuring both DC and AC currents broadens the application potential of this circuit, making it suitable for various electronic devices.
The choice of operational amplifiers and MOSFETs plays a significant role in the performance and efficiency of the circuit. It is essential to select components that are compatible with low voltage operations, as this is critical for battery-powered applications. The recommendation for MOSFETs with low on-resistance (Rds(on)) ensures minimal power loss and heat generation during operation, which is vital for maintaining the longevity of portable devices.
Furthermore, the integration of a high-resolution ADC enhances the circuit's ability to detect minute changes in magnetic fields, which is essential for applications such as metal detection. The firmware's capability to handle slow drifts while responding to sudden changes ensures reliable operation in dynamic environments.
The design considerations regarding the placement of the HMC1052 sensor highlight the importance of minimizing interference from nearby components, particularly those that may generate magnetic fields. This attention to detail is crucial for achieving the desired accuracy and performance of the circuit.
Overall, this circuit represents a sophisticated approach to magnetic field measurement and position detection, incorporating best practices in electronic design to ensure reliability and effectiveness in practical applications.Calibrate the measurement circuit by forcing a known conductor current and measuring the resulting voltage output. If sensor to conductor displacement changes, recalibrate This sensor circuit can measure DC and AC currents to the bandwidth of the op-amp.
Additional bandwidth limitation can be had by placing capacitance across the 475k-ohm feedback resistor. Other power supplies can be used with this circuit if the selected op-amp can operate. Note that the 1N4148 diode can be removed if reverse polarity protection is un-needed. Simple circuit for laptop computers, portable devices, etc. for detecting change in location (i. e. rotational movement). The HMC1021S is placed on a horizontal circuit board in a magnetically clean area. 10-bit to higher ADC`s recommended for best resolution. Software should allow for slow drifts in value, but trigger for disturbances if sudden value changes in many ADC counts. Gradiometers are basic magnetic anomaly detectors, commonly used for metal detection. The near sensor is the reference in which the far sensor is used to probe for metals. Differences show up in the meter. This circuit is optimized for voltage operation and using the HMC1052 AMR sensor in the 1. 8 to 3. 6 volt battery supply. To conserve battery life, you can power off the sensor and amplifier supplies (VDDSW) when not measuring the magnetic axes.
The set/reset MOSFETs can remain powered and will not draw current unless the gate logic toggles. The op-amp and MOSFET types are not specified to allow sourcing from multiple vendors. MOSFETs should have Rds(on) ratings of 0. 4 ohms or lower per FET. All parts should be chosen for low voltage compatibility. Placement of the HMC1052 must permit a standoff from other SMT parts and ferrous metals for best performance. Compass accuracy is set primarily by processor ADC resolution and firmware to compute heading. Typically, +/- 3 degree accuracy or better can be obtained. Substitution of 3-Axis Accel, ADC, and magnetic sensors can be permitted for brand preferences, cost concerns, and layout.
Host controller may have onboard ADC channels to further minimize chip count and costs. Keep the layout tight to minimize extra supply decoupling capacitors. A 10uf reservoir capacitor is recommended if supply (battery, regulator) is more than 2 inches away

op amp Amplifying signal from CO2 Sensor
Amplify a MG811 CO2 sensor to a range readable by an ATMEGA2560 (0-5V). Other analog sensors are in use, so it is preferred not to change the reference voltage on the ATmega. A module that scales the signal has been...
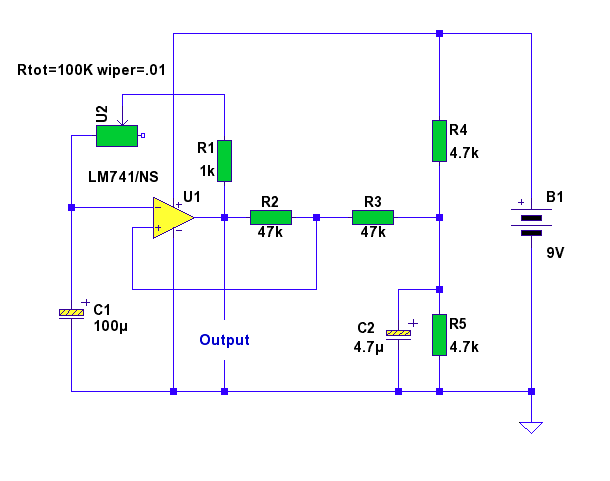
741 Astable Timer
In this circuit, a standard operational amplifier (op-amp) is configured as an astable multivibrator. The output is non-symmetrical, but it has the advantage of being controlled by only one resistor and one capacitor: a 100k variable resistor (U2) and a...
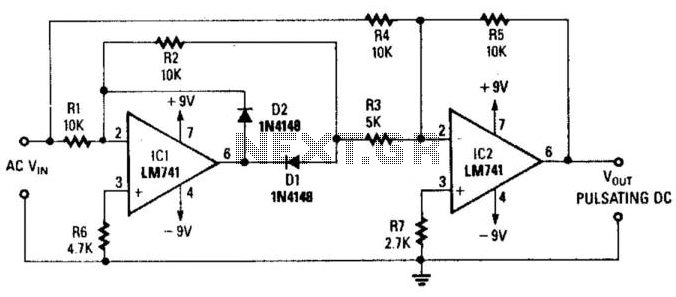
Precision Full-Wave Rectifier
This circuit utilizes two operational amplifiers (op amps) to generate a full-wave rectified version of the input signal. Op amp IC1 inverts the negative-going signal, but due to diode D2, it remains close to zero. IC2 generates a positive-going signal....
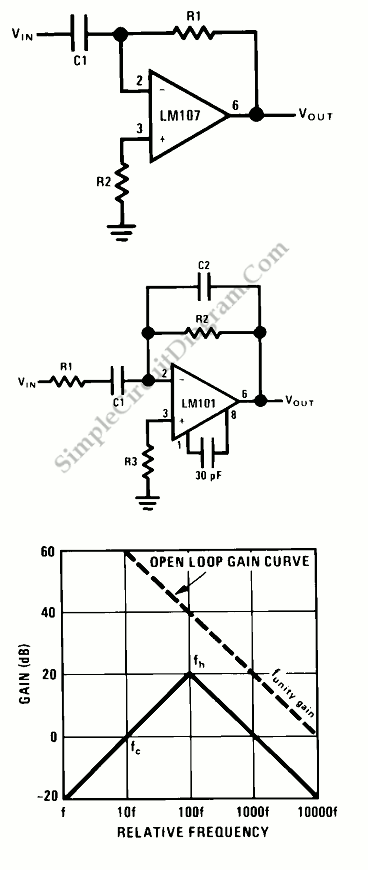
Op-Amp Circuit: Differentiator
This is a differentiator circuit. This circuit can be used to perform differential operations. There are two types of differentiators: the true differentiator and another type.
A differentiator circuit is designed to output a voltage that is proportional to the rate...
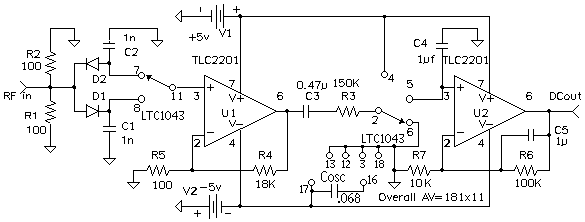
Amplifying DC Diode Detector Output
The small DC voltages at the output of the diode detector are challenging to amplify accurately due to DC offsets introduced by any operational amplifier (op-amp) and low-frequency noise (1/f noise). A solution to these issues is to chop the...
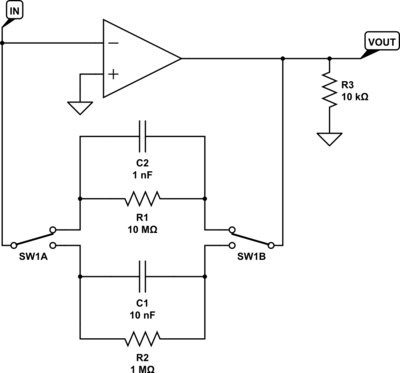
op amp Why do some of my IE converter circuits have a large offset voltage
The inverting input is maintained at a low level via a 10K resistor when the circuit is powered on but not in use. During measurement activities, including calibration measurements where the input is floating, this resistor is disconnected. The circuit...
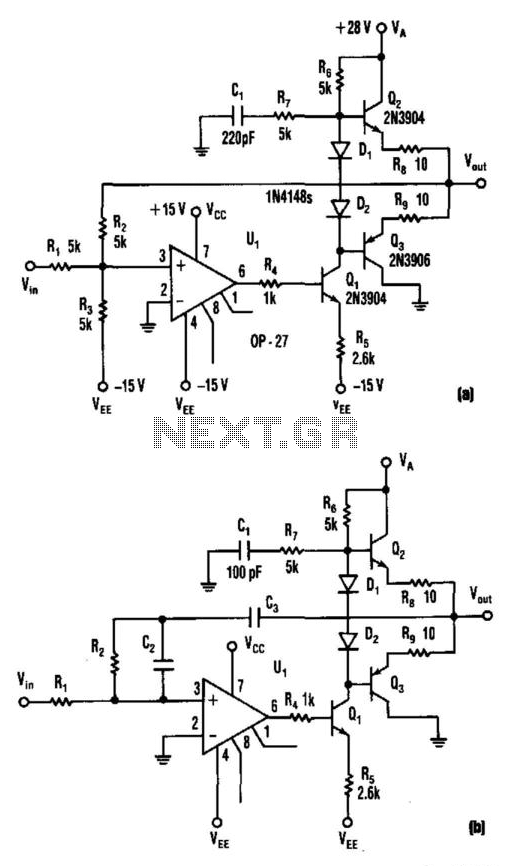
Compound Op Amp Vco Driver
This circuit produces a 5 to 25 V output to drive a voltage-controlled oscillator (VCO) from a standard ±15 V supply system. Resistor R7 and capacitor C1 provide frequency compensation. Transistors Q1 through Q3 form an inverting amplifier with a...
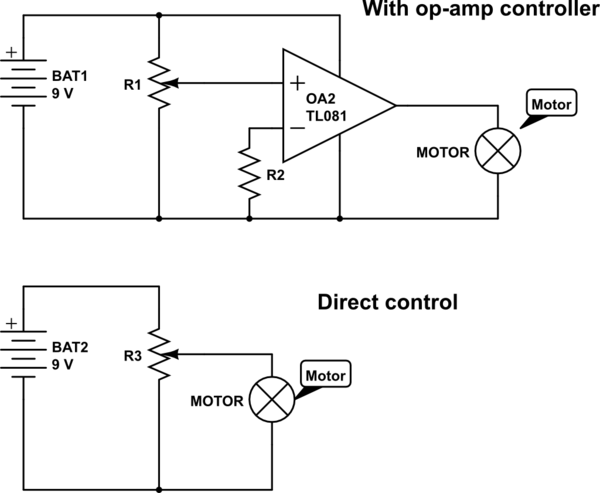
op amp op-amp vs direct control
A 100 Ohm resistor connected to a 4.5 Volt supply (using three AA batteries) allows a current of 45 mA. However, at the upper end of the current sweep, the effective current will be significantly higher due to the load...
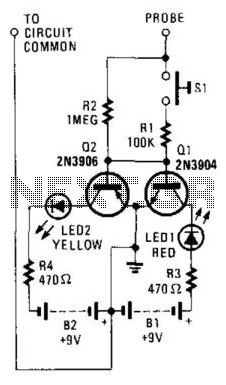
Ac/Dc Indicator
This circuit utilizes two switching transistors and two LEDs to differentiate between low-level AC and DC signals. A lit red LED indicates a positive DC signal, while a lit yellow LED signifies a negative DC signal. If the input signal...