
Automated Pet Door
#pet door
#automation
#prototype
#polymer
#two-way operation
#one-way operation
#sensor
#motor control
#arduino
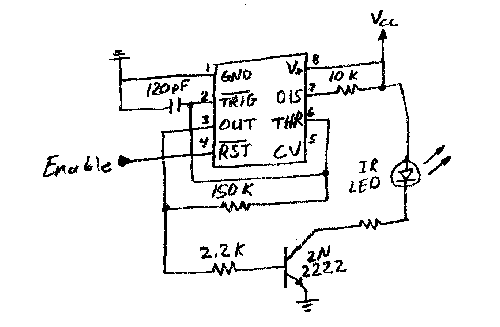
Description: This week has been productive for the pet door project, culminating in a fully functional prototype. The door is made from a high-tech polymer, facilitating an efficient prototyping process for the door mechanism. It features two-way operation, with an option for one-way functionality. A sensor is integrated to detect if a pet is still in the doorway before closing, and it will reopen if an obstruction is detected. The sensor utilizes an infrared beam positioned in the door's plane, ensuring the door does not strike the pet. Although a contact sensor could enhance safety, the current setup uses basic DC voltage for sensor operation. This approach is affected by ambient lighting, leading to potential false alarms. To mitigate this, the infrared signal should be modulated at approximately 10 kHz, avoiding interference with the main infrared system operating at 40 kHz. Time constraints may prevent the implementation of this additional circuitry. Efforts are also directed towards minimizing the size of the pet's collar device, particularly by finding a compact battery that offers reasonable endurance, with a promising candidate being a 6-volt lithium battery commonly used in cameras. The project utilizes a Motorola controller, currently configured with four inputs and seven outputs, all representing simple logic signals (0 or 1). Progress is being made with limit switches for motor control of the door, alongside LED indicators to simulate the door's status and the pet's position. Simple toggle switches have been added to control the IR transmitters and main power. A challenge arose when the collar's signal transmission caused the output LED to activate only briefly. This was traced to the collar system's incompatibility with 9 volts, prompting a switch to 5 volts, which resolved the issue. The team is also considering motor options, as the current motor draws excessive current. A test program has been developed to interface the microprocessor with the pet detection system, receiving inputs from the RF receiver and signaling via a green LED. Initial attempts to power the RF receiver from the processor led to resets due to excessive current draw; therefore, a direct voltage source is now used. Integration of the infrared transmitter and receiver into the program is underway, and preparations for the automatic pet door report and poster board are commencing.
The automated pet door operates on a sophisticated mechanism designed to enhance pet accessibility while ensuring safety. The core of the system is built around a high-tech polymer door that is lightweight yet durable, allowing for rapid prototyping and testing. The two-way operational capability ensures that pets can enter and exit freely, while the option for one-way operation can be utilized in specific scenarios, providing flexibility for pet owners.
The safety features of the door are paramount. The infrared sensor, positioned in the door's plane, continuously monitors the area for pets or obstructions. This design prevents accidental closure on pets, leveraging the infrared beam to detect any presence in the doorway. The proposed modulation of the infrared signal at 10 kHz serves to eliminate interference with the main system operating at 40 kHz, enhancing reliability and performance. The implementation of a contact sensor could further improve safety, although it may not be prioritized due to time constraints.
Power management is a critical aspect of the design, with the system powered by a basic DC voltage. The choice of a 6-volt lithium battery is advantageous due to its compact size and adequate endurance, making it suitable for the collar device. The integration of limit switches to control the motor's operation for opening and closing the door ensures precise movement, while LED indicators provide real-time feedback on the door's status.
The microcontroller, a Motorola unit, plays a vital role in processing inputs from the RF receiver and controlling the output signals. The current configuration allows for efficient management of inputs and outputs, facilitating seamless communication between the collar and the door mechanism. The transition to a 5-volt power supply for the RF receiver has resolved previous issues with signal transmission, thus enhancing system stability.
In conclusion, the automated pet door project demonstrates significant advancements in design and functionality, with ongoing refinements aimed at optimizing performance and safety. The integration of various components, including sensors, power management systems, and control logic, showcases a comprehensive approach to creating a reliable and user-friendly pet access solution.This has been a fine week for the pet door. We actually have a fully functional prototype! The door itself is constructed of a high-tech polymer which is easy to work with and provided a quick means of prototyping the door mechanism. (Read: Legos) The door has the two wayoperation desired, with the ability to select one-way operation.
It has a sensor to determine if the pet is still in the door before it is closed. This also will reopen the door if something gets in the way while it is closing. The sensor used to monitor the door opening is an infrared beam which is in the plane of the door. This means that the door will never strike the pet. A contact sensor would also be beneficial just to make sure everything is okay, however. In order to get the sensor installed as soon as possible it is just powered by a basic DC voltage. The problem with this is that the ambient lighting has an affect on sensor performance and can cause false alarms. To get around this the IR should be modulated at a frequency of around 10 kHz. This frequency would prevent any cross-talk with the main IR system which is running at 40 kHz. It is yet to be seen if we will have enough time to implement this extra circuitry. Since it is functional as is, we probably won`t bother with it. Something else that could be done is to try to reduce the bulk of the pet`s collar device. The primary thing is to find a suitable battery which is compact and will still give reasonable endurance.
One battery that looks promising is the 6 volt Lithium type used in many cameras. It then could be packaged appropriately. We are making good use of the Motorola controller. Our system in its current configuration has four inputs and seven outputs, all simple logic signals (0 or 1). We are looking forward to seeing the other group projects as they get up and running also. It is a good feeling to see a year`s worth of time and effort come to fruition. April 4, 1997 Paul Potts Darrell Rounds Michael Sprague This week we have decided to use limit switches to control the motor opening and closing the door.
We have set up different LED`s to simulate whether the door is opening or closing and which side of the door the pet is on. Also, we have integrated the limit switches to the system to simulate the opening and closing the pet door.
Currently, we are implementing simple toggle switches to turn on and off the IR transmitters and the main power. There was one problem with the system, each time the collar transmitted a signal to the door our output LED would turn on for about 5 seconds and cut off.
The system was designed to keep the LED on when the RF receiver received. The solution to the problem was simple the collar system did not like the 9 volts so it would not transmit the signal continuously, so we change the voltage to 5 volts which worked out well. There is another problem we are having a little trouble figuring out what kind of motor to use. The motor we have currently draws to much current. If anyone has any suggestions we would gladly consider them. Automated Pet Door March 28, 1997 Paul Potts Darrell Rounds Michael Sprague This week we have a test program that interfaces the microprocessor to the pet detection system.
The test program recieves input from the RF reciever and uses an green led output the signal. We tried to pull a voltage from the processor to power the RF receiver, but each time we tried to test the signal the processor reset itself. The RF reciever was drawing too much current from the microprocessor, therefore it reset itself. Now we have the voltage coming directly from voltage source. At this point we are in the process of incorporating the IR transmitter and reciever into the program.
Also now that the first of April is next week, we have to start writing the automatic pet door report and planning the poster board
arduino How can I display a scoreboard on stage for a play
A scoreboard is located in the center of the room, which will be controlled from backstage. The scoreboard features two individual 3-digit numbers. Whenever the score changes, a sound will be emitted. The simplest, most efficient, and cost-effective solution identified...
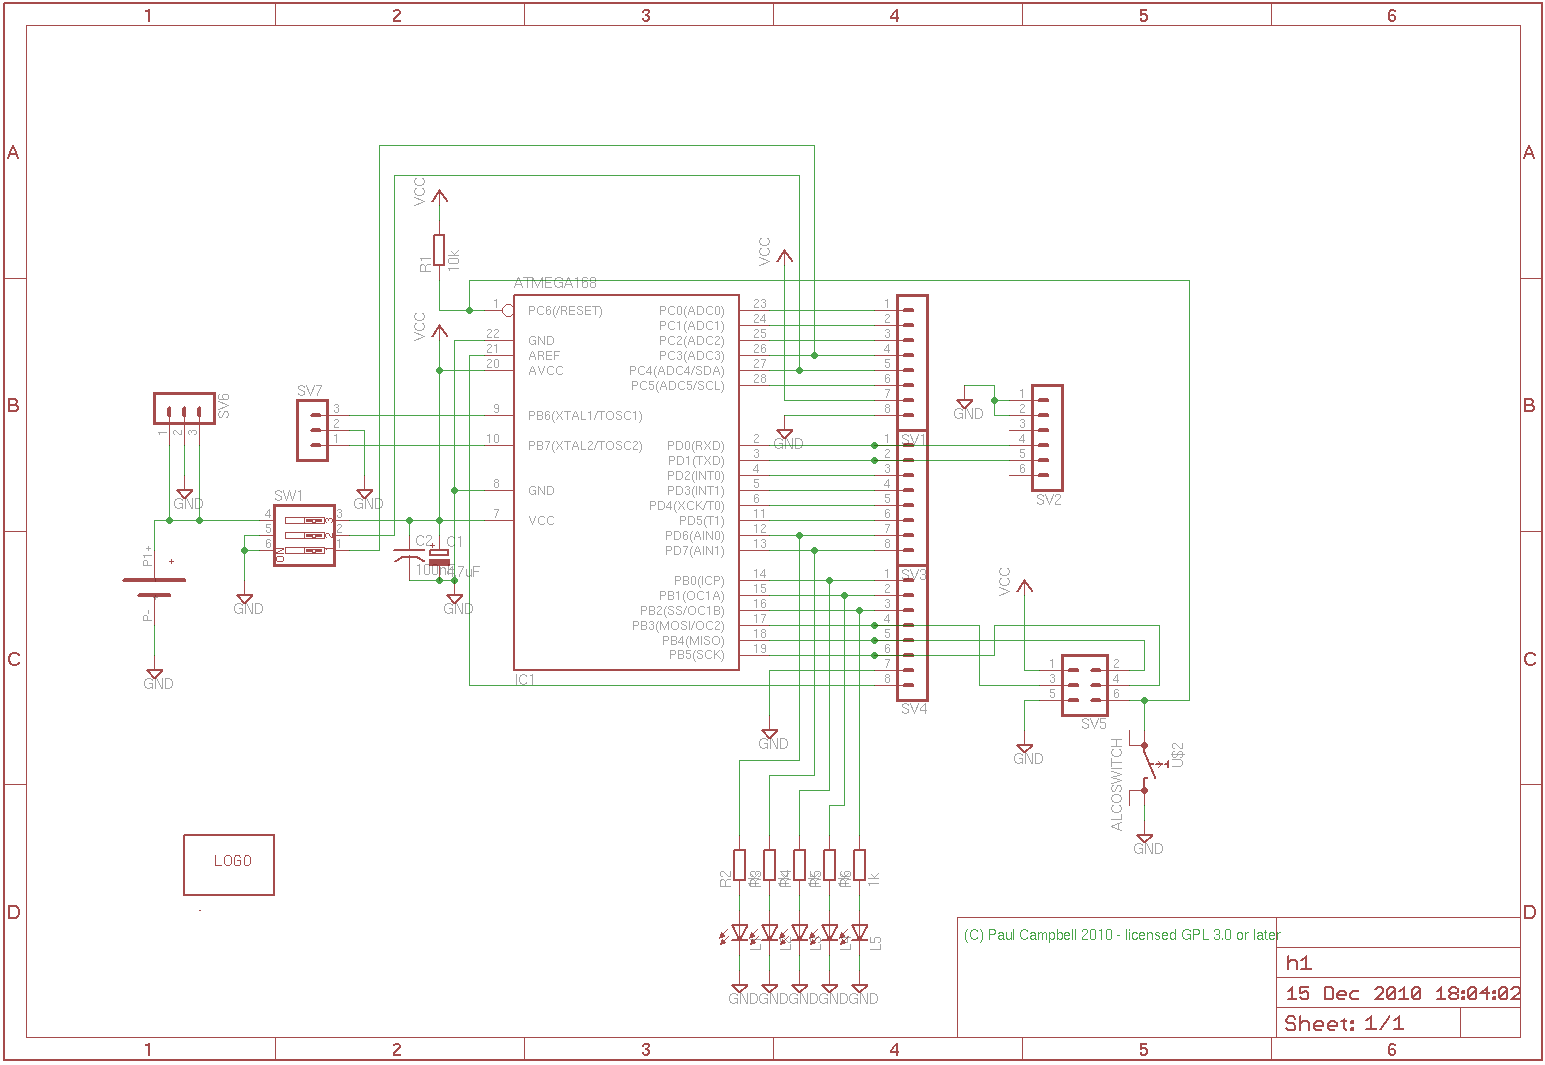
DSpace badge board build Instructions
This project is designed to assist in a basic course where students create a simple AVR/Arduino-based badge. It serves as a beginner's soldering project, resulting in a small object with blinking lights that can be worn around the neck using...
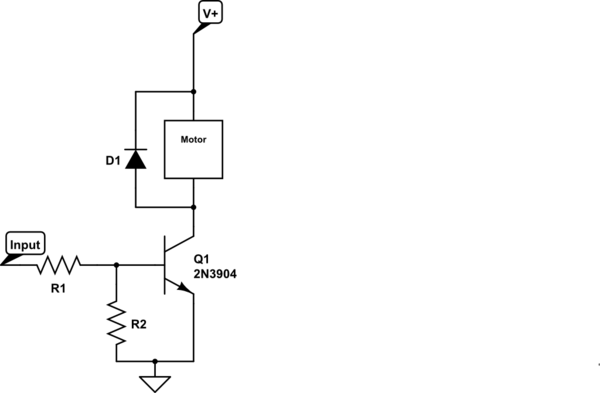
transistors Is this arduino motor driving circuit correct
Control a small 5V motor using an external power supply by triggering a transistor with an Arduino. The transistor in use is an NPN type, specifically the 2N3904.
To control a small 5V motor using an Arduino and an NPN transistor...
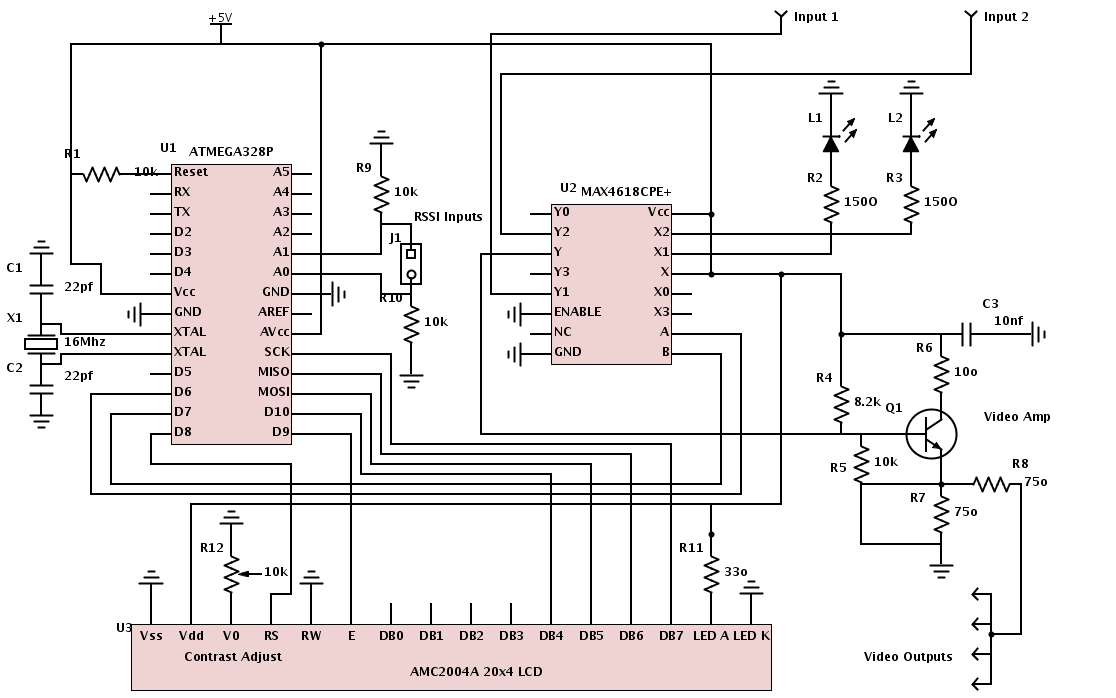
DIY Arduino Powered Diversity
All necessary materials have been gathered to work on an Arduino-powered diversity controller. The design aims to support two inputs, although the hardware can accommodate up to four inputs, and features four amplified outputs. The diversity function will utilize Received...
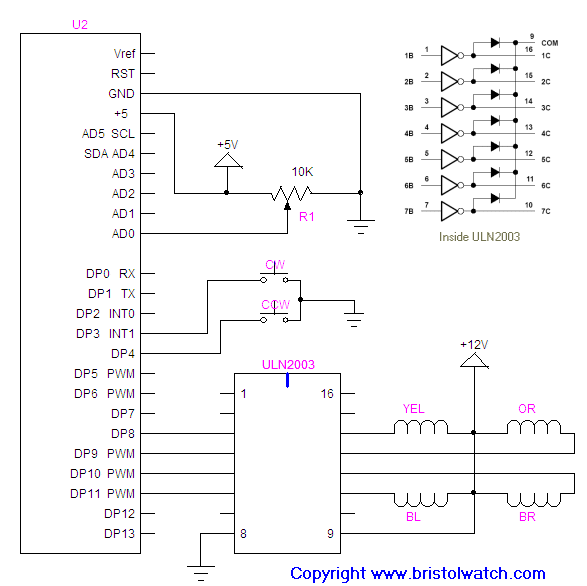
arduino unipolar stepper
How to connect and program the Arduino/Atmega168 microcontroller to operate a unipolar stepper motor.
To connect and program the Arduino/Atmega168 microcontroller for operating a unipolar stepper motor, the following steps should be followed:
1. **Components Required**:
- Arduino or Atmega168...
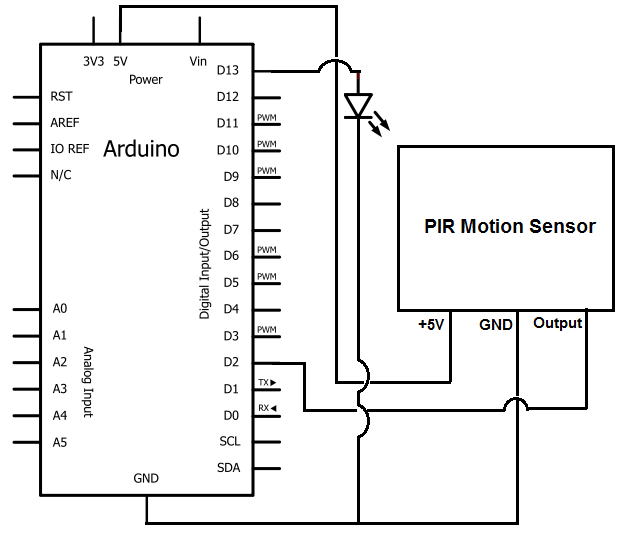
Arduino Motion Detector Circuit
Once the motion sensor detects motion, the Arduino can be programmed to activate an LED, turn on a motor, sound a buzzer, etc. In this circuit, for simplicity, an LED will be turned on when the motion sensor detects movement....
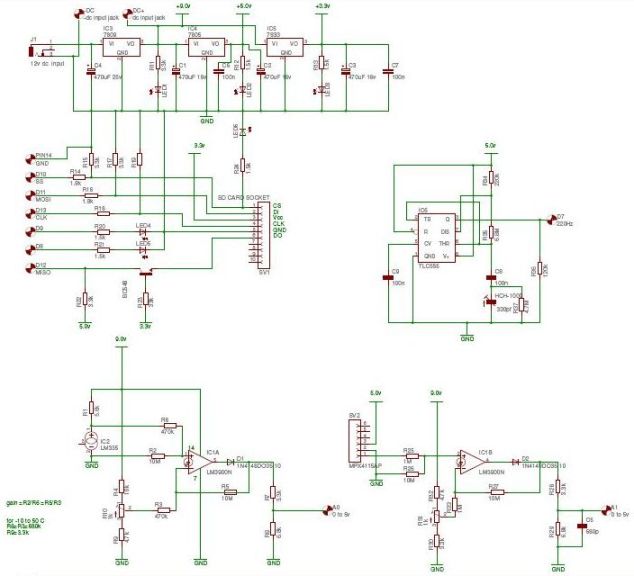
Indoor Weather Station using Arduino
The Arduino 2009 functions as an independent weather station without a display. It can operate autonomously for extended periods, sampling data from sensors until the RAM reaches full capacity. The collected data is stored in a designated sector of an...
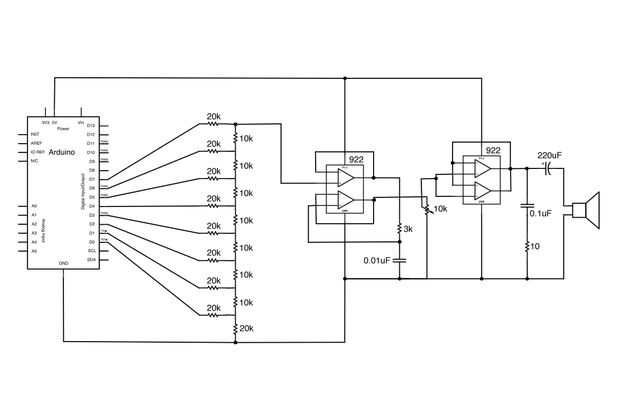
Arduino Audio Output
Generate sound or output analog voltages with an Arduino. This guide will demonstrate how to set up a basic digital-to-analog converter.
To create a digital-to-analog converter (DAC) using an Arduino, one can utilize the Pulse Width Modulation (PWM) feature available on...
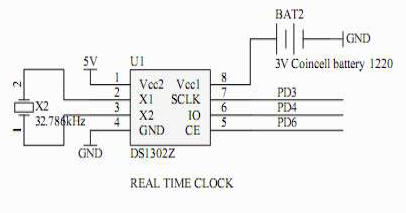
sd card logging
This documentation was compiled as a result of a bee hive temperature monitoring project. Multiple DS18B20 temperature sensors were used to sense the temperature at various locations in the hive. An Arduino with a Nuelectronics sensor shield was used to...