


MicroPower Solar Engine
#solar
#low power
#pager motor
#voltage threshold
#BC559C
#BC549C
#energy harvesting
#switching circuit
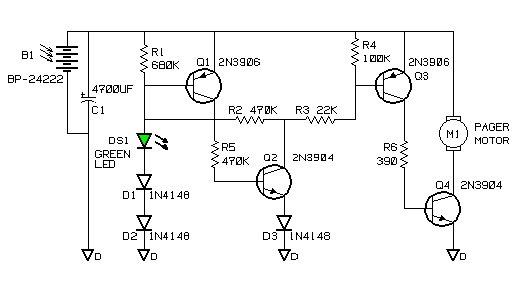
Description: A power source providing 2.5V DC at 10µA is utilized to drive a pager motor. The motor activates between 2.3V and 2.5V, and deactivates between 1.2V and 1.5V. The circuit design has been breadboarded by multiple individuals, showing consistent results, although individual experiences may vary. The configuration employs a BC559C (Q1), a BC549C (Q2), a BC559B (Q3), and a BC337-25 (Q4). Upon enabling power to the circuit, the voltage rises to a threshold that momentarily activates the motor, discharging the capacitor to a level where minimal current flows through it while Q1 and Q2 remain active. Initially, R1 was removed, its resistance measured, and replaced with a standard resistor value that is 5% to 10% lower; a 560K resistor was used by both builders, indicating the design's repeatability. It is acknowledged that this presentation is somewhat cryptic, as a complete circuit description and layout could delay sharing. The complexity of creating circuit cards, sourcing components, assembling kits, and writing assembly/debug instructions is significant, with associated costs and risks. After building several units, it was determined that R1 could be substituted with a 680K resistor instead of a potentiometer. Additionally, R6 was added to limit the current to the base of Q4, allowing more current for the motor. A minimum of 390 Ohms is recommended for R6, though it can be increased based on the motor and Q4 combination. A potential improvement to overall efficiency involves replacing Q4 with a ZTX618, which enhances the voltage across the motor. This component is produced by Zetex and available from Digi-Key, though its cost ($1.08) may not justify the effort.
The circuit operates on a simple principle of controlling a pager motor using a low-voltage DC source. The design relies on bipolar junction transistors (BJTs) to manage the activation and deactivation of the motor based on the voltage levels. The transistors Q1, Q2, and Q3 form a basic amplification stage that responds to the input voltage, while Q4 serves as the main switching transistor that drives the motor.
When the circuit is powered, the initial voltage rise activates the motor momentarily. This is crucial for ensuring that the motor receives sufficient current to start without drawing excessive power, which could exceed the power source's capabilities. The capacitor discharges quickly, allowing for a brief motor operation while maintaining the transistors Q1 and Q2 in a conductive state. This configuration helps to stabilize the operation and prevent the motor from drawing too much current continuously.
The selection of resistor values, particularly R1 and R6, plays a significant role in the circuit's performance. R1's value influences the base current flowing into Q1 and Q2, while R6 limits the base current for Q4, thus impacting the overall current available to the motor. The recommendation to use a 680K resistor instead of a potentiometer simplifies the design and enhances reliability by reducing potential points of failure.
The suggestion to replace Q4 with a ZTX618 transistor is noteworthy, as this component is designed for higher efficiency and could lead to better performance in terms of voltage across the motor. However, the cost-benefit analysis of this change should be considered, especially in low-budget or prototype applications.
In summary, the circuit design effectively utilizes low-voltage components to drive a pager motor, with careful consideration given to resistor values and transistor selection to optimize performance while maintaining simplicity and reliability.If you have a power source which will provide 2. 5Vdc at 10uA this circuit should drive a pager motor. It turns on the motor at 2. 3 to 2. 5Vdc and switches off at 1. 2 to 1. 5Vdc. Both Steve and I have built ( bread boarded or haywired) the business end of the design and achieved similar results. This does not mean that it will work for everyone but it should. [I used a BC559C (Q1), a BC549C (Q2) a BC559B (Q3) and a BC337-25 (Q4), which happened to be in the bitbox. SB] Enable power to the circuit. If the circuit works properly, the voltage will rise to a firing point, turn on the motor momentarily which discharges the capacitor to level where motor has little current passing through it but Q1 and Q2 are still conducting. At this point, . In practice, I removed R1, measured its value and replaced it with a standard resistor value 5 to 10% less.
560K was the value that both Steve and I used which shows just how repeatable this design is or how lucky we were. Note: It is realized that this presentation is very cryptic. If it were delayed until a complete circuit description and circuit layout were complete, it may not have been presented at all.
It is hard for many to realize the time and effort it takes to create the circuit cards, obtain the correct parts, make up the kits and write assembly / debug instructions. The dollar cost and other risks are not minimal. The first results from building a number of units. It was found that R1 could be replaced with a 680K resistor rather than using a pot. R6 was added to limit the current used to drive the base of Q4 which meant that more current became available for the motor.
390 Ohms is the smallest value that should be used for R6, it can be larger depending upon the motor and drive transistor (Q4) combination. There is one further proposed change that could improve the overall efficiency but it has not been tried, as far as I know.
Changing Q4 to a ZTX618 improves the voltage across the motor. It is manufactured by Zetex and available from Digi-Key, but the trouble and the price ($1. 08 US) may just not be worth it.
The circuit operates on a simple principle of controlling a pager motor using a low-voltage DC source. The design relies on bipolar junction transistors (BJTs) to manage the activation and deactivation of the motor based on the voltage levels. The transistors Q1, Q2, and Q3 form a basic amplification stage that responds to the input voltage, while Q4 serves as the main switching transistor that drives the motor.
When the circuit is powered, the initial voltage rise activates the motor momentarily. This is crucial for ensuring that the motor receives sufficient current to start without drawing excessive power, which could exceed the power source's capabilities. The capacitor discharges quickly, allowing for a brief motor operation while maintaining the transistors Q1 and Q2 in a conductive state. This configuration helps to stabilize the operation and prevent the motor from drawing too much current continuously.
The selection of resistor values, particularly R1 and R6, plays a significant role in the circuit's performance. R1's value influences the base current flowing into Q1 and Q2, while R6 limits the base current for Q4, thus impacting the overall current available to the motor. The recommendation to use a 680K resistor instead of a potentiometer simplifies the design and enhances reliability by reducing potential points of failure.
The suggestion to replace Q4 with a ZTX618 transistor is noteworthy, as this component is designed for higher efficiency and could lead to better performance in terms of voltage across the motor. However, the cost-benefit analysis of this change should be considered, especially in low-budget or prototype applications.
In summary, the circuit design effectively utilizes low-voltage components to drive a pager motor, with careful consideration given to resistor values and transistor selection to optimize performance while maintaining simplicity and reliability.If you have a power source which will provide 2. 5Vdc at 10uA this circuit should drive a pager motor. It turns on the motor at 2. 3 to 2. 5Vdc and switches off at 1. 2 to 1. 5Vdc. Both Steve and I have built ( bread boarded or haywired) the business end of the design and achieved similar results. This does not mean that it will work for everyone but it should. [I used a BC559C (Q1), a BC549C (Q2) a BC559B (Q3) and a BC337-25 (Q4), which happened to be in the bitbox. SB] Enable power to the circuit. If the circuit works properly, the voltage will rise to a firing point, turn on the motor momentarily which discharges the capacitor to level where motor has little current passing through it but Q1 and Q2 are still conducting. At this point, . In practice, I removed R1, measured its value and replaced it with a standard resistor value 5 to 10% less.
560K was the value that both Steve and I used which shows just how repeatable this design is or how lucky we were. Note: It is realized that this presentation is very cryptic. If it were delayed until a complete circuit description and circuit layout were complete, it may not have been presented at all.
It is hard for many to realize the time and effort it takes to create the circuit cards, obtain the correct parts, make up the kits and write assembly / debug instructions. The dollar cost and other risks are not minimal. The first results from building a number of units. It was found that R1 could be replaced with a 680K resistor rather than using a pot. R6 was added to limit the current used to drive the base of Q4 which meant that more current became available for the motor.
390 Ohms is the smallest value that should be used for R6, it can be larger depending upon the motor and drive transistor (Q4) combination. There is one further proposed change that could improve the overall efficiency but it has not been tried, as far as I know.
Changing Q4 to a ZTX618 improves the voltage across the motor. It is manufactured by Zetex and available from Digi-Key, but the trouble and the price ($1. 08 US) may just not be worth it.
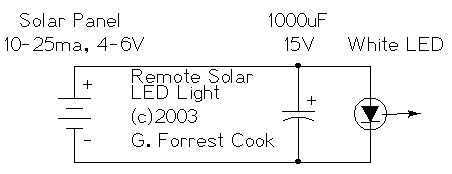
Remote Solar LED light
The remote solar powered LED light takes advantage of the current limited nature of solar photovoltaic cells. If light shines on the solar array, current will flow through the circuit. For a typical size of solar cell, there is a...
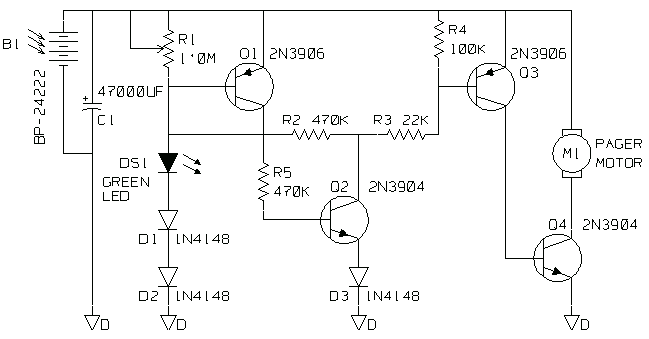
The MicroPower SE
A micro power solar engine has been a goal since my introduction to BEAM Robotics. I believe that if there wasn't one before, there is one now. What I'm presenting to you looks very similar to one of the circuits...
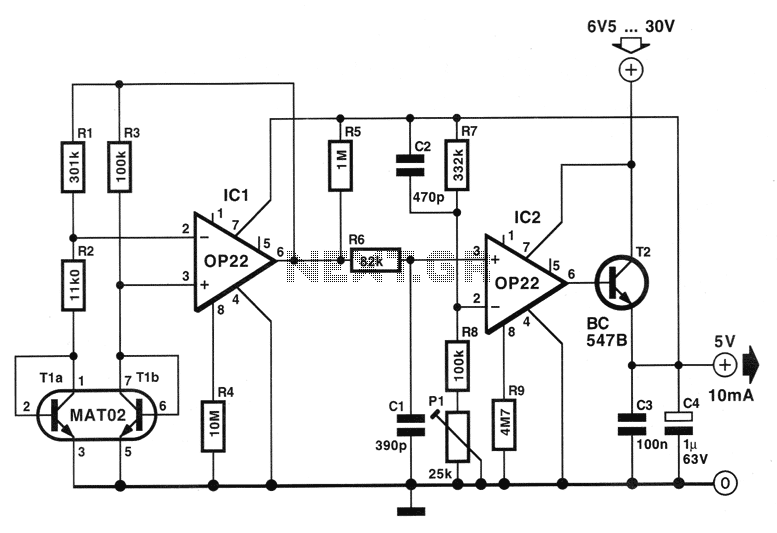
Low Power consumption 5V regulator circuit
The circuit described below is notable for its low power consumption. With a 9V input and no load at the output, it draws only 50 mA, which is significantly lower than the quiescent current of a 78L05 regulator. The circuit...
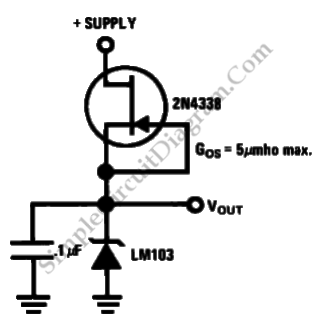
Low Power Regulator Reference
This is a simple circuit of a low-power voltage regulator reference. This circuit can produce a stable voltage reference.
The low-power voltage regulator reference circuit is designed to provide a consistent output voltage, which is crucial for various electronic applications requiring...
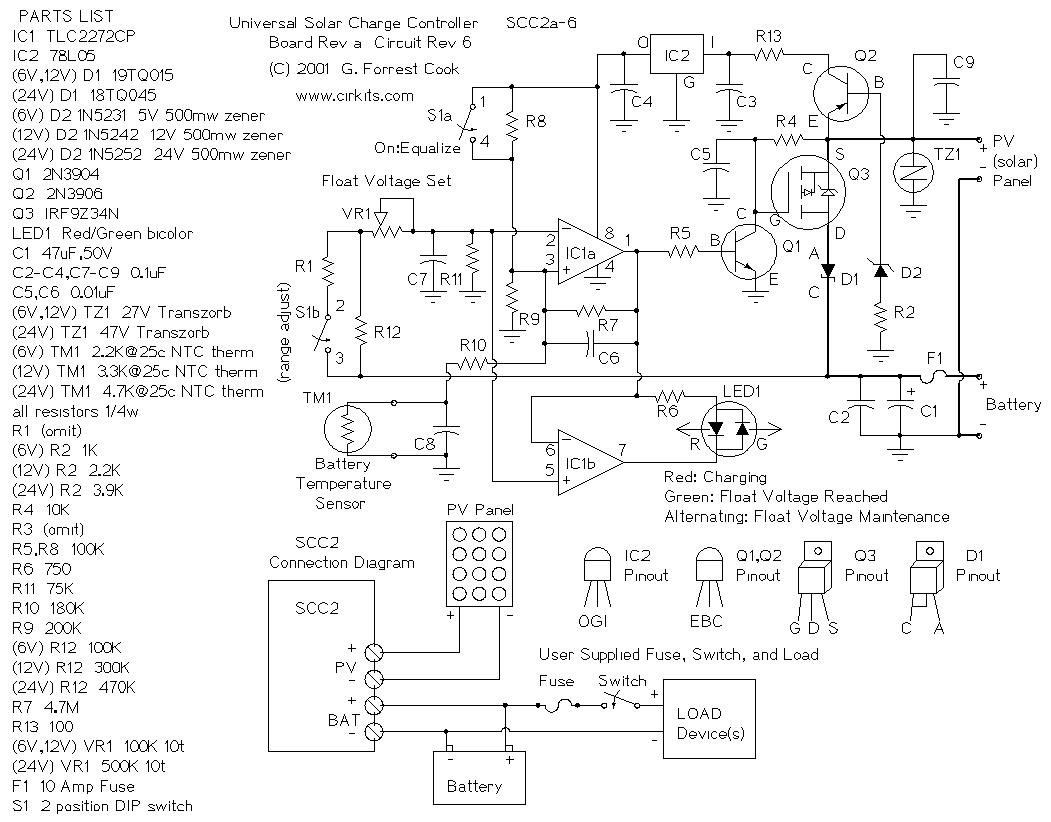
SCC2 10 Amp Solar Charge Controller
The SCC2 is a solar charge controller designed to manage the power transfer from a photovoltaic panel to a rechargeable battery. It includes a straightforward setup process utilizing a single potentiometer for adjusting the float voltage, an equalization function for...
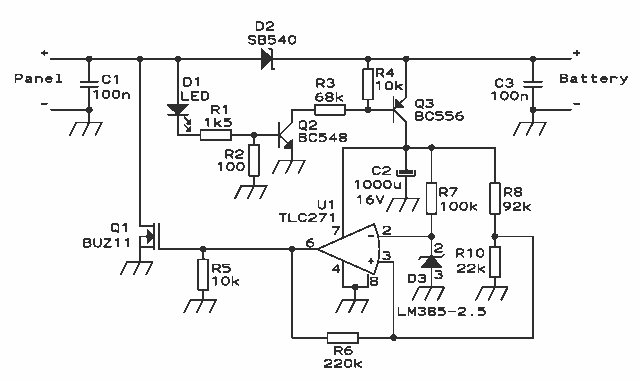
12V / 4A Solar cell regulator
When the panel isn't generating, the entire circuit is off and there is absolutely no current drain from the battery. When the sun gets up and panel starts producing at least 10 Volt, the LED lights and the two small...
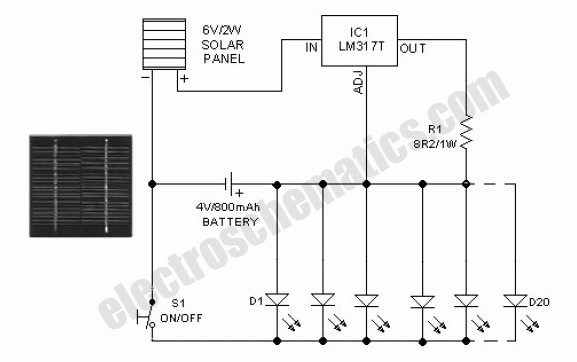
Outdoor Garden LED Solar Light Circuit
This Outdoor LED Solar Garden Lights project is a hobby circuit for an automatic garden light that utilizes a light-dependent resistor (LDR) and a 6V/5W solar panel. During daytime, the internal rechargeable 6 Volt sealed lead-acid (SLA) battery is charged...
micro power pulse generator
This circuit generates clean logic pulses with minimal current consumption. It is designed to produce short 2 ms pulses at a frequency of one pulse per second, drawing only 1 microamp from a 9-volt battery.
The described circuit operates efficiently by...
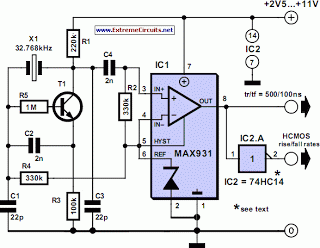
Very Low Power 32kHz Oscillator
The 32-kHz low-power clock oscillator provides several advantages compared to traditional oscillator circuits that utilize a CMOS inverter. These inverter circuits often exhibit issues such as significant fluctuations in supply currents across a 3V to 6V supply range, making it...