


PC joystick interface
#joystick
#IBM PC
#analogue
#game controller
#Y-cable
#input device
#retro computing
#PC peripherals
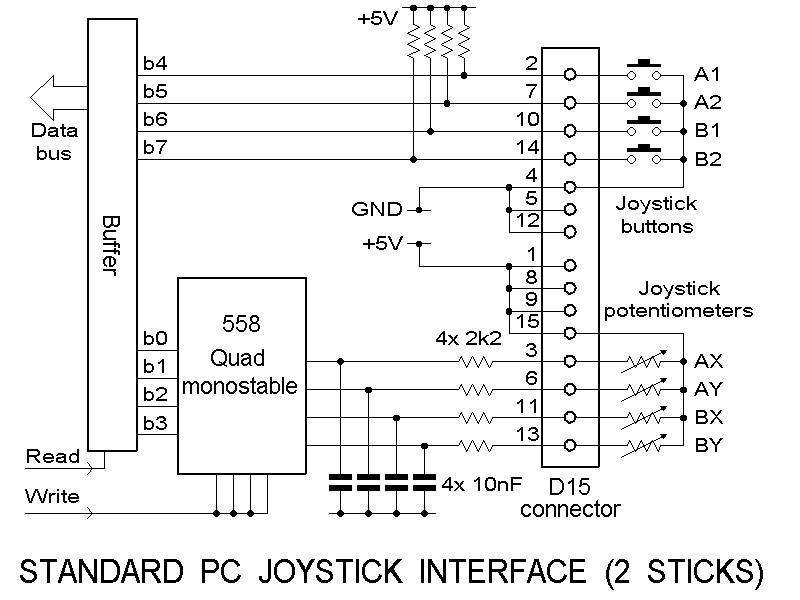
Description: This joystick model was introduced by IBM alongside their first IBM PC computer. It is a basic analog joystick featuring two buttons. The original joystick interface included a circuit for connecting two joysticks but only had one joystick connector. A special Y-cable was required to connect two joysticks simultaneously. Over time, some manufacturers added two connectors to their interface cards, while others implemented only one joystick input. Fortunately, most modern cards offer support for two joysticks, similar to the original IBM joystick card. The joystick interface card was designed to be simple and cost-effective, consisting only of bus interface electronics and four monostable multivibrators, all integrated into a single 558 chip. These monostable multivibrators function as timer circuits that output a pulse width directly proportional to the joystick's resistance value. The pulse width is measured using a software loop, which has led to significant issues for game programmers as computer speeds increased. On faster machines, the joystick routine in the software may not accurately read the joystick signal, resulting in timing problems. Some dedicated joystick cards are designed to modulate the joystick signal so that software can correctly detect and process the data. The joystick comprises two potentiometers with variable resistance values ranging from 0 Ohm to 100 kOhm (and in some cases, up to 150 kOhm). The minimum resistance values are recorded when the joystick is positioned at the top left. One end of each potentiometer connects to the +5V pin, while the center pin connects to the joystick's analog input. The other end of the potentiometer remains unconnected. There are two common construction methods for PC analog joystick mechanisms. Some joysticks convert stick position to linear motion, which adjusts the position of a slider in a linear potentiometer of about 100 kOhm. A more prevalent design uses standard axial potentiometers, where the joystick movement directly turns the potentiometers. Some joysticks utilize specialized 100 kOhm potentiometers that can only rotate 60 to 90 degrees, corresponding to the joystick's movement range. The more common design employs standard 470 kOhm (linear) 270-degree potentiometers, utilizing approximately one-fourth of the scale to achieve a resistance range of 0 to 120 kOhm. Typically, these potentiometers are carbon slider types, which may not endure prolonged gaming sessions. The joystick port is a straightforward 8-bit I/O card located at the ISA bus I/O address 201h. The CPU can read from and write to the joystick port at this address. Writing to this address initiates joystick position measurement, and the interface only uses the write signal to reset the multivibrators on the card. The data value written is not stored, making the specific value irrelevant. When reading one byte from I/O address 201h, the status information of the joystick interface is obtained. The following table illustrates the bit mapping in the received value:
Game port 201h byte:
_ | 7 | 6 | 5 | 4 | 3 | 2 | 1 | 0 |
| | but4 | but3 | but2 | but1 | stk4 | stk3 | stk2 | stk1 |
|_|_|_|_|_|_|_|_|
The four most significant bits indicate the state of the joystick buttons, while the four least significant bits represent the states of the multivibrators used to measure the resistance values of the joystick position potentiometers. A more detailed description of the bit meanings is as follows:
7 6 5 4 3 2 1 0
*. . . . . . . Button B2 (pin 14), 0=closed, 1=open (default).
*. . . . . . Button B1 (pin 10), 0=closed, 1=open (default).
. *. . . . . Button A2 (pin 7), 0=closed, 1=open (default).
The joystick's operational design relies on the interaction between the potentiometers and the interface card, which processes the analog signals generated by the joystick's movements. The simplicity of the design allows for effective integration with early IBM PC systems, while the evolution of joystick technology has led to improved capabilities and features in modern gaming peripherals. The analog nature of the joystick allows for smooth and continuous input, making it suitable for a variety of applications, including gaming and simulation. The implementation of dedicated joystick cards and the evolution of software routines have addressed many of the timing and detection issues that arose with increasing computer speeds, ensuring reliable performance across a range of hardware configurations.This joystick model was presented by IBM together with their first IBM PC computer. The joystick is just a basic analogue joystick with two buttons. The original joystick interface had circuit for connecting two joysticks, but had only one joystick connector. A special Y-cable was needed if there was need for two joysticks at the same time. Later time some manufacturers put two connectors to their interface card and some card manufacturers implemented only one joystick input. Fortunately most of the card nowadays have option for two joysticks like the original IBM joystick card.
The joystick interface card was designed to be as simple and cheap as possible. The card consisted only of bus interface electronics and four monostable multivibrators (all in on 558 chip). Those monostable multivibrators were simple timer circuits which put out a pulse with width directly proportional to the joystick resistance value.
The pulse width was then measured using software loop. This has caused anormous amounts of problems to game programmers when computers have become faster and faster all the time. On faster machines, the joystick routine in the software does not read the joystick signal properly resulting in a timing problems.
Some dedicated joystick cards are designed to vary the joystick signal so the software can properly detect the joystick and process the data. The joystick consists of two potentiometers with variable resistance value between 0 Ohm and 100 kohm (in some joysticks up to 150 kohm).
The potentiometer resistances have the minimum values when the joystick is at the top left position. One end of the potentiometer is connected to +5V pin and the center pin is connected top the analogue input of the joystick. The other end of the potentiometer is left not connected to anywhere. There are two commonly used ways how PC analogue joystick stick mechanism is constructed. Some joystick convert the stick position to linear motion, whcih then changes the position of the slider in about 100 kohm linear potentiometer.
More popular construction is to use normal axial potentiometers and the joystick movement directly turns those potentiometers. Some joystick used special 100 kohm potentiometer which can only turn that 60. 90 degrees which joytick can turn. The more common construction is to use the standard 470 kohm (lin) 270 degree potentiomer and use about one fourth of the scale from the beginning (in this way getting 0.
120 kohm value range). Usually those potentiometers are normal carbon slider potentimeters which do not last long in intense gaming. The joystick port is a very simple 8 bit I/0 card which resides in ISA bus I/O address 201h. The CPU can read and write to the joystick port I/O address 201h. Writing to that address starts joystick postition measurement. Joystick interface only uses the signal that somebody is writing to the I/O address to reset the multivibrators in the card.
The data value is not stored anywhere, so it is really same what value is written to this address. When you read one byte from I/O addess 201h, you get the status information of the joystick interface. The following table will show how the bits are mapped in the value you get. Game port 201h byte: _ | 7 | 6 | 5 | 4 | 3 | 2 | 1 | 0 | | but4 | but3 | but2 | but1 | stk4 | stk3 | stk2 | stk1 | |_|_|_|_|_|_|_|_| The four most significant bits tell you the state of the joystick buttons.
Four least significant bits tell the state of the multivibrators which are used for measuring the resistance value of the joytick position potentiometers. More accurate description of the bit meanings can be found at the table below: 7 6 5 4 3 2 1 0 *. . . . . . . Button B2 (pin 14), 0=closed, 1=open (default). *. . . . . . Button B1 (pin 10), 0=closed, 1=open (default). . *. . . . . Button A2 (pin 7), 0=closed, 1=open (default). . . *
Game port 201h byte:
_ | 7 | 6 | 5 | 4 | 3 | 2 | 1 | 0 |
| | but4 | but3 | but2 | but1 | stk4 | stk3 | stk2 | stk1 |
|_|_|_|_|_|_|_|_|
The four most significant bits indicate the state of the joystick buttons, while the four least significant bits represent the states of the multivibrators used to measure the resistance values of the joystick position potentiometers. A more detailed description of the bit meanings is as follows:
7 6 5 4 3 2 1 0
*. . . . . . . Button B2 (pin 14), 0=closed, 1=open (default).
*. . . . . . Button B1 (pin 10), 0=closed, 1=open (default).
. *. . . . . Button A2 (pin 7), 0=closed, 1=open (default).
The joystick's operational design relies on the interaction between the potentiometers and the interface card, which processes the analog signals generated by the joystick's movements. The simplicity of the design allows for effective integration with early IBM PC systems, while the evolution of joystick technology has led to improved capabilities and features in modern gaming peripherals. The analog nature of the joystick allows for smooth and continuous input, making it suitable for a variety of applications, including gaming and simulation. The implementation of dedicated joystick cards and the evolution of software routines have addressed many of the timing and detection issues that arose with increasing computer speeds, ensuring reliable performance across a range of hardware configurations.This joystick model was presented by IBM together with their first IBM PC computer. The joystick is just a basic analogue joystick with two buttons. The original joystick interface had circuit for connecting two joysticks, but had only one joystick connector. A special Y-cable was needed if there was need for two joysticks at the same time. Later time some manufacturers put two connectors to their interface card and some card manufacturers implemented only one joystick input. Fortunately most of the card nowadays have option for two joysticks like the original IBM joystick card.
The joystick interface card was designed to be as simple and cheap as possible. The card consisted only of bus interface electronics and four monostable multivibrators (all in on 558 chip). Those monostable multivibrators were simple timer circuits which put out a pulse with width directly proportional to the joystick resistance value.
The pulse width was then measured using software loop. This has caused anormous amounts of problems to game programmers when computers have become faster and faster all the time. On faster machines, the joystick routine in the software does not read the joystick signal properly resulting in a timing problems.
Some dedicated joystick cards are designed to vary the joystick signal so the software can properly detect the joystick and process the data. The joystick consists of two potentiometers with variable resistance value between 0 Ohm and 100 kohm (in some joysticks up to 150 kohm).
The potentiometer resistances have the minimum values when the joystick is at the top left position. One end of the potentiometer is connected to +5V pin and the center pin is connected top the analogue input of the joystick. The other end of the potentiometer is left not connected to anywhere. There are two commonly used ways how PC analogue joystick stick mechanism is constructed. Some joystick convert the stick position to linear motion, whcih then changes the position of the slider in about 100 kohm linear potentiometer.
More popular construction is to use normal axial potentiometers and the joystick movement directly turns those potentiometers. Some joystick used special 100 kohm potentiometer which can only turn that 60. 90 degrees which joytick can turn. The more common construction is to use the standard 470 kohm (lin) 270 degree potentiomer and use about one fourth of the scale from the beginning (in this way getting 0.
120 kohm value range). Usually those potentiometers are normal carbon slider potentimeters which do not last long in intense gaming. The joystick port is a very simple 8 bit I/0 card which resides in ISA bus I/O address 201h. The CPU can read and write to the joystick port I/O address 201h. Writing to that address starts joystick postition measurement. Joystick interface only uses the signal that somebody is writing to the I/O address to reset the multivibrators in the card.
The data value is not stored anywhere, so it is really same what value is written to this address. When you read one byte from I/O addess 201h, you get the status information of the joystick interface. The following table will show how the bits are mapped in the value you get. Game port 201h byte: _ | 7 | 6 | 5 | 4 | 3 | 2 | 1 | 0 | | but4 | but3 | but2 | but1 | stk4 | stk3 | stk2 | stk1 | |_|_|_|_|_|_|_|_| The four most significant bits tell you the state of the joystick buttons.
Four least significant bits tell the state of the multivibrators which are used for measuring the resistance value of the joytick position potentiometers. More accurate description of the bit meanings can be found at the table below: 7 6 5 4 3 2 1 0 *. . . . . . . Button B2 (pin 14), 0=closed, 1=open (default). *. . . . . . Button B1 (pin 10), 0=closed, 1=open (default). . *. . . . . Button A2 (pin 7), 0=closed, 1=open (default). . . *
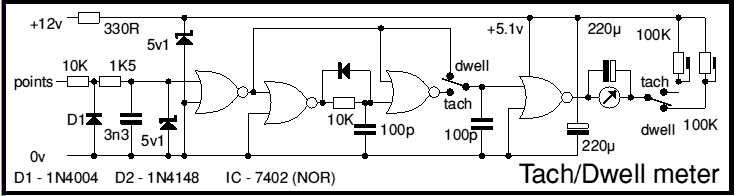
Analogue Tachometer and Dwellmeter
This circuit as first published in Wireless World September 1975 and subsequently in MECRM. It's built around a TTL quad NOR gate, though CMOS could be used.
The circuit in question utilizes a TTL (Transistor-Transistor Logic) quad NOR gate, which consists...
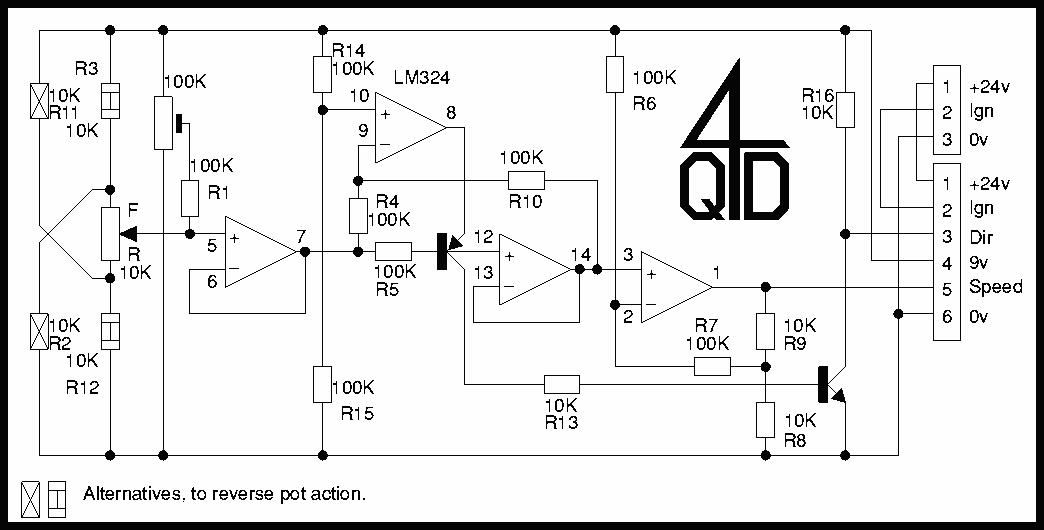
Joystick Interfaces
This is a page of analogue interfaces for joysticks. Although these interfaces have been developed for use with 4QD's controllers, they will have plenty of other uses. Also, because of the development history, we have printed circuit boards available (either...
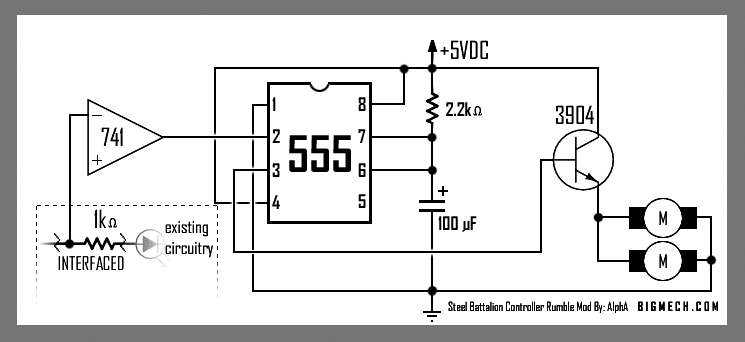
Rumble Mod Circuit For Steel Battalion
This is the large controller utilized for the game Steel Battalion for the Xbox. The schematic diagram was sourced from an individual named Alpha who created it for his own use.
The Steel Battalion controller is a specialized input device designed...
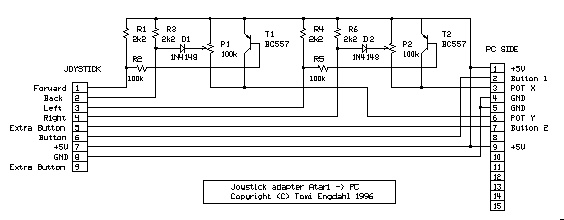
Atari joystick to PC joystick adapter
Some games are easier to play with a digital joystick instead of an analogue type. Unfortunately, PC has only an analogue joystick connector, which makes it impossible to connect a normal digital joystick to it. But with a little adapter...
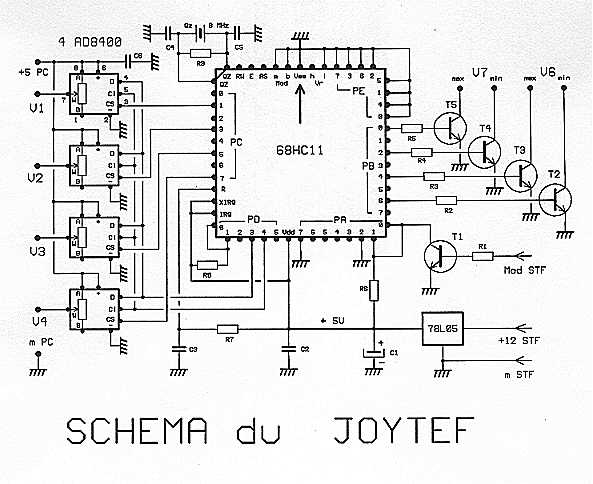
A SPECIAL INTERFACE Joystic ( 68HC11A1)
Using the software during flight simulation models of planes: REAL-FLIGHT, we first chose a housing of any transmitter empty direct connection potentiometers innings. However, this is not good because, first races of the potentiometers are only 90 degrees, which makes...
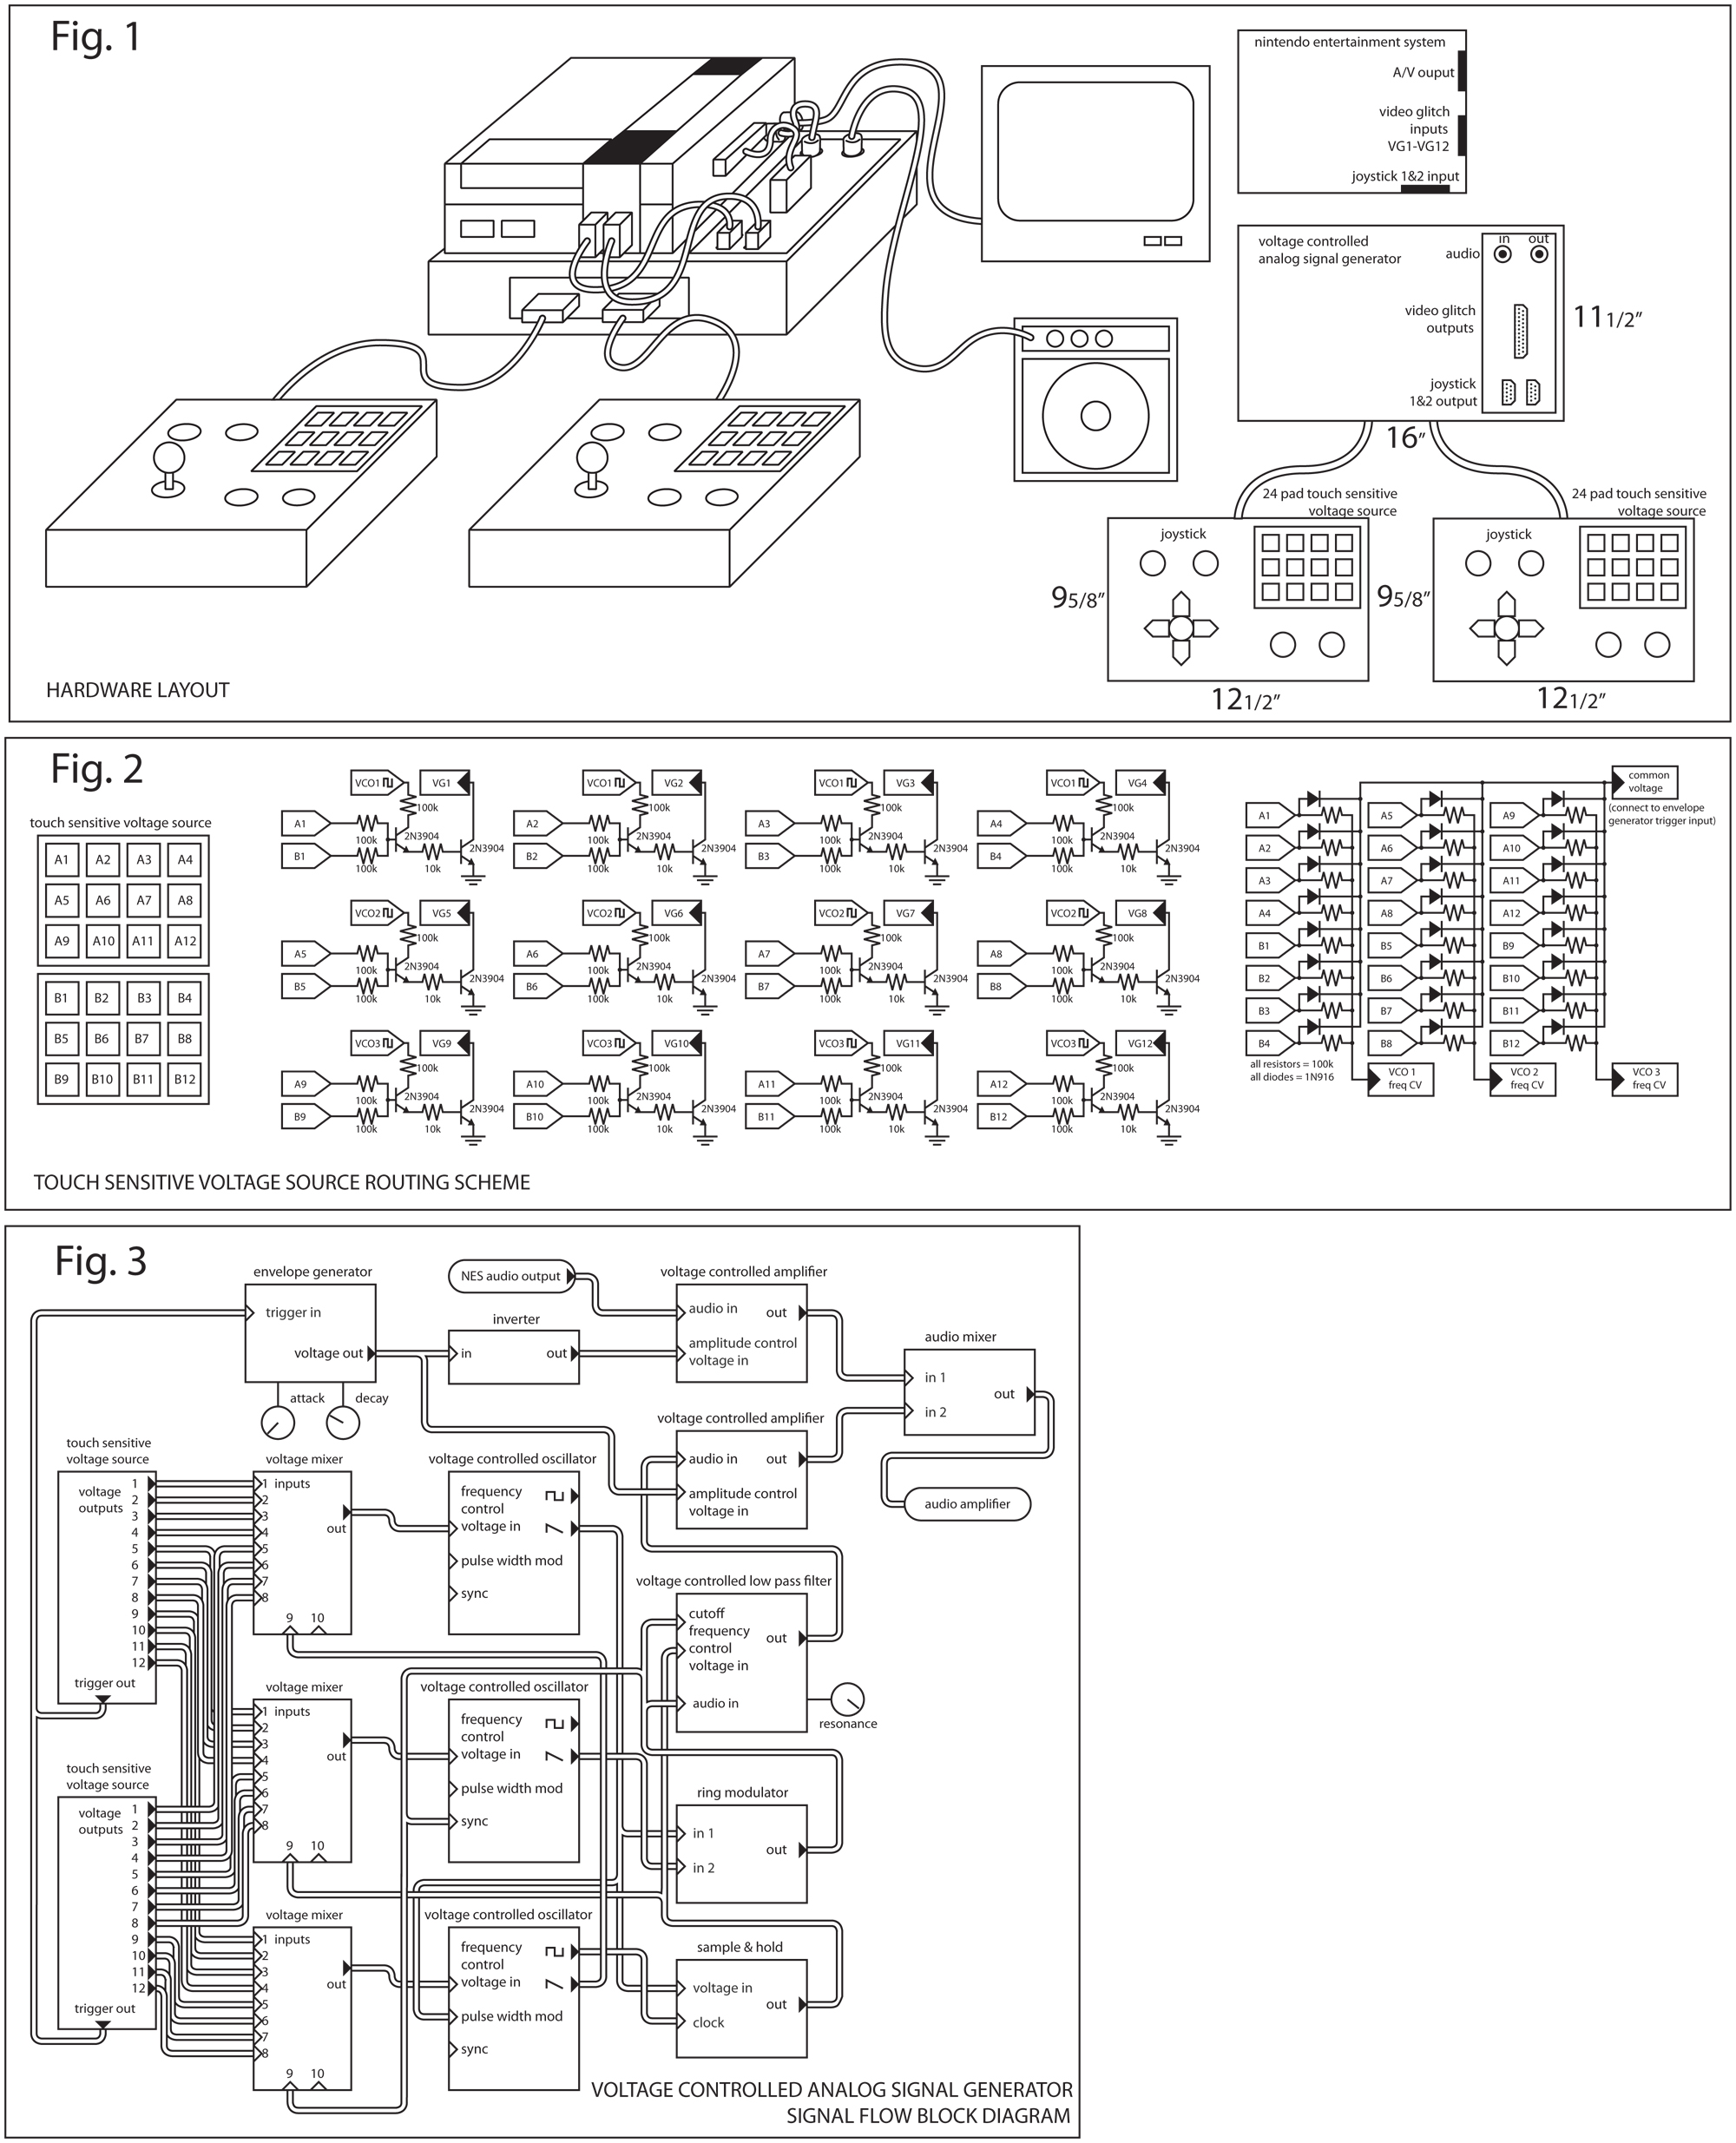
Bit Bender
The user selects a game to play and presses the power button on the Nintendo console. Players can choose between one or two-player games. Once the game loads, the game controller enables standard gameplay. As long as the user interacts...
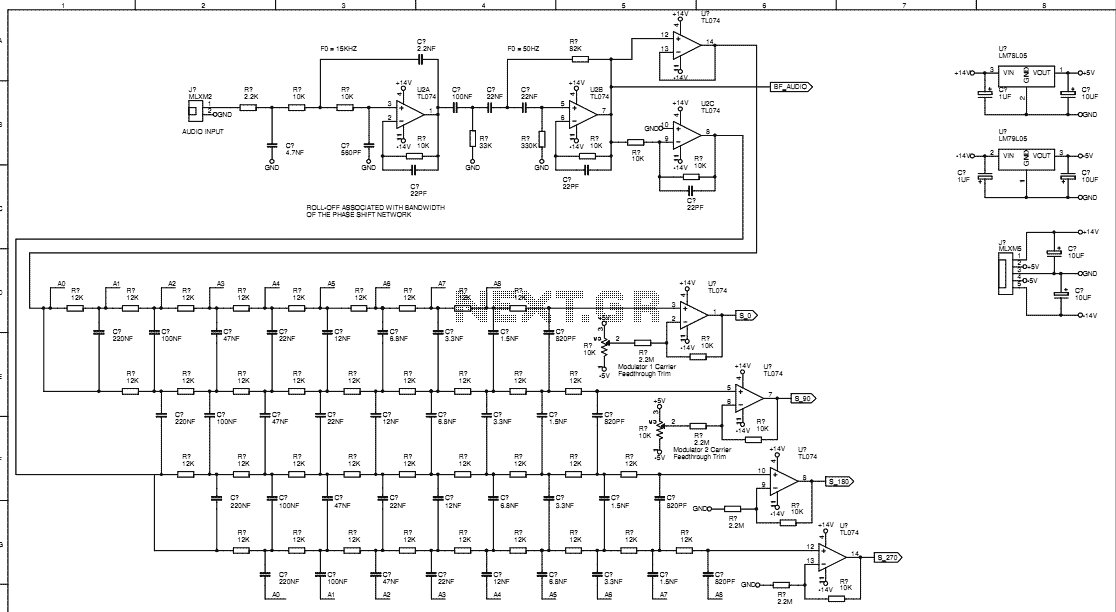
Analogue Pitch Shifter
This is two three pole bandpass filters with the HPF Fo about 50Hz and the LPF Fo about 15kHz. This limits the input bandwidth to the phase sequence array, which can produce 90° phase shifts only over a limited bandwidth....
Analogue VU meter
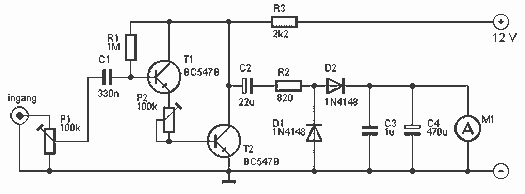
This circuit can drive analog moving coil meters, for use as a VU meter. The circuit is left connected to the line terminals of the amplifier. The VU meter works pretty simple. T1 and T2 signal increase. The signal is...
Analogue Pulse Counter Schematic
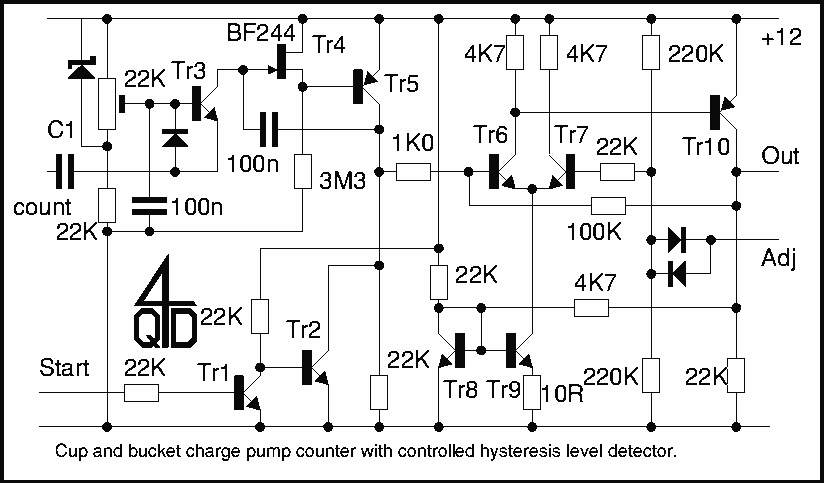
It was designed for an application in a welding machine: there are lots of bits of machinery which are cylindrical in shape and which are subjected to heavy surface wear. For instance ore crushers, and the idler and roller wheels...