


74LS192 Computer controller 4 DC motors
#74LS192
#DC motors
#computer interface
#robotics
#relays
#shaft encoders
#positional feedback
#motor control
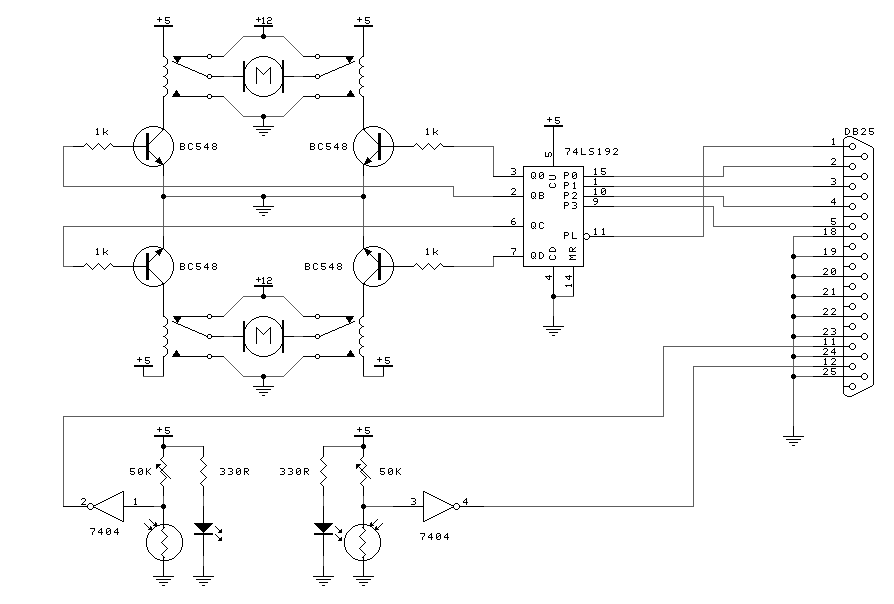
Description: This circuit is beneficial for connecting a computer to homemade robotics. It is straightforward to construct and operate, capable of controlling two DC motors of varying current and voltage ratings, contingent on the specifications of the relays used. Additionally, the circuit includes two shaft encoders to provide positional feedback to the computer.
The described circuit serves as a versatile interface for controlling robotic systems. It is designed to handle two DC motors, which can be selected based on the desired current and voltage ratings, as determined by the specifications of the relays integrated into the circuit. The relays act as switches that enable or disable the motors, allowing for precise control over their operation.
Incorporating two shaft encoders into the design enhances the functionality of the circuit by providing real-time positional feedback. These encoders detect the rotational position of the motor shafts, translating mechanical movement into electrical signals that can be processed by the computer. This feedback loop is essential for applications requiring accurate positioning and movement control, enabling the robotic system to respond dynamically to its environment.
The overall design emphasizes simplicity and ease of use, making it accessible for hobbyists and engineers alike. The circuit can be built using commonly available components, and its modular nature allows for easy modifications and expansions, such as adding more motors or sensors as needed. This flexibility makes the circuit an excellent choice for various robotic applications, from simple tasks to more complex automated systems.This circuit has proven useful when interfacing my computer to home made robotics. It is easy to build and use and it can control two DC motors of any current or voltage rating, depending on the rating of the relays. The circuit also provides two shaft encoders for positional feedback to the computer. Disclaimer All files are found using legitimat e search engine techniques. This site does not and will not condone hacking into sites to create the links it list. We will and do assume that all links found on the search engines we use are obtained in a legal manner and the webmasters are aware of the links listed on the search engines. If you find a URL that belongs to you, and you did not realize that it was "open to the public", please use the report button to notify the blogmaster of your request to remove it or it will remove within 24 hours.
This is not an invitation for webblog haters to spam with requests to remove content they feel that is objectionable and or unacceptable. Proof of URL ownership is required. NOTICE: This Blog Has Already Been Reviewed And Accepted By Blogger. com
The described circuit serves as a versatile interface for controlling robotic systems. It is designed to handle two DC motors, which can be selected based on the desired current and voltage ratings, as determined by the specifications of the relays integrated into the circuit. The relays act as switches that enable or disable the motors, allowing for precise control over their operation.
Incorporating two shaft encoders into the design enhances the functionality of the circuit by providing real-time positional feedback. These encoders detect the rotational position of the motor shafts, translating mechanical movement into electrical signals that can be processed by the computer. This feedback loop is essential for applications requiring accurate positioning and movement control, enabling the robotic system to respond dynamically to its environment.
The overall design emphasizes simplicity and ease of use, making it accessible for hobbyists and engineers alike. The circuit can be built using commonly available components, and its modular nature allows for easy modifications and expansions, such as adding more motors or sensors as needed. This flexibility makes the circuit an excellent choice for various robotic applications, from simple tasks to more complex automated systems.This circuit has proven useful when interfacing my computer to home made robotics. It is easy to build and use and it can control two DC motors of any current or voltage rating, depending on the rating of the relays. The circuit also provides two shaft encoders for positional feedback to the computer. Disclaimer All files are found using legitimat e search engine techniques. This site does not and will not condone hacking into sites to create the links it list. We will and do assume that all links found on the search engines we use are obtained in a legal manner and the webmasters are aware of the links listed on the search engines. If you find a URL that belongs to you, and you did not realize that it was "open to the public", please use the report button to notify the blogmaster of your request to remove it or it will remove within 24 hours.
This is not an invitation for webblog haters to spam with requests to remove content they feel that is objectionable and or unacceptable. Proof of URL ownership is required. NOTICE: This Blog Has Already Been Reviewed And Accepted By Blogger. com
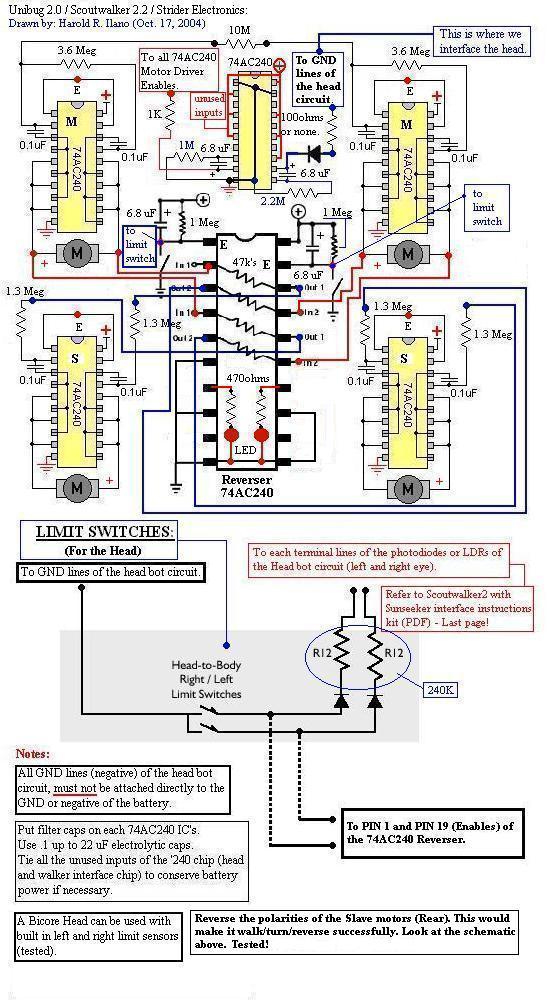
Robotics Page
This is an attempt to create a simple and compact photovore. Although it may not be visually appealing, it serves as a good starting point for beginners. It is a personal version of the Dozer photovore. The latest robot built...
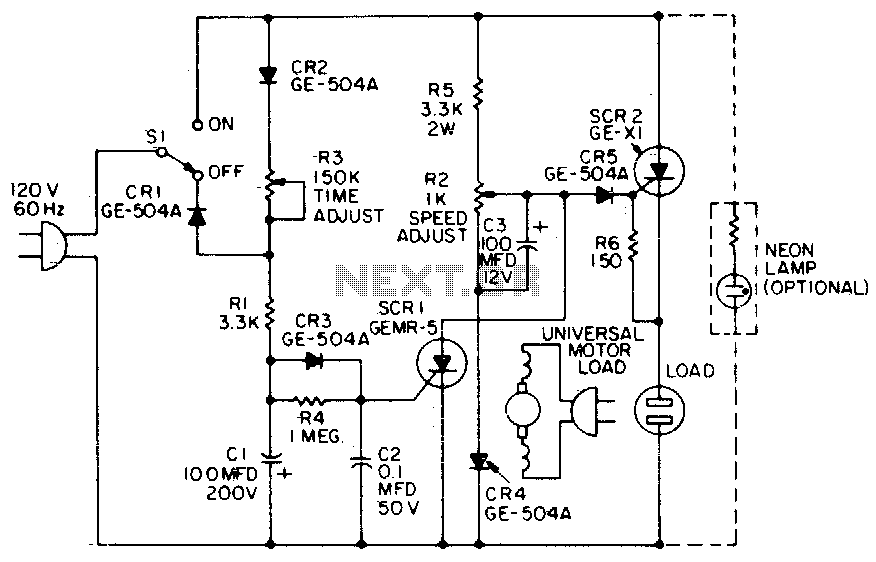
Universal motor control
When the time delay expires, SCR1 conducts and removes the gate signal from SCR2, which stops the motor. Both the time delay and motor speed are adjustable by potentiometers R2 and R3. If heavier motor loads are anticipated, use the...
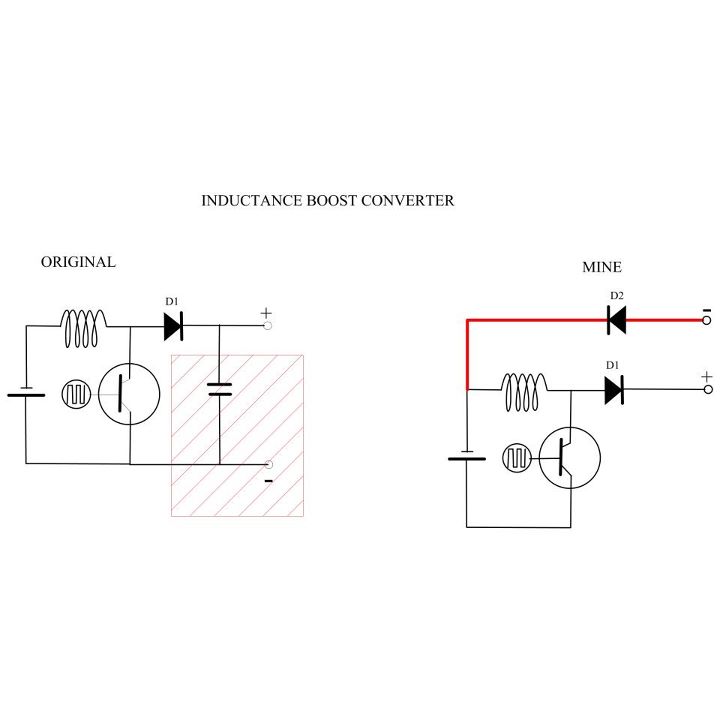
My Motors got me to Tap into Radiant Energy
A new user is seeking to share information about their experiences on this platform.
The user expresses a desire to communicate and engage with the community regarding their experiences. This indicates an interest in exchanging knowledge and possibly seeking assistance or...
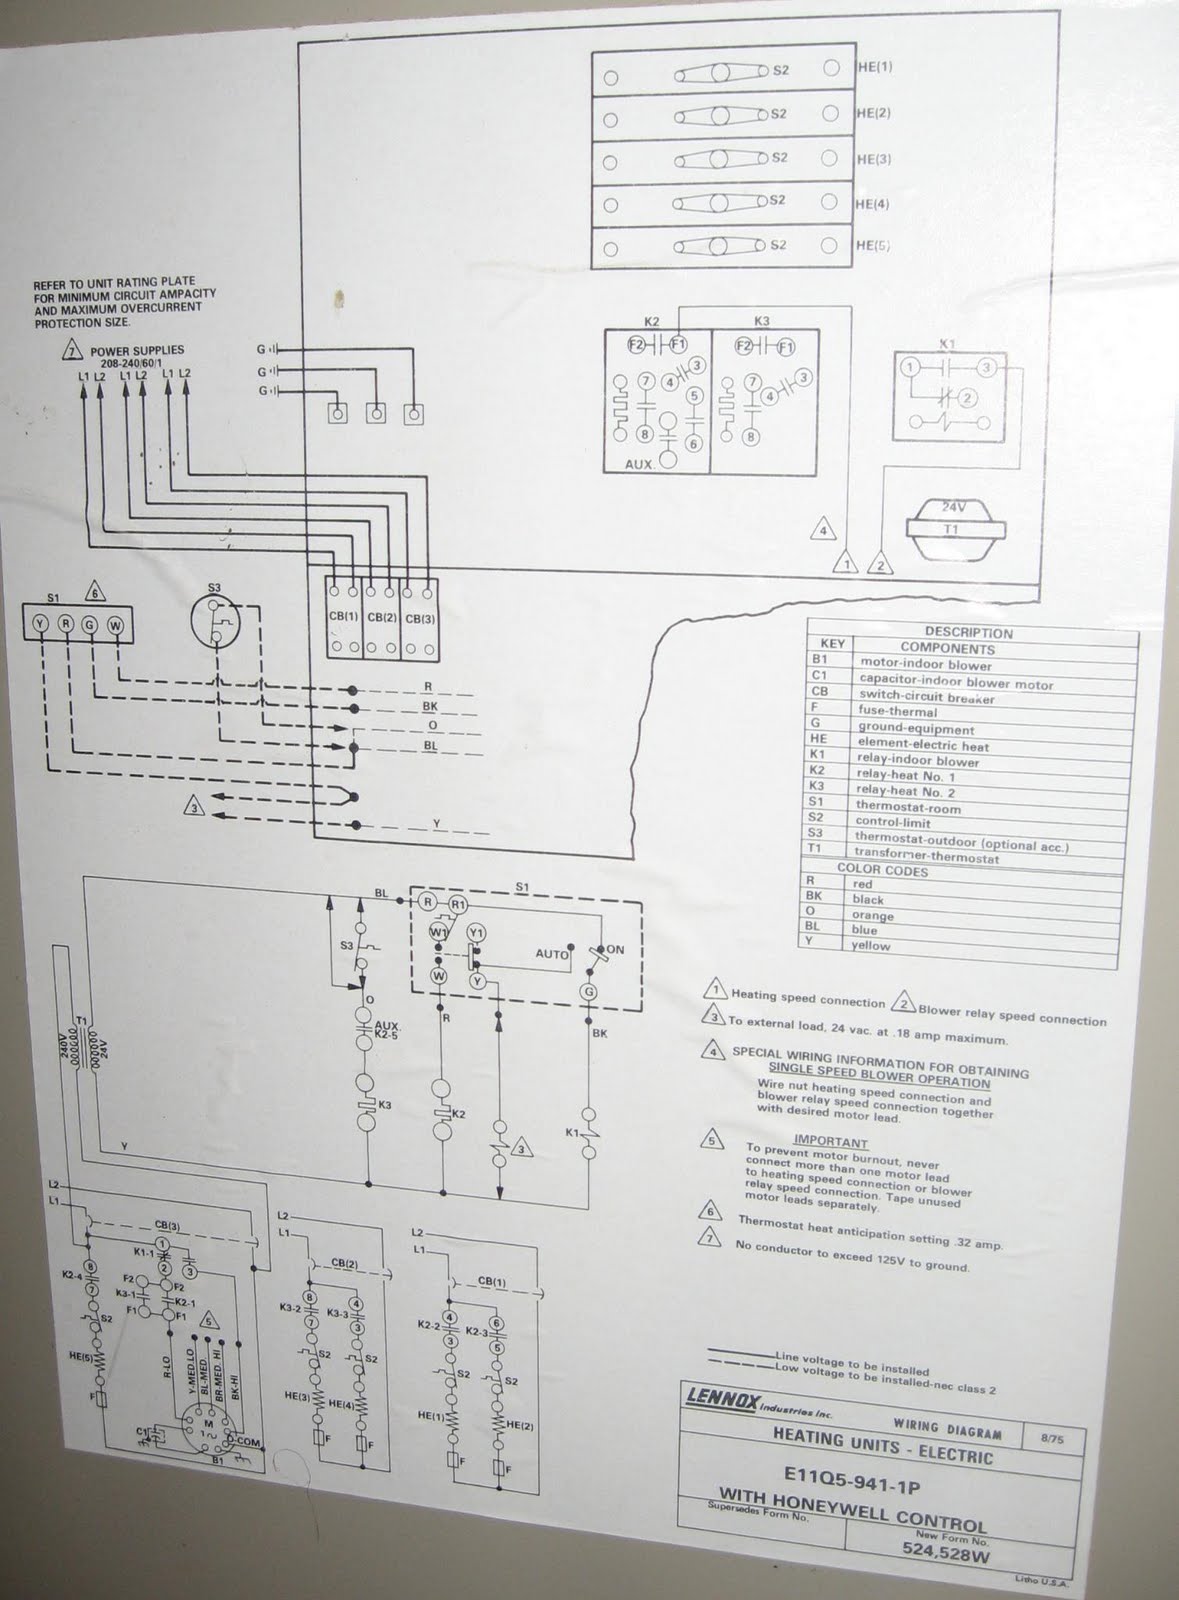
original electric furnace
This is a switched system, which does not utilize a sequencer like modern electric furnaces. Instead, it employs relays. An upgrade to install a sequencer may be beneficial. The system features a 5-speed blower, although only two speeds appear to...
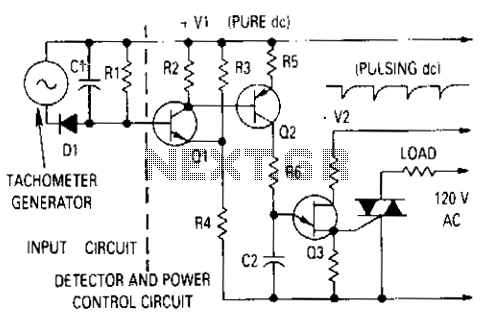
Motor control with tachometer
The generator output is rectified, filtered, and applied between the positive supply voltage and the base of the detector transistor. This configuration provides a negative voltage that reduces the base voltage as the speed increases. During normal operation, if the...
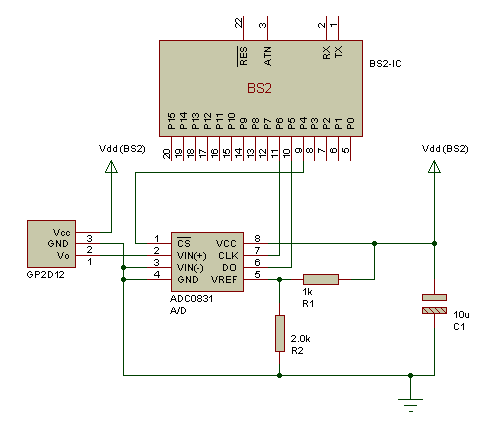
Code Collection
CrustCrawler develops and manufactures advanced walking robots and robotic accessories.
CrustCrawler specializes in the design and production of innovative walking robots, which incorporate advanced technologies and engineering principles to achieve improved mobility and functionality. These robots are typically characterized by their...
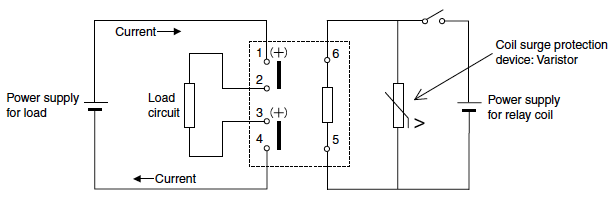
high capacity dc power relays
The value may vary based on the switching frequency, environmental conditions, and required reliability level; therefore, it is advisable to verify this with the actual load. The maximum ambient temperature represents the highest temperature that can meet the coil temperature...
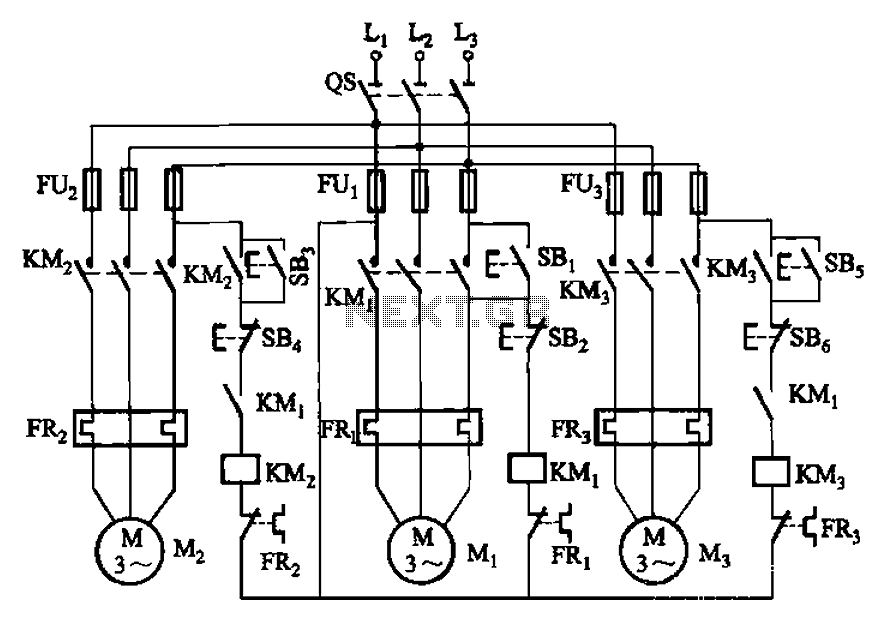
Three motor control circuit start and stop sequence requirements
The circuit shown in Figure 3-89 illustrates a system where starting motor M1 allows motors M2 and M3 to initiate operation. Upon shutdown, motor Mz can be stopped first; however, once motor M1 is stopped (by pressing switch SB2), motors...
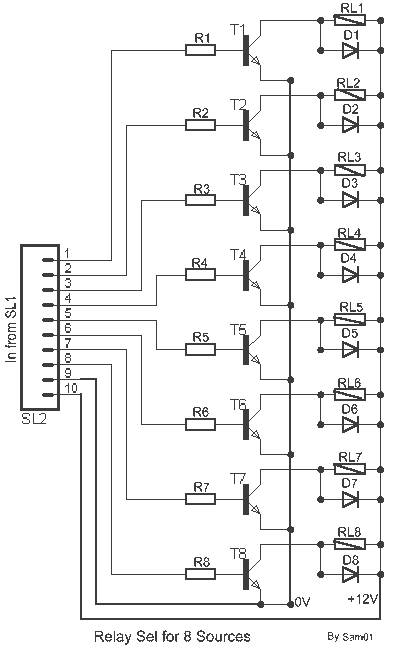
8 input Relays circuit
It is the essential continuity of circuits Sel 8 Sources and Up/Down Sel 8 Sources, but can work and autonomously, collaborating with any suitable circuit of control. The Relay 1-8 can be 6-24v DC. For current of collector of transistors...