


Wireless Coupler Terminal Interface
#wireless
#RS-232
#terminal interface
#RF communication
#antenna
#9600 baud
#data transmission
#coupler
#computer interface
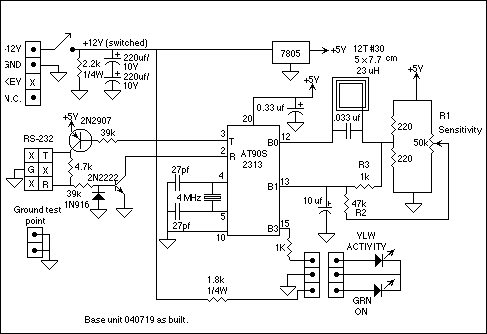
Description: The purpose of the terminal interface is to allow my computer to communicate with Minimum Mass Wireless Coupler equipped devices using a terminal emulator program. Consequently, the Base Unit is basically an RS-232 interface and Minimum Mass Wireless Coupler. The Base Unit is the larger enclosure in Photo 1. The RS-232 interface to the computer is 9600 baud, 1 stop bit, no parity, plenty fast to keep up with the 1200 baud maximum data rate from the Coupler. The antenna is made of 12 turns of #30 enameled wire threaded through metal guide loops arranged around the perimeter of the board. This antenna's area is about 160% that of the prototype 5.5 cm loop so it has a little more range for both transmitting and receiving.
To further increase the transmitter's range, 220-ohm bias resistors are used. This sets the maximum peak current from the microcontroller’s output pin at about 23 milliamps, safely below the maximum current specified on the microcontroller’s data sheet. Since the antenna is resonant, the peak antenna current is greater than the microcontroller's drive current, about 70 milliamps peak-to-peak in this case.
The Base Unit uses a trick to increase the receiver's sensitivity. An adjustment is added to compensate for some of the comparator's offset. The smaller the offset voltage, the smaller the signal needed from the antenna to trip the comparator. Adjusting R1 causes the voltage drop across R3 of up to ± 60 millivolts, and this effectively compensates for offset voltages across the comparator input up to the maximum shown on the controller’s data sheet.
Increasing the sensitivity can be beneficial, but excessive sensitivity can lead to problems. When the offset is adjusted to near zero, noise from the microcontroller itself can cause the receiver to repeatedly detect false signals. Additionally, placing the base unit too close to a backlight power supply in a notebook computer may introduce interference. Not only does the RS-232 output send out corrupted data, but the noise can also interfere with the proper decoding of desired signals. The solution involves reducing the sensitivity adjustment to a level where the receiver remains stable.
The firmware for the terminal interface is compact. Its primary function is to check for incoming characters from the UART; if one is present, it sends it out via the Minimum Mass Wireless Coupler. Similarly, it checks the Minimum Mass Wireless Coupler for incoming characters and sends them out through the UART.
If an escape character is received from the terminal, the subsequent character is processed as a command. If the character following the escape character is another escape character, it is transmitted over the Minimum Mass Wireless Coupler. If the character following the escape character is an ASCII "e", local echo is toggled on and off, and a notification is displayed on the terminal screen. The "e" command is the only command recognized by this interpreter.
The overall design of the terminal interface and Base Unit emphasizes effective communication between a computer and devices equipped with the Minimum Mass Wireless Coupler, ensuring reliable data transmission and reception through careful consideration of component selection, circuit design, and firmware implementation. The RS-232 interface operates at a standard baud rate, while the antenna design enhances the range and performance of the wireless communication. The sensitivity adjustments and noise management strategies are critical for maintaining signal integrity in various operational environments.The purpose of the terminal interface is to allow my computer to communicate with Minimum Mass Wireless Coupler equipped devices using a terminal emulator program. Consequently, the Base Unit is basically an RS-232 interface and Minimum Mass Wireless Coupler. The Base Unit is the larger enclosure in Photo 1. The RS-232 interface to the computer is 9600 baud, 1 stop bit, no parity, plenty fast to keep up with the 1200 baud maximum data rate from the Coupler.
The antenna is made of 12 turns of #30 enameled wire threaded through metal guide loops arranged around the perimeter of the board (See the photograph.) This antenna's area is about 160% that of the prototype 5.5 cm loop so it has a little more range for both transmitting and receiving. To further increase the transmitter's range, I used 220 ohm bias resistors (See the schematic, Figure 4). This sets the maximum peak current from the microcontroller’s output pin at about 23 milliamps, safely below the maximum current specified on the microcontroller’s data sheet.
Since the antenna is resonant, the peak antenna current is greater than the microcontroller's drive current, about 70 milliamps peak-to-peak in this cae. The Base Unit uses a trick to increase the receiver's sensitivity. I added an adjustment to compensate for some of the comparator's offset. The smaller the offset voltage, the smaller the signal needed from the antenna to trip the comparator.
Adjusting R1 causes the voltage drop across R3 of up to ± 60 millivolts, and this effectively compensates for offset voltages across the comparator input up to the maximum shown on the controller’s data sheet. Increasing the sensitivity can be a good thing, but too much can be a problem. When the offset is adjusted to near zero, noise from the microcontroller itself causes the receiver to repeatedly detect false signals.
I've also noted that when I put the base unit too close to a backlight power supply in my notebook computer it picks up interference. Not only does the RS-232 output send out garbage, but the noise interferes with the desired signals from being properly decoded.
The solution is to back off on the sensitivity adjustment. to the point that the receiver is stable. The firmware for the terninal interface is very compact. All it does is to check for an incoming character from the UART if one is present, send it out the Minimum Mass Wireless Coupler, and check the Miniumu Mass Wireless Coupler for an incoming character, and if one is present, send it out the UART. If an escape character is received from the terminal, the following character is trapped and executed as a command.
If the character following the escape character is a second escape character, it is sent out over the Minimum Mass Wireless Coupler. If the character following the escape character is an ASCII "e", local echo is toggled on and off, and a notation is typed to the terminal screen.
The "e" command is the only command that this interpreter responds to.
To further increase the transmitter's range, 220-ohm bias resistors are used. This sets the maximum peak current from the microcontroller’s output pin at about 23 milliamps, safely below the maximum current specified on the microcontroller’s data sheet. Since the antenna is resonant, the peak antenna current is greater than the microcontroller's drive current, about 70 milliamps peak-to-peak in this case.
The Base Unit uses a trick to increase the receiver's sensitivity. An adjustment is added to compensate for some of the comparator's offset. The smaller the offset voltage, the smaller the signal needed from the antenna to trip the comparator. Adjusting R1 causes the voltage drop across R3 of up to ± 60 millivolts, and this effectively compensates for offset voltages across the comparator input up to the maximum shown on the controller’s data sheet.
Increasing the sensitivity can be beneficial, but excessive sensitivity can lead to problems. When the offset is adjusted to near zero, noise from the microcontroller itself can cause the receiver to repeatedly detect false signals. Additionally, placing the base unit too close to a backlight power supply in a notebook computer may introduce interference. Not only does the RS-232 output send out corrupted data, but the noise can also interfere with the proper decoding of desired signals. The solution involves reducing the sensitivity adjustment to a level where the receiver remains stable.
The firmware for the terminal interface is compact. Its primary function is to check for incoming characters from the UART; if one is present, it sends it out via the Minimum Mass Wireless Coupler. Similarly, it checks the Minimum Mass Wireless Coupler for incoming characters and sends them out through the UART.
If an escape character is received from the terminal, the subsequent character is processed as a command. If the character following the escape character is another escape character, it is transmitted over the Minimum Mass Wireless Coupler. If the character following the escape character is an ASCII "e", local echo is toggled on and off, and a notification is displayed on the terminal screen. The "e" command is the only command recognized by this interpreter.
The overall design of the terminal interface and Base Unit emphasizes effective communication between a computer and devices equipped with the Minimum Mass Wireless Coupler, ensuring reliable data transmission and reception through careful consideration of component selection, circuit design, and firmware implementation. The RS-232 interface operates at a standard baud rate, while the antenna design enhances the range and performance of the wireless communication. The sensitivity adjustments and noise management strategies are critical for maintaining signal integrity in various operational environments.The purpose of the terminal interface is to allow my computer to communicate with Minimum Mass Wireless Coupler equipped devices using a terminal emulator program. Consequently, the Base Unit is basically an RS-232 interface and Minimum Mass Wireless Coupler. The Base Unit is the larger enclosure in Photo 1. The RS-232 interface to the computer is 9600 baud, 1 stop bit, no parity, plenty fast to keep up with the 1200 baud maximum data rate from the Coupler.
The antenna is made of 12 turns of #30 enameled wire threaded through metal guide loops arranged around the perimeter of the board (See the photograph.) This antenna's area is about 160% that of the prototype 5.5 cm loop so it has a little more range for both transmitting and receiving. To further increase the transmitter's range, I used 220 ohm bias resistors (See the schematic, Figure 4). This sets the maximum peak current from the microcontroller’s output pin at about 23 milliamps, safely below the maximum current specified on the microcontroller’s data sheet.
Since the antenna is resonant, the peak antenna current is greater than the microcontroller's drive current, about 70 milliamps peak-to-peak in this cae. The Base Unit uses a trick to increase the receiver's sensitivity. I added an adjustment to compensate for some of the comparator's offset. The smaller the offset voltage, the smaller the signal needed from the antenna to trip the comparator.
Adjusting R1 causes the voltage drop across R3 of up to ± 60 millivolts, and this effectively compensates for offset voltages across the comparator input up to the maximum shown on the controller’s data sheet. Increasing the sensitivity can be a good thing, but too much can be a problem. When the offset is adjusted to near zero, noise from the microcontroller itself causes the receiver to repeatedly detect false signals.
I've also noted that when I put the base unit too close to a backlight power supply in my notebook computer it picks up interference. Not only does the RS-232 output send out garbage, but the noise interferes with the desired signals from being properly decoded.
The solution is to back off on the sensitivity adjustment. to the point that the receiver is stable. The firmware for the terninal interface is very compact. All it does is to check for an incoming character from the UART if one is present, send it out the Minimum Mass Wireless Coupler, and check the Miniumu Mass Wireless Coupler for an incoming character, and if one is present, send it out the UART. If an escape character is received from the terminal, the following character is trapped and executed as a command.
If the character following the escape character is a second escape character, it is sent out over the Minimum Mass Wireless Coupler. If the character following the escape character is an ASCII "e", local echo is toggled on and off, and a notation is typed to the terminal screen.
The "e" command is the only command that this interpreter responds to.
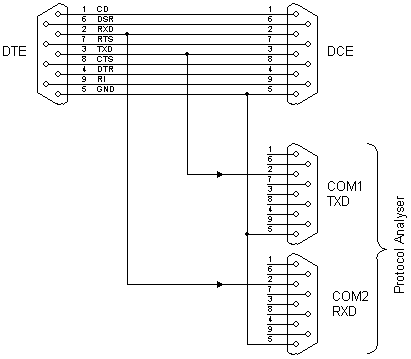
RS-232 Protocol Analyser Y Cable
In need for a cheap but effective RS-232 Protocol Analyser? Just make your own Y adaptor to enable the logging or display of data transmitted and/or received in ASCII, Hex, Decimal or Hex-Dump formats. A configuration file is included to...
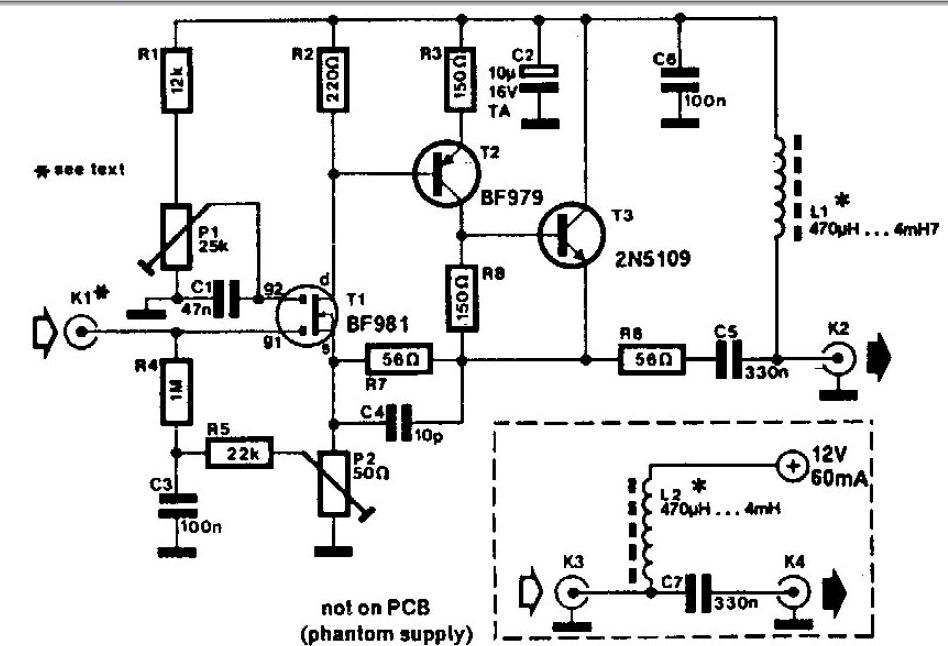
Wideband Active Antenna Circuit
A whip antenna measuring between 30 to 50 cm is capable of receiving signals from 10 MHz to over 220 MHz. The circuit incorporates a BF981 dual-gate MOSFET (T1), which offers low noise characteristics, high input impedance, and enhanced performance.
The...
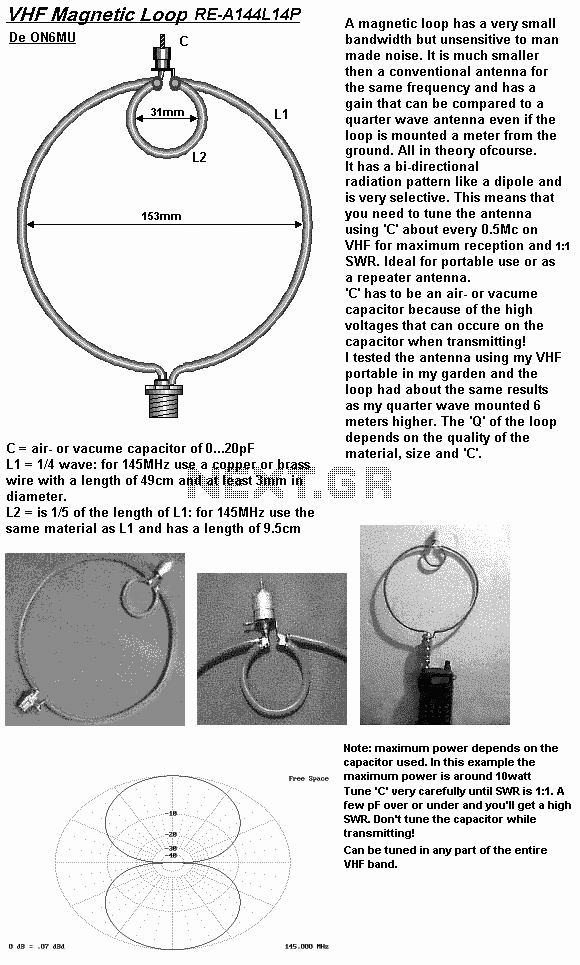
loop antennas
A loop antenna is a radio antenna made up of a loop (or loops) of wire, tubing, or other electrical conductor with its ends connected to a balanced transmission line. This design includes two distinct types of antennas: the small...
Q- Multiplying Loop Antenna
This circuit is designed to be used in conjunction with the standard 4 foot square loop used in MW for long distance reception.
The described circuit is intended for use with a standard 4-foot square loop antenna, optimized for medium wave...
Active Antenna
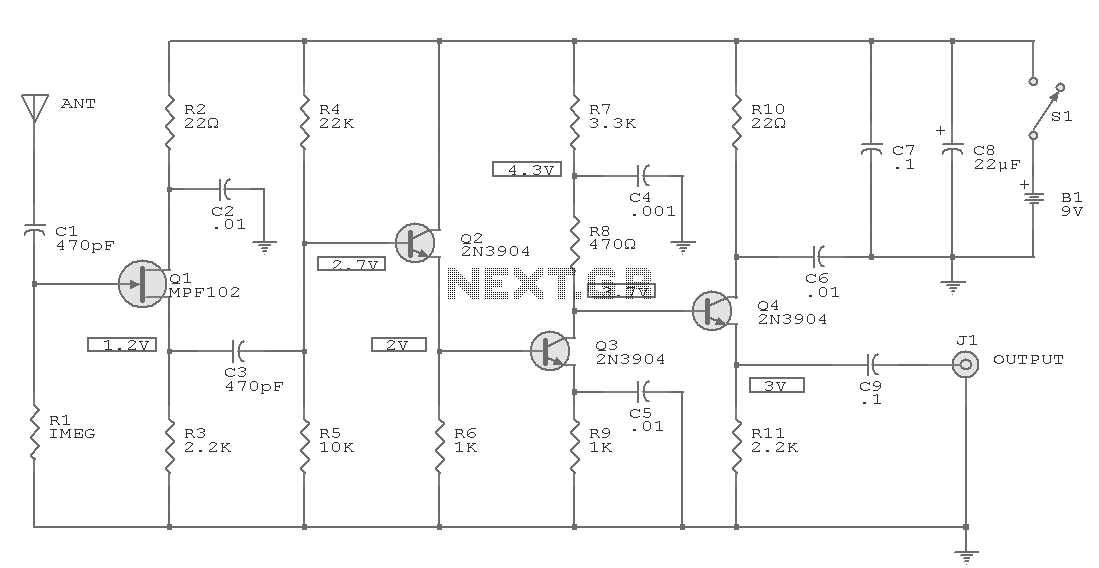
Antennas that are much shorter than 1/4 wavelength present a very small and highly relative impedance that is dependent on the received frequency. It is difficult to match impedances over a decade of frequency coverage. Instead, input stage Q1 is...
Wireless-fm-microphone
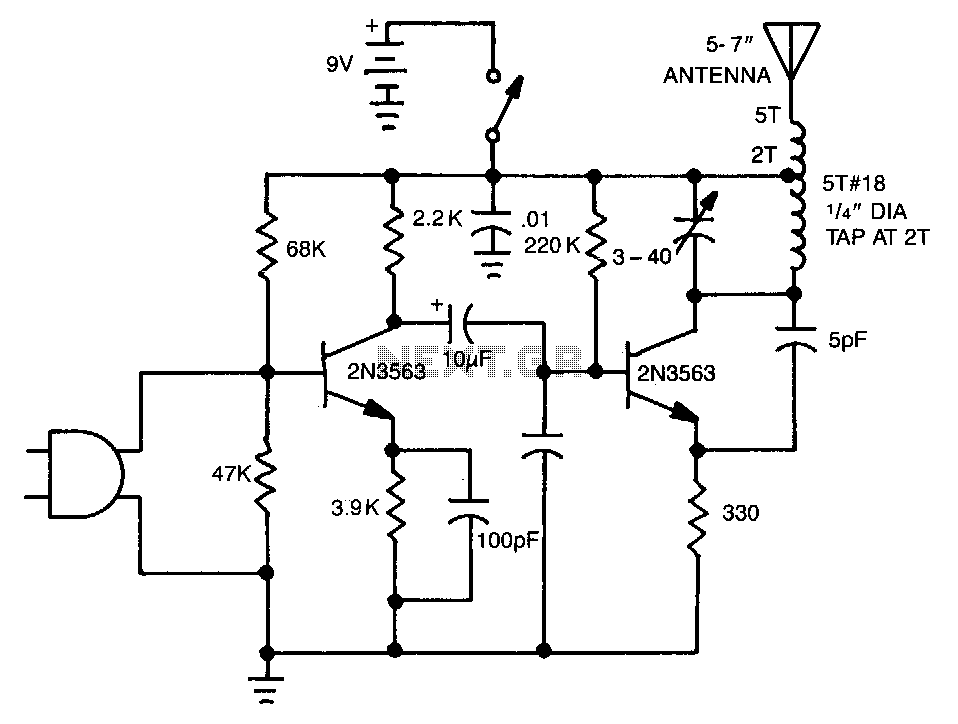
Utilize standard RF wiring precautions. Optimal speech clarity is achieved by employing an electret microphone. For music reproduction, replace it with a dynamic microphone element.
In the design of audio circuits, particularly those involving speech and music, the choice of microphone...
One kind of wireless remote control circuit
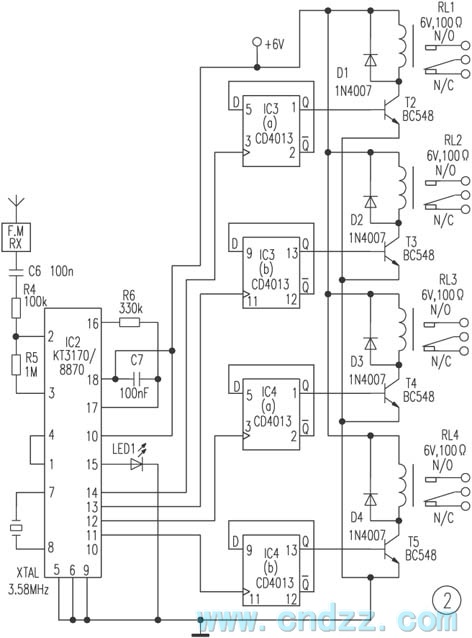
The remote control transmitter consists of a DTMF generator and an FM transmitter circuit. A UM91214B phone-specific integrated circuit (IC) is utilized to generate the DTMF signal, with a 3V power supply provided by a 3V zener diode (D1). The...
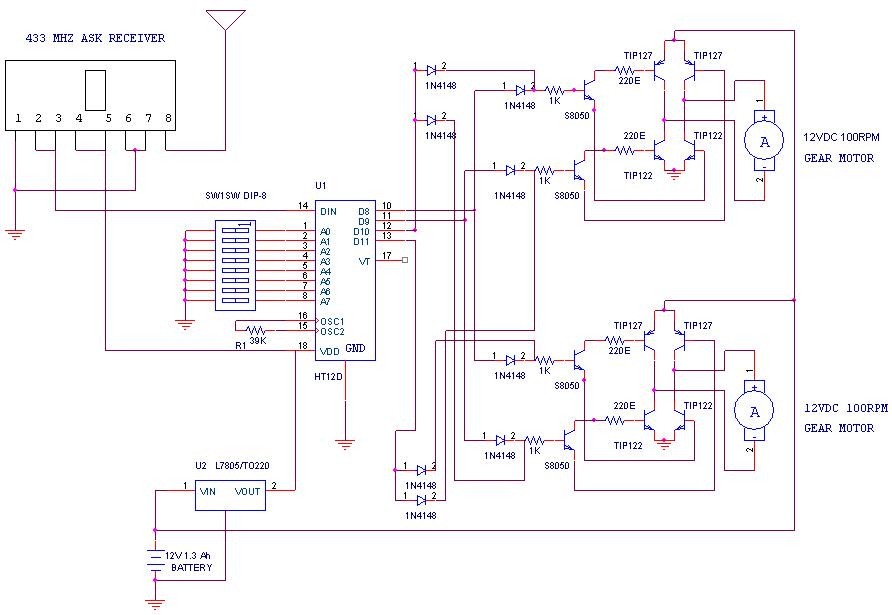
Remote Operated Spy Robot Circuit
A remote-operated spy robot circuit can be controlled using a wireless remote controller. It captures audio and video information from the surroundings and transmits this data to a remote station via RF signals, with a maximum range of 125 meters,...
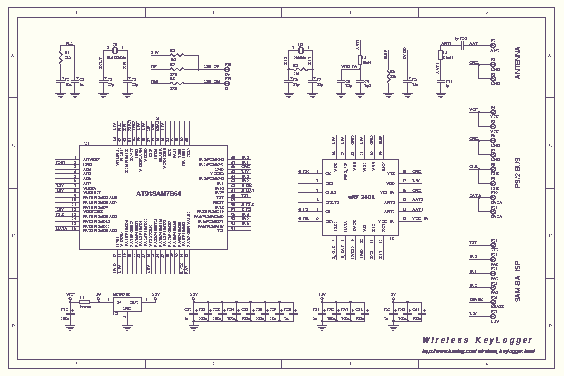
Wireless Keylogger circuit
The Wireless Keylogger consists of two main building blocks: the transmitter and the receiver. The actual keylogging takes place in the transmitter, which is in fact a PS/2 hardware keylogger, with a built-in 2.4 GHz wireless module. Captured keystroke data...