


SPI
#SPI
#serial bus
#data transmission
#clock frequency
#microcontroller
#digital communication
#embedded systems
#peripheral interface
#protocol
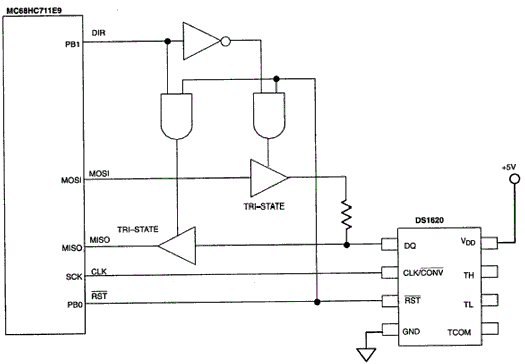
Description: Increasingly, serial bus systems are favored over parallel buses due to their simpler wiring. As the efficiency of serial buses improves, the speed advantage of parallel data transmission becomes less significant. SPI devices can operate at clock frequencies reaching several megahertz and are suitable for numerous applications where serial transmission suffices. The use of SPI extends beyond measurement applications and includes audio transmission. The term SPI, coined by Motorola, is also known as Microwire, a trademark of National Semiconductor, both of which share the same functionality. Extensions such as QSPI (Queued Serial Peripheral Interface) and MicrowirePLUS are also available. Synchronous interfaces are distinguished by the presence of a dedicated clock signal for receiving and transmitting data. A "Master" device generates a clock signal that is utilized by all "Slave" devices for synchronized data exchange. This arrangement allows each device to operate with the master’s clock, independent of individual oscillator variations, making these interfaces suitable for use with low-cost oscillators that may have significant frequency variations. Examples of synchronous interfaces include SPI (Serial Peripheral Interface) developed by Motorola, MICROWIRE from National Semiconductor, I2C (Inter-Integrated Circuit) developed by Philips/Signetics, and USART (Universal Synchronous & Asynchronous Receiver Transmitter), which can function in either synchronous or asynchronous modes. Synchronous interfaces are primarily designed to connect peripheral devices on the same circuit board, such as external EEPROMs, A/D converters, display drivers, and sensors to microcontrollers, and are typically limited to short distances (less than 1 meter). Various types of peripherals can be connected to the host processor, categorized by converters with different resolutions, clock frequencies, and channel counts, ranging from 8 to 24 bits with clock frequencies from 30 ksps to 600 ksps. Memory devices mainly consist of EEPROM variants and some SPI flash memories, with capacities from a few bits to 64 Kbits and clock frequencies up to 3 MHz. Serial EEPROMs using SPI are available for various supply voltages (2.7V to 5V), suitable for low-voltage applications, with data retention times of 10 to 100 years and a maximum of 1 million write cycles for most components. By cascading memory devices, any number of bits/word can be achieved. Real-Time Clocks (RTCs) are particularly suitable for serial communication due to the small data transfer requirements. A wide variety of RTCs are available with supply voltages starting from 2.0V. In addition to standard clock functions, some RTCs offer alarm functions and non-volatile RAM. Most RTCs are manufactured by DALLAS and EPSON. CAN and USB controllers utilizing SPI facilitate the use of these protocols on microcontrollers, and interfacing an LCD via SPI simplifies wiring compared to parallel connections. SPI lacks an acknowledgment mechanism to confirm data receipt; therefore, the SPI master has no awareness of the existence of a slave device. Additionally, SPI does not support flow control, which may necessitate external solutions for hardware flow control. Slaves can be regarded as input/output devices of the master. SPI does not define a specific higher-level protocol for master-slave communication, which may be adequate for applications where only raw data exchange occurs, such as interfacing with a simple codec. In other cases, a higher-level protocol, like a command-response protocol, may be required.
The Serial Peripheral Interface (SPI) is a synchronous serial communication protocol designed for short-distance communication, primarily used for connecting microcontrollers to various peripheral devices. The architecture of SPI consists of a master device that controls one or more slave devices. The master generates a clock signal that synchronizes data transfer, ensuring that both the master and slave devices operate in lockstep. This clocking mechanism is critical for maintaining data integrity and timing, especially when dealing with devices that may have different internal clock frequencies.
SPI operates on four primary lines: Master Out Slave In (MOSI), Master In Slave Out (MISO), Serial Clock (SCK), and Chip Select (CS). MOSI is used for data transmission from the master to the slave, while MISO is used for data transmission from the slave back to the master. SCK is the clock line generated by the master, and CS is used to select which slave device is active during communication. This selection is essential when multiple slaves are connected to the same SPI bus, as it prevents data collisions and ensures that only one device responds to the master at any given time.
The flexibility of SPI allows it to support a wide range of data formats and speeds, making it suitable for various applications. The maximum clock frequency can vary based on the specific devices used in the communication, with many SPI devices capable of operating at several megahertz. This high-speed capability makes SPI an attractive choice for applications requiring rapid data transfer, such as video processing, sensor data acquisition, and audio streaming.
In terms of device compatibility, SPI can interface with numerous types of peripherals, including ADCs, DACs, EEPROMs, and sensors. The ability to cascade multiple devices on the same bus enhances the versatility of SPI, allowing for complex configurations without the need for extensive wiring. Additionally, the protocol's simplicity means that it can be implemented in both hardware and software, providing developers with options depending on their specific requirements and constraints.
Despite its advantages, SPI does have limitations. The lack of an acknowledgment mechanism means that the master cannot confirm whether data has been successfully received by the slave. This can be mitigated by implementing higher-level protocols or error-checking mechanisms in the application layer. Furthermore, SPI's reliance on short-distance communication limits its use in applications requiring long-range data transfer, where other protocols like I2C or CAN may be more appropriate.
Overall, the SPI protocol remains a robust and efficient option for synchronous serial communication, particularly in environments where high-speed data transfer and simplicity are paramount. Its widespread adoption across various industries underscores its effectiveness in meeting the needs of modern electronic systems.More and more serial bus systems are preferred instead of a parallel bus, because of the simpler wiring. As the efficiency of serial buses increases, the speed advantage of the parallel data transmission gets less important.
The clock frequencies of SPI devices can go up to some Megahertz and more. There are a lot of application where a serial tra nsmission is perfectly sufficient. The usage of SPI is not limited to the measuring area, also in the audio field this type of transmission is used. The SPI (this name was created by Motorola) is also known as Microwire, trade mark of National Semiconductor.
Both have the same functionality. There are also the extensions QSPI (Queued Serial Peripheral Interface) and MicrowirePLUS. Synchronous interfaces are characterized by the presence of a dedicated receive/transmit clock signal. A "Master" device usually outputs a clock signal that is received by all "Slave" devices to receive and transmit data in synch.
The advantage: Each device works with the transmit/receive clock of the master independent of any oscillator variations of each individual device; so these interfaces are very suitable for use with cheap oscillators that have large frequency variations Examples of synchronous interfaces are: SPI (Serial Peripheral Interface), developed by Motorola, MICROWIRE developed by National Semiconductor, I2C (Inter Integrated Circuit) developed by Philips/Signetics, and USART (Universal Synchronous & Asynchronous Receiver Transmitter) - as the name suggests a USART can either be used in a synchronous or asynchronous mode, so it falls into both categories. Synchronous interfaces were designed mainly to connect peripheral devices on the same circuit board, like external EEPROMS, A/D converters, display drivers and sensors to microcontrollers.
They are only suitable to bridge relatively short distances (< 1 meter). The question is of course, which peripheral types exist and which can be connected to the host processor. Peripheral types can be subdivided into the following categories: There are lots of converters with different resolutions, clock frequencies and number of channels to choose from.
8, 10, 12 up to 24Bit with clock frequencies from 30ksps up to 600ksps. Memory devices are mostly EEPROM variants. There are also a few SPI flash memories. Capacities range from a couple of bits up to 64KBit. Clock frequencies up to 3MHz. Serial EEPROMS SPI are available for different supply voltages (2. 7V to 5V) allowing their use in low-voltage applications. The data retention time duration from 10 years to 100 years. The permitted number of write accesses is 1 million cycles for most components. By cascading memory devices any number of bits/word can be obtained. RTCs are ideally suited for serial communication because only small amounts of data have to be transferred. There is also a great variety of RTCs with supply voltages from 2. 0V. In addition to the standard functions of a "normal" clock, some RTCs offer an alarm function, non-volatile RAM etc.
Most RTCs come from DALLAS and EPSON. CAN and USB controllers with SPI make it easier to use these protocols on a micro controller and inerfacing a LCD via SPI saves the troublesome parallel wiring. SPI does not have an acknowledgement mechanism to confirm receipt of data. In fact, without a communication protocol, the SPI master has no knowledge of whether a slave even exists.
SPI also offers no flow control. If you need hardware flow control, you might need to do something outside of SPI. Slaves can be thought of as input/output devices of the master. SPI does not specify a particular higher-level protocol for master-slave dialog. In some applications, a higher-level protocol is not needed and only raw data are exchanged. An example of this is an interface to a simple codec. In other applications, a higher-level protocol, such as a command-response protocol, may be necessary. Note that
The Serial Peripheral Interface (SPI) is a synchronous serial communication protocol designed for short-distance communication, primarily used for connecting microcontrollers to various peripheral devices. The architecture of SPI consists of a master device that controls one or more slave devices. The master generates a clock signal that synchronizes data transfer, ensuring that both the master and slave devices operate in lockstep. This clocking mechanism is critical for maintaining data integrity and timing, especially when dealing with devices that may have different internal clock frequencies.
SPI operates on four primary lines: Master Out Slave In (MOSI), Master In Slave Out (MISO), Serial Clock (SCK), and Chip Select (CS). MOSI is used for data transmission from the master to the slave, while MISO is used for data transmission from the slave back to the master. SCK is the clock line generated by the master, and CS is used to select which slave device is active during communication. This selection is essential when multiple slaves are connected to the same SPI bus, as it prevents data collisions and ensures that only one device responds to the master at any given time.
The flexibility of SPI allows it to support a wide range of data formats and speeds, making it suitable for various applications. The maximum clock frequency can vary based on the specific devices used in the communication, with many SPI devices capable of operating at several megahertz. This high-speed capability makes SPI an attractive choice for applications requiring rapid data transfer, such as video processing, sensor data acquisition, and audio streaming.
In terms of device compatibility, SPI can interface with numerous types of peripherals, including ADCs, DACs, EEPROMs, and sensors. The ability to cascade multiple devices on the same bus enhances the versatility of SPI, allowing for complex configurations without the need for extensive wiring. Additionally, the protocol's simplicity means that it can be implemented in both hardware and software, providing developers with options depending on their specific requirements and constraints.
Despite its advantages, SPI does have limitations. The lack of an acknowledgment mechanism means that the master cannot confirm whether data has been successfully received by the slave. This can be mitigated by implementing higher-level protocols or error-checking mechanisms in the application layer. Furthermore, SPI's reliance on short-distance communication limits its use in applications requiring long-range data transfer, where other protocols like I2C or CAN may be more appropriate.
Overall, the SPI protocol remains a robust and efficient option for synchronous serial communication, particularly in environments where high-speed data transfer and simplicity are paramount. Its widespread adoption across various industries underscores its effectiveness in meeting the needs of modern electronic systems.More and more serial bus systems are preferred instead of a parallel bus, because of the simpler wiring. As the efficiency of serial buses increases, the speed advantage of the parallel data transmission gets less important.
The clock frequencies of SPI devices can go up to some Megahertz and more. There are a lot of application where a serial tra nsmission is perfectly sufficient. The usage of SPI is not limited to the measuring area, also in the audio field this type of transmission is used. The SPI (this name was created by Motorola) is also known as Microwire, trade mark of National Semiconductor.
Both have the same functionality. There are also the extensions QSPI (Queued Serial Peripheral Interface) and MicrowirePLUS. Synchronous interfaces are characterized by the presence of a dedicated receive/transmit clock signal. A "Master" device usually outputs a clock signal that is received by all "Slave" devices to receive and transmit data in synch.
The advantage: Each device works with the transmit/receive clock of the master independent of any oscillator variations of each individual device; so these interfaces are very suitable for use with cheap oscillators that have large frequency variations Examples of synchronous interfaces are: SPI (Serial Peripheral Interface), developed by Motorola, MICROWIRE developed by National Semiconductor, I2C (Inter Integrated Circuit) developed by Philips/Signetics, and USART (Universal Synchronous & Asynchronous Receiver Transmitter) - as the name suggests a USART can either be used in a synchronous or asynchronous mode, so it falls into both categories. Synchronous interfaces were designed mainly to connect peripheral devices on the same circuit board, like external EEPROMS, A/D converters, display drivers and sensors to microcontrollers.
They are only suitable to bridge relatively short distances (< 1 meter). The question is of course, which peripheral types exist and which can be connected to the host processor. Peripheral types can be subdivided into the following categories: There are lots of converters with different resolutions, clock frequencies and number of channels to choose from.
8, 10, 12 up to 24Bit with clock frequencies from 30ksps up to 600ksps. Memory devices are mostly EEPROM variants. There are also a few SPI flash memories. Capacities range from a couple of bits up to 64KBit. Clock frequencies up to 3MHz. Serial EEPROMS SPI are available for different supply voltages (2. 7V to 5V) allowing their use in low-voltage applications. The data retention time duration from 10 years to 100 years. The permitted number of write accesses is 1 million cycles for most components. By cascading memory devices any number of bits/word can be obtained. RTCs are ideally suited for serial communication because only small amounts of data have to be transferred. There is also a great variety of RTCs with supply voltages from 2. 0V. In addition to the standard functions of a "normal" clock, some RTCs offer an alarm function, non-volatile RAM etc.
Most RTCs come from DALLAS and EPSON. CAN and USB controllers with SPI make it easier to use these protocols on a micro controller and inerfacing a LCD via SPI saves the troublesome parallel wiring. SPI does not have an acknowledgement mechanism to confirm receipt of data. In fact, without a communication protocol, the SPI master has no knowledge of whether a slave even exists.
SPI also offers no flow control. If you need hardware flow control, you might need to do something outside of SPI. Slaves can be thought of as input/output devices of the master. SPI does not specify a particular higher-level protocol for master-slave dialog. In some applications, a higher-level protocol is not needed and only raw data are exchanged. An example of this is an interface to a simple codec. In other applications, a higher-level protocol, such as a command-response protocol, may be necessary. Note that
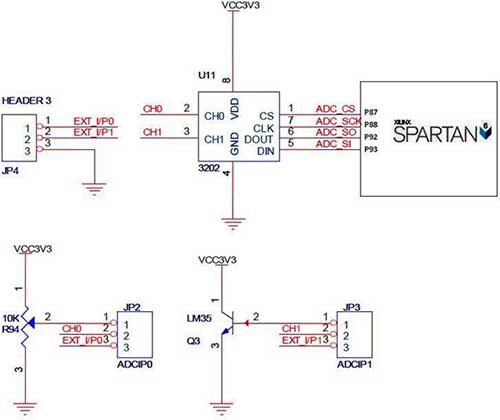
interfacing spi adc with spartan 6 fpga
The Spartan-6 board features a 2-channel, 12-bit SPI ADC, as shown in the accompanying figure. In synchronous serial communication, a clock line (SCK in the case of SPI) is used to synchronize data transfer, with the clock being controlled by...
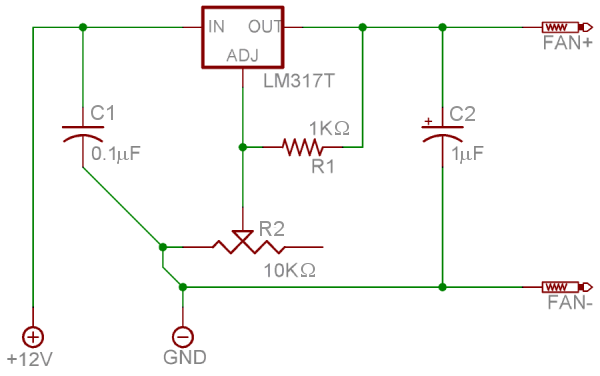
Robo Atmega328p project
This project was designed to introduce a friend to microcontrollers and circuits using various functionalities and spare parts. A PS2 numpad was utilized as the key entry mechanism, which was found at a thrift store and included the necessary connector....
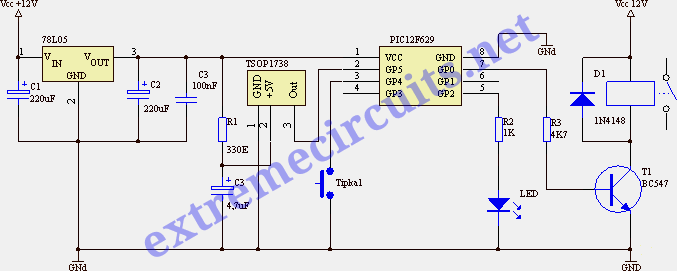
IR On/Off Switch Using Microcontroller
Turning electrical devices ON or OFF using a remote control is a well-established concept, with numerous devices available that perform this function effectively. To create such a device, it is necessary to construct a receiver and a transmitter, as well...
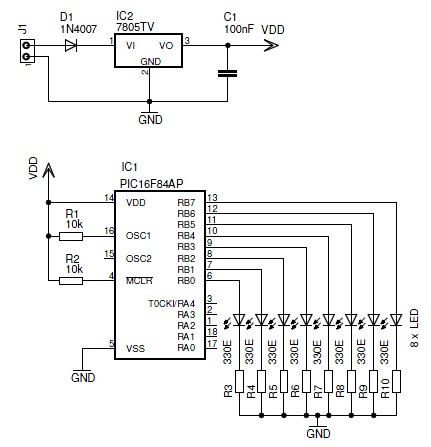
knight Rider
A light computer has been developed that simulates the scanning effect seen in the KITT car from the TV series Knight Rider. The design utilizes a microcontroller, specifically the PIC16F84A, instead of the commonly used CD4017 counter IC. This choice...
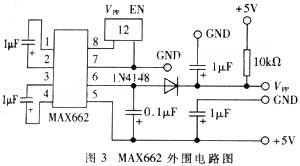
The embedded microcontroller MC68HC912B32 background debugs the mode to design
The widespread application of Flash technology in microprocessors has led to significant advancements in the development and utilization of one-chip computers. Designers have transitioned from traditional in-circuit emulators (ICE) and JTAG interfaces to more cost-effective and user-friendly development methods. While...
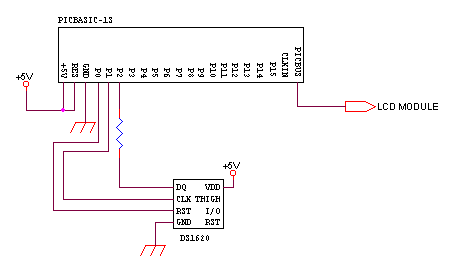
spi circuit
SPI Integrated Circuit Bus, IC Buses, an IC, Chip-to-Chip Bus Serial Peripheral Interface, Integrated Circuit Bus types, and IC Bus Electrical Interface Descriptions. Peripheral Interface (SPI) circuit is a.
The Serial Peripheral Interface (SPI) is a synchronous serial communication protocol...
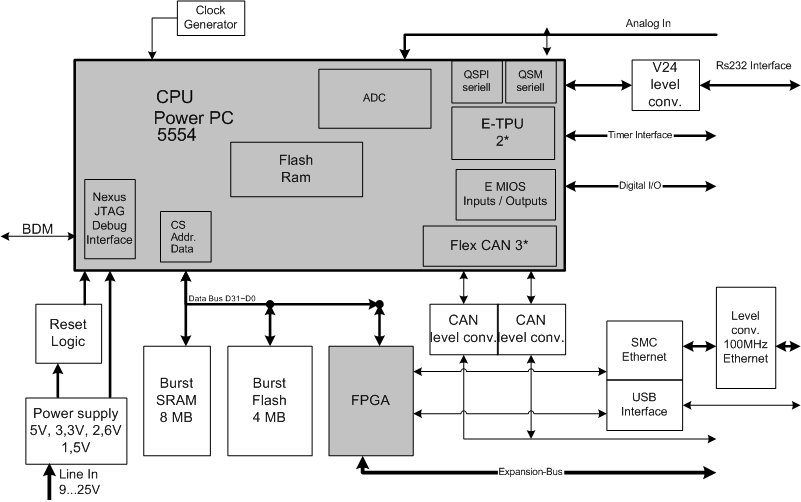
Electronics Engineering Herald - online magazine of electronics -home
Embedded systems serve as the core of most electronics-based systems, enabling data access, processing, storage, and control. While some simple electronic circuits can be designed without a microprocessor or microcontroller, this approach is often economically impractical, except for basic passive...
Exploring Microcontrollers
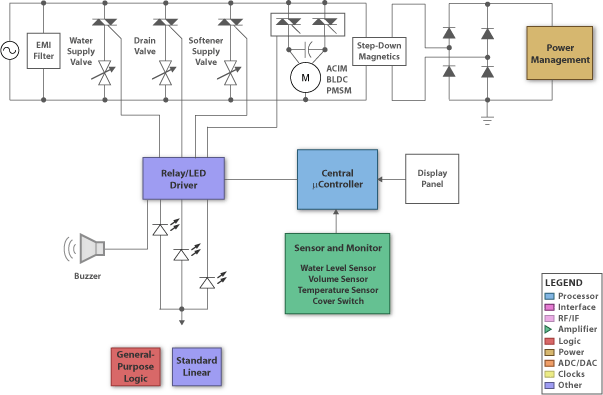
Many of today's appliances feature displays and buttons. Instead of relying on motors and gears, numerous household items now incorporate embedded microcontrollers. This exploration focuses on how to experiment with microcontrollers at home.
Microcontrollers serve as the central processing units for...
Carrier-Current Receiver For Data Transmission
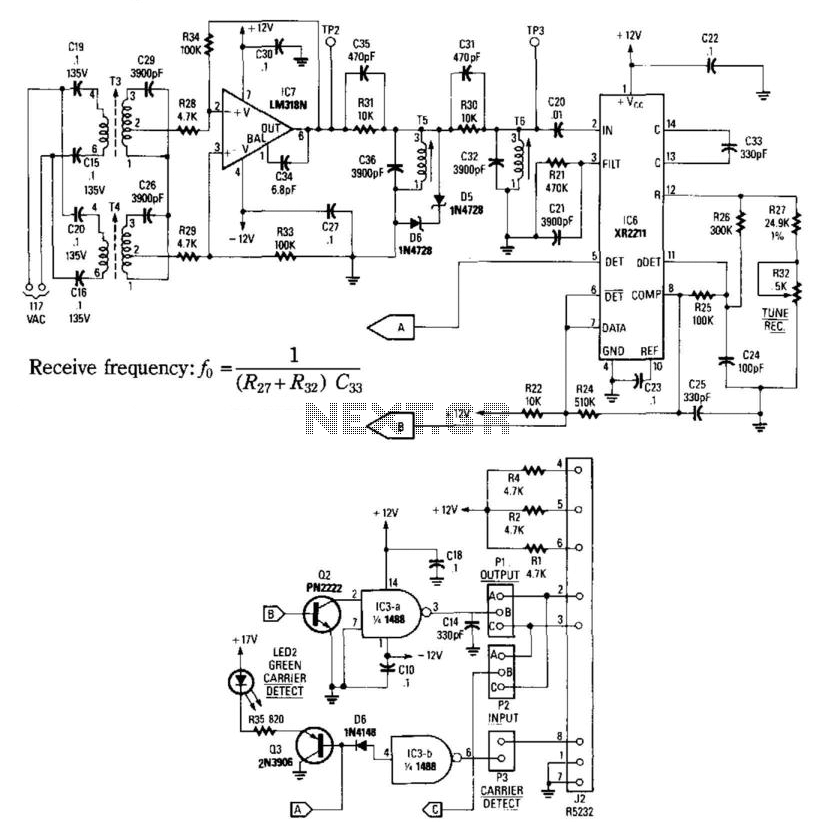
This receiver consists of an input network, amplifier IC7, FSK PLL detector IC8, and output amplifier/interface circuits Q2, Q3, IC3A, and IC3B, which include a 1488 Quad RS232 line driver for the carrier-current signal. The tuned amplifier IC7 amplifies this...