


vehicle tracking
Description: This project involves the design of an embedded system for tracking and positioning vehicles using the Global Positioning System (GPS) and the Global System for Mobile Communications (GSM). When a user sends a request to the number associated with the modem, the system automatically replies with the vehicle's position. The design employs an ATmega16 microcontroller to interface with various hardware peripherals. The current application is an embedded system that reports the vehicle's status on demand. An ATmega16 microcontroller is connected to a GSM modem and a GPS receiver. The GSM modem is responsible for sending the vehicle's position from a remote location. It continuously monitors for incoming SMS requests. If the request is from a valid mobile number (verified through the SMS content, which includes a password), the GPS modem is activated, providing data such as latitude and longitude to indicate the vehicle's location. Although the GPS modem outputs multiple parameters, only the NMEA data is processed. This data is then converted to determine the location name of the vehicle. The processed information, including the location name and time, is sent back to the requesting mobile device.
The embedded vehicle tracking system is designed to provide real-time location updates through a seamless integration of GPS and GSM technologies. The ATmega16 microcontroller serves as the central processing unit, coordinating the interactions between the GSM modem and the GPS receiver. The system architecture includes the following components:
1. **ATmega16 Microcontroller**: This microcontroller is responsible for processing incoming SMS requests and controlling the overall operation of the embedded system. It executes the logic for validating incoming messages, activating the GPS module, and formatting the response data.
2. **GSM Modem**: The GSM modem is essential for communication with the user. It continuously listens for SMS requests. Upon receiving a valid request, it triggers the GPS receiver to obtain the current location coordinates. The modem's ability to send and receive SMS messages enables remote monitoring of the vehicle's position.
3. **GPS Receiver**: This component provides accurate geographical coordinates (latitude and longitude) of the vehicle. It outputs NMEA formatted data, which includes various parameters. The system is designed to parse this data to extract the necessary location information.
4. **Power Supply**: The entire system requires a stable power supply to ensure reliable operation. This may involve a battery backup to maintain functionality during vehicle operation.
5. **Software Logic**: The embedded software running on the ATmega16 microcontroller includes routines for parsing SMS messages, validating user credentials, activating the GPS module, and formatting the output data for transmission back to the user.
The system's operation begins when a user sends an SMS to the GSM modem. Upon receiving the message, the ATmega16 microcontroller checks for the correct password. If the authentication is successful, the GPS receiver is activated, and it begins to provide location data. The microcontroller processes this data, retrieves the latitude and longitude, and converts these coordinates into a human-readable location name using geocoding techniques. Finally, the formatted location information is sent back to the user's mobile device, providing timely updates on the vehicle's status.
This embedded vehicle tracking system is particularly useful for fleet management, personal vehicle tracking, and any application requiring real-time location monitoring. Its design emphasizes reliability, user authentication, and efficient communication, ensuring that users receive accurate information about their vehicles' whereabouts.In this Project we have designed an embedded system which is used for tracking and positioning of any vehicle by using Global Positioning System (GPS) and Global system for mobile communication (GSM). When the request by user is sent to the number at the modem, the system automatically sends a return reply to that mobile indicating the position of
the vehicle. In this project ATmega16 microcontroller is used for interfacing to various hardware peripherals. The current design is an embedded application, which will report the status of the Vehicle on demand. For doing so an ATmega16 microcontroller is interfaced to a GSM Modem and GPS Receiver. A GSM modem is used to send the position of the vehicle from a remote place. This modem continuously waits for a request SMS. If it is from a valid mobile number(checked with the content of the SMS, which means a password), the GPS modem gets activated and it then continuously gives the data i.
e. the latitude and longitude indicating the position of the vehicle. The GPS modem gives many parameters as the output, but only the NMEA data coming out is read. Then only the latitude and longitude is converted to find out the name of the location of the vehicle. The converted data including the location name, time etc. is sent to the mobile at the other end from where the position of the vehicle is demanded.
The embedded vehicle tracking system is designed to provide real-time location updates through a seamless integration of GPS and GSM technologies. The ATmega16 microcontroller serves as the central processing unit, coordinating the interactions between the GSM modem and the GPS receiver. The system architecture includes the following components:
1. **ATmega16 Microcontroller**: This microcontroller is responsible for processing incoming SMS requests and controlling the overall operation of the embedded system. It executes the logic for validating incoming messages, activating the GPS module, and formatting the response data.
2. **GSM Modem**: The GSM modem is essential for communication with the user. It continuously listens for SMS requests. Upon receiving a valid request, it triggers the GPS receiver to obtain the current location coordinates. The modem's ability to send and receive SMS messages enables remote monitoring of the vehicle's position.
3. **GPS Receiver**: This component provides accurate geographical coordinates (latitude and longitude) of the vehicle. It outputs NMEA formatted data, which includes various parameters. The system is designed to parse this data to extract the necessary location information.
4. **Power Supply**: The entire system requires a stable power supply to ensure reliable operation. This may involve a battery backup to maintain functionality during vehicle operation.
5. **Software Logic**: The embedded software running on the ATmega16 microcontroller includes routines for parsing SMS messages, validating user credentials, activating the GPS module, and formatting the output data for transmission back to the user.
The system's operation begins when a user sends an SMS to the GSM modem. Upon receiving the message, the ATmega16 microcontroller checks for the correct password. If the authentication is successful, the GPS receiver is activated, and it begins to provide location data. The microcontroller processes this data, retrieves the latitude and longitude, and converts these coordinates into a human-readable location name using geocoding techniques. Finally, the formatted location information is sent back to the user's mobile device, providing timely updates on the vehicle's status.
This embedded vehicle tracking system is particularly useful for fleet management, personal vehicle tracking, and any application requiring real-time location monitoring. Its design emphasizes reliability, user authentication, and efficient communication, ensuring that users receive accurate information about their vehicles' whereabouts.In this Project we have designed an embedded system which is used for tracking and positioning of any vehicle by using Global Positioning System (GPS) and Global system for mobile communication (GSM). When the request by user is sent to the number at the modem, the system automatically sends a return reply to that mobile indicating the position of
the vehicle. In this project ATmega16 microcontroller is used for interfacing to various hardware peripherals. The current design is an embedded application, which will report the status of the Vehicle on demand. For doing so an ATmega16 microcontroller is interfaced to a GSM Modem and GPS Receiver. A GSM modem is used to send the position of the vehicle from a remote place. This modem continuously waits for a request SMS. If it is from a valid mobile number(checked with the content of the SMS, which means a password), the GPS modem gets activated and it then continuously gives the data i.
e. the latitude and longitude indicating the position of the vehicle. The GPS modem gives many parameters as the output, but only the NMEA data coming out is read. Then only the latitude and longitude is converted to find out the name of the location of the vehicle. The converted data including the location name, time etc. is sent to the mobile at the other end from where the position of the vehicle is demanded.
gps voice interface circuitry
The yellow wires on the far right serve as temporary power connections, allowing battery power to enter through the contact studs located in the large holes that press against the radio's battery terminals. The cable in the lower right is...
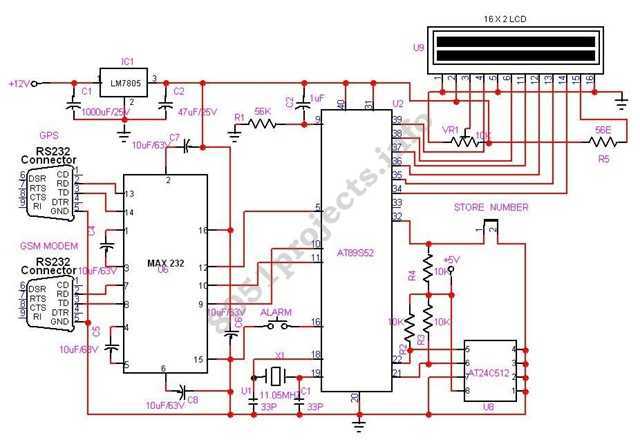
Tracking System using GPS and GSM modem
In this project AT89S52 microcontroller is used for interfacing to various hardware peripherals. The current design is an embedded application, which will continuously monitor a moving Vehicle and report the status of the Vehicle on demand. For doing so an...
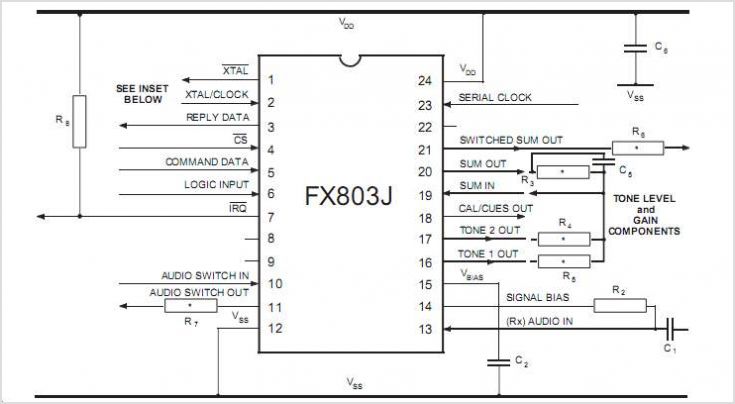
FX803 Signalling Processor
The CMX469A is a single-chip CMOS LSI circuit that functions as a full-duplex modem, supporting baud rates of 1200, 2400, or 4800. The mark and space frequencies for this modem are 1200/1800 Hz, 1200/2400 Hz, and 2400/4800 Hz, respectively. The...
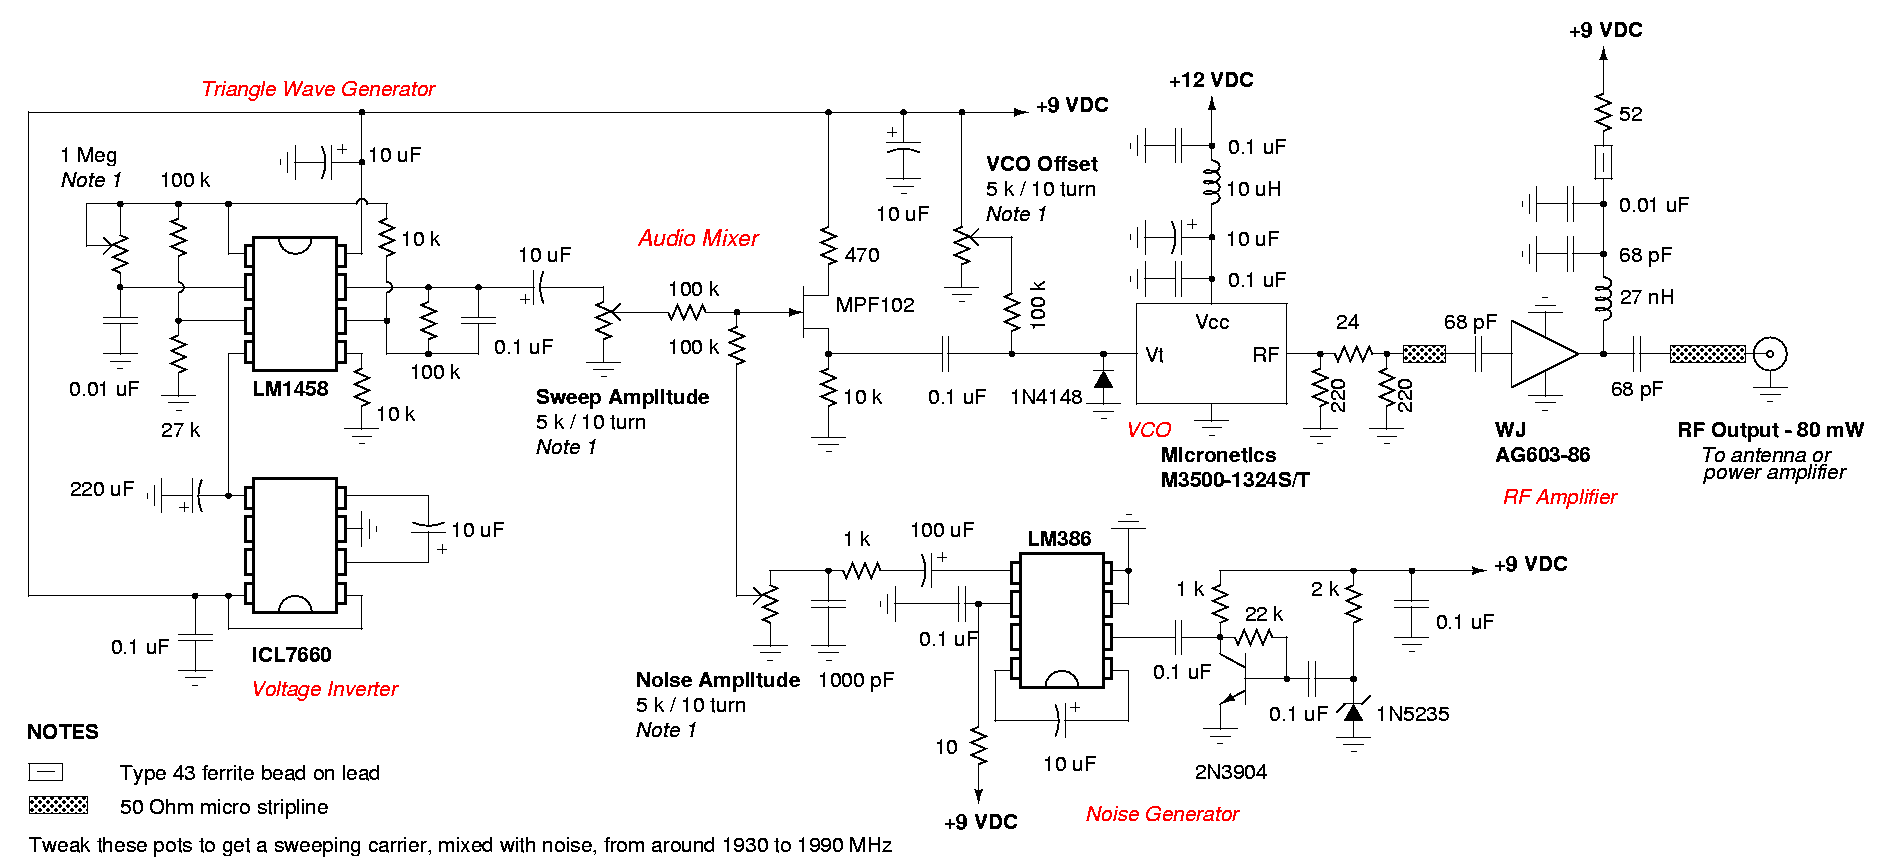
Cell Phone Jammer Circuit
A DIY GSM jammer schematic diagram designed for use with GSM1900, operating within the frequency range of 1930 MHz to 1990 MHz.
The GSM jammer circuit is intended to disrupt communication between mobile phones and base stations within the specified frequency...
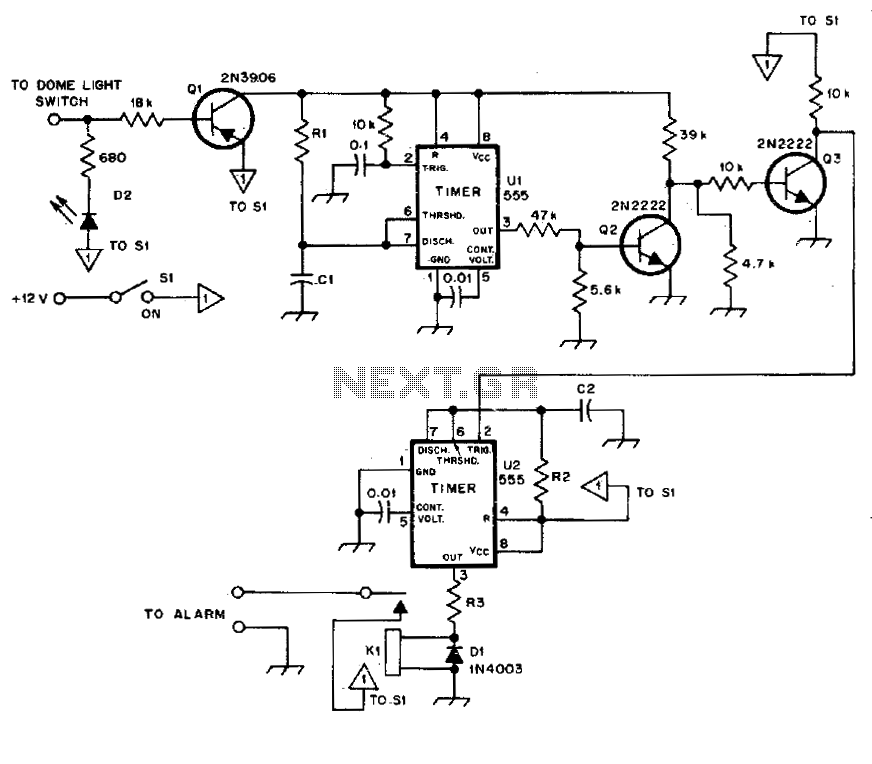
Automotive burglar alarm
The alarm activates after a 13-second delay and remains active for 1 to 1.5 minutes before automatically resetting. It can also be deactivated and reset by opening and reclosing switch SI.
The described circuit functions as a delay-triggered alarm system, incorporating...
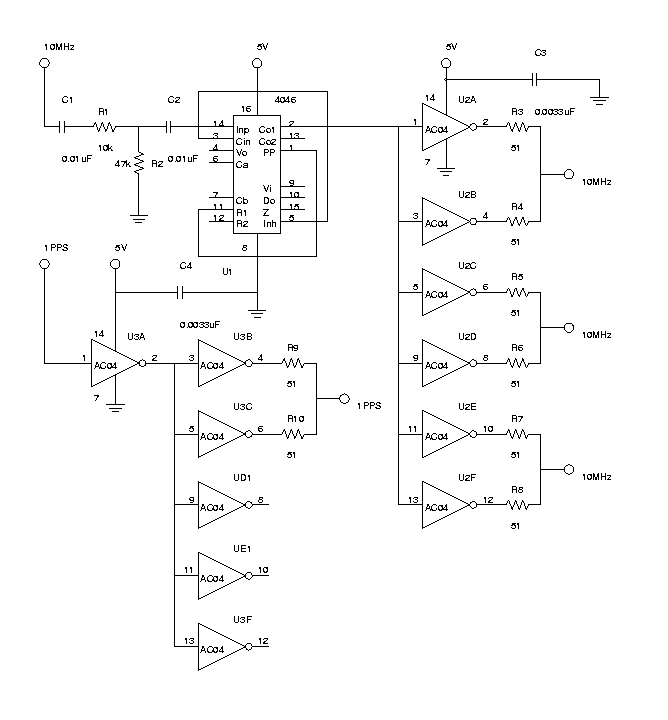
Adding 1 PPS and 10MHz Outputs to the Z3801A
Enhance the functionality of the Z3801A GPS-disciplined oscillators by making 1 PPS and additional 10 MHz signals accessible from the rear panel. A 1 PPS signal is also provided on the DCD line of the serial connector to enable the...
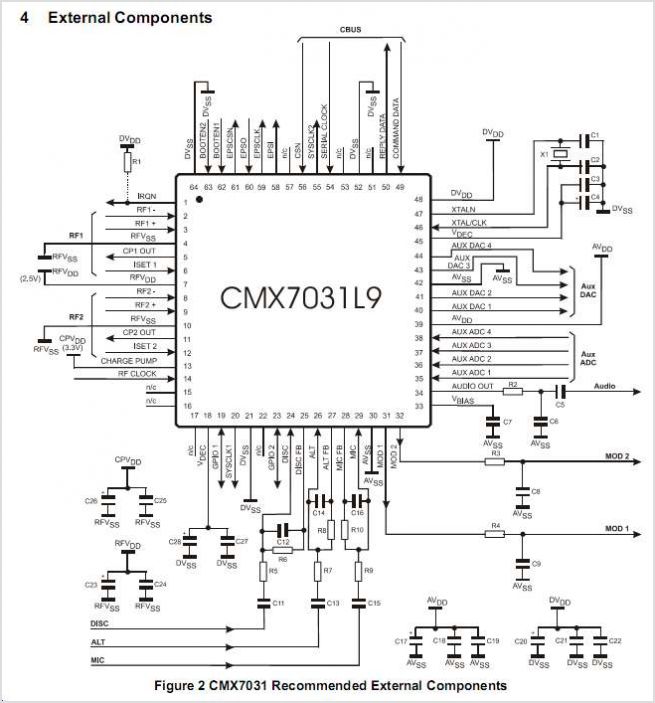
CMX7031Q1 The Two-Way Radio Processor
The CMX866 is a multi-standard modem designed for use in telephone-based information and telemetry systems. Control of the device is achieved through AT commands via a simple 9600 b/s serial interface, which is compatible with various types of host controllers....
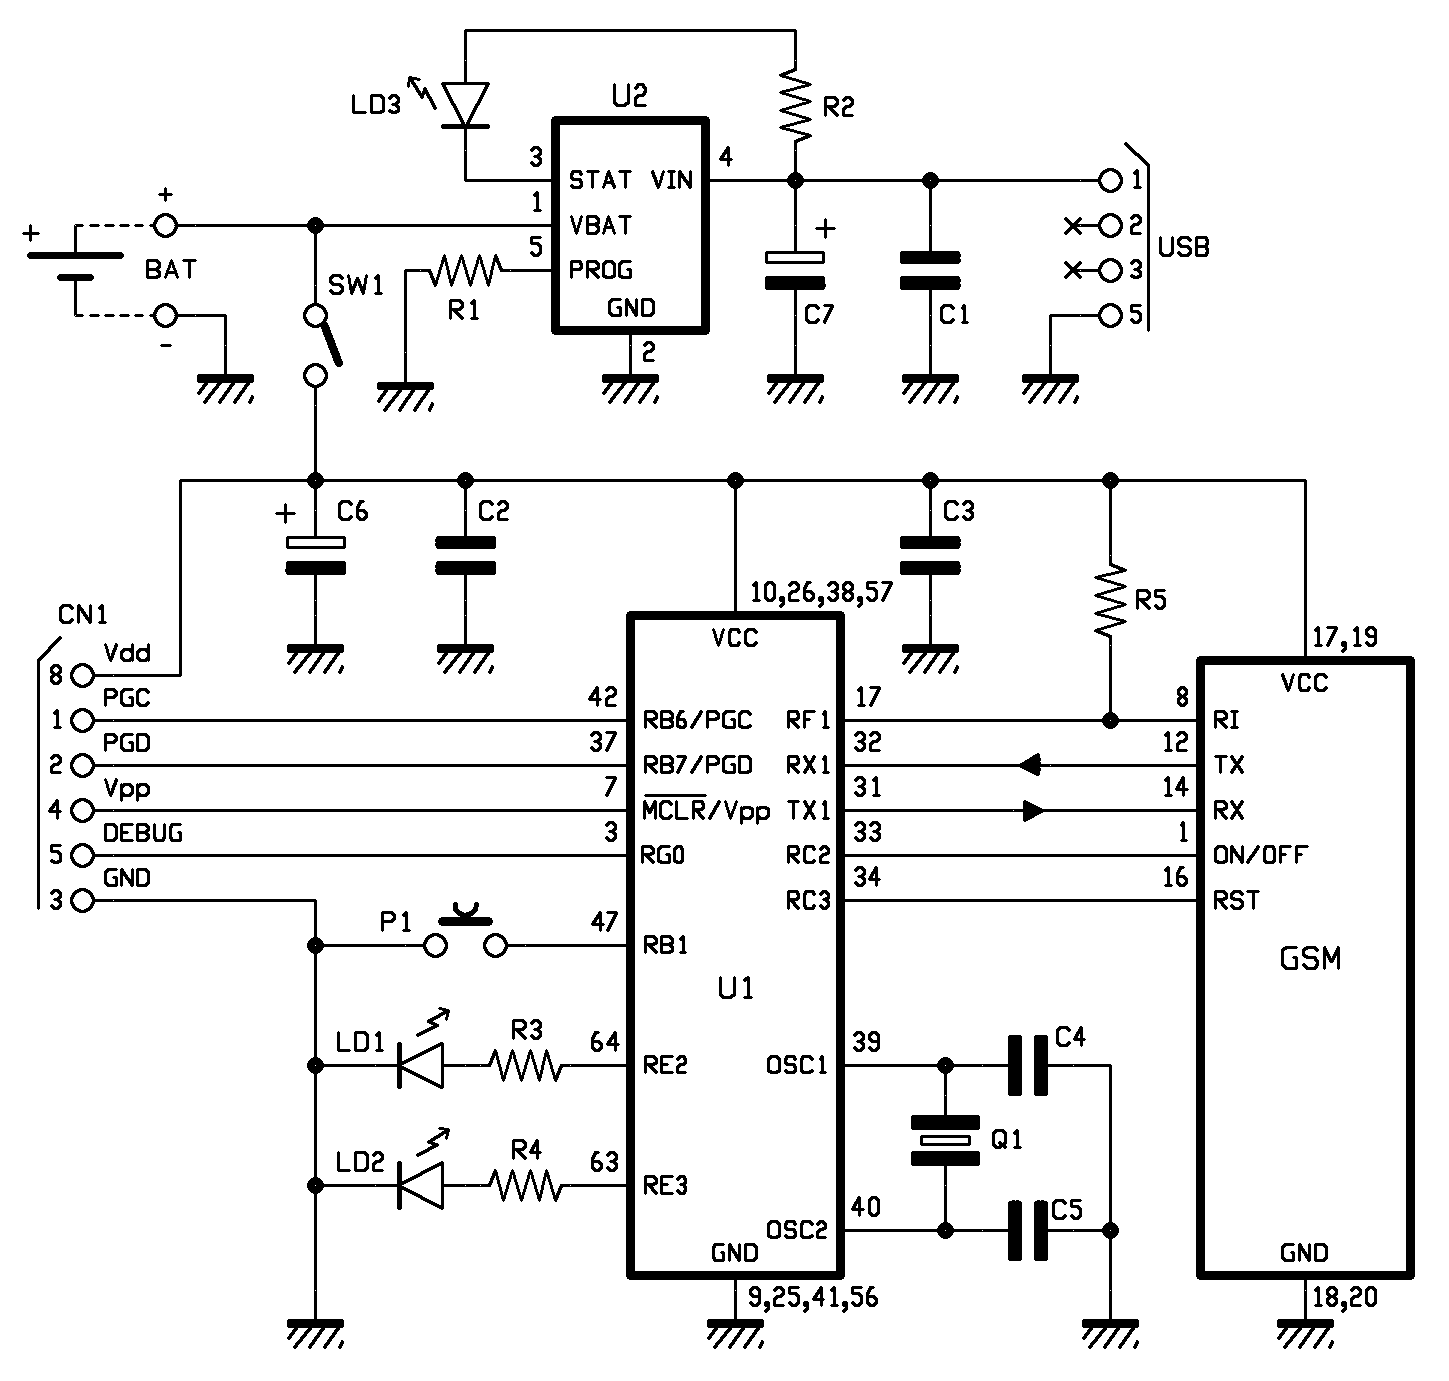
Mini GSM localizer without GPS
A localizer that does not utilize GPS technology has been developed using the cost-effective SimCom SIM900 module. In previous discussions, the GSM section was presented, and now the complete localization system is introduced. This system allows for object localization without...
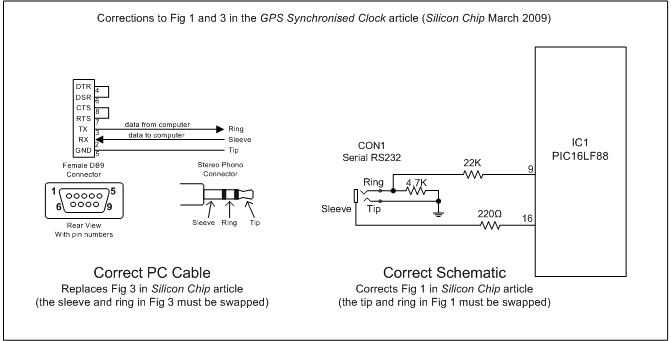
GPS Synchronised Clock
This project replaces the electronics in a standard quartz wall clock with a circuit that uses GPS satellites to obtain precise time.
The proposed project involves the modification of a conventional quartz wall clock by integrating a GPS-based timing circuit. The...