


Sound-To-Servo Driver
#servo
#sound detection
#RC servo
#audio signal
#animation
#toy design
#sound-to-motion
#DIY
#electronics
#mechanical
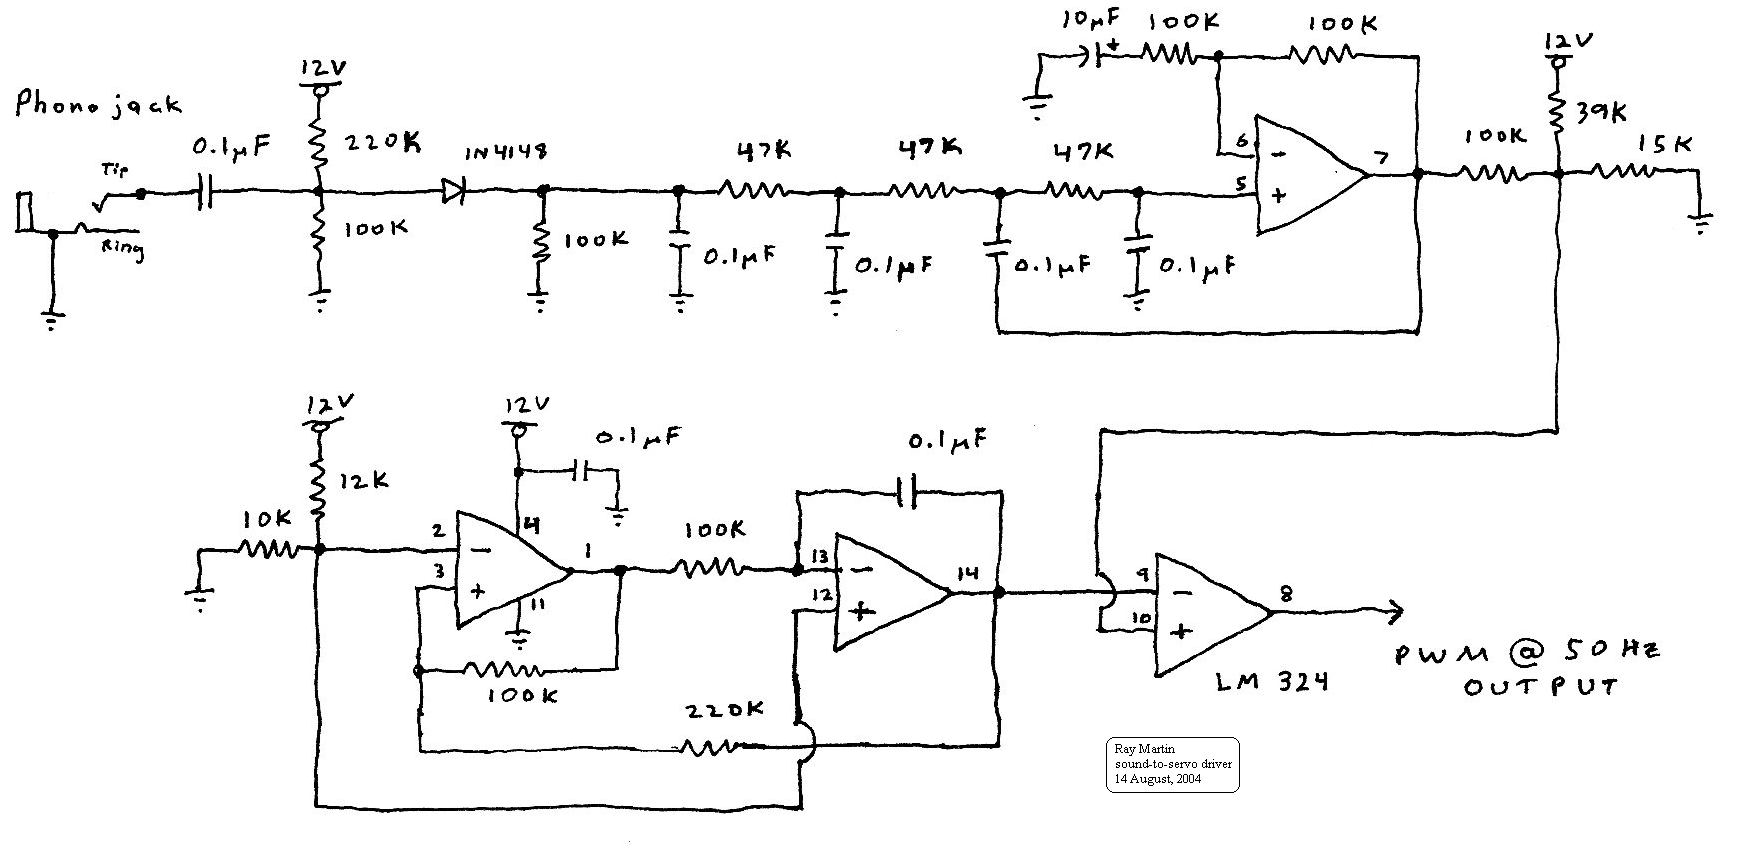
Description: This page outlines a project that utilizes an audio signal to control an RC servo. The movement of the servo is proportional to the loudness of the sound. This concept is particularly applicable for creating animated mouths for talking and singing creatures. Ray Martin, a toy designer, was inspired during a lunch conversation about the discontinuation of popular hackable products featuring animated mouths. He noted that Halloween enthusiasts have been repurposing servos to create singing and talking props. Ray mentioned that he had an existing circuit design that met the project's needs. He further customized the design to accommodate specific servo limits and pulse frequencies, developed a prototype, and provided detailed specifications. The frequency of the driving pulses is not critically important; rather, the pulse width is the key factor. Typical pulse rates include 400 Hz (with a pulse spacing of 2.5 milliseconds) and 50 Hz (with a pulse spacing of 20 milliseconds). The driving pulse is generally specified as 3-5 volts peak-to-peak, although it may be feasible to use the existing power supply of the motor. It is advisable to avoid driving pulses that exceed the motor's power rating.
This project involves a circuit that effectively translates audio input into control signals for an RC servo. The fundamental principle is to convert the amplitude of the audio signal into a corresponding servo movement, thereby allowing for dynamic interaction based on sound levels.
The circuit can be broken down into several key components: an audio input stage, a signal processing unit, and the servo control output. The audio input stage typically includes a microphone or line-in jack to capture the audio signal, which is then amplified to ensure adequate signal strength for processing. A band-pass filter may be employed to isolate the relevant frequency range of the audio input, ensuring that only the desired sound frequencies are utilized for servo control.
The signal processing unit is responsible for analyzing the amplitude of the audio signal. This can be achieved using an envelope detector or a peak detector circuit, which converts the audio waveform into a DC voltage that corresponds to the loudness of the sound. This voltage is then used to modulate the pulse width of the control signal sent to the servo. The width of the pulse determines the extent of the servo's movement, allowing for nuanced control based on the input audio's amplitude.
The final output stage involves the generation of PWM (Pulse Width Modulation) signals that drive the RC servo. The pulse width is adjusted according to the detected audio amplitude, translating the sound level into physical movement. Typical pulse widths for RC servos range from 1 millisecond to 2 milliseconds, corresponding to the servo's range of motion.
It is crucial to ensure that the voltage levels of the control signal remain within the specifications of the servo to prevent damage. The circuit may also include a protection mechanism, such as a zener diode, to safeguard against voltage spikes. Overall, this project presents an innovative approach to integrating audio signals with electronic movement, enabling the creation of interactive and animated devices.This page describes a project that takes an audio signal and uses it to drive a RC servo. The louder the sound, the more the servo moves. The most obvious application of this is to make your own mouth animation for talking and singing creatures. Ray Martin is a friend of ours who designs toys for a living, sometimes electronic, sometimes mechanic
al. We were having lunch after the TRW Amateur Radio Club swap meet, and I mentioned that some of the best hackable products with animated mouths were discontinued, and Halloween lovers were constructing singing and talking props out of alternative things like servos. Ray said, "I have a circuit that does exactly what you need on my desk right now!" Ray went further than that.
He customized the design for specific servo limits and pulse frequency, built a prototype and tested it, and sent me the details. The rate at which these pulses are sent isn`t terribly important - only the width of the pulse. Some typical rates are 400 Hz (2. 5 mSec pulse spacing) and 50 Hz (20 mSec pulse spacing). The driving pulse is usually specified as 3-5 Volt Peak to Peak, but I suspect that in many cases you can get by with whatever power the motor is getting.
I would avoid using a drive pulse greater than the motor power.
This project involves a circuit that effectively translates audio input into control signals for an RC servo. The fundamental principle is to convert the amplitude of the audio signal into a corresponding servo movement, thereby allowing for dynamic interaction based on sound levels.
The circuit can be broken down into several key components: an audio input stage, a signal processing unit, and the servo control output. The audio input stage typically includes a microphone or line-in jack to capture the audio signal, which is then amplified to ensure adequate signal strength for processing. A band-pass filter may be employed to isolate the relevant frequency range of the audio input, ensuring that only the desired sound frequencies are utilized for servo control.
The signal processing unit is responsible for analyzing the amplitude of the audio signal. This can be achieved using an envelope detector or a peak detector circuit, which converts the audio waveform into a DC voltage that corresponds to the loudness of the sound. This voltage is then used to modulate the pulse width of the control signal sent to the servo. The width of the pulse determines the extent of the servo's movement, allowing for nuanced control based on the input audio's amplitude.
The final output stage involves the generation of PWM (Pulse Width Modulation) signals that drive the RC servo. The pulse width is adjusted according to the detected audio amplitude, translating the sound level into physical movement. Typical pulse widths for RC servos range from 1 millisecond to 2 milliseconds, corresponding to the servo's range of motion.
It is crucial to ensure that the voltage levels of the control signal remain within the specifications of the servo to prevent damage. The circuit may also include a protection mechanism, such as a zener diode, to safeguard against voltage spikes. Overall, this project presents an innovative approach to integrating audio signals with electronic movement, enabling the creation of interactive and animated devices.This page describes a project that takes an audio signal and uses it to drive a RC servo. The louder the sound, the more the servo moves. The most obvious application of this is to make your own mouth animation for talking and singing creatures. Ray Martin is a friend of ours who designs toys for a living, sometimes electronic, sometimes mechanic
al. We were having lunch after the TRW Amateur Radio Club swap meet, and I mentioned that some of the best hackable products with animated mouths were discontinued, and Halloween lovers were constructing singing and talking props out of alternative things like servos. Ray said, "I have a circuit that does exactly what you need on my desk right now!" Ray went further than that.
He customized the design for specific servo limits and pulse frequency, built a prototype and tested it, and sent me the details. The rate at which these pulses are sent isn`t terribly important - only the width of the pulse. Some typical rates are 400 Hz (2. 5 mSec pulse spacing) and 50 Hz (20 mSec pulse spacing). The driving pulse is usually specified as 3-5 Volt Peak to Peak, but I suspect that in many cases you can get by with whatever power the motor is getting.
I would avoid using a drive pulse greater than the motor power.
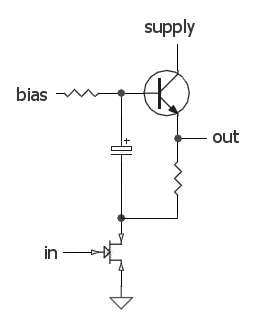
DC biasing audio signal
The audio source will be a line-level audio signal ranging from -2V to +2V AC, which will be passed through a 220µF coupling capacitor followed by a two-pole low-pass filter (RC). The signal will be processed by an Analog-to-Digital Converter...
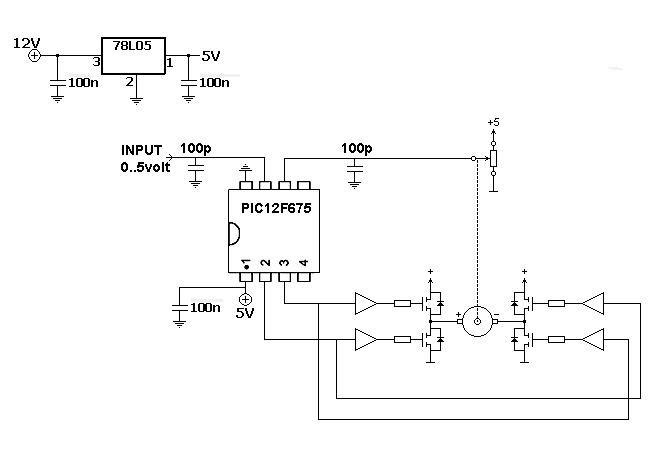
Servo CDI Programmable Digital Ignition
The motor is utilized to provide the mechanical output of the system and to move the potentiometer for loop closure. For high-power servos, three-phase motors can be employed. Potentiometer: A simple potentiometer can be used for standard industrial applications to...
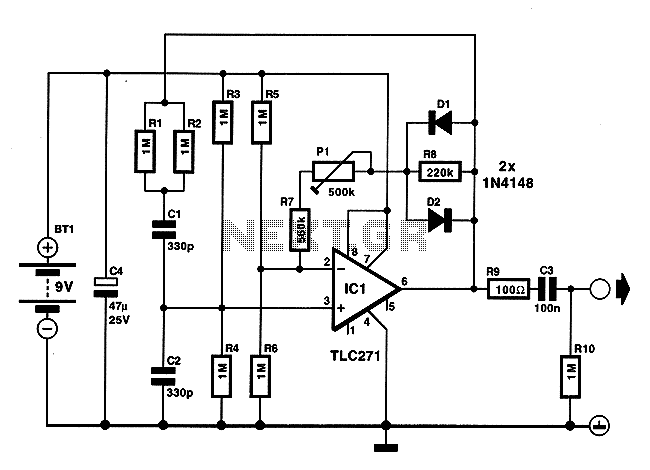
Low energy consumption audio signal generator
On occasions when it is necessary to determine if an amplifier is functioning, the most effective tool is an acoustic signal source with a frequency around 1 kHz. The specifications can be considered flexible, as rapid tests typically do not...
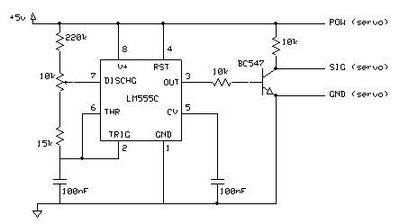
Simple servo controller Schematic
This circuit enables the testing of a servo motor. The angle of the servo can be adjusted using a 10k potentiometer. It is possible that not all positions can be achieved with this circuit; experimenting with different resistors may provide...
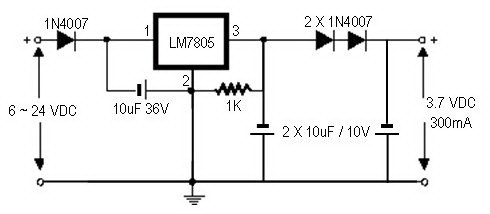
how to convert a 9v battery to 3.7v
A regulator circuit is needed for this DIY project. Familiarity with electronic components, circuitry, the use of a multitester, and a soldering iron is essential. The schematic diagram provided can accept an input voltage ranging from 6 to 24 volts...
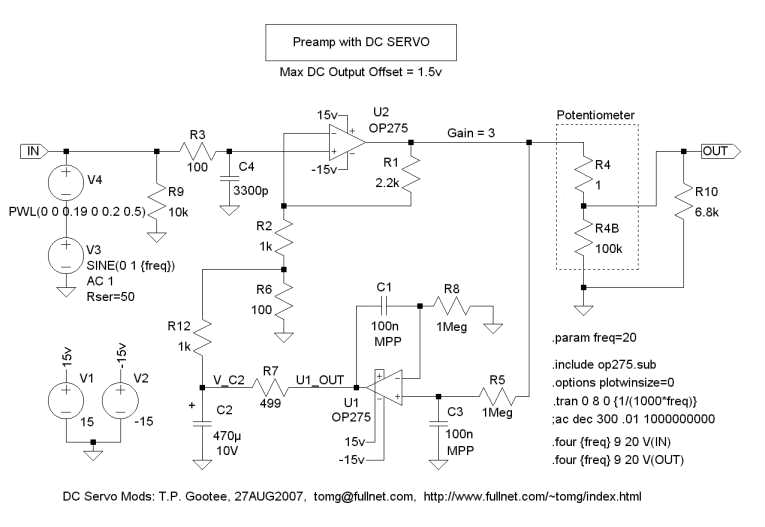
DC Servo
Additional experimentation has been conducted with the LTspice simulation of the Dxvideo preamplifier circuit that includes a DC servo. The .four command has been utilized within the simulation environment.
The LTspice simulation of the Dxvideo preamplifier circuit featuring a DC servo...
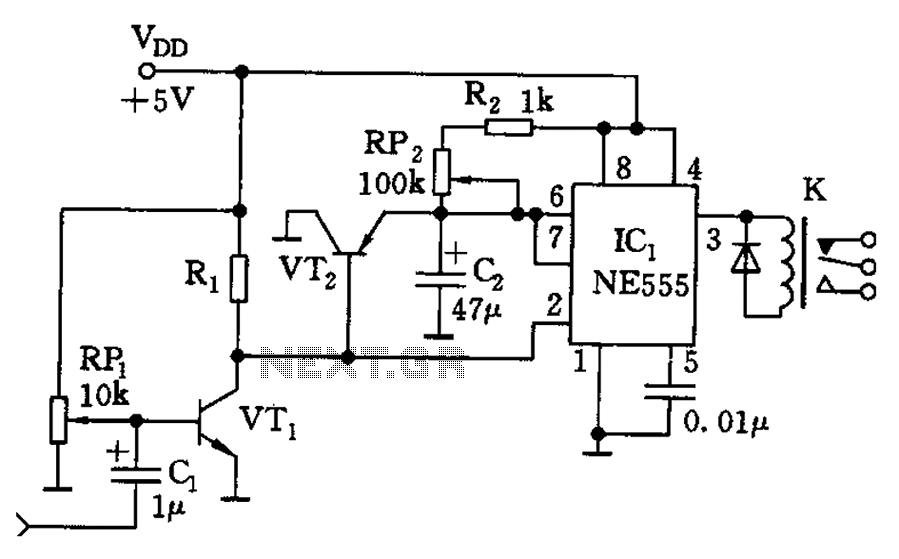
Voice relay circuit
The circuit consists of a sound detection circuit and a monostable trigger circuit that activates a relay. VT1 amplifies the input audio signal. When a signal is detected, the 555 timer is triggered, pulling K. Simultaneously, VT2 conducts, allowing the...
DIY kinetic energy harvester
A DIY kinetic energy harvester utilizing the electromagnetic method to generate electricity. The materials that will be used are currently known.
The project involves creating a kinetic energy harvester that converts mechanical energy from motion into electrical energy through electromagnetic induction....
Servo Driver
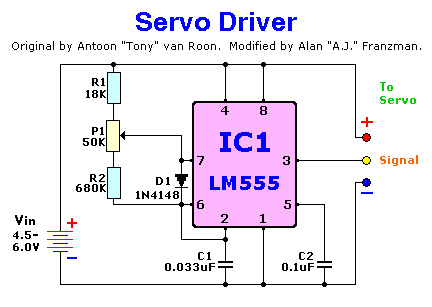
This circuit can be utilized to verify the functionality of servos, assess full travel, detect binding, and identify any drag or rubbing when the servos are integrated into a model. It may also serve as a control circuit in robotics...