


Water Tank Depth Sensor using Arduino
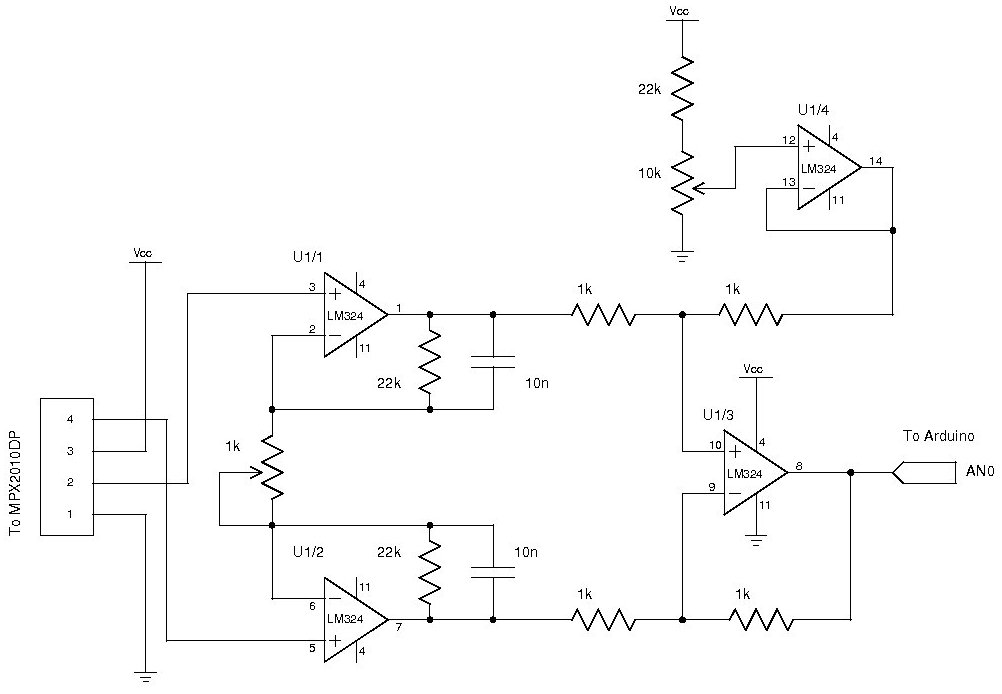
Description: Water is a valuable resource in many regions, with numerous individuals depending on water tanks to enhance their water supply by storing collected rainwater or water drawn from a well or bore. Measuring the fullness of a tank can be challenging, as tanks are typically made of opaque materials to inhibit algae growth and are often sealed to prevent mosquito infestations or access by small rodents, making it inconvenient to visually inspect the interior. Implementing an electronic method to measure tank depth presents various advantages, such as automating pump controls to refill tanks when levels are low or disabling irrigation systems when insufficient water is available. A conventional approach involves installing a series of conductive pickups at different heights within the tank to measure resistance between them. For instance, placing ten exposed terminals at equal intervals attached to a length of material like PVC tubing allows for measuring depth in 10% increments by reading the resistance from the bottom terminal to each terminal above it. However, this method requires extensive wiring and necessitates reading an analog input for each terminal, which can be a limitation since most Arduino designs offer a maximum of six analog inputs. This project adopts a different approach by utilizing a differential pressure transducer to gauge the water pressure at the tank's bottom, thereby calculating the tank's fullness. Water pressure increases by approximately 9.8067 kPa for each meter of depth, so a full 2-meter tank will exhibit a pressure of about 19.6134 kPa above ambient atmospheric pressure. The distinction of measuring above ambient pressure is crucial, as varying atmospheric conditions can affect readings. Therefore, this project employs a differential pressure transducer with two inlets: one open to the atmosphere and the other connected to the tank's bottom. This configuration allows the transducer to output the pressure difference, automatically compensating for fluctuations in air pressure and providing a stable reading for a consistent depth. The Arduino interprets the transducer's output to report the tank's depth. In this project, an Ethernet shield will enable the Arduino to connect to an online data logging service called Pachube, facilitating the generation of graphs depicting water depth over time. Additionally, the system could be programmed to make decisions based on the readings to control devices such as a water pump or irrigation system solenoid.
The implementation of a differential pressure transducer in this system allows for an efficient and reliable method of measuring water levels in tanks. The transducer's two inlets play a critical role in ensuring accurate measurements by negating the effects of atmospheric pressure changes. The integration of the Arduino microcontroller enables real-time data processing and communication with external services, facilitating remote monitoring and control of water resources.
The schematic for this project would typically include the following components: the differential pressure transducer, the Arduino board, the Ethernet shield, and the necessary power supply. The transducer would be connected to the Arduino through an analog input pin, allowing the Arduino to read the voltage output from the transducer. The Ethernet shield would connect to the Arduino, enabling internet connectivity for data logging purposes.
For the wiring, it is essential to ensure that the transducer is properly calibrated and that the connections are secure to prevent erroneous readings. The Arduino can be programmed to periodically read the transducer output and send the data to the Pachube service, where it can be visualized in real-time. Additionally, control logic can be implemented in the Arduino code to activate or deactivate pumps or irrigation systems based on the measured water levels, enhancing the efficiency of water usage.
By employing this electronic measurement system, users can effectively monitor their water supply, make informed decisions regarding water management, and automate processes to conserve this vital resource.Water is a precious resource in many parts of the world, and many people rely on water tanks to supplement their water supply by storing collected rainwater or water pumped from a well or bore. But how do you measure how full a tank is Tanks are constructed of opaque material to prevent algae growth and often kept closed up to prevent mosquito in
festation or access by small rodents so it`s inconvenient to physically look inside. And besides, having a way to measure tank depth electronically opens up a world of possibilities such as automatic control of pumps to top up tanks when they get low or to disable irrigation systems when not enough water is available. The obvious way to measure tank depth is by placing a series of conductive pickups at various heights inside the tank and measure the resistance between them.
For example, placing ten exposed terminals at equal intervals attached to a length of material such as PVC tubing and inserting it into the tank will allow you to measure the depth in 10% increments by reading the resistance between the bottom terminal and each of the terminals above it. The downside to this approach though is that you`ll need to do a lot of wiring and you`ll also need to read an analogue input for every individual terminal while most Arduino designs have no more than 6 analogue inputs.
This project works a little differently. It uses a device called a differential pressure transducer to measure the water pressure at the bottom of the tank, and from that to calculate how full the tank is. Water pressure increases by about 9. 8067kPa per meter of depth so a full tank 2m tall will have a pressure at the bottom of about 19. 6134kPa above ambient atmospheric pressure. The above ambient atmospheric pressure part is important: it`s not enough to simply measure the pressure at the bottom of the tank because varying climate conditions will alter the reading.
That`s why this project uses a differential pressure transducer that has two inlets. By leaving one inlet open to the atmosphere and connecting the other to the bottom of the tank the transducer will output the difference between the two, automatically compensating for varying air pressure and giving a constant reading for constant depth. The Arduino then reads the output of the transducer and reports the depth of the tank. In this project we will use an Ethernet shield to have the Arduino connect to an online datalogging service called Pachube to generate graphs of water depth over time, but you could also have it make decisions on the basis of the reading to control items such as a water pump or irrigation system solenoid.
The implementation of a differential pressure transducer in this system allows for an efficient and reliable method of measuring water levels in tanks. The transducer's two inlets play a critical role in ensuring accurate measurements by negating the effects of atmospheric pressure changes. The integration of the Arduino microcontroller enables real-time data processing and communication with external services, facilitating remote monitoring and control of water resources.
The schematic for this project would typically include the following components: the differential pressure transducer, the Arduino board, the Ethernet shield, and the necessary power supply. The transducer would be connected to the Arduino through an analog input pin, allowing the Arduino to read the voltage output from the transducer. The Ethernet shield would connect to the Arduino, enabling internet connectivity for data logging purposes.
For the wiring, it is essential to ensure that the transducer is properly calibrated and that the connections are secure to prevent erroneous readings. The Arduino can be programmed to periodically read the transducer output and send the data to the Pachube service, where it can be visualized in real-time. Additionally, control logic can be implemented in the Arduino code to activate or deactivate pumps or irrigation systems based on the measured water levels, enhancing the efficiency of water usage.
By employing this electronic measurement system, users can effectively monitor their water supply, make informed decisions regarding water management, and automate processes to conserve this vital resource.Water is a precious resource in many parts of the world, and many people rely on water tanks to supplement their water supply by storing collected rainwater or water pumped from a well or bore. But how do you measure how full a tank is Tanks are constructed of opaque material to prevent algae growth and often kept closed up to prevent mosquito in
festation or access by small rodents so it`s inconvenient to physically look inside. And besides, having a way to measure tank depth electronically opens up a world of possibilities such as automatic control of pumps to top up tanks when they get low or to disable irrigation systems when not enough water is available. The obvious way to measure tank depth is by placing a series of conductive pickups at various heights inside the tank and measure the resistance between them.
For example, placing ten exposed terminals at equal intervals attached to a length of material such as PVC tubing and inserting it into the tank will allow you to measure the depth in 10% increments by reading the resistance between the bottom terminal and each of the terminals above it. The downside to this approach though is that you`ll need to do a lot of wiring and you`ll also need to read an analogue input for every individual terminal while most Arduino designs have no more than 6 analogue inputs.
This project works a little differently. It uses a device called a differential pressure transducer to measure the water pressure at the bottom of the tank, and from that to calculate how full the tank is. Water pressure increases by about 9. 8067kPa per meter of depth so a full tank 2m tall will have a pressure at the bottom of about 19. 6134kPa above ambient atmospheric pressure. The above ambient atmospheric pressure part is important: it`s not enough to simply measure the pressure at the bottom of the tank because varying climate conditions will alter the reading.
That`s why this project uses a differential pressure transducer that has two inlets. By leaving one inlet open to the atmosphere and connecting the other to the bottom of the tank the transducer will output the difference between the two, automatically compensating for varying air pressure and giving a constant reading for constant depth. The Arduino then reads the output of the transducer and reports the depth of the tank. In this project we will use an Ethernet shield to have the Arduino connect to an online datalogging service called Pachube to generate graphs of water depth over time, but you could also have it make decisions on the basis of the reading to control items such as a water pump or irrigation system solenoid.
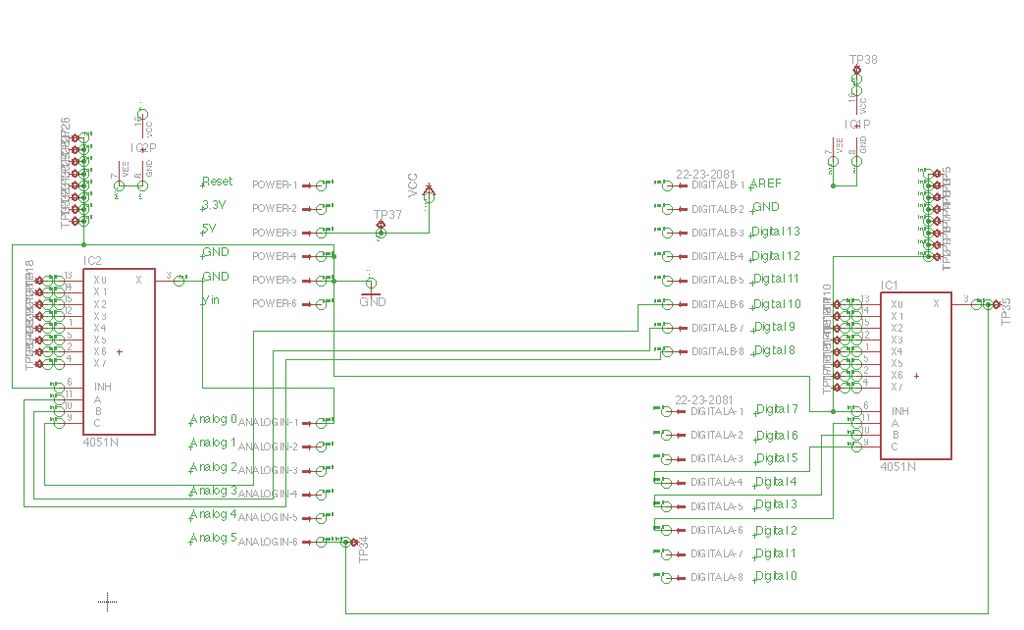
Pressure Activated Light-Up Umbrella using an Arduino
Inspired by a previous project, a unique design was developed that incorporates an umbrella capable of playing musical notes when pressed. For additional information regarding the 4051 chip, which functions as a multiplexer or demultiplexer, refer to resources available on...
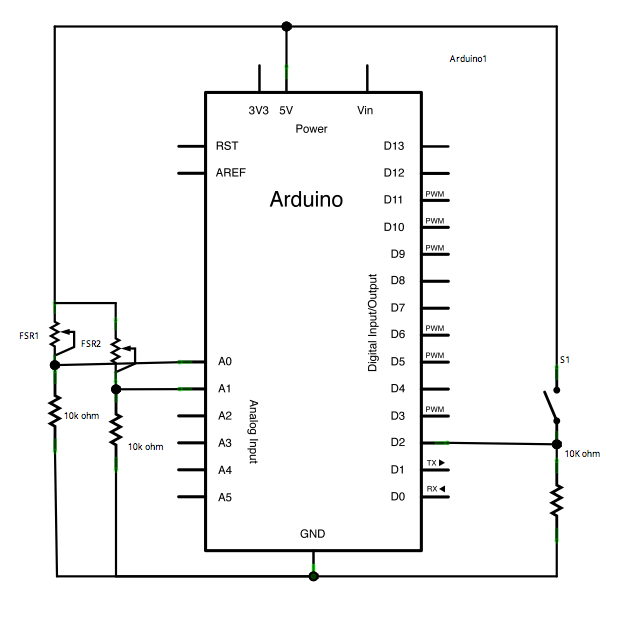
Arduino Serial Call Response
This sketch transmits an ASCII 'A' (byte value 65) upon startup and continues to do so until it receives a serial response from the computer. After receiving a response, it sends three sensor values as individual bytes and waits for...
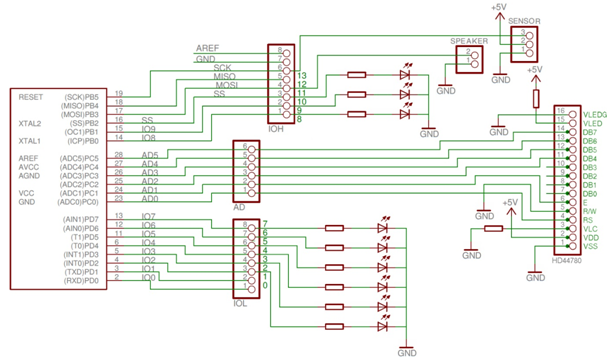
arduino uno parking sensor
Required components include an Arduino Uno, an HD44780 Character LCD, a PING))) Ultrasonic Distance Sensor, a speaker cone from an old computer, a breadboard, wires, resistors, colored LEDs, and Arduino software. The provided schematic illustrates the parking sensor circuit. A...
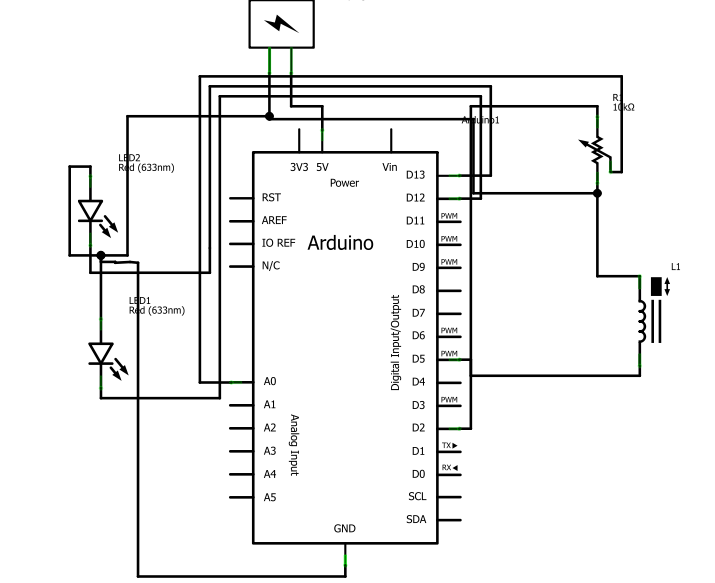
Small Engine ECU EFI Moped Using Ardrino UNO
After several days of considering electronic fuel injection for a moped, a decision has been made to proceed with the project. The required parts have been identified, and the remaining task involves programming.
The implementation of electronic fuel injection (EFI) in...
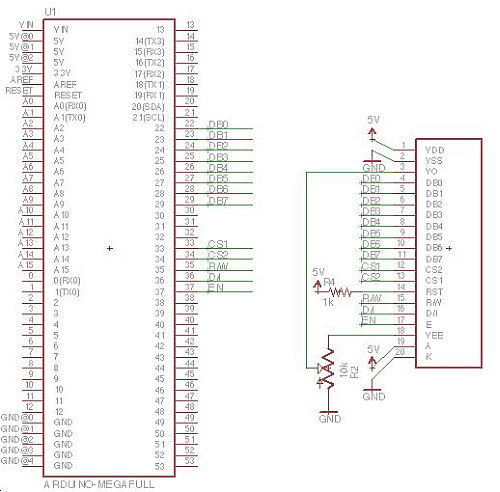
Arduino powered GLCD (Graphic LCD)
Displays are always beneficial. Until now, only 7-segment displays have been demonstrated for showing numbers using minimal resources. However, for displaying text or images, a simple LCD screen is required. There are basic LED screens available that operate on serial...
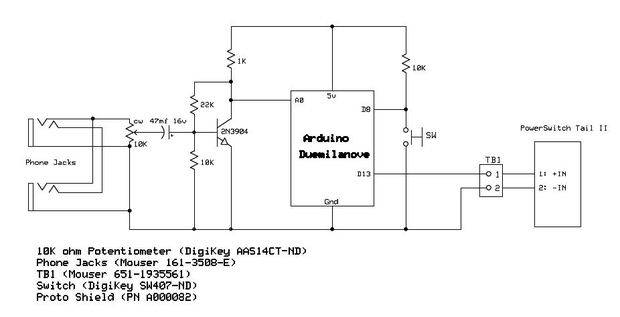
Arduino Audio Triggered Power Switch
Have you ever wanted your home entertainment or sound system to power on automatically when plugging in your iPod or another portable MP3 player?
To achieve automatic power activation of a home entertainment system when a portable device is connected,...
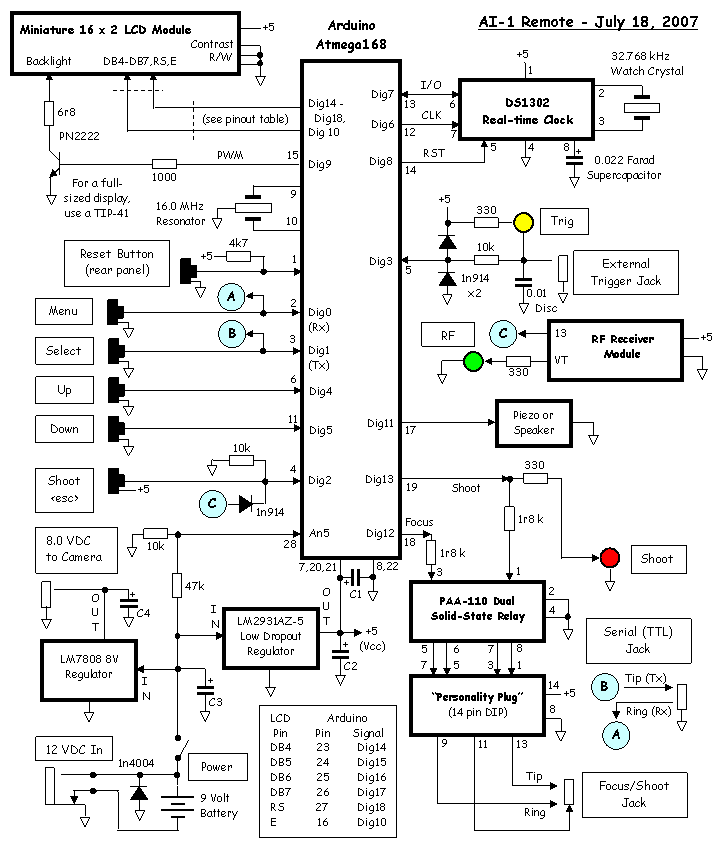
All in one Remote using Arduino
In August 2007, an individual with a passion for photography acquired a Panasonic FZ30 digital camera and joined a forum on dpreview dedicated to Panasonic products. A fellow forum member, who was a programmer and electronics enthusiast, created a wireless...
Simulating and controlling GE Color Effects Lights with Arduino
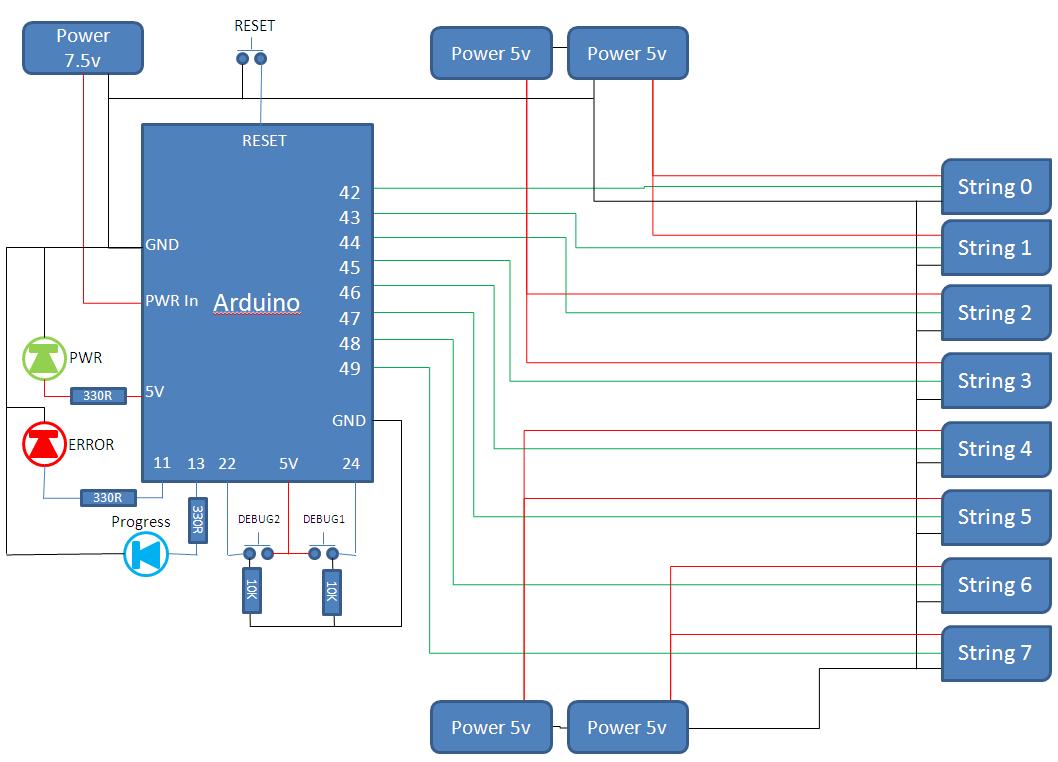
This project develops a Christmas lights controller for GE Color Effects lights, enabling programmed control of up to eight sets of lights. It includes a function-specific language for programming light patterns and an emulation environment for testing programs before deployment....
Arduino on a prototype board
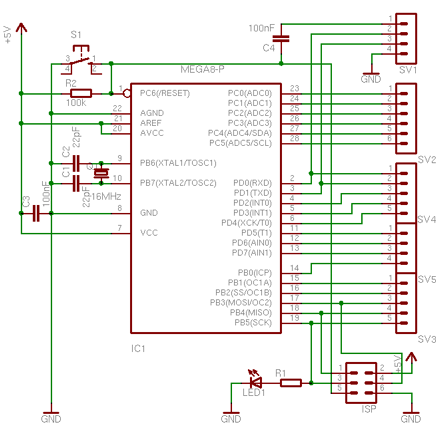
The USB to RS232 converter is called USB-2-bot and comes from another project. Any other converter would work as well, e.g. this USB-TTL-232-cable from adafruit. It has an ISP connector to program the bootloader and a serial connection used for...