


servo creating a switch using arduinos digital outputs
#arduino
#servo
#digital output
#motor control
#battery power
#3.3V pin
#weak torque
#strong torque
#DIY
#electronics
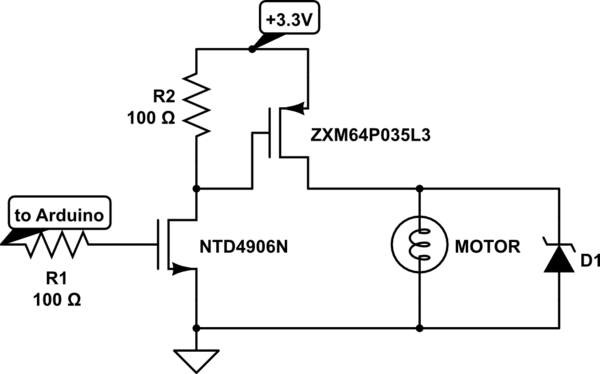
Description: Charge a simple servo that only has + and - pins. Typically, the - pin is connected to ground, while the + pin is connected to a digital output from an Arduino. This setup works, but the servo operates weakly and can be stopped manually. When the servo is connected directly to a battery or the 3.3V pin from the Arduino, it operates strongly and cannot be stopped. Please add a datasheet or at least a picture of the servo. Edit the question, press Ctrl-M, and include a circuit diagram of the connections. Some users have suggested that the term "servo" may not be used correctly, and it could be a motor or actuator. It has been noted that the circuit allows for driving higher voltage motors as well. The PMOS component is identified as the ZXM part, and when selecting another PMOS, it is important to ensure its VGS is about 1/3 to 1/2 of the motor voltage (in this case, 3.3V) and that it can handle 30%-50% more current than required by the motor. The NMOS is used to drive the PMOS, especially since the motor voltage might exceed 3.3V. When choosing the NMOS, it should be rated for a higher voltage than the motor and have a VGS of less than 2V, as it is driven from a 3.3V Arduino.
The circuit involves a basic connection configuration for a servo or motor control using an Arduino. The servo typically features two terminals: a positive (+) and a negative (-). The negative terminal is grounded, while the positive terminal connects to a digital output pin on the Arduino. This configuration is suitable for low-power applications but may not provide sufficient current to drive the servo effectively, leading to weak performance and the ability to stall the servo manually.
For optimal performance, the servo can be powered directly from a battery or the Arduino's 3.3V pin, which supplies a higher voltage and current, resulting in stronger operation. However, it is crucial to ensure that the power source matches the servo's specifications to prevent damage.
In more advanced applications, the use of a PMOS and NMOS transistor configuration allows for the control of higher voltage motors. The PMOS transistor acts as a switch that connects the motor to the power supply, while the NMOS transistor is used to control the gate of the PMOS. This configuration is beneficial when the motor voltage is higher than the control voltage from the Arduino (3.3V).
When selecting a PMOS transistor, it is essential to ensure that its gate-source voltage (VGS) is approximately 1/3 to 1/2 of the motor's operating voltage. Additionally, the PMOS should be rated to handle 30%-50% more current than the motor's maximum requirements to ensure reliable operation. The NMOS transistor must also be chosen carefully, ensuring that it can handle a voltage greater than that of the motor and that its VGS is less than 2V to ensure proper switching when driven by the Arduino.
This circuit design provides flexibility and enhances the performance of servo or motor applications, allowing for the control of motors with varying voltage requirements while maintaining safe operational parameters.Charge a simple servo that only has + and - pins. Usually I would connect it`s - pin to the ground and + pin to the digital output from Arduino. This works, but the servo turns weakly and can be stopped by hand. If i connect the servo directly to the battery or to 3. 3 pin from the Arduino it turns strongly and i cannot stop it. Pleas e add a datasheet or at least a picture of your servo. Edit your question, hit Ctrl-M and add a circuit diagram of how you are connecting things together. jippie May 12 `13 at 8:54 I don`t think you`re using the word "servo" correctly, What is sounds like you have is a motor or some sort of actuator. Connor Wolf May 12 `13 at 10:54 @jippie i added a link. And thank you for the warning, but I`m sure the servo will not get burnt, it can handle takes much more power that what arduino can give.
himura May 12 `13 at 16:12 The nice thing about this circuit is that you can drive higher voltage motors with it too. The PMOS is the ZXM part. If you want to get another PMOS make sure it`s VGS is about 1/3 to 1/2 of your motor voltage (in this case 3.
3V) and that it can handle 30%-50% more current than your motor needs. The NMOS is used to drive the PMOS since your motor voltage might be higher than 3. 3V - for some other use case. The only thing when selecting the NMOS is making sure it is rated for higher than your motor voltage and that it`s VGS is less than 2V (since you are driving it from a 3. 3V Arduino).
The circuit involves a basic connection configuration for a servo or motor control using an Arduino. The servo typically features two terminals: a positive (+) and a negative (-). The negative terminal is grounded, while the positive terminal connects to a digital output pin on the Arduino. This configuration is suitable for low-power applications but may not provide sufficient current to drive the servo effectively, leading to weak performance and the ability to stall the servo manually.
For optimal performance, the servo can be powered directly from a battery or the Arduino's 3.3V pin, which supplies a higher voltage and current, resulting in stronger operation. However, it is crucial to ensure that the power source matches the servo's specifications to prevent damage.
In more advanced applications, the use of a PMOS and NMOS transistor configuration allows for the control of higher voltage motors. The PMOS transistor acts as a switch that connects the motor to the power supply, while the NMOS transistor is used to control the gate of the PMOS. This configuration is beneficial when the motor voltage is higher than the control voltage from the Arduino (3.3V).
When selecting a PMOS transistor, it is essential to ensure that its gate-source voltage (VGS) is approximately 1/3 to 1/2 of the motor's operating voltage. Additionally, the PMOS should be rated to handle 30%-50% more current than the motor's maximum requirements to ensure reliable operation. The NMOS transistor must also be chosen carefully, ensuring that it can handle a voltage greater than that of the motor and that its VGS is less than 2V to ensure proper switching when driven by the Arduino.
This circuit design provides flexibility and enhances the performance of servo or motor applications, allowing for the control of motors with varying voltage requirements while maintaining safe operational parameters.Charge a simple servo that only has + and - pins. Usually I would connect it`s - pin to the ground and + pin to the digital output from Arduino. This works, but the servo turns weakly and can be stopped by hand. If i connect the servo directly to the battery or to 3. 3 pin from the Arduino it turns strongly and i cannot stop it. Pleas e add a datasheet or at least a picture of your servo. Edit your question, hit Ctrl-M and add a circuit diagram of how you are connecting things together. jippie May 12 `13 at 8:54 I don`t think you`re using the word "servo" correctly, What is sounds like you have is a motor or some sort of actuator. Connor Wolf May 12 `13 at 10:54 @jippie i added a link. And thank you for the warning, but I`m sure the servo will not get burnt, it can handle takes much more power that what arduino can give.
himura May 12 `13 at 16:12 The nice thing about this circuit is that you can drive higher voltage motors with it too. The PMOS is the ZXM part. If you want to get another PMOS make sure it`s VGS is about 1/3 to 1/2 of your motor voltage (in this case 3.
3V) and that it can handle 30%-50% more current than your motor needs. The NMOS is used to drive the PMOS since your motor voltage might be higher than 3. 3V - for some other use case. The only thing when selecting the NMOS is making sure it is rated for higher than your motor voltage and that it`s VGS is less than 2V (since you are driving it from a 3. 3V Arduino).
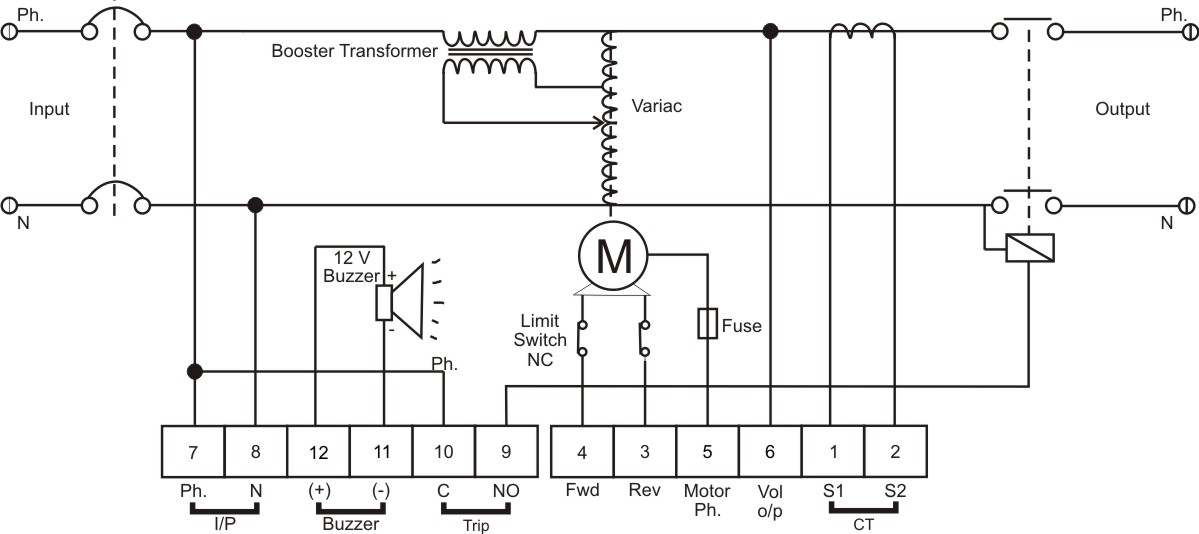
SERVO CONTROLLER DIGITAL
The BPS Servo Controller - Digital is a comprehensive metering and control solution designed for servo stabilizers, accommodating a wide range of input voltages and load requirements. This system minimizes production overheads such as wiring and testing, thereby enhancing the...
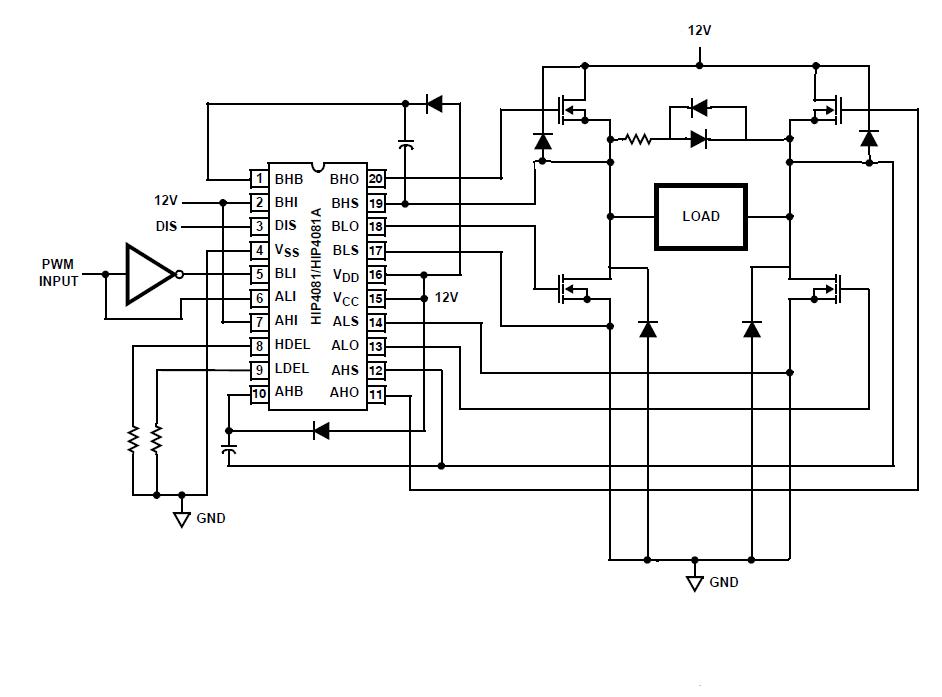
Motor Driver works with PS not battery
An individual is experiencing an unusual issue while utilizing an Intersil HIP4081A H-bridge driver integrated circuit (IC). The IC is connected to an Arduino microcontroller unit (MCU).
The Intersil HIP4081A is a high-performance H-bridge driver designed for driving DC motors and...
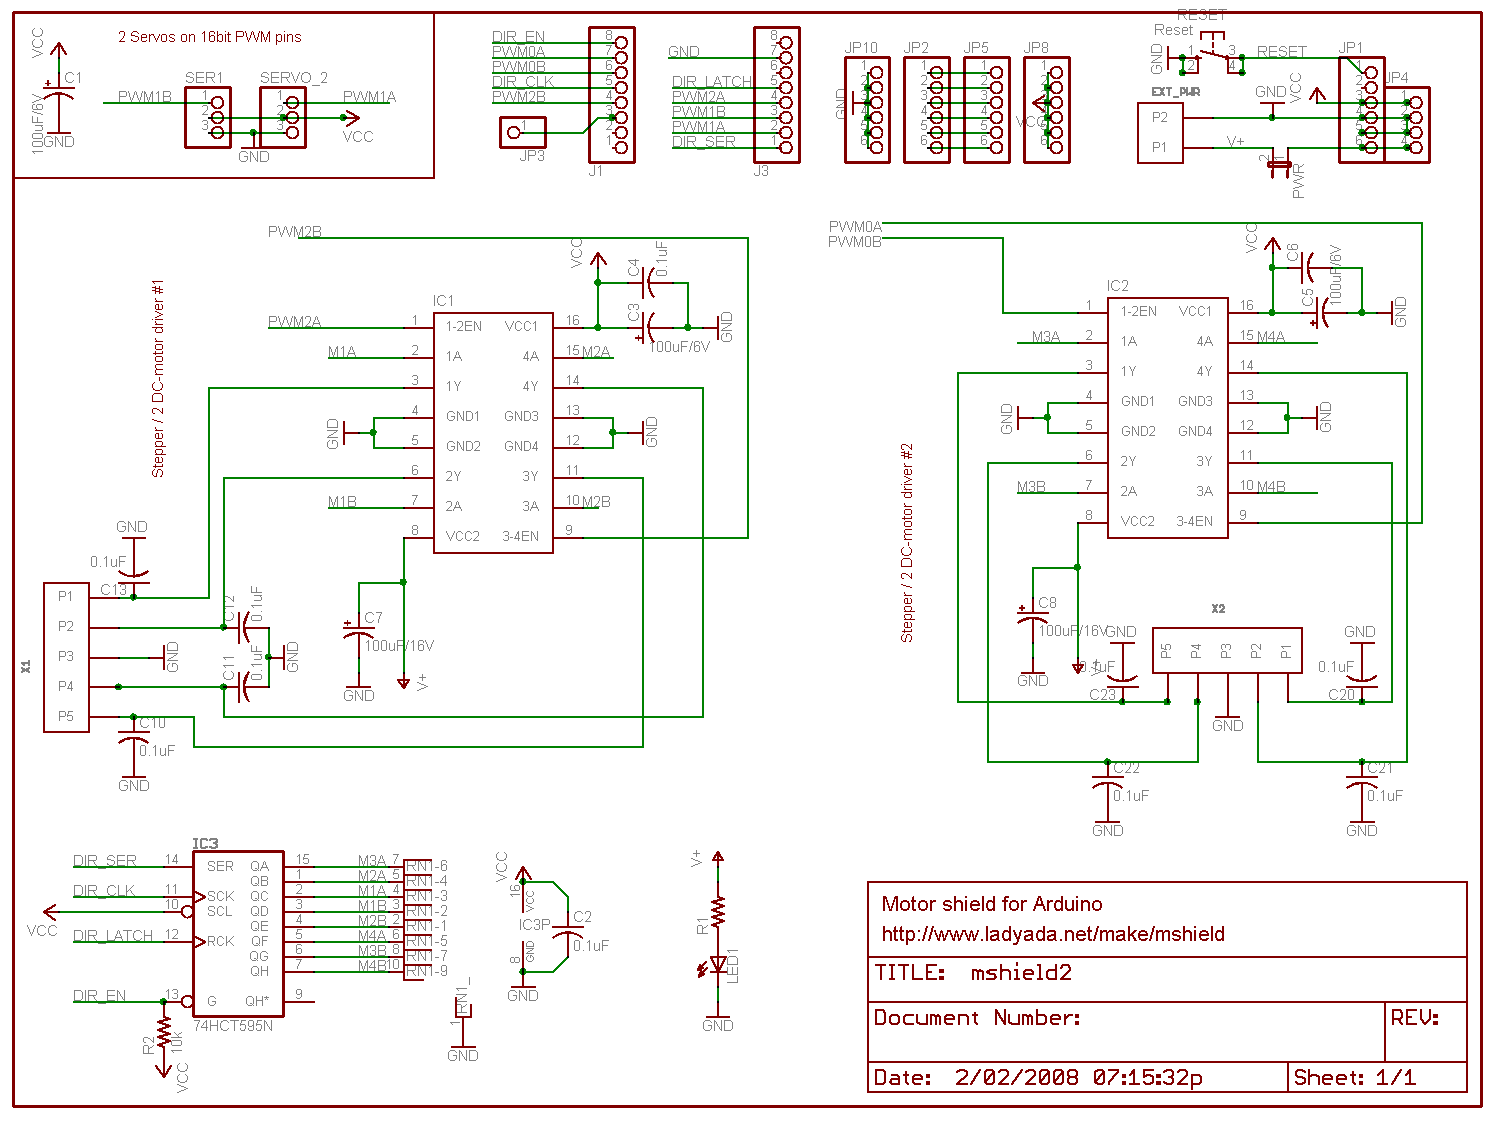
controlling your trains with an arduino
Arduino is an open-source electronics prototyping platform that features flexible and user-friendly hardware and software. It is designed for artists, designers, hobbyists, and anyone interested in creating interactive objects or environments. Arduino can sense the environment by receiving input from...
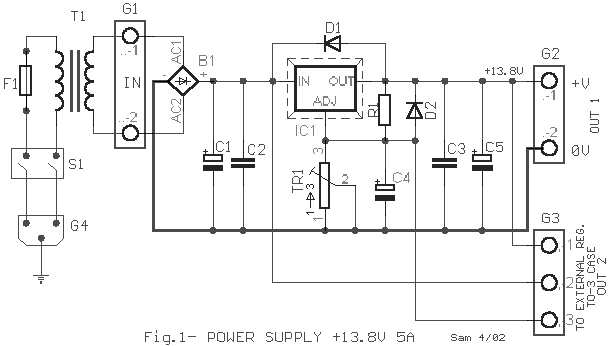
Electronics Projects Circuits
Over 1400 top electronics projects and electronic circuits with photos, datasheets, and easy-to-read schematics, along with explanations of how they work and how to build them.
The collection comprises a vast array of electronics projects suitable for enthusiasts and professionals alike....
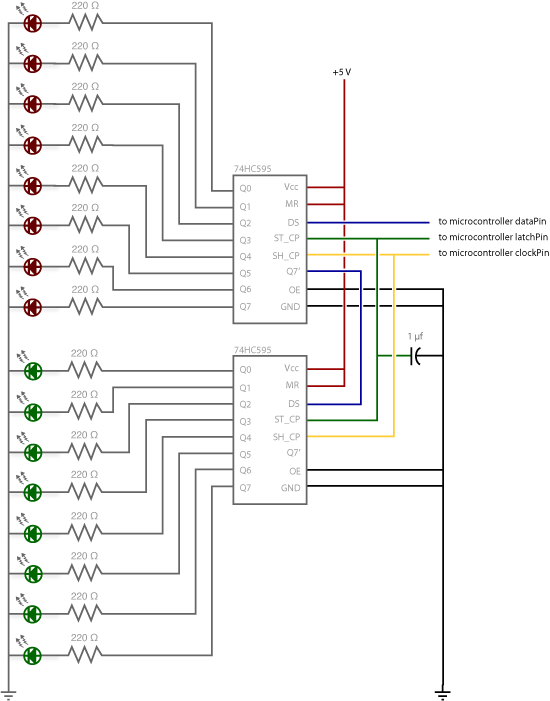
Arduino Shift Out
At some point, it may be necessary to extend the number of pins on an Arduino board using shift registers. This example utilizes the 74HC595, which is described in the datasheet as an "8-bit serial-in, serial or parallel-out shift register...
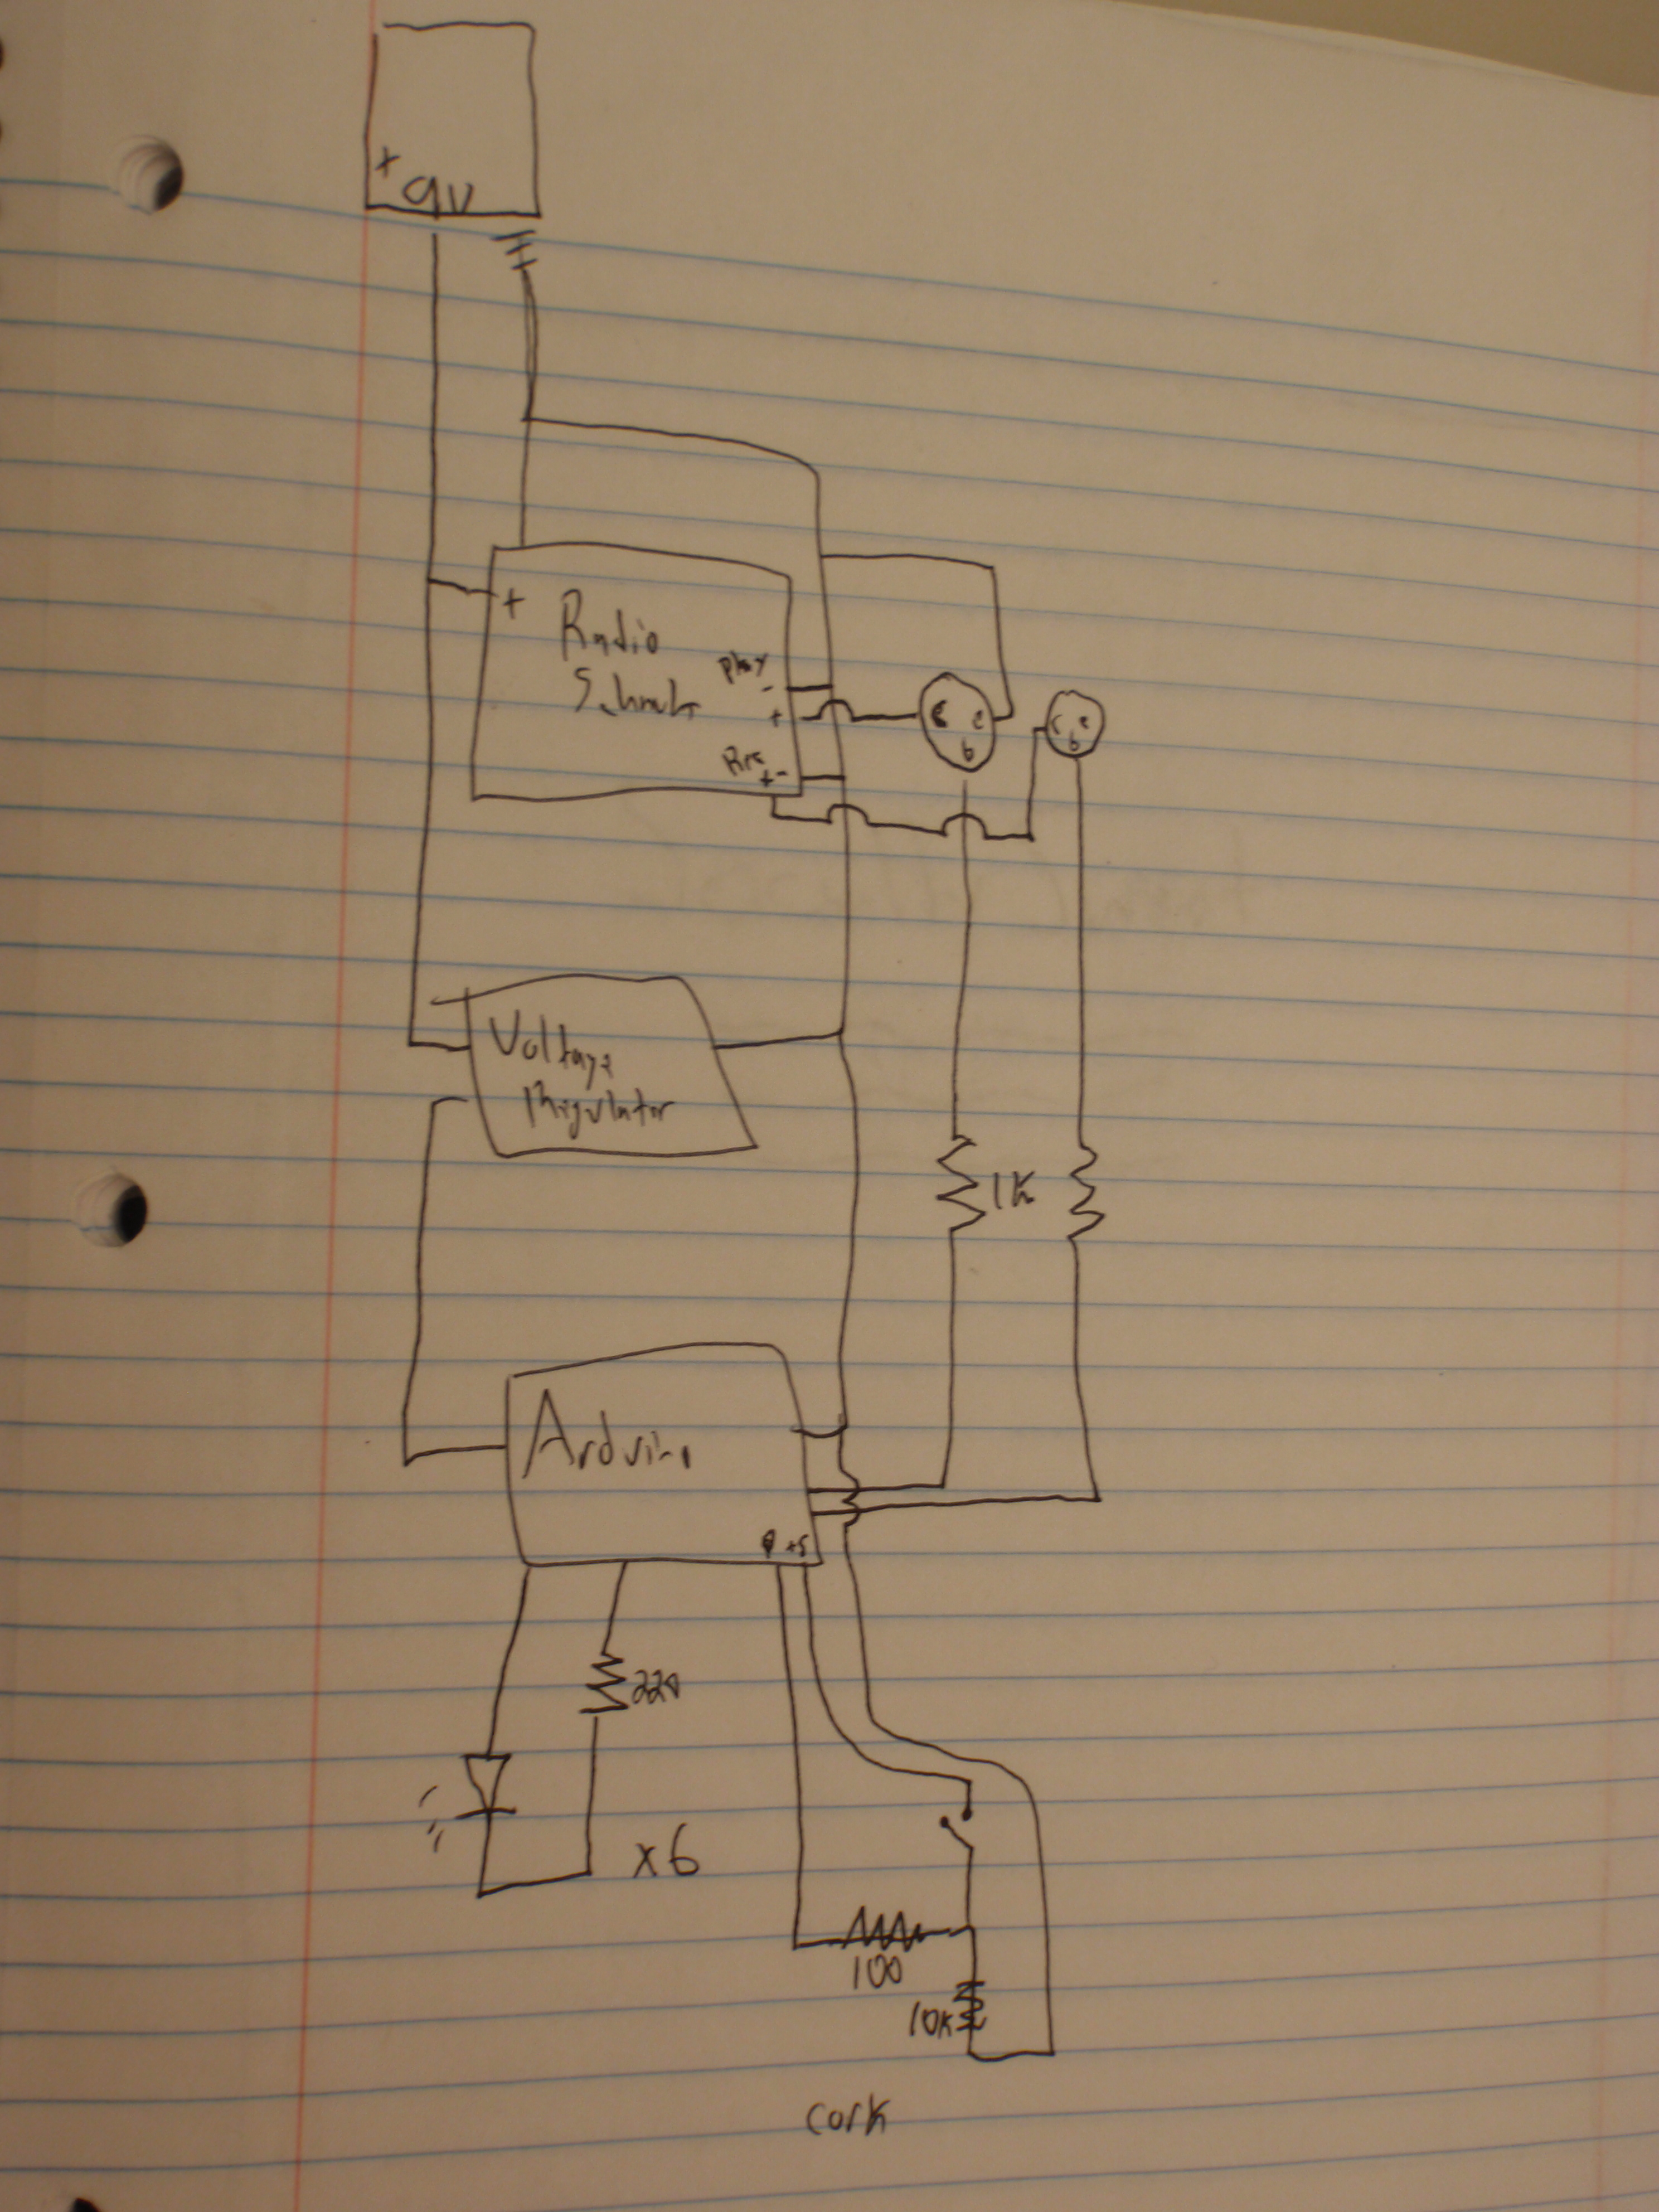
message in a bottle
Message in a Bottle is an Arduino microcontroller and sensor project that enables an individual to record their voice inside a glass bottle and send it to someone else for playback. By uncorking the bottle and speaking into it, the...
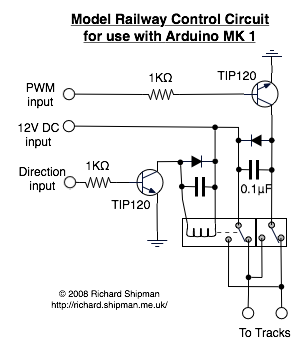
arduino model railway control
A model railway operates under computer control, utilizing a laptop to send commands via the USB port to an Arduino. The Arduino employs PWM (Pulse Width Modulation) to regulate the speed of the train. There were several challenges encountered, particularly...
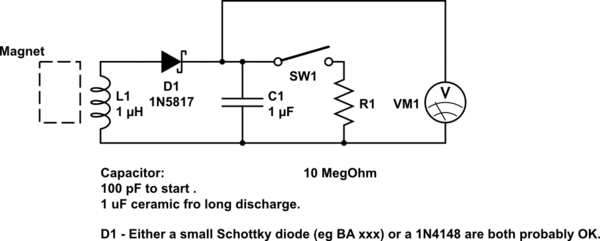
DIY kinetic energy harvester
A DIY kinetic energy harvester utilizing the electromagnetic method to generate electricity. The materials that will be used are currently known.
The project involves creating a kinetic energy harvester that converts mechanical energy from motion into electrical energy through electromagnetic induction....
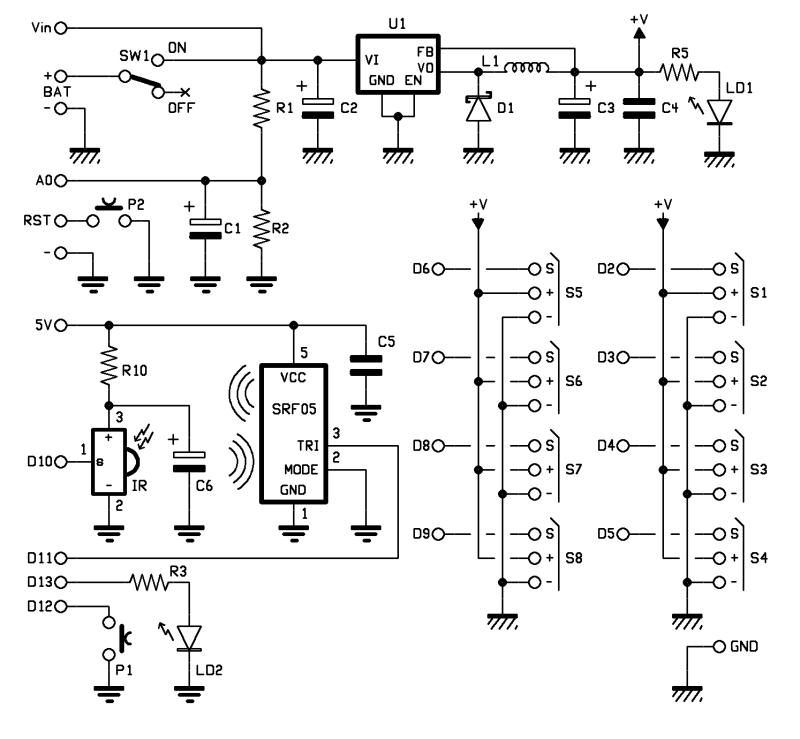
Robot shield for Arduino
The objective of this project is to consolidate various robot designs and transform them into a new device featuring updated hardware and standardized software, specifically utilizing Arduino for ease of use. These robots share three key components: a mechanical structure,...