


Controlling a LED using a switch
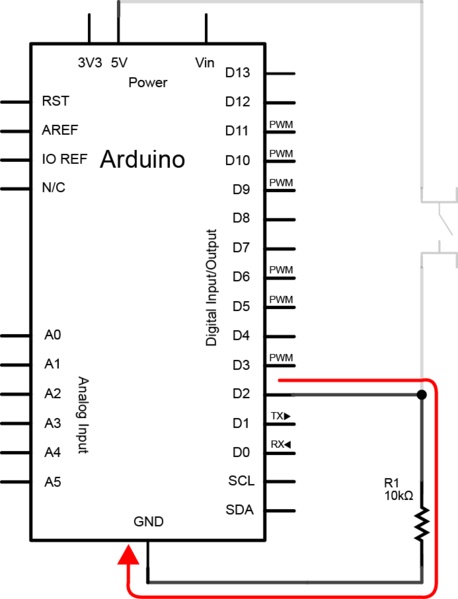
Description: To create the circuit, connect a switch as an input and an LED as an output to the Arduino. The components required include a switch, an LED, a 10kΩ resistor, a 470Ω resistor, a blue or yellow jumper wire, and a red jumper wire. The Arduino pin connects to the circuit between the resistor and the switch because the digital pin is configured to require a small amount of power to change states. This is beneficial as it prevents excessive power draw through the Arduino. However, if the pin is not connected to a known level in the circuit, it may float, meaning it could have any value. To address this issue, a resistor is used to connect the pin to ground, limiting the current flow. A large resistor, such as 10kΩ, is chosen to minimize power consumption. When the switch is not pressed, the pin is connected to ground through the resistor, and it behaves like a wire. When the switch is pressed, the pin connects directly to 5V, and the resistor limits the current to 0.5 mA, thus preventing a short circuit. After connecting the components, ROBOTC must be configured to recognize the pins before programming. The Parallax BOE Shield should be specified, with the LED connected to pin 5. Additionally, pin 2 must be designated as a Digital High Impedance (the LED switch with the resistor connected to ground) and named "ledSwitch." The Arduino should turn the LED on when the button is pressed and off when it is not pressed. This requires an infinite while loop and a method for determining the switch's state. Various approaches can be taken, but a second while loop that runs only when the button is pressed will be utilized. The equality operator "==" checks if the values on either side are equal, returning true if they are and false otherwise. This differs from the single equals sign "=", which is used for value assignment. By placing this condition inside the second while loop, the loop will execute only when the switch is pressed.
The circuit design consists of an Arduino microcontroller, a switch, an LED, and two resistors (10kΩ and 470Ω). The switch is connected to one side of the Arduino digital pin, while the other side is connected to ground through the 10kΩ resistor. This configuration ensures that when the switch is open (not pressed), the digital pin is pulled low to ground, preventing it from floating. The 10kΩ resistor serves to limit the current to the ground, thus protecting the microcontroller from excessive current draw.
When the switch is closed (pressed), the digital pin is connected to the positive voltage supply (5V), allowing current to flow through the 470Ω resistor and the LED. The LED will illuminate as long as the switch is pressed, and the 470Ω resistor serves to limit the current through the LED to a safe level, preventing damage.
The software component requires initializing the digital pins in the Arduino environment. A loop continuously checks the state of the switch. If the switch is detected as pressed, the LED will be activated; if not, the LED will remain off. The use of an infinite loop allows for real-time monitoring of the switch state, ensuring immediate response to user input.
This circuit is a fundamental example of interfacing digital inputs and outputs with an Arduino, showcasing basic principles of electrical engineering, such as current limiting, voltage levels, and digital logic. Proper implementation guarantees efficient operation while safeguarding the components involved.To create the circuit you will need to connect a switch as an input and an LED as an output to the Arduino. This means that you will need a switch, an LED, a 10k © resistor, a 470 © resistor, a blue or yellow jumper wire, and a red jumper wire.
The Arduino pin is connected to the circuit between the resistor and the switch. This is because the digital pin is configured such that it needs a small amount of power to change states. This is useful since we don`t want to draw too much power through the Arduino. However, this also means that if the pin is not connected to a known level in the circuit, it could have any value. This is called floating, since the value of the pin is neither high nor low. To solve this problem we use the resistor to connect the pin to ground. We use a resistor and not just a wire so that we can limit how much current is flowing through the connection.
Since we want to minimize the power draw we will use a large resistor, in this case 10k ©. When the switch is not pressed the pin is only connected to ground through the resistor. Since the pin will have what ever voltage value is applied to it, the resistor can be considered as a wire when the switch is not pressed. However, once the switch is pressed, the pin is directly connected to 5V and the resistor limits the current flowing to just 0.
5 mA, and thus prevents a short circuit. Now that we have everything connected, we need to tell ROBOTC how to configure the pins before we can program. We need to tell ROBOTC that we are using the Parallax BOE Shield, and that we have the LED connected to pin 5.
We also need to tell ROBOTC that pin 2 is a Digital High Impedance (the led switch with the resistor connected to ground) and name it "ledSwitch". We want the Arduino to turn the LED on when the button is pressed and turn it off when it is not pressed.
To do this we will need an infinite while loop and a way to determine the state of the switch. There are a lot of different ways to do this, but for now we will just use a second while loop that only runs when the button is pressed: The "=" means to check if the values to either side are equal. If the values are equal, then it will return true, otherwise it will return false. This is different than the single equals sign "=", which is used when assigning values. So by placing that code inside the second while loop`s condition, we can make that loop only run when the switch is pressed.
The circuit design consists of an Arduino microcontroller, a switch, an LED, and two resistors (10kΩ and 470Ω). The switch is connected to one side of the Arduino digital pin, while the other side is connected to ground through the 10kΩ resistor. This configuration ensures that when the switch is open (not pressed), the digital pin is pulled low to ground, preventing it from floating. The 10kΩ resistor serves to limit the current to the ground, thus protecting the microcontroller from excessive current draw.
When the switch is closed (pressed), the digital pin is connected to the positive voltage supply (5V), allowing current to flow through the 470Ω resistor and the LED. The LED will illuminate as long as the switch is pressed, and the 470Ω resistor serves to limit the current through the LED to a safe level, preventing damage.
The software component requires initializing the digital pins in the Arduino environment. A loop continuously checks the state of the switch. If the switch is detected as pressed, the LED will be activated; if not, the LED will remain off. The use of an infinite loop allows for real-time monitoring of the switch state, ensuring immediate response to user input.
This circuit is a fundamental example of interfacing digital inputs and outputs with an Arduino, showcasing basic principles of electrical engineering, such as current limiting, voltage levels, and digital logic. Proper implementation guarantees efficient operation while safeguarding the components involved.To create the circuit you will need to connect a switch as an input and an LED as an output to the Arduino. This means that you will need a switch, an LED, a 10k © resistor, a 470 © resistor, a blue or yellow jumper wire, and a red jumper wire.
The Arduino pin is connected to the circuit between the resistor and the switch. This is because the digital pin is configured such that it needs a small amount of power to change states. This is useful since we don`t want to draw too much power through the Arduino. However, this also means that if the pin is not connected to a known level in the circuit, it could have any value. This is called floating, since the value of the pin is neither high nor low. To solve this problem we use the resistor to connect the pin to ground. We use a resistor and not just a wire so that we can limit how much current is flowing through the connection.
Since we want to minimize the power draw we will use a large resistor, in this case 10k ©. When the switch is not pressed the pin is only connected to ground through the resistor. Since the pin will have what ever voltage value is applied to it, the resistor can be considered as a wire when the switch is not pressed. However, once the switch is pressed, the pin is directly connected to 5V and the resistor limits the current flowing to just 0.
5 mA, and thus prevents a short circuit. Now that we have everything connected, we need to tell ROBOTC how to configure the pins before we can program. We need to tell ROBOTC that we are using the Parallax BOE Shield, and that we have the LED connected to pin 5.
We also need to tell ROBOTC that pin 2 is a Digital High Impedance (the led switch with the resistor connected to ground) and name it "ledSwitch". We want the Arduino to turn the LED on when the button is pressed and turn it off when it is not pressed.
To do this we will need an infinite while loop and a way to determine the state of the switch. There are a lot of different ways to do this, but for now we will just use a second while loop that only runs when the button is pressed: The "=" means to check if the values to either side are equal. If the values are equal, then it will return true, otherwise it will return false. This is different than the single equals sign "=", which is used when assigning values. So by placing that code inside the second while loop`s condition, we can make that loop only run when the switch is pressed.
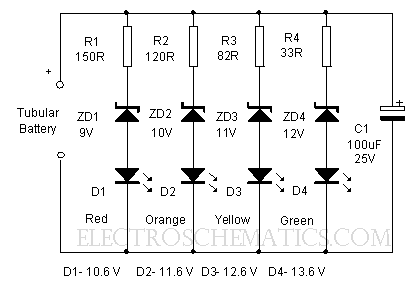
LED VoltMeter Circuit
A simple LED voltmeter is designed to monitor the charge level in a lead-acid battery or tubular battery. The terminal voltage of the battery is displayed using four LED indicators. The nominal terminal voltage for a lead-acid battery is 13.8...
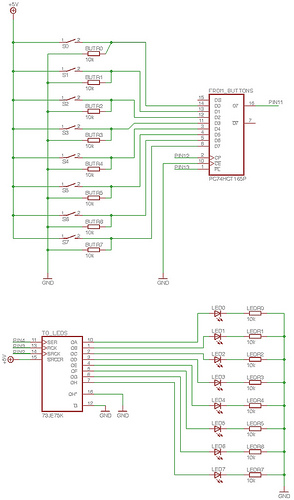
Basement LEDs
To enable the MonomeSerial software to recognize the monome clone, it is necessary to modify the Arduino's EEPROM serial number to match that of a genuine monome. Following Melka's updated instructions from the Bricktable blog is recommended. The D2XX drivers...
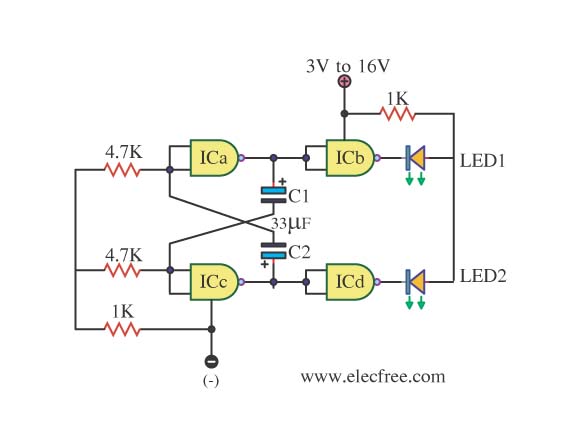
The simple LED Flasher by IC 4011
This is simply a LED flasher circuit that is suggested for construction. However, it is important to understand the use of transistors, which can be challenging when learning about digital electronics.
The LED flasher circuit operates by utilizing a basic astable...
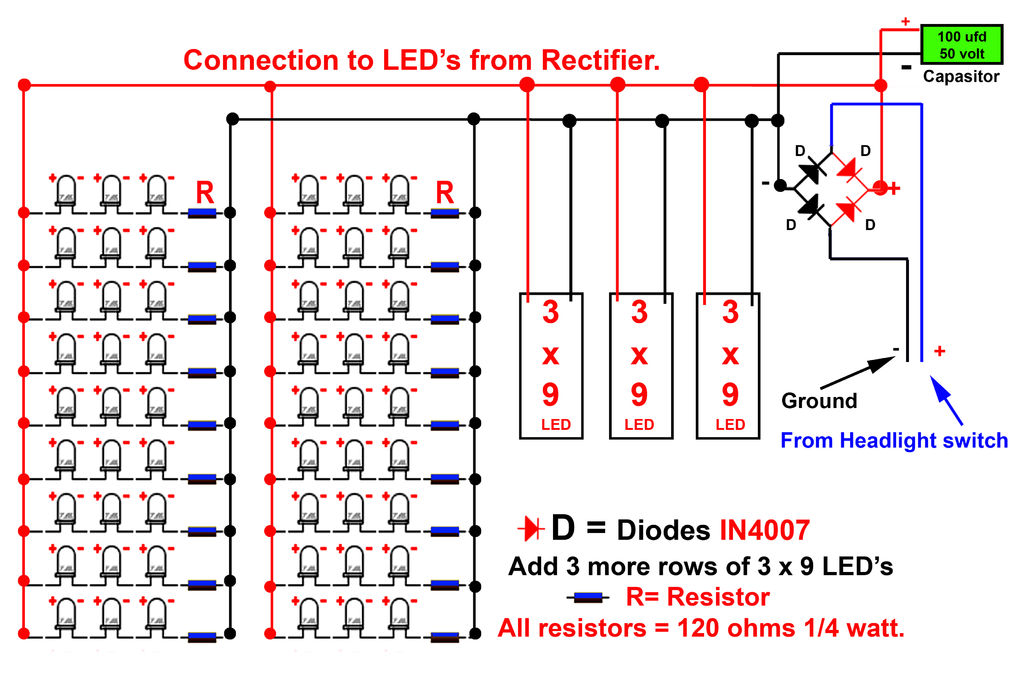
DIY Full LED 600+ Lumens LED Headlight
Gently bend the leads of the LEDs and, using the provided schematic circuit diagram, begin to solder. Once soldering is complete, it should...
To successfully assemble the LED circuit, it is essential to follow a systematic approach. Start by preparing the...
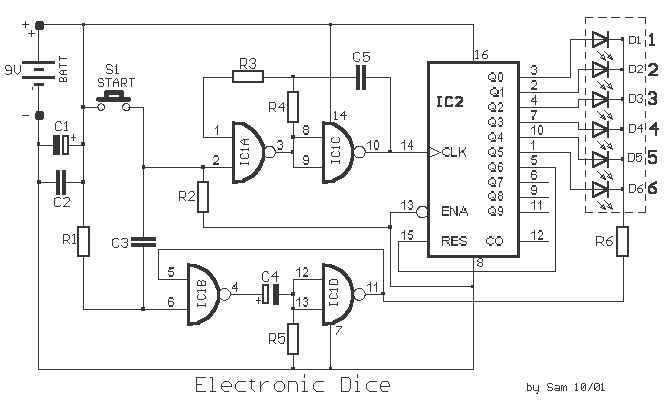
LED Dice II
The particular circuit is substantially a generator of accidental numbers, from 1 until the 6. The clue him we see in a line from led, that each one corresponds also in a number from the 1-6, if push and leave,...
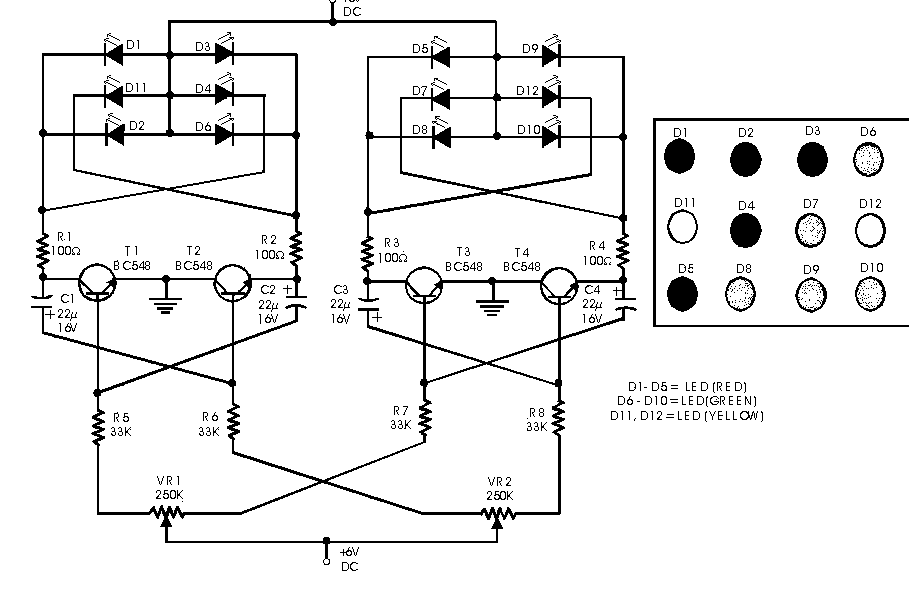
fun electronic circuits
This circuit serves as a decorative element or indicator, featuring adjustable flashing or dancing speeds of LEDs and the ability to create various light patterns. It comprises two astable multivibrators; the first is constructed using transistors T1 and T2, while...
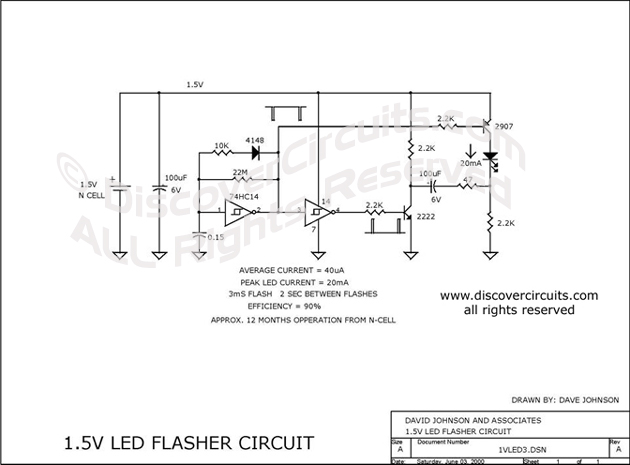
15v led flasher version b
This circuit is designed to extract additional energy from an alkaline battery cell by incorporating two transistors into a configuration similar to a previously mentioned design, thereby enhancing efficiency. A standard 1.5-volt alkaline N cell is capable of powering an...
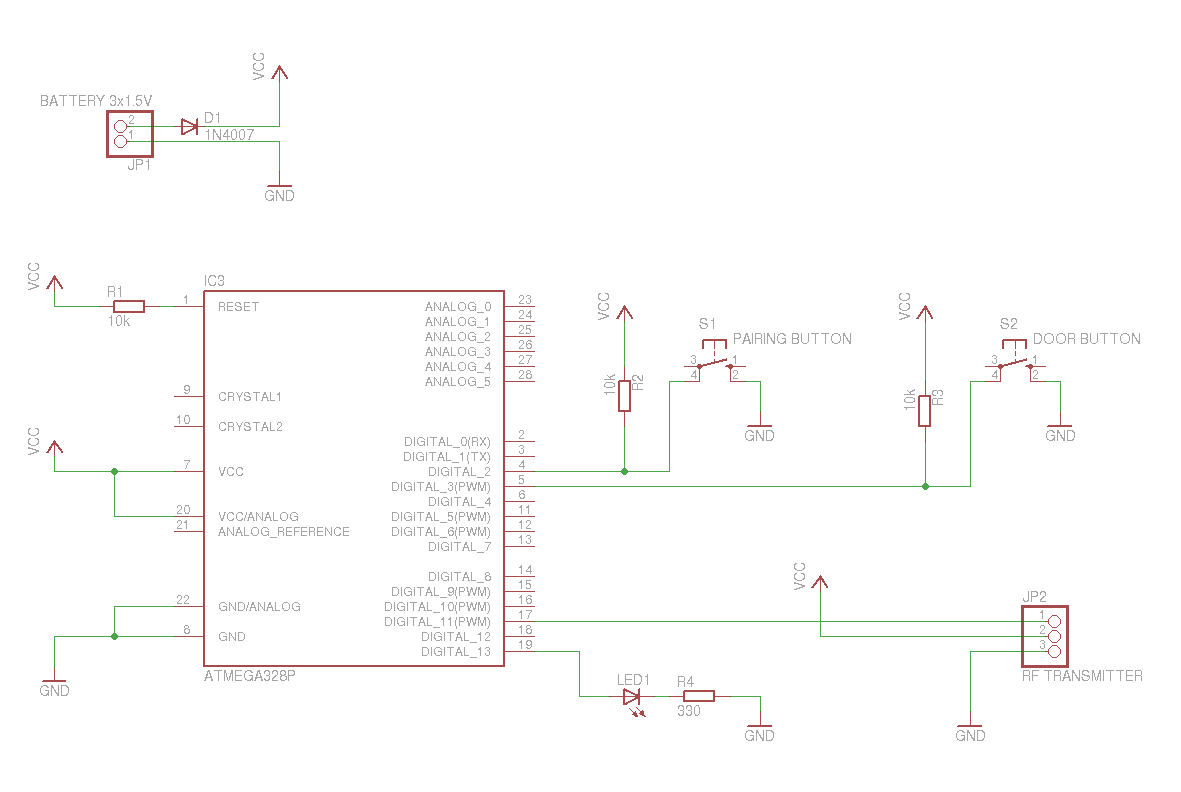
arduino based remote control for electric door
A replacement remote control system for an electric garage door was constructed after the original remote failed multiple times. Although the old remote could have been repaired, it was 35 years old and not particularly enjoyable to use.
The replacement...
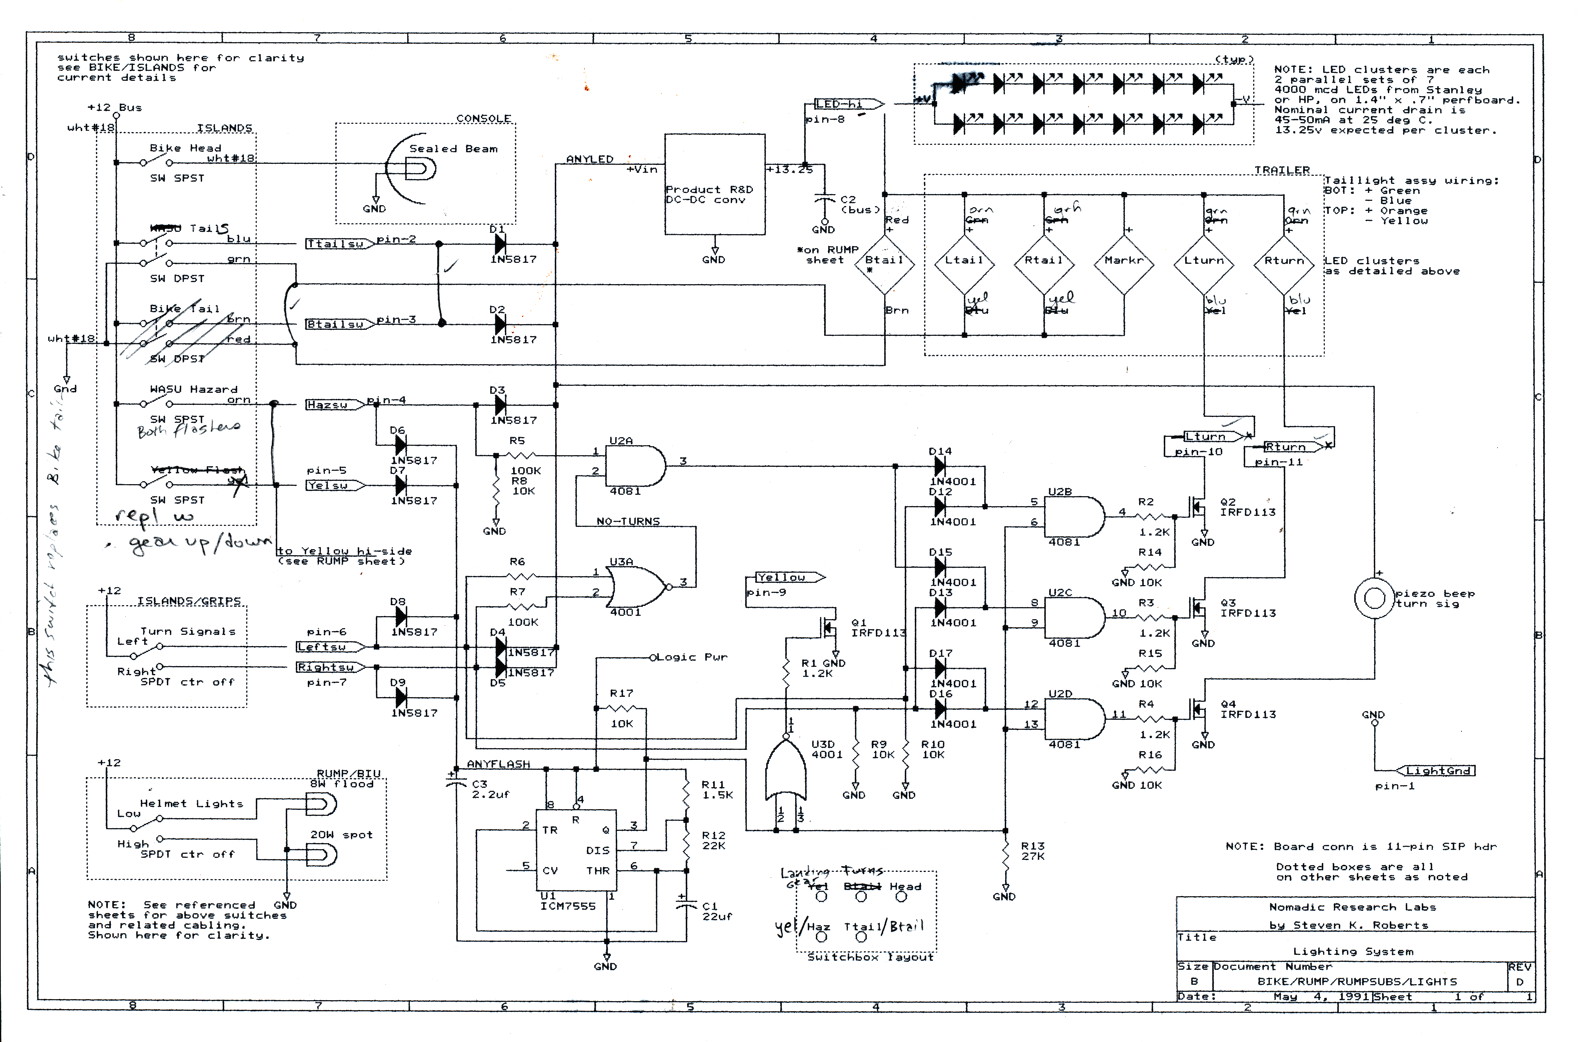
bikelab report 2 the sun lab and led taillights
This second issue of the Bikelab Notes, published during the development of BEHEMOTH at Sun Microsystems, focuses on high-brightness LED taillight assemblies that were not commercially available at the time, making this a unique project. The author also comments on...