


Arduino 2-axis servo solar tracker
#solar tracker
#servo
#light sensors
#tilt sensor
#Arduino
#2-axis
#DIY
#renewable energy
#photovoltaic
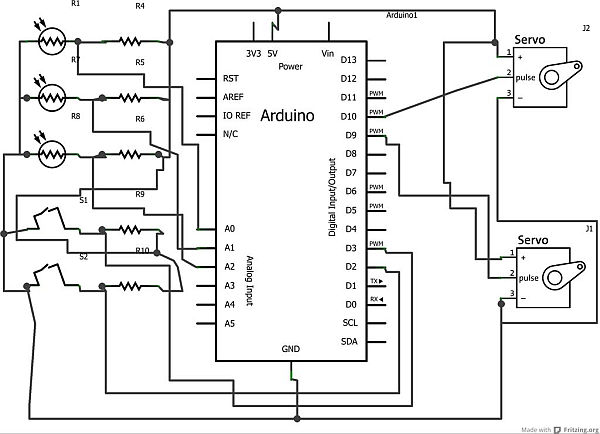
Description: The approximate center of the base was marked, and a hole was drilled large enough to accommodate a setscrew for the servo armature. The armature was then secured to the underside of the base using hot glue, ensuring that the glue did not enter the drilled hole. A total of three light sensors and one tilt sensor were utilized. Alternatives such as LEDs or photo-transistors can be employed instead of the CDS cells, and mercury switches can be used in place of the ball-bearing tilt sensor, though any changes will require corresponding updates in the code. Wires were soldered from a scrap ribbon cable to the leads of each light sensor, with a two-pin header attached at the opposite end for easy connection to a breadboard. Electrical tape, heat shrink, or liquid insulator was applied to the exposed sections of the wires to prevent short circuits. After completing these steps, the sensors were hot-glued at equal intervals around the mirror's circumference, ensuring the flat collecting side of each sensor was parallel to the mirror's plane and slightly angled outward from the center. The tilt sensor, which was a plastic box containing four contacts and a ball bearing, was positioned to prevent the tracker from pointing downward and to provide a y-axis end-stop. Wires were soldered to the four pins of the tilt sensor, which was then glued to the back side of the mirror with the leads oriented horizontally. With the mirror positioned vertically, the ball bearing should rest on the two middle leads.
The described circuit involves a servo mechanism controlled by light and tilt sensors, forming a basic automated tracking system. The servo armature is essential for adjusting the angle of the mirror based on sensor inputs. The light sensors detect ambient light levels and guide the servo to orient the mirror towards the light source, enhancing the system's responsiveness to environmental changes. The tilt sensor plays a critical role in preventing the mirror from tilting too far down, which could lead to mechanical failure or misalignment.
In terms of wiring, the use of a ribbon cable simplifies connections to the breadboard, allowing for easy adjustments and troubleshooting. The application of insulating materials is crucial for maintaining circuit integrity, as exposed wires can lead to short circuits, especially in an environment where movement occurs. The sensors are strategically placed to maximize their effectiveness, ensuring that they can adequately detect light from various angles.
The choice of components, such as the type of light sensors and the tilt sensor, can significantly affect the performance of the circuit. Substituting different sensors may require modifications to the code that processes the sensor inputs, indicating the importance of software-hardware integration in the design. The overall assembly should be tested to confirm that the sensors function correctly and that the servo responds accurately to their signals, providing a reliable tracking mechanism.I marked the approximate center of the base and drilled a hole large enough to screw the setscrew for the servo armature in. I then hot glued the armature to the underside of the base making sure not to get glue in the hole i drilled.
I used 3 light sensors and 1 tilt sensor. You can substitute LEDs orphoto-transistors for the CDS cells, and/or me rcury switches for theball bearing tilt sensor but your code will have to reflect the change(s). I soldered wires from a scrap ribbon cable to the leads of each light sensor and a 2 pin header on the opposite end to connect easily to the breadboard. Use electrical tape / heat shrink / liquid insulator on the bare parts of the wire so that they don`t short out.
Once that`s done, hot glue the sensors at equal intervals around the circumference of the mirror. I placed the sensors so that the flat collecting side of the sensor was parallel with the plane of the mirror and angled out from the center just slightly. The tilt sensor that I found was a plastic box with 4 contacts running through it and a ball bearing inside.
This sensor prevents the tracker from pointing at the ground and also gives the y-axis an end-stop. Solder wires onto the 4 pins of the tilt sensor then glue it on the back side of the mirror with the leads running horizontally. With the mirror pointing straight upward, the BB should be resting on the 2 middle leads.
The described circuit involves a servo mechanism controlled by light and tilt sensors, forming a basic automated tracking system. The servo armature is essential for adjusting the angle of the mirror based on sensor inputs. The light sensors detect ambient light levels and guide the servo to orient the mirror towards the light source, enhancing the system's responsiveness to environmental changes. The tilt sensor plays a critical role in preventing the mirror from tilting too far down, which could lead to mechanical failure or misalignment.
In terms of wiring, the use of a ribbon cable simplifies connections to the breadboard, allowing for easy adjustments and troubleshooting. The application of insulating materials is crucial for maintaining circuit integrity, as exposed wires can lead to short circuits, especially in an environment where movement occurs. The sensors are strategically placed to maximize their effectiveness, ensuring that they can adequately detect light from various angles.
The choice of components, such as the type of light sensors and the tilt sensor, can significantly affect the performance of the circuit. Substituting different sensors may require modifications to the code that processes the sensor inputs, indicating the importance of software-hardware integration in the design. The overall assembly should be tested to confirm that the sensors function correctly and that the servo responds accurately to their signals, providing a reliable tracking mechanism.I marked the approximate center of the base and drilled a hole large enough to screw the setscrew for the servo armature in. I then hot glued the armature to the underside of the base making sure not to get glue in the hole i drilled.
I used 3 light sensors and 1 tilt sensor. You can substitute LEDs orphoto-transistors for the CDS cells, and/or me rcury switches for theball bearing tilt sensor but your code will have to reflect the change(s). I soldered wires from a scrap ribbon cable to the leads of each light sensor and a 2 pin header on the opposite end to connect easily to the breadboard. Use electrical tape / heat shrink / liquid insulator on the bare parts of the wire so that they don`t short out.
Once that`s done, hot glue the sensors at equal intervals around the circumference of the mirror. I placed the sensors so that the flat collecting side of the sensor was parallel with the plane of the mirror and angled out from the center just slightly. The tilt sensor that I found was a plastic box with 4 contacts running through it and a ball bearing inside.
This sensor prevents the tracker from pointing at the ground and also gives the y-axis an end-stop. Solder wires onto the 4 pins of the tilt sensor then glue it on the back side of the mirror with the leads running horizontally. With the mirror pointing straight upward, the BB should be resting on the 2 middle leads.
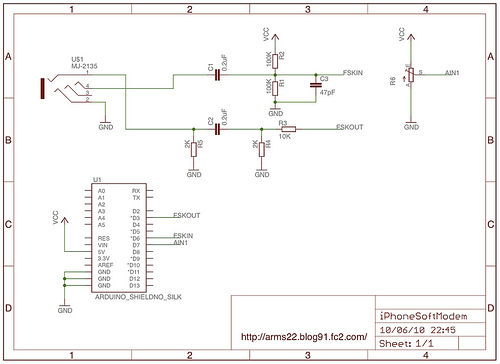
iOS interfacing Frequency Shift Keying (FSK) from Arduino
It has been determined that the Hijack method for obtaining serial data from the Mindflex to the iPhone will likely not be utilized. This decision is primarily based on the availability of most components needed to construct a similar system...
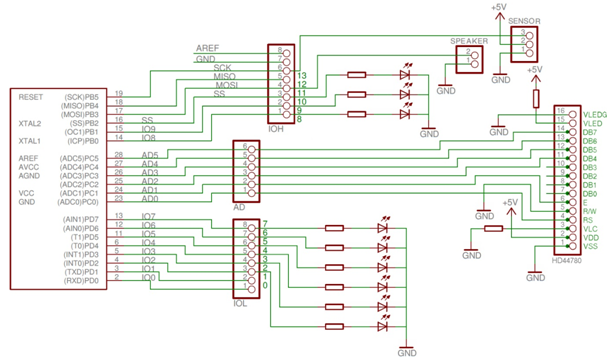
arduino uno parking sensor
Required components include an Arduino Uno, an HD44780 Character LCD, a PING))) Ultrasonic Distance Sensor, a speaker cone from an old computer, a breadboard, wires, resistors, colored LEDs, and Arduino software. The provided schematic illustrates the parking sensor circuit. A...
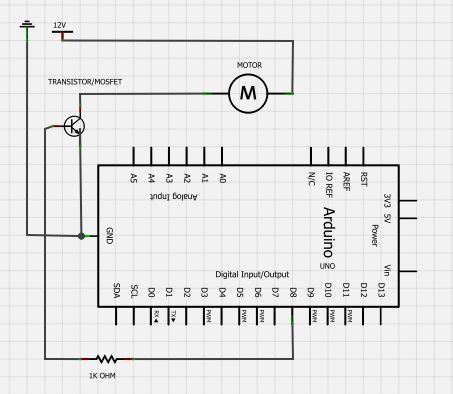
Arduino Running A DC Motor and High Current Lamp
The BC547 transistor has a maximum operating current of 100 mA and a maximum voltage rating of 65 volts. When oriented with the label facing the viewer, the three terminals from left to right are collector, base, and emitter. It...
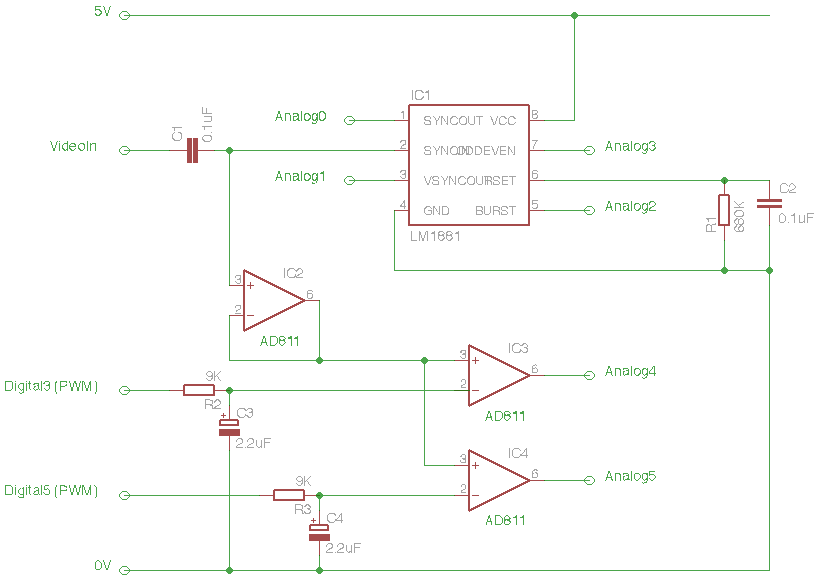
Arduino Eye Shield
The Arduino Eye Shield is a circuit board that can be plugged on top of the Arduino, enabling it to interpret analog video (PAL or NTSC) from a camera or other source. This provides the Arduino with visual capabilities, allowing...
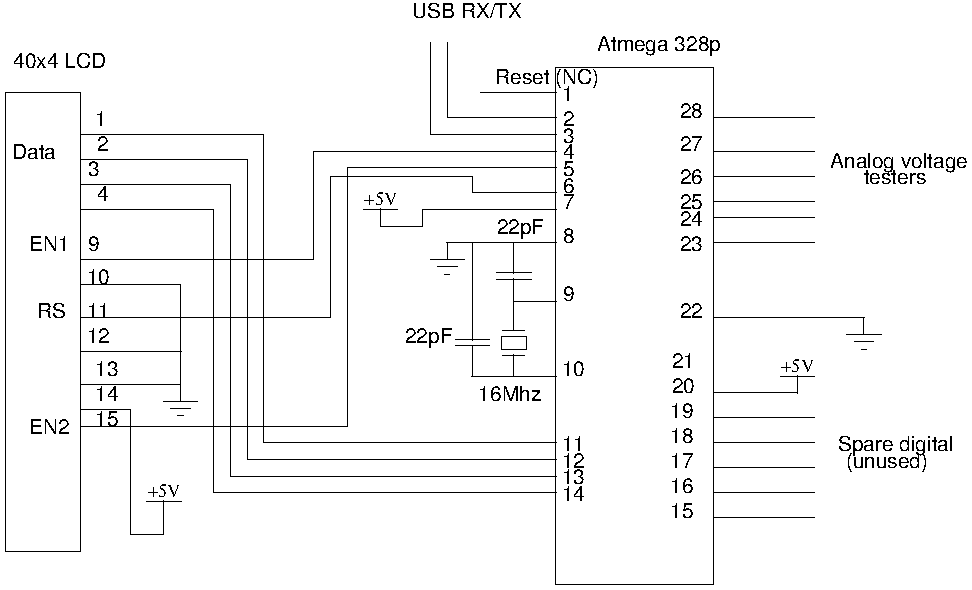
Microcontroller driven LCD panel with voltage measurement time EEPROM for computers
Drive a four-line LCD panel using an Arduino. The project initially aimed to control the LCD for displaying arbitrary information but evolved to include functionalities such as timekeeping, EEPROM read/write operations from the Atmel 328p, and voltage measurement. Multiple existing...
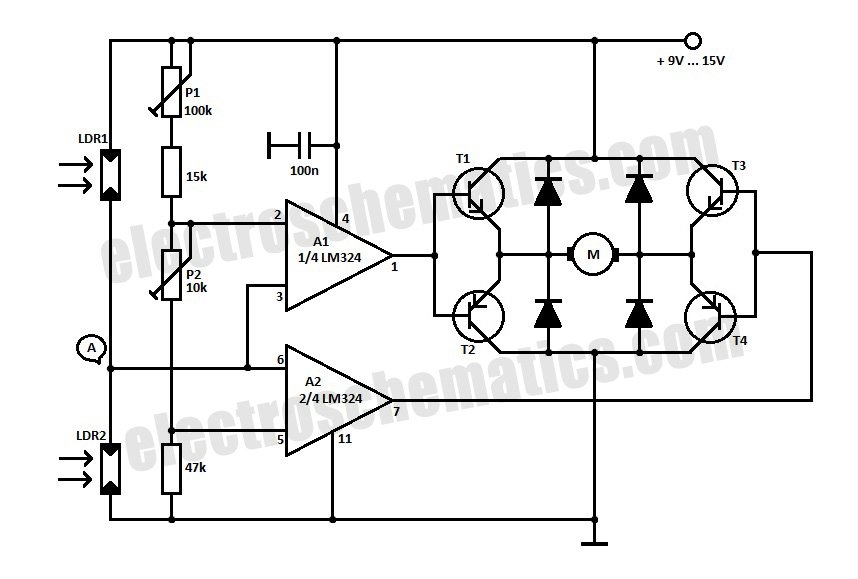
DIY Solar Tracker System Circuit
As the position of the sun changes, the illumination level on the light-dependent resistors (LDRs) also varies, causing the input voltage for the window comparator to deviate from half of the supply voltage. Consequently, the output of the comparator provides...
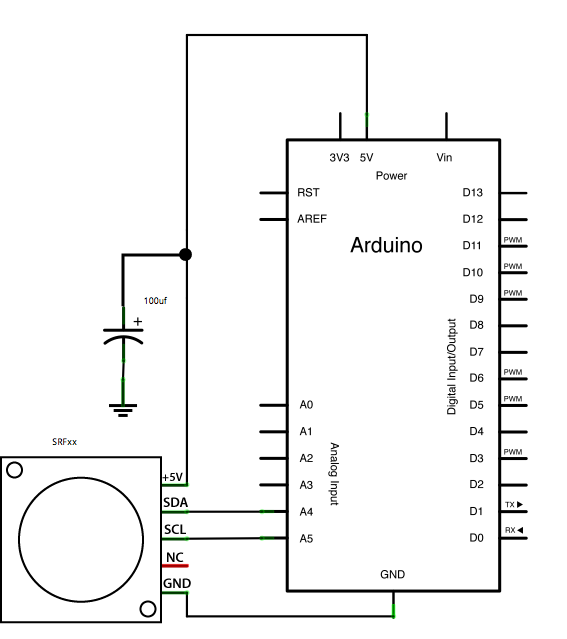
Arduino SFR Ranger Reader
This example demonstrates how to read a Devantech SRFxx, an ultrasonic range finder that communicates via the I2C synchronous serial protocol, using Arduino's Wire Library. The I2C protocol utilizes two wires for data transmission: a serial clock pin (SCL) that...
Hercules: The Motion Controlled Android Robot using Arduino
The motion games on the Nokia 5800 sparked an interest in creating a real-world version of a racing car controlled by tilting a phone. The motion-controlled robot, named Hercules due to its high torque and speed, is operated via Bluetooth...
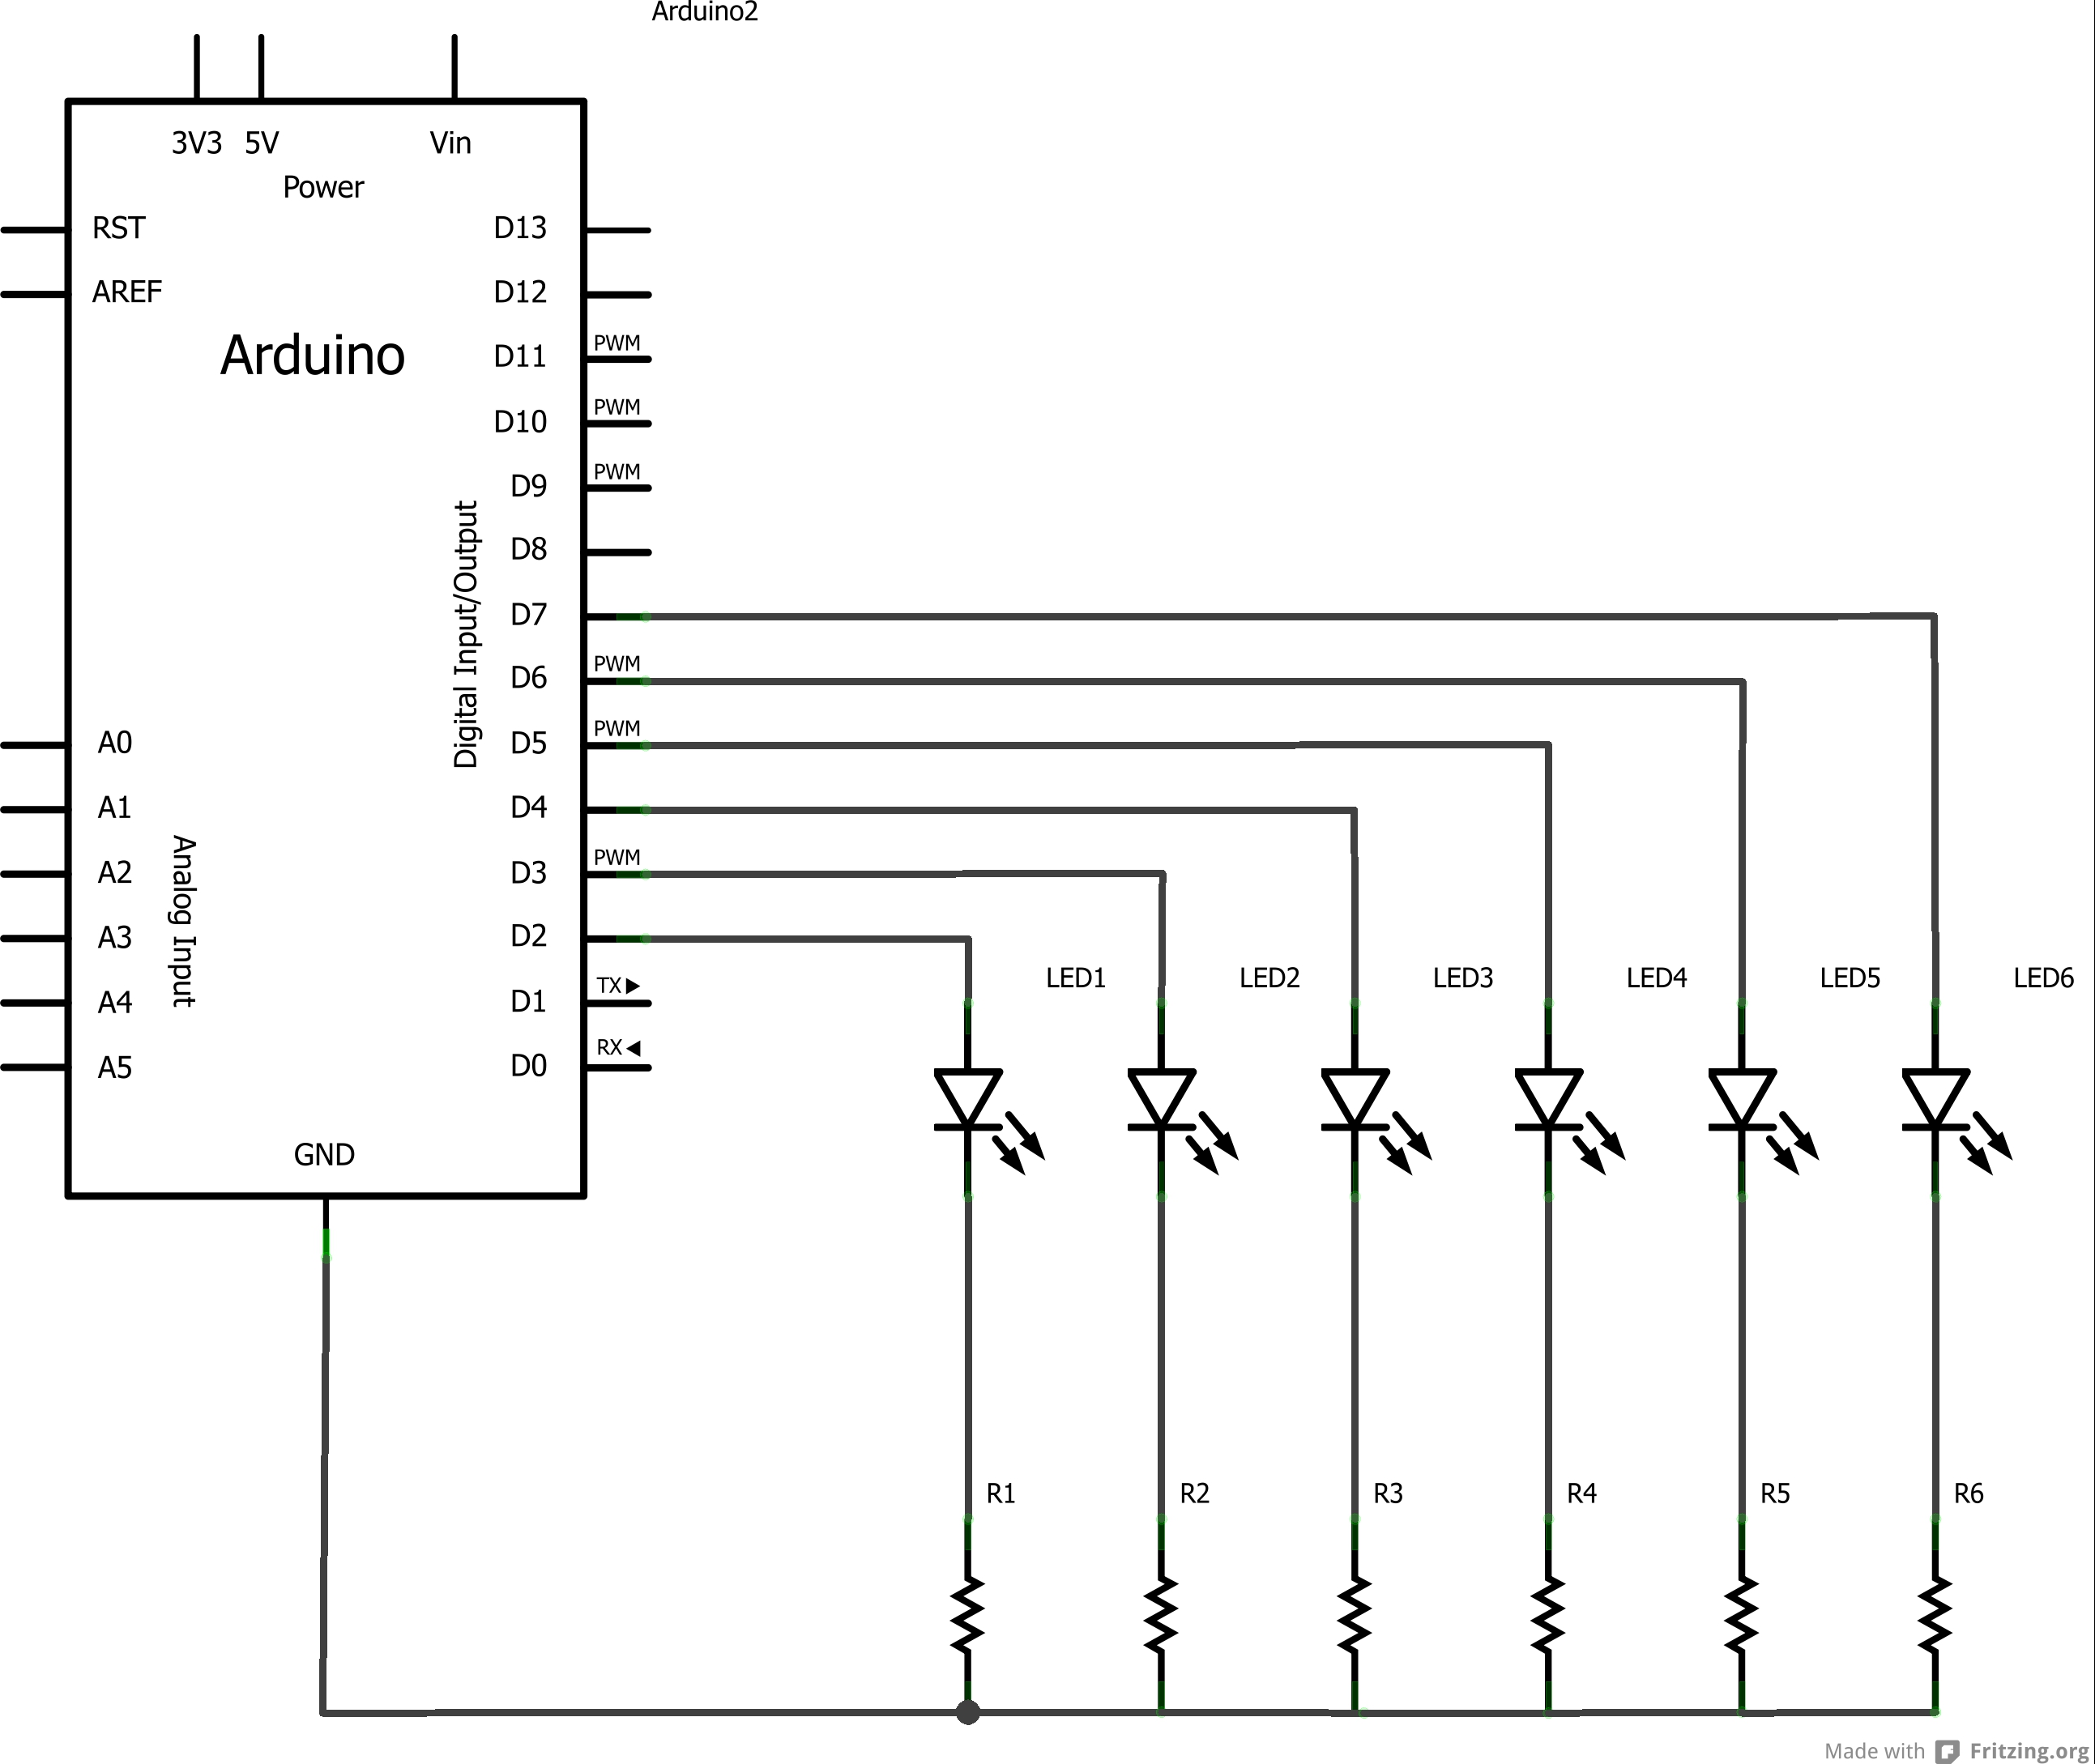
arduino masterpieces
A challenge encountered when beginning to work with Arduino was determining how to create circuit diagrams for projects. There are numerous software options available for drawing schematic diagrams, some of which are free while others require payment, each presenting a...